
With the rapid advancement of renewable energy vehicles, thermal management of traction battery packs has become a critical technological breakthrough. As a core energy storage component in electric vehicles, traction battery packs have a direct impact on driving range, service life and operational safety through their thermal performance. However, traditional rectangular fins and conventional straight fin structures often suffer from limited design freedom and insufficient heat dissipation, resulting in elevated cell temperature and increased risks of thermal runaway. To address these challenging issues, I innovatively adopted topology optimization to design phase change material (PCM) composite fin structures for traction battery packs, and verified their comprehensive thermal management performance through detailed numerical simulations. In this chapter, I systematically investigated the discharge heat generation, passive phase change cooling, forced air cooling integration, and thermal runaway propagation suppression by establishing multi-physics models for both prismatic and cylindrical lithium-ion cells in traction battery packs.
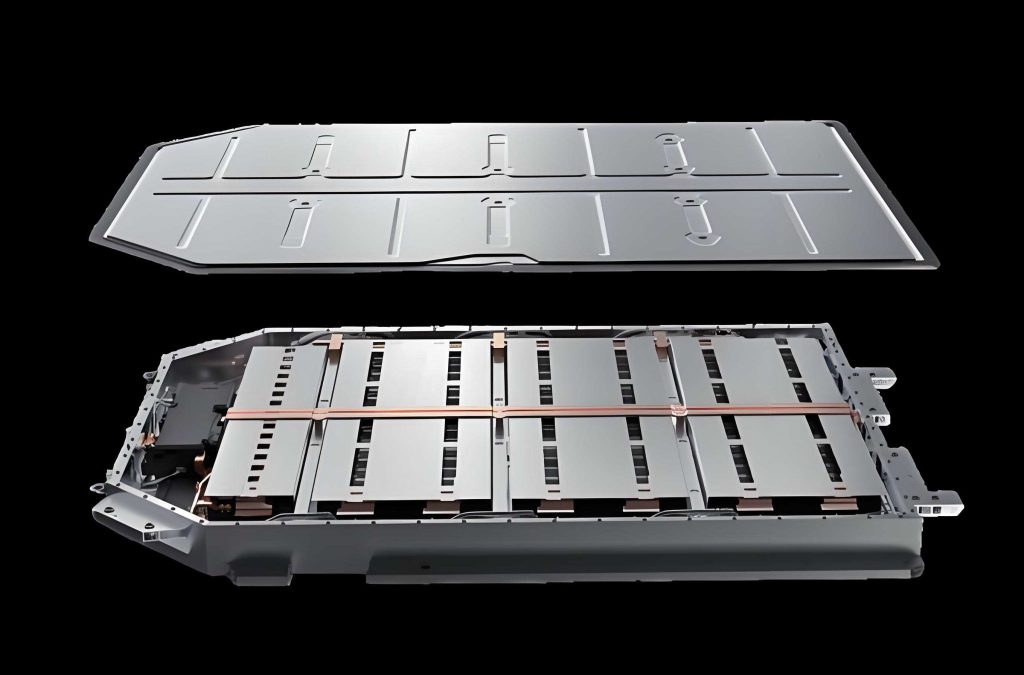
To obtain a reliable numerical platform, I first constructed the physical model of a lithium-ion traction battery cell and solved the transient heat dissipation problem in a discrete manner. Experimental data from discharge tests were adopted to validate the numerical model for multiple C-rates. The validation results demonstrated that the maximum deviation between simulated and experimental temperatures was less than 5%, which confirmed the reliability of the battery model. Based on this foundation, I implemented topology optimization for the fins embedded in the PCM domain. The average temperature within the battery was employed as the objective function while the volume ratio between aluminum fins and PCM was constrained to prescribed values. This optimization process was applied to different configurations that are relevant for traction battery packs, especially square cells and cylindrical cells. I further compared the thermal behavior of the optimized fins with that of conventional straight fins under identical volume ratio conditions.
At a discharge rate of 3C, the simulation showed that when the volume ratio was 0.1, the temperature of the battery pack with topology-optimized fins decreased by 8.2% compared with the conventional straight fin configuration. When the volume ratio was increased to 0.6, the temperature reduction reached 10.1%. Moreover, increasing the volume ratio from 0.1 to 0.6 for the topology-optimized fin design yielded a further temperature decrease of 7.9%. For cylindrical cells arranged in square and regular hexagonal patterns, I analyzed the effect of different fin topologies. It was observed that with the regular hexagonal topology, increasing the volume ratio from 0.1 to 0.5 reduced the temperature by approximately 4.8%, giving a better cooling performance than the square arrangement. These quantitative results prove that topology optimization can effectively reshape the fin distribution inside the PCM and substantially improve the heat transfer capability of passive thermal management systems for traction battery packs.
Beyond the basic passive cooling assessment, I extended the investigation to hybrid thermal management strategies by combining the optimized PCM-fin structure with different air cooling schemes. This part of my study concentrated on the effect of fin protrusion height, inlet wind speed and air flow arrangement, including single-side air cooling, double-side co-current air cooling and double-side counter-current air cooling. The three-dimensional conjugate heat transfer model that involved conduction in solid domains and convection in the air region was constructed for a battery module within the traction battery pack. The numerical grid was refined and a grid independence study was performed to ensure accuracy. The simulation results indicated that increasing the fin protrusion height significantly enhanced heat dissipation initially, but the improvement gradually saturated as the height exceeded 10 mm. Selecting a protruding height of 10 mm lowered the maximum temperature of the traction battery pack by about 2 °C compared with the case without protrusion. Among the three air cooling schemes, double-side counter-current air cooling showed the best comprehensive performance because it not only reduced the overall temperature but also greatly decreased the temperature difference among cells. Relative to single-side air cooling, this scheme lowered the cell temperature by about 1 °C and reduced the cell-to-cell temperature difference by nearly 90%. Therefore, double-side counter-current air cooling is regarded as the optimal air cooling arrangement for the topology-optimized PCM-fin module in traction battery packs.
In addition to normal discharge scenarios, thermal runaway propagation is an extremely important safety concern for traction battery packs. I numerically simulated the response of the optimized PCM-fin structure when one cell was triggered into thermal runaway. The heat release rate of the triggered cell was calculated based on the total stored energy and the duration of the runaway process. Comparing the topology-optimized fins with the conventional straight fins, I found that the optimized topology clearly hindered the heat propagation path. In the prismatic cell configuration, the normal cell temperature for the optimized fin case reached only 67.2 °C, whereas the straight fin with disconnected form gave 92.6 °C. For cylindrical cells, the optimized fin maintained the adjacent normal cell at 83.2 °C, which was much lower than 88.9 °C obtained with the straight fin. The optimized fin geometry blocks the heat transmission through the metallic phase change heat transfer skeleton and simultaneously improves the melting uniformity of PCM, thereby suppressing thermal runaway propagation in traction battery packs effectively. In the following sections, I present the detailed modeling process, mathematical formulation, key numerical results and practical implications for thermal management system design.
1. Lithium-Ion Battery Heat Generation and Heat Transfer Mechanism
In my research, both prismatic and cylindrical lithium-ion cells are considered because these two formats are widely used in modern traction battery packs. A lithium-ion cell mainly comprises a positive electrode, a negative electrode, an electrolyte, a separator, and a metallic casing. During charge and discharge, lithium ions are repeatedly intercalated and deintercalated between the positive and negative electrodes through the electrolyte. This electrochemical process is accompanied by complex heat generation including reversible reaction heat, irreversible Joule heat, polarization heat and side-reaction heat. Among them, the reversible heat originates from entropy change of the electrochemical reactions, while the irreversible heat is induced by ohmic resistance and polarization resistance.
To quantify the heat production rate in traction battery cells, I applied the widely accepted Bernardi model:
$$q = \frac{I}{V_\text{cell}}\left( U_\text{ocv} – U_\text{terminal} + T\frac{\partial U_\text{ocv}}{\partial T} \right)$$
In this expression, \(q\) is the volumetric heat generation rate, \(I\) is the operating current, \(V_\text{cell}\) is the volume of the cell, \(U_\text{ocv}\) is the open-circuit voltage, \(U_\text{terminal}\) is the terminal voltage, \(T\) is the absolute temperature and \(\partial U_\text{ocv}/\partial T\) denotes the entropic heat coefficient. Because the terminal voltage equals \(U_\text{ocv} – IR_\text{int}\), where \(R_\text{int}\) is the total internal resistance, another equivalent expression is:
$$q = \frac{I}{V_\text{cell}}\left( IR_\text{int} + T\frac{\partial U_\text{ocv}}{\partial T} \right)$$
For a battery discharging at a certain C-rate, the relation between discharge current and rated capacity must satisfy \(I = nC\). Hence a 51 Ah prismatic cell at 3C has a nominal current of 153 A, while a 2.6 Ah 18650 cylindrical cell at 3C has a nominal current of 7.8 A. The generated heat is first transported inside the electrode and electrolyte by thermal conduction and then dissipated through the surface into the surrounding coolant or PCM.
The governing differential equation for the transient temperature field in a solid battery is the Fourier energy equation:
$$\rho C_p \frac{\partial T}{\partial t} = \nabla \cdot \left( k\nabla T \right) + q$$
where \(\rho\) is the density, \(C_p\) is the specific heat capacity, and \(k\) is the anisotropic thermal conductivity tensor. Since the cell is not thermally isotropic, I defined different values for the in-plane and through-plane thermal conductivities. For the prismatic cell, the through-thickness direction has degraded conductivity while the in-plane direction is high. The heat convection at the cooling surface, on the other hand, is modeled by Newton’s law of cooling:
$$Q_\text{conv} = hA_\text{s}\left( T_\text{surface} – T_\text{fluid} \right)$$
where \(h\) is the convective heat transfer coefficient and \(A_\text{s}\) is the effective convective area. The ambient or inlet air temperature was fixed at 25 °C in all simulations unless otherwise stated. In view of the relatively low surface temperature encountered in my simulations, thermal radiation was ignored.
2. Model Geometry and Material Parameters
The basic geometry and material data for the cells, PCM and aluminum fins are summarized in Table 1, Table 2 and Table 3. These data constitute the baseline for constructing all meshed models of traction battery packs in this thesis.
| Parameter | Prismatic cell | Cylindrical cell |
|---|---|---|
| Nominal capacity (Ah) | 51 | 2.6 |
| Weight (g) | 816.47 | 47.5 |
| Dimensions (mm) | 148 × 27 × 91 | R = 18, H = 65 |
| Specific heat capacity (J kg⁻¹ K⁻¹) | 1050.31 | 1200 |
| Thermal conductivity (W m⁻¹ K⁻¹) | kxy = 14, kz = 1.31 | kxy = 0.2, kz = 37.6 |
| Density (kg m⁻³) | 2245.3 | 2873.5 |
| Property | Liquid phase | Solid phase |
|---|---|---|
| Phase-change temperature range (°C) | 37 | 35 |
| Density (kg m⁻³) | 770 | 810 |
| Specific heat capacity (kJ kg⁻¹ K⁻¹) | 2.2 | 1.9 |
| Latent heat (kJ kg⁻¹) | 241 | 241 |
| Thermal conductivity (W m⁻¹ K⁻¹) | 0.157 | 0.39 |
| Property | Value |
|---|---|
| Specific heat capacity (J kg⁻¹ K⁻¹) | 900 |
| Thermal conductivity (W m⁻¹ K⁻¹) | 238 |
| Density (kg m⁻³) | 2700 |
The PCM required for each battery was determined from the total heat generated during a complete discharge. By ignoring sensible heat compared with the latent heat and using 3C discharge for 1200 seconds as the most demanding condition, the necessary PCM volume for the prismatic cell was calculated as 23.144 cm³ and that for the cylindrical cell was computed as 13.715 cm³. Such volume is sufficiently large to absorb the majority of the heat while keeping the cell surface temperature near the melting point. In the optimized composite layout, the aluminum fins are embedded into the PCM domain to compensate for the poor thermal conductivity of the paraffin wax. The volume ratio \(\omega\) is defined as the volume of aluminum fins divided by the volume of PCM.
$$\omega = \frac{V_\text{fin}}{V_\text{PCM}}$$
In my parametric study, \(\omega\) was varied from 0.1 to 0.6 for the prismatic cell and from 0.1 to 0.5 for the cylindrical cell in square or hexagonal arrangement. The total PCM volume was conserved by enlarging the composite domain when the fin volume increased. For prismatic cells, because the cell height was fixed, only the length of the PCM domain in the in-plane direction was increased. For cylindrical cells, both the square and regular hexagon domains were adjusted so that the PCM region expanded with increasing fin fraction.
3. Topology Optimization Formulation and Numerical Implementation
Topology optimization is a mathematical approach that seeks the optimal spatial distribution of a given amount of material inside a prescribed design domain. In this research, the design domain is the PCM region, and the goal is to distribute aluminum fins such that the average temperature of the traction battery cell is minimized while a certain volume fraction of aluminum is maintained.
I employed the solid isotropic material with penalization model to interpolate the effective thermal conductivity, density and volumetric heat capacity between the PCM and the aluminum fin material. For each finite element in the design domain, a continuous design variable \(\gamma\) is introduced, where \(\gamma = 1\) represents aluminum and \(\gamma = 0\) represents pure PCM. The intermediate values are allowed during the optimization but are penalized by the power law to push the final design toward a black-and-white solution. The interpolation formulas for the material properties are:
$$k(\gamma) = k_\text{PCM} + \gamma^p \left( k_\text{fin} – k_\text{PCM} \right)$$
$$\rho(\gamma) = \rho_\text{PCM} + \gamma \left( \rho_\text{fin} – \rho_\text{PCM} \right)$$
$$C_p(\gamma) = C_{p,\text{PCM}} + \gamma \left( C_{p,\text{fin}} – C_{p,\text{PCM}} \right)$$
where \(p\) is the penalization exponent, usually taken as 3 for heat conduction problems. The effective density and specific heat are linearly interpolated because mass and heat capacity need not be penalized as strongly as conductivity. Since the material distribution is described at the element level, the raw solution may contain checkerboard patterns or length scales that cannot be manufactured. To overcome this issue, I applied a Helmholtz-type partial differential equation filter to the design variable:
$$\gamma_f = \gamma_c + r_\text{min}^2 \nabla^2 \gamma_f$$
where \(r_\text{min}\) controls the minimum length scale and \(\gamma_c\) is the unfiltered design field. This filter smooths the boundaries and removes numerical artifacts. After filtering, the projected physical density \(\bar{\gamma}\) is obtained through a hyperbolic tangent projection to reduce the amount of intermediate-density elements:
$$\bar{\gamma} = \frac{\tanh\left(\beta (\gamma_f – \gamma_\beta)\right) + \tanh(\beta \gamma_\beta)}
{\tanh\left(\beta (1 – \gamma_\beta)\right) + \tanh(\beta \gamma_\beta)}$$
I chose the projection slope \(\beta = 8\) and the projection point \(\gamma_\beta = 0.5\), which was found to produce crisp topologies without causing severe convergence difficulties.
To ensure that the optimized fins are suited for thermal management of traction battery packs, I focused on two objective functions. The first objective is the minimization of the thermal compliance, written as:
$$J_1 = \int_\Omega q \, T \, d\Omega$$
The second objective is the minimization of the average temperature over the battery domain or over a specific control region:
$$J_2 = \frac{1}{V_\Omega}\int_\Omega T \, d\Omega$$
Since the battery internal heat generation is spatially distributed in the electrode sheets, thermal compliance is proportional to the product of heat source and temperature field. Therefore, minimizing thermal compliance tends to reduce high-temperature regions as well. However, the average-temperature objective more directly reflects the desired outcome for traction battery packs. I performed comparative topology optimizations using both objectives and evaluated the resulting temperature distribution of the complete battery module. Results for the prismatic cell at \(\omega = 0.1\), 0.2 and 0.3 are shown in Table 4.
| Volume ratio ω | Min thermal compliance (°C) | Min average temperature (°C) |
|---|---|---|
| 0.1 | 41.26 | 40.37 |
| 0.2 | 39.58 | 39.35 |
| 0.3 | 38.01 | 37.77 |
The data clearly demonstrate that the average-temperature objective yields consistently lower final cell temperatures in all three volume fractions. Therefore, I chose the average-temperature minimization as the primary objective in all subsequent optimization runs of the fin structure for traction battery packs.
From the perspective of practical manufacturing, the optimized topology initially contained many curved branches, sharp corners and irregular jagged boundaries. Since such complex shapes are not convenient for large-scale production, I reconstructed the topology-optimized fin into a simplified geometry with straight edges. The reconstruction process preserved the main heat-flow paths while making the structure easier to machine and to mesh. A comparative simulation indicated that the temperature difference between the raw topology and the reconstructed geometry was only about 0.1 °C, e.g. 40.6 °C for the raw topology versus 40.5 °C for the reconstructed design. This result proves that a manufacturable approximation of the topology can retain most of its thermal benefit.
4. Topology Optimized Fins for Prismatic Cells
For the prismatic cell, the topology domain was initially set to be a thin rectangular layer around the cell block. The internal heat source was applied to the battery core, while the PCM domain was placed adjacent to the main heat-generating surfaces. In the optimization, only one pair of fins was generated because of the symmetric thermal boundary condition. After the topologies were obtained, I replicated the optimized two-dimensional fin layout along the cell height direction to form the complete three-dimensional composite structure. The volume ratio \(\omega\) was varied between 0.1 and 0.6 and the corresponding PCM domain length varied as given in Table 5.
| Volume ratio ω | Domain length (mm) |
|---|---|
| 0.1 | 37.6 |
| 0.2 | 39.8 |
| 0.3 | 42.0 |
| 0.4 | 44.1 |
| 0.5 | 46.3 |
| 0.6 | 48.5 |
For the same volume ratio, the topology-optimized fin has a branching tree-like pattern instead of the simple straight plate. This branching pattern creates multiple heat-flow channels from the battery surface into the bulk of the PCM, preventing local saturation of the PCM close to the cell surface. As the volume ratio increased, both the straight fin and the topology-optimized fin became thicker and longer. The overall temperature of the traction battery pack decreased as \(\omega\) increased. However, the gain gradually reduced because the latent heat capacity of the PCM decreased when more aluminum occupied the available volume.
At the end of a 3C full discharge, the average temperature of the cell with straight fins at \(\omega=0.1\) reached 44.3 °C, while that with the topology-optimized fin at the same \(\omega\) was only 40.3 °C. Similarly, at \(\omega=0.6\), the temperatures for the straight and optimized fin cases were 41.3 °C and 37.1 °C, respectively. The temperature reductions relative to the straight fin are therefore 8.2% and 10.1%. These data are summarized in Table 6 and they strongly support the idea that topology optimization can noticeably improve the thermal management performance of traction battery packs.
| Volume ratio ω | Straight fin (°C) | Optimized fin (°C) | Reduction (%) |
|---|---|---|---|
| 0.1 | 44.3 | 40.3 | 8.2 |
| 0.3 | 42.5 | 38.01 | 10.5 |
| 0.6 | 41.3 | 37.1 | 10.1 |
Within the family of optimized fins, increasing \(\omega\) from 0.1 to 0.6 continuously decreased the cell temperature by 7.9%. The temperatures at \(\omega=0.4\), 0.5 and 0.6 were 37.4 °C, 37.2 °C and 37.1 °C, respectively. Thus the difference between \(\omega=0.4\) and \(\omega=0.6\) is less than 0.3 °C. From the standpoint of material economy and structural robustness, \(\omega=0.4\) is considered the preferred volume ratio for the prismatic cell in traction battery packs.
Another important observation is that the optimized fin has a discontinuity between the two neighboring battery cells. This discontinuity breaks the continuous conductive heat flow path through the aluminum fins between adjacent cells. Consequently, the heat released by one cell is forced to enter the PCM instead of being transferred directly to the neighboring cell. This feature becomes particularly beneficial in thermal runaway prevention and is discussed in the next section.
5. Influence of Cell Arrangement for Cylindrical Traction Battery Packs
When cylindrical cells are considered, the PCM domain can be constructed in different forms depending on the relative arrangement of cells. I considered two common packing arrangements in traction battery packs: square arrangement and regular hexagonal arrangement. In the square arrangement, cells are placed at the vertices of a square so that each cell has four closest neighbors. In the regular hexagonal arrangement, every cell has six equidistant neighbors, producing a more compact and geometrically efficient packing. The required PCM volume was held constant at 13.715 cm³ across both cases so that the observed differences could be attributed solely to the arrangement and the corresponding fin topologies.
For a fixed \(\omega\), the side length of the square and the hexagon cell changed according to Table 7.
| Volume ratio ω | Square side length (mm) | Hexagon side length (mm) |
|---|---|---|
| 0.1 | 18.9 | 21.0 |
| 0.2 | 19.5 | 21.6 |
| 0.3 | 20.1 | 22.3 |
| 0.4 | 20.7 | 22.9 |
| 0.5 | 21.3 | 23.6 |
The topology-optimized fins obtained for the square and hexagon arrangement both show a tree-like branched shape extending from the central cylindrical cell surface toward the outer corners. At low volume ratios, the fin branches are thin and sparse, while at higher volume ratios the main trunks become thicker and more second-order branches appear. The distribution of fins over the whole PCM domain is more uniform in the hexagonal case than in the square case. Since a regular hexagon has more corner regions, the fins can reach further into the PCM without using extra material.
For the square arrangement at the end of a 3C discharge, the straight fin had a temperature of 45.4 °C when \(\omega=0.1\), whereas the topology-optimized fin achieved 42.7 °C under the same conditions. This corresponds to a temperature reduction of approximately 6%. By increasing \(\omega\) from 0.1 to 0.5, the optimized structure reduced the cell temperature from 42.7 °C to 40.1 °C, a decrease of 6.2%. However, after \(\omega=0.4\), the marginal benefit was small because the cell temperature only changed from 40.2 °C at \(\omega=0.4\) to 40.1 °C at \(\omega=0.5\).
For the regular hexagonal arrangement, the straight fin at \(\omega=0.1\) produced a temperature of 45.2 °C at the end of discharge. The optimized fin lowered this value to 41.7 °C, a notable decline of about 7.8%. Increasing the volume ratio from 0.1 to 0.5 brought the temperature down from 41.7 °C to 39.7 °C, exhibiting a total reduction of 4.6% within the optimized family. At \(\omega=0.4\), the temperature was already 39.6 °C, indicating that the optimum layout can be achieved with a moderate amount of aluminum.
When comparing the two arrangements at the same volume fraction, the regular hexagonal topology consistently gives a lower temperature. At \(\omega=0.1\), the difference is 0.9 °C, and at \(\omega=0.5\), the difference is still near 0.5 °C. This outcome is caused by the better heat diffusion path in the hexagon domain, where the fin branches more evenly spread the generated heat across the phase change material. Table 8 summarizes the simulated cell temperature values for the cylindrical cell topology.
| Volume ratio ω | Square straight fin (°C) | Square optimized fin (°C) | Hexagon straight fin (°C) | Hexagon optimized fin (°C) |
|---|---|---|---|---|
| 0.1 | 45.4 | 42.7 | 45.2 | 41.7 |
| 0.3 | — | 41.0 | — | 40.4 |
| 0.5 | — | 40.1 | — | 39.7 |
Based on the above results, I concluded that the regular hexagonal arrangement with topology optimization provides better temperature control in traction battery packs using 18650-format cylindrical cells. The outcomes can be used to guide cell layout and fin design in high-energy-density battery modules.
6. Three-Dimensional Reconstruction and Hybrid Air Cooling Optimization
Since the topology optimization was performed on a two-dimensional cross section, the resulting fin pattern had to be extruded in the third direction to form the actual battery module. However, the raw topology contained non-manufacturable serrated edges and multilevel branches that cannot be easily processed. Therefore, I first reconstructed the fin layout into a simplified straight-edged shape while preserving the main skeleton of the topology. The reconstructed model was then used in a three-dimensional conjugate heat transfer simulation. The geometry consisted of the battery core, the PCM and fin domain, and an extended air domain above the fins. Figure 1 already illustrated the full traction battery pack module. In this section, the emphasis is on the optimization of the cooling air flow.
I set the computational domain according to three different air cooling concepts. In the single-side air cooling scheme, only one side of the battery pack has an air channel and the opposite side is treated as an open surface with natural convection. In the double-side co-current air cooling scheme, both left and right sides have an air channel with the same inlet velocity and flow direction. In the double-side counter-current air cooling scheme, the flow directions on the two sides are opposite so that the cool air enters simultaneously from opposite ends. These three configurations represent different levels of design complexity for traction battery packs and have different effects on temperature uniformity.
The boundary condition at the battery exterior and at the side surfaces without forced convection was described by a natural convective coefficient \(h=10\) W m⁻² K⁻¹, with the ambient temperature set to 25 °C. The remaining surfaces were assumed adiabatic. The air inlet temperature was also 25 °C and the outlet was set to a zero-pressure outflow boundary. The k-epsilon turbulence model was not necessary for the low inlet velocities used here, since the Reynolds number in the channel remained moderate. Instead, the laminar flow model was selected and solved together with the energy equation in the fluid domain.
To guarantee mesh-independent solution, I performed a grid independence study using the single-side air cooling model with a fin protrusion height of 5 mm. Six different mesh resolutions were tested, containing approximately 170,000, 200,000, 320,000, 440,000, 590,000 and 850,000 elements. The predicted average battery temperature for each mesh count is shown in Table 9.
| Number of elements | Average cell temperature (°C) | Relative to finest mesh (%) |
|---|---|---|
| 170,000 | 38.76 | 0.1 |
| 200,000 | 38.74 | 0.06 |
| 320,000 | 38.68 | 0.03 |
| 440,000 | 38.66 | 0.01 |
| 850,000 | 38.64 | 0 |
The temperature variation between 320,000 and 850,000 elements is negligible. Thus, the mesh strategy with approximately 320,000 elements was chosen for the subsequent simulations to balance accuracy and computational cost. For the double-side cooling configurations, an equivalent target element number was maintained by locally refining the boundary layers around the protruding fins.
7. Impact of Fin Protrusion Height
The optimized fins embedded in the PCM layer can be extended above the PCM top surface and exposed directly to the airflow. The protruding part then serves as a fin-to-air heat exchanger. In my simulations, the air inlet velocity was set to 1.5 m/s and the fin protrusion height was changed from 0 mm to 20 mm. The average cell temperature at the end of the 3C discharge is shown in Table 10.
| Protrusion height (mm) | Average temperature (°C) | Reduction relative to 0 mm (°C) |
|---|---|---|
| 0 | 40.6 | — |
| 5 | 38.7 | 1.9 |
| 10 | 38.3 | 2.3 |
| 15 | 38.0 | 2.6 |
| 20 | 37.9 | 2.7 |
When the protrusion height was zero, the only path for heat rejection was the upper flat surface of the PCM enclosure, so the cooling was weak. By providing a 5 mm protrusion, the heat from the PCM was conducted through the aluminum fin directly into the air stream, and the average temperature fell by about 1.6 °C. A 10 mm protrusion lowered the temperature by another 0.4 °C. However, increasing the protrusion from 10 mm to 20 mm improved the cooling by only about 0.4 °C extra. This indicates that the benefit gained by enlarging the convective area gradually decreases because the external heat transfer coefficient is not constant and the additional fin tip becomes less effective. Moreover, longer fins increase the manufacturing difficulty and the pressure loss in the airflow channel. Hence, 10 mm was selected as an appropriate protrusion height for both single-side and double-side air cooling configurations in traction battery packs.
8. Comparison among Single-Side, Double-Side Co-Current and Counter-Current Air Cooling
After the fin protrusion height was fixed at 10 mm, I performed a series of simulations for three air cooling schemes under different inlet velocities. Five velocities were considered, 1.0 m/s, 1.5 m/s, 2.0 m/s, 2.5 m/s and 3.0 m/s. In each case, the cell temperature and the maximum cell-to-cell temperature difference were extracted at the end of the 3C discharge. The final temperatures for the three cooling schemes are summarized in Table 11.
| Inlet velocity (m/s) | Single side (°C) | Double side co-current (°C) | Double side counter-current (°C) |
|---|---|---|---|
| 1.0 | 38.55 | 37.7 | 37.7 |
| 1.5 | 38.40 | 37.5 | 37.5 |
| 2.0 | 38.20 | 37.3 | 37.3 |
| 2.5 | 38.00 | 37.1 | 37.1 |
| 3.0 | 37.80 | 36.9 | 36.9 |
At a fixed velocity, the two double-side cooling schemes produce essentially the same average cell temperature. The benefit of double-side cooling relative to single-side cooling is about 0.7 °C to 1.0 °C depending on velocity. This is because the total airflow area is doubled and the air can contact both sides of the module. Since the heat flux is uniformly distributed across both sides, the local surface temperature decreases and the heat transfer coefficient becomes more effective.
Although the average temperature is nearly identical between co-current and counter-current double-side cooling, there is a substantial difference in the temperature spatial distribution. For the co-current scheme, the left inlet side is cold and the right outlet side is warm. Therefore, cells on the left side remain cooler than those on the right side. The difference grows with inlet velocity because the cooling intensity at the inlet increases while the outlet air has already absorbed a considerable amount of heat. The measured maximum temperature difference across the cells at 3.0 m/s is around 0.19 °C for the co-current double-side scheme and 0.18 °C for the single-side scheme.
In the counter-current scheme, the left channel has air flowing from left to right, whereas the right channel has air flowing from right to left. In the middle of the module, the two streams meet and provide a more balanced thermal environment. The cell temperature increases along each airflow path, but the two opposite trends compensate each other. Consequently, the cell-to-cell temperature difference is much smaller. At all tested velocities, the maximum temperature difference in the counter-current scheme was not higher than 0.01 °C. Compared with single-side cooling, the maximum cell-to-cell temperature difference was reduced by nearly 90%. Thus the double-side counter-current air cooling is not only capable of lowering the maximum cell temperature but also dramatically improves the thermal uniformity of traction battery packs. The detailed cell-to-cell temperature differences are compared in Table 12.
| Inlet velocity (m/s) | Single side (°C) | Double side co-current (°C) | Double side counter-current (°C) |
|---|---|---|---|
| 1.0 | 0.12 | 0.16 | ≤0.01 |
| 1.5 | 0.14 | 0.17 | ≤0.01 |
| 2.0 | 0.16 | 0.18 | ≤0.01 |
| 2.5 | 0.18 | 0.19 | ≤0.01 |
| 3.0 | 0.20 | 0.20 | ≤0.01 |
The rapid increase of temperature difference with velocity for single-side and co-current cooling is caused by the growing asymmetry between the inlet and outlet regions. The counter-current configuration reverses the flow direction in one channel, so that one channel cools the first half of the module while the other cools the second half. The result is equivalent to averaging the temperature pattern from the two ends, giving an almost perfectly uniform temperature distribution. Therefore, I recommend double-side counter-current air cooling as the most reliable choice when strict temperature uniformity is required for large traction battery packs.
9. Investigation of Thermal Runaway Propagation Suppression
Thermal runaway remains the most severe safety hazard for lithium-ion traction battery packs. When one cell undergoes an internal short circuit and rapidly releases stored energy, the high temperature can trigger adjacent cells through the thermally conductive components between them. The aluminum fins embedded in the PCM significantly affect the propagation process. Since aluminum has a thermal conductivity of 238 W m⁻¹ K⁻¹, which is three orders of magnitude higher than the PCM conductivity, a continuous metallic path between neighboring cells can accelerate heat propagation. In my optimized topology, the fin branches are deliberately arranged in a discontinuous form. This prevents the formation of a long continuous metallic bridge from one battery to the other. In this section, I present the numerical simulation of thermal runaway propagation in both prismatic and cylindrical cell configurations to verify the advantage of the topology-optimized fin design.
The thermal runaway model was constructed according to conservative recommendations from literature. The fully charged cell has a state of charge (SOC) of 100% and the thermal runaway initiating temperature is set to 150 °C. Before the trigger, all cells generate heat at a rate equivalent to 3C discharge. At 60 seconds, the central cell is assumed to enter thermal runaway and releases all its stored electrochemical energy within 10 seconds. The volumetric power density during runaway is 136.3 MW m⁻³ for the prismatic cell and 129.3 MW m⁻³ for the cylindrical cell. The simulation continues until 500 seconds so that the peak temperature and the temperature evolution of the neighboring normal cell can be fully captured.
For the prismatic cell module, I compared the straight fin with continuous connection, the straight fin with a discontinuous connection, and the topology-optimized discontinuous fin. The continuous straight fin provided the worst performance because the metallic heat conduction path allowed the heat from the trigger cell to reach the adjacent cell quickly. The normal cell temperature rose sharply after the onset of the thermal runaway and crossed the 150 °C threshold at around 300 seconds. Once the neighboring cell reached this critical temperature, a cascading thermal runaway could occur. In contrast, when the straight fin was disconnected, the temperature rise of the normal cell was much slower. At the end of 500 seconds, the normal cell reached 92.6 °C, which is above the safe limit but below the trigger temperature. In the case of the topology-optimized fin, the normal cell temperature was only 67.2 °C, giving the smallest temperature rise among all cases. The maximum temperatures of the trigger cell were almost identical in all cases, because this value is dominated by the stored energy and the heat generation rate rather than by the fin geometry. However, the trigger cell in the optimized topology cooled more slowly than in the continuous straight fin case because less heat was transferred to the surrounding structure. These data are summarized in Table 13.
| Fin type | Runaway cell temperature (°C) | Normal cell temperature (°C) |
|---|---|---|
| Straight fin continuous | ~450 | ≥150 |
| Straight fin discontinuous | ~480 | 92.6 |
| Topology-optimized fin | ~490 | 67.2 |
For the cylindrical cell module, I compared the straight fin and topology-optimized fin, both with the same volume ratio of 0.4. The temperature distribution at the end of simulation showed clear differences. In the straight fin case, the normal cell adjacent to the trigger cell reached 88.9 °C, while in the optimized case it only reached 83.2 °C. The runaway trigger cell itself reached about 171 °C in the straight fin case and 184 °C in the optimized case. The lower trigger-cell temperature and higher normal-cell temperature in the straight fin case indicate that more heat was transferred from the trigger cell into the rest of the module. Conversely, the optimized topology kept more heat within the trigger cell or restricted its transport to the PCM, thereby delaying the temperature rise of the normal cell. Table 14 lists the final temperature values for the cylindrical cell cases.
| Fin type | Runaway cell temperature (°C) | Normal cell temperature (°C) |
|---|---|---|
| Straight fin | 171.3 | 88.9 |
| Topology-optimized fin | 184.3 | 83.2 |
These findings demonstrate that the geometric configuration of fins in phase change cooling structures plays a determining role in limiting thermal runaway propagation. The topology-optimized fin suppresses the heat flux toward the neighboring cell by breaking the continuous high-conductivity path and by distributing the metallic skeleton in a way that maximizes direct contact with the PCM. The PCM is therefore allowed to melt and absorb a larger amount of latent heat before the heat reaches the neighbor cell. Consequently, the optimized PCM-fin structure is a promising approach for enhancing the safety of traction battery packs without sacrificing normal discharge cooling performance.
10. Conclusion
In this work, I performed a comprehensive numerical investigation of topology-optimized phase change cooling structures for traction battery packs. A reliable lithium-ion cell heat generation model was constructed first and validated with experimental data. Then, the topology optimization method based on the SIMP approach was adopted to design fin distributions inside the PCM domain for both prismatic and cylindrical cells. The average temperature objective was selected after comparing with thermal compliance objective. Through the optimization, the conventional straight fins in traction battery packs were reshaped into tree-like branched structures that effectively transport heat from the cell surface to a larger volume of the phase change material.
The simulation results showed that the topology-optimized fin outperforms the straight fin in reducing the temperature of traction battery packs during 3C discharge. For prismatic cells, the optimized topology lowered the maximum cell temperature by 8.2% at a volume ratio of 0.1 and by 10.1% at a volume ratio of 0.6. For cylindrical cells, the regular hexagonal arrangement with optimized fins was more effective than the square arrangement. At a volume ratio of 0.4, the optimized structure achieved a low cell temperature of about 40 °C for the prismatic geometry and approximately 39.6 °C for the hexagonal cylindrical battery arrangement.
In the hybrid active-passive cooling stage, the simplified but manufacturable topology was coupled with air cooling. The fin protrusion height study indicated that a height of 10 mm provides a good compromise between enhanced heat transfer and material usage. Comparing the three air cooling schemes, the double-side counter-current scheme produced the lowest cell-to-cell temperature difference, about 90% smaller than that of the single-side scheme, while achieving the same average temperature as the double-side co-current scheme. Therefore, double-side counter-current air cooling is the most attractive scheme for the thermal management of traction battery packs when both temperature level and uniformity are considered.
Finally, in the thermal runaway simulation, the topology-optimized fin displayed outstanding suppression of heat propagation. The normal cell temperature for the optimized fins remained far below the thermal runaway threshold, while the constant straight fin design could not prevent the neighboring cell from approaching dangerous temperatures. The optimised structure is thus proven to be not only a passive cooling component for normal operation but also a safety barrier against thermal runaway propagation in traction battery packs.
The results of this study provide important guidance for the design of phase change cooling structures in future electric vehicles. By combining topology optimization, latent heat storage and forced air convection, it is possible to achieve high heat dissipation, good temperature uniformity and robust safety in one integrated thermal management system. Future work could extend the topology optimization to three-dimensional full-scale battery modules, include transient cycling conditions, consider the influence of natural convection within the liquid PCM, and validate the numerical results by experiments with 3D-printed fin inserts. These efforts will bring the passively enhanced active cooling concept even closer to practical application in high-energy-density traction battery packs.