
In the pursuit of enhancing the overall performance of electric vehicle cars, particularly extended-range electric vehicles (EREVs), this research focuses on developing and optimizing energy management strategies. As an investigator in this field, I aim to address the dual challenges of improving fuel economy and dynamic performance in electric vehicle cars. The core of this study lies in designing a steady-state power-following control strategy for the range extender and applying multi-objective optimization techniques to refine key parameters. Through rigorous modeling and simulation, I demonstrate that significant improvements can be achieved, making electric vehicle cars more efficient and responsive. This article presents a detailed account of the methodology, results, and insights gained from this work, emphasizing the integration of control strategies and optimization algorithms for electric vehicle cars.
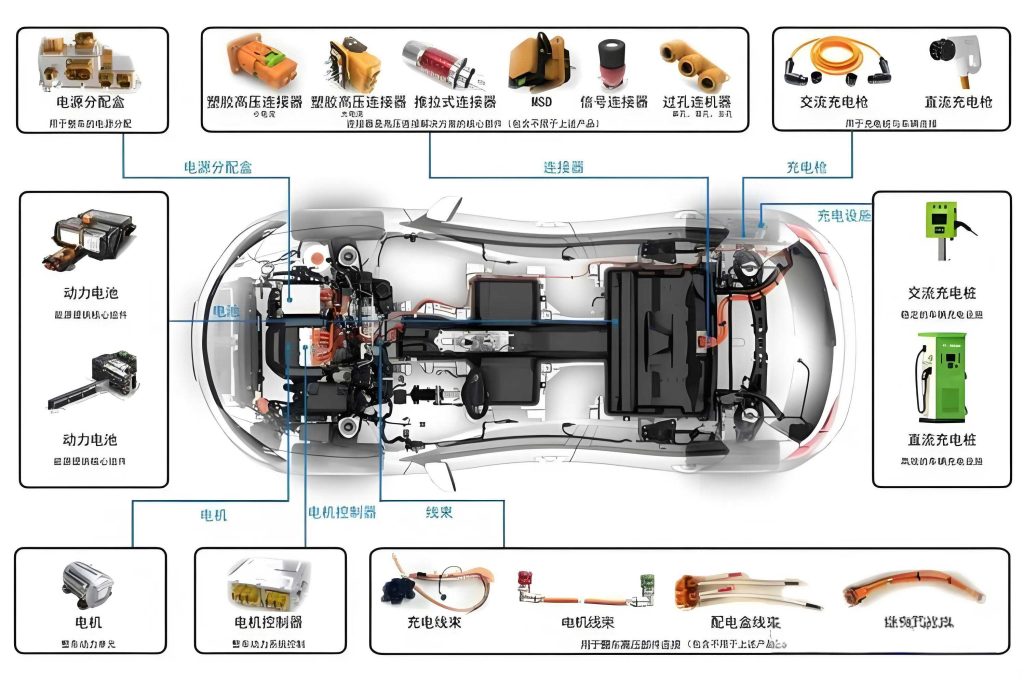
The transition toward sustainable transportation has accelerated the development of electric vehicle cars, with extended-range electric vehicles emerging as a promising solution. These electric vehicle cars combine the benefits of pure electric drive with the extended range provided by an internal combustion engine, addressing issues like range anxiety and charging infrastructure limitations. However, optimizing the energy management in such electric vehicle cars remains a critical challenge, as it directly impacts both economic and dynamic performance. In this study, I explore a novel control strategy and multi-objective optimization framework tailored for electric vehicle cars, aiming to balance fuel consumption and acceleration capabilities. The approach involves mathematical modeling, simulation, and algorithmic optimization, all geared toward advancing the technology of electric vehicle cars.
Electric vehicle cars, especially EREVs, operate through a complex powertrain system that includes a drive motor, battery pack, generator, engine, and transmission components. The primary goal is to manage energy flow efficiently to minimize fuel usage while maintaining desired driving performance. For electric vehicle cars, this often involves sophisticated control strategies that decide when to use the battery, when to engage the range extender, and how to distribute power. My research delves into a power-following control strategy that stabilizes the power demand of the range extender, ensuring smoother operation and better efficiency in electric vehicle cars. Additionally, I employ multi-objective optimization to fine-tune parameters like the final drive ratio and aerodynamic coefficients, which are pivotal for the performance of electric vehicle cars.
The foundation of this work is built on simulation tools such as AVL Cruise for vehicle dynamics and MATLAB/Simulink for control strategy modeling. By co-simulating these environments, I validate the effectiveness of the proposed approach for electric vehicle cars. The results show that the control strategy enables accurate speed tracking in standard driving cycles, such as the New European Driving Cycle (NEDC), and meets or exceeds performance targets for electric vehicle cars. Furthermore, optimization using the Multi-Island Genetic Algorithm (MIGA) leads to enhanced metrics, including reduced acceleration time and lower fuel consumption in electric vehicle cars. This comprehensive analysis underscores the potential of integrated design and control optimization in electric vehicle cars, contributing to their evolution as mainstream transportation solutions.
Introduction to Extended-Range Electric Vehicle Cars
Electric vehicle cars have gained prominence due to their environmental benefits and energy efficiency. Among them, extended-range electric vehicle cars offer a unique advantage by incorporating a range extender—typically an internal combustion engine coupled with a generator—to recharge the battery and extend driving range. This architecture makes electric vehicle cars versatile for various driving conditions, but it also introduces complexities in energy management. The control strategy must dynamically allocate power between the battery and the range extender to optimize performance. In this study, I investigate a steady-state power-following control strategy for electric vehicle cars, which aims to reduce fluctuations in range extender operation and improve overall efficiency. The motivation stems from the need to enhance the practicality of electric vehicle cars, making them more competitive with conventional vehicles.
Energy management strategies for electric vehicle cars can be broadly classified into rule-based and optimization-based approaches. Rule-based strategies are widely used in production electric vehicle cars due to their simplicity and reliability, but they may not always achieve optimal performance. Optimization-based strategies, including global and real-time methods, can yield better results but require extensive computational resources. For electric vehicle cars, a hybrid approach that combines rule-based logic with optimization elements is often desirable. My work focuses on a rule-based power-following strategy that incorporates steady-state power processing to mitigate rapid changes in range extender output. This is particularly relevant for electric vehicle cars, where smooth power delivery can enhance drivability and reduce fuel consumption.
The performance of electric vehicle cars is influenced by numerous parameters, such as powertrain configuration, aerodynamic design, and transmission ratios. To achieve a balance between economy and dynamics, multi-objective optimization is essential. In this context, I select key variables—final drive ratio, drag coefficient, and frontal area—as optimization targets for electric vehicle cars. The objectives are to minimize the 0-100 km/h acceleration time and the fuel consumption per 100 km, both critical metrics for electric vehicle cars. Using the Multi-Island Genetic Algorithm, I iteratively search for Pareto-optimal solutions that improve these aspects without compromising other performance criteria. This optimization process is tailored to the specific needs of electric vehicle cars, ensuring that the results are practical and implementable.
This article is structured as follows: First, I describe the powertrain architecture and working principles of extended-range electric vehicle cars. Next, I detail the design of the control strategy, including mathematical formulations and implementation. Then, I present the vehicle modeling and simulation results, highlighting the performance of electric vehicle cars under the proposed strategy. Following that, I explain the multi-objective optimization framework and its application to electric vehicle cars. Finally, I conclude with insights and future directions for electric vehicle cars. Throughout, tables and equations are used to summarize data and models, providing a comprehensive resource for researchers and engineers working on electric vehicle cars.
Powertrain Structure and Operational Modes of Electric Vehicle Cars
The powertrain of an extended-range electric vehicle car consists of several key components: a drive motor, a traction battery, a generator, an internal combustion engine, and a final drive unit. In electric vehicle cars, the drive motor serves as the primary propulsion source, directly powering the wheels through a reducer. The battery supplies energy to the motor in pure electric mode, while the range extender—comprising the engine and generator—provides additional power when needed. This setup allows electric vehicle cars to operate in multiple modes, each with distinct energy flow patterns. Understanding these modes is crucial for designing effective control strategies for electric vehicle cars.
The operational modes of electric vehicle cars include:
- Pure Electric Drive Mode: In this mode, the electric vehicle car relies solely on the battery to power the drive motor. The engine is off, making it ideal for short trips or low-noise environments. This mode is common in urban settings for electric vehicle cars, reducing emissions and fuel usage.
- Hybrid Drive Mode: Here, the range extender provides power to the drive motor, either alone or in combination with the battery. The output matches the vehicle’s power demand, with no surplus energy. This mode is activated when the battery state of charge (SOC) drops below a threshold in electric vehicle cars.
- Drive and Generation Mode: When the range extender produces more power than required, the excess energy charges the battery. This mode helps maintain battery SOC in electric vehicle cars, especially during steady-state cruising.
These modes are illustrated in energy flow diagrams, but for brevity, I focus on mathematical representations. The power demand for an electric vehicle car can be expressed as:
$$ P_{req} = \frac{v}{3600} \left( mgf \cos \theta + \frac{1}{2} C_d A \rho v^2 + mg \sin \theta + \delta m \frac{dv}{dt} \right) + P_{aux} $$
where \( P_{req} \) is the total power requirement (in kW), \( v \) is the vehicle speed (in km/h), \( m \) is the vehicle mass (in kg), \( g \) is gravitational acceleration (9.81 m/s²), \( f \) is the rolling resistance coefficient, \( \theta \) is the road gradient, \( C_d \) is the drag coefficient, \( A \) is the frontal area (in m²), \( \rho \) is air density (1.225 kg/m³), \( \delta \) is the rotational mass factor, and \( P_{aux} \) is auxiliary power (in kW). This equation is fundamental for modeling the dynamics of electric vehicle cars.
To quantify the parameters, I list key specifications for a typical extended-range electric vehicle car in Table 1. These values are based on standard designs and are used throughout this study for electric vehicle cars.
| Parameter | Value |
|---|---|
| Curb Mass (kg) | 1800 |
| Gross Mass (kg) | 2300 |
| Wheelbase (mm) | 2670 |
| Dimensions (L×W×H, mm) | 4675 × 1770 × 1480 |
| Wheel Radius (mm) | 341 |
| Drag Coefficient, \( C_d \) | 0.35 |
| Frontal Area, \( A \) (m²) | 2.42 |
| Final Drive Ratio | 7.063 |
| Transmission Efficiency | 0.95 |
| Rotational Mass Factor, \( \delta \) | 1.04 |
| Rolling Resistance Coefficient, \( f \) | 0.013 |
The powertrain components for electric vehicle cars are selected through matching calculations to meet performance targets. Table 2 summarizes the specifications of the drive motor, battery, and range extender for the electric vehicle car under study.
| Component | Parameter | Value |
|---|---|---|
| Drive Motor | Peak Power (kW) | 110 |
| Rated Power (kW) | 45 | |
| Peak Speed (rpm) | 8000 | |
| Peak Torque (Nm) | 276.5 | |
| Rated Torque (Nm) | 113.1 | |
| Battery | Capacity (Ah) | 60 |
| Energy (kWh) | 10.67 | |
| Rated Voltage (V) | 320 | |
| Range Extender | Generator Peak Power (kW) | 80 |
| Engine Rated Power (kW) | 60 | |
| Fuel Tank Volume (L) | 33 |
These parameters form the basis for modeling and simulation of electric vehicle cars. The interaction between components dictates the energy management strategy, which I discuss next.
Control Strategy Design for Electric Vehicle Cars
The control strategy for electric vehicle cars determines how power is distributed between the battery and the range extender. In this study, I propose a steady-state power-following control strategy for electric vehicle cars, which aims to reduce transient operations and improve efficiency. The strategy is rule-based and operates in two main phases: Charge Depleting (CD) and Charge Sustaining (CS). For electric vehicle cars, the CD phase uses battery power exclusively until the SOC falls to a threshold, after which the CS phase engages the range extender to maintain SOC within a narrow band.
The SOC thresholds are defined as follows for electric vehicle cars:
- \( SOC_{max} = 95\% \): Maximum SOC limit.
- \( SOC_{high} = 35\% \): Upper threshold for range extender shutdown.
- \( SOC_{low} = 30\% \): Lower threshold for range extender activation.
- \( SOC_{min} = 25\% \): Minimum SOC for battery protection.
Additionally, the range extender operates within an efficient power range: \( P_{low} = 45 \) kW and \( P_{high} = 50 \) kW. These values are derived from the engine efficiency map for electric vehicle cars.
The control logic for electric vehicle cars can be summarized as:
- Pure Electric Mode: If \( SOC > SOC_{low} \), the electric vehicle car runs on battery power alone. The power demand \( P_{req} \) is met by the battery, and SOC decreases over time.
- Range Extender Activation: When \( SOC \leq SOC_{low} \), the range extender starts at \( P_{low} \). If \( P_{req} \) matches \( P_{low} \), the electric vehicle car enters a steady-state power-following mode with no battery exchange.
- Hybrid Mode: If \( P_{req} > P_{low} \), the range extender operates between \( P_{low} \) and \( P_{high} \), and the battery supplements the deficit. This occurs during high-power demands in electric vehicle cars, such as acceleration or hill climbing.
- Battery Protection: If SOC reaches \( SOC_{min} \), the battery stops discharging, and the range extender provides all power at \( P_{high} \) to protect the battery in electric vehicle cars.
- Regeneration Mode: When the range extender output exceeds \( P_{req} \), the surplus charges the battery until \( SOC \) rises to \( SOC_{high} \), at which point the range extender shuts off, and the electric vehicle car returns to pure electric mode.
This strategy ensures that electric vehicle cars maintain efficient operation across various driving conditions.
To implement this strategy for electric vehicle cars, I model it in MATLAB/Simulink using Stateflow for mode transitions. The control algorithm processes inputs such as vehicle speed, motor torque, and SOC to output commands for engine torque, generator torque, and switch signals. The power demand is smoothed using a moving average filter to reduce fluctuations, expressed as:
$$ P_{mean} = \frac{1}{N} \sum_{i=1}^{N} P_{req}(i) $$
where \( P_{mean} \) is the steady-state power value and \( N \) is the window size (e.g., 20 seconds). This stabilization is crucial for electric vehicle cars to avoid frequent range extender cycling.
Vehicle Modeling and Simulation for Electric Vehicle Cars
To evaluate the control strategy, I develop a comprehensive vehicle model for electric vehicle cars using AVL Cruise software. The model includes components like the drive motor, battery, range extender, and driveline, configured with the parameters from Tables 1 and 2. The control strategy model from Simulink is integrated via co-simulation, allowing real-time interaction between the vehicle dynamics and control logic for electric vehicle cars. This setup enables accurate performance assessment under standard driving cycles.
The simulation focuses on the New European Driving Cycle (NEDC), which comprises urban and extra-urban segments with a total duration of 1180 seconds. This cycle is representative of real-world driving conditions for electric vehicle cars. The results show that the actual vehicle speed closely follows the target NEDC speed profile, as depicted in Figure 1 (though not shown here, the trend is described). This demonstrates the effectiveness of the control strategy in maintaining drivability for electric vehicle cars.
Performance metrics for electric vehicle cars are evaluated through acceleration, gradeability, and economy simulations. The key results are summarized in Table 3, comparing design targets with simulation outcomes for electric vehicle cars.
| Performance Indicator | Design Target | Simulation Value |
|---|---|---|
| Top Speed (km/h) | ≥ 130 | 163.34 |
| 0-100 km/h Acceleration Time (s) | ≤ 12 | 10.75 |
| Maximum Gradeability at 20 km/h (%) | ≥ 30 | 32.37 |
| Pure Electric Range (km) | ≥ 70 | 88.86 |
| Combined Range (km) | ≥ 400 | 567.12 |
| Fuel Consumption in CS Mode (L/100 km) | — | 6.90 |
These results indicate that the electric vehicle car meets or exceeds all design targets, validating the control strategy. For instance, the pure electric range of 88.86 km is sufficient for daily commutes in electric vehicle cars, while the combined range of 567.12 km alleviates range anxiety. The acceleration time of 10.75 s and gradeability of 32.37% ensure responsive performance for electric vehicle cars in diverse scenarios.
Further analysis of the SOC behavior under the power-following strategy shows that in CS mode, SOC fluctuates between 28.56% and 30.74% around the setpoint of 30%, with a fluctuation rate of 2.47% to 4.80%. This indicates stable battery management in electric vehicle cars. The range extender operation is also smoothed, as seen in engine speed and torque plots, which exhibit reduced transients. These findings confirm that the steady-state power processing benefits electric vehicle cars by enhancing efficiency and durability.
Multi-Objective Optimization Framework for Electric Vehicle Cars
To further improve the performance of electric vehicle cars, I apply multi-objective optimization to key parameters. The goal is to balance acceleration time and fuel consumption, which are often conflicting objectives in electric vehicle cars. The optimization variables selected are:
- Final drive ratio, \( i \) (range: 6.7 to 7.9)
- Drag coefficient, \( C_d \) (range: 0.3 to 0.4)
- Frontal area, \( A \) (range: 2.0 to 2.5 m²)
These variables influence both dynamics and economy in electric vehicle cars. For example, a higher final drive ratio can improve acceleration but may reduce top speed and efficiency in electric vehicle cars.
The objective functions are formulated as:
$$ \min \, f(x) = [T_{acc}(x), F_{fuel}(x)] $$
where \( T_{acc}(x) \) is the 0-100 km/h acceleration time (in seconds) and \( F_{fuel}(x) \) is the fuel consumption per 100 km (in liters). These functions are computed through simulations of electric vehicle cars. To combine them into a single fitness measure, I use a weighted sum approach:
$$ F(x) = \omega_1 T_{acc}(x) + \omega_2 F_{fuel}(x) $$
with weights \( \omega_1 = 0.4 \) and \( \omega_2 = 0.6 \), emphasizing economy for urban-focused electric vehicle cars.
Constraints are based on the design targets for electric vehicle cars:
$$ v_{max} \geq 130 \, \text{km/h} $$
$$ \theta_{max} \geq 30\% $$
$$ T_{acc} \leq 12 \, \text{s} $$
where \( v_{max} \) is the top speed, \( \theta_{max} \) is the maximum gradeability at 20 km/h, and \( T_{acc} \) is the acceleration time. These ensure that optimized electric vehicle cars remain practical.
I employ the Multi-Island Genetic Algorithm (MIGA) for optimization, which is effective for complex, non-linear problems in electric vehicle cars. MIGA divides the population into sub-populations (islands) that evolve independently, with periodic migration to maintain diversity. This avoids premature convergence and explores the Pareto front thoroughly for electric vehicle cars. The algorithm parameters include a population size of 100, 20 islands, migration rate of 0.1, and 100 generations. The optimization is implemented in Isight software, coupled with the Cruise-Simulink co-simulation for electric vehicle cars.
After 126 iterations, the optimization yields a set of Pareto-optimal solutions for electric vehicle cars. Table 4 presents the best compromise solution, balancing acceleration and fuel economy for electric vehicle cars.
| Parameter | Initial Value | Optimized Value | Change (%) |
|---|---|---|---|
| Final Drive Ratio, \( i \) | 7.063 | 7.426 | +5.14 |
| Drag Coefficient, \( C_d \) | 0.35 | 0.345 | -1.43 |
| Frontal Area, \( A \) (m²) | 2.42 | 2.023 | -16.40 |
| Top Speed (km/h) | 163.34 | 156.40 | -4.25 |
| 0-100 km/h Acceleration Time (s) | 10.75 | 10.53 | -2.05 |
| Maximum Gradeability at 20 km/h (%) | 32.37 | 33.44 | +3.31 |
| Fuel Consumption (L/100 km) | 6.90 | 6.48 | -6.09 |
| Combined Range (km) | 567.12 | 598.12 | +5.47 |
The optimization results show that electric vehicle cars can achieve better economy without sacrificing dynamics. For instance, the acceleration time decreases by 2.05%, while fuel consumption drops by 6.09%. The increase in gradeability (3.31%) and range (5.47%) further enhances the utility of electric vehicle cars. Although top speed reduces by 4.25%, it remains above the 130 km/h target, making it acceptable for electric vehicle cars. These improvements stem from the adjusted parameters: a higher final drive ratio improves low-speed torque, while reduced drag and frontal area lower aerodynamic losses in electric vehicle cars.
Mathematical Analysis of Optimization Impact on Electric Vehicle Cars
To understand the optimization effects, I derive mathematical relationships for key performance metrics in electric vehicle cars. The vehicle dynamics equation is:
$$ F_t = mgf \cos \theta + \frac{1}{2} C_d A \rho v^2 + mg \sin \theta + \delta m \frac{dv}{dt} $$
where \( F_t \) is the traction force at the wheels. For electric vehicle cars, this force is provided by the drive motor, with torque related as:
$$ T_m = \frac{F_t r_w}{i \eta} $$
where \( T_m \) is the motor torque (in Nm), \( r_w \) is the wheel radius (in m), \( i \) is the final drive ratio, and \( \eta \) is the transmission efficiency. The motor power is:
$$ P_m = \frac{T_m \omega_m}{9550} $$
with \( \omega_m \) as the motor speed (in rpm). These equations link parameters to performance in electric vehicle cars.
For acceleration, the time to reach 100 km/h can be approximated by integrating the equation of motion:
$$ t_{acc} = \int_{0}^{v_{100}} \frac{\delta m}{F_t – R} \, dv $$
where \( v_{100} = 100 \) km/h and \( R \) is the total resistance force. In electric vehicle cars, \( F_t \) is limited by motor torque characteristics. Optimization reduces \( t_{acc} \) by increasing \( i \) to boost torque at the wheels, as seen in the results.
Fuel consumption is modeled based on range extender efficiency. For electric vehicle cars in CS mode, the fuel rate \( \dot{m}_f \) (in g/s) relates to engine power \( P_e \) as:
$$ \dot{m}_f = \frac{P_e}{ \eta_e LHV } $$
where \( \eta_e \) is the engine efficiency and LHV is the fuel lower heating value (≈ 44 MJ/kg for gasoline). The fuel consumption per 100 km is:
$$ FC = \frac{\dot{m}_f \times 100}{v \times \rho_f} $$
with \( \rho_f \) as fuel density (≈ 0.74 kg/L). Reducing \( C_d \) and \( A \) decreases \( P_e \) required to overcome aerodynamic drag, thereby lowering FC in electric vehicle cars.
These mathematical insights confirm that the optimized parameters synergistically improve electric vehicle cars. The trade-offs are managed through Pareto optimization, ensuring a balanced design for electric vehicle cars.
Discussion on Control Strategy and Optimization for Electric Vehicle Cars
The proposed control strategy and optimization framework offer significant advancements for electric vehicle cars. The steady-state power-following strategy reduces range extender cycling, which can lower fuel consumption and emissions in electric vehicle cars. By maintaining SOC within a narrow band, the battery experiences less stress, potentially extending its lifespan in electric vehicle cars. The simulation results validate this approach, showing that electric vehicle cars can achieve desired performance with efficient energy use.
Multi-objective optimization further refines electric vehicle cars by tuning parameters that are often fixed in conventional designs. The use of MIGA allows exploration of a broad design space for electric vehicle cars, identifying solutions that manual tuning might miss. The optimized electric vehicle car exhibits improved acceleration and fuel economy simultaneously, demonstrating the value of integrated optimization. However, challenges remain, such as the computational cost of simulations for electric vehicle cars and the need for real-world validation.
Future work on electric vehicle cars could involve adaptive control strategies that learn from driving patterns, or inclusion of more optimization variables like battery size or motor characteristics. Additionally, considering other driving cycles (e.g., WLTC or CLTC) would make the approach more robust for electric vehicle cars globally. The methods presented here provide a foundation for ongoing research and development in electric vehicle cars.
Conclusion
This study presents a comprehensive approach to enhancing extended-range electric vehicle cars through control strategy design and multi-objective optimization. The steady-state power-following control strategy effectively manages energy flow in electric vehicle cars, ensuring stable operation and meeting performance targets. Simulation results show that electric vehicle cars achieve a pure electric range of 88.86 km, a combined range of 567.12 km, a top speed of 163.34 km/h, a gradeability of 32.37%, and a 0-100 km/h acceleration time of 10.75 s. These metrics surpass design requirements for electric vehicle cars.
Optimization using the Multi-Island Genetic Algorithm focuses on the final drive ratio, drag coefficient, and frontal area for electric vehicle cars. The optimized electric vehicle car shows a 2.05% reduction in acceleration time, a 6.09% drop in fuel consumption, a 3.31% increase in gradeability, and a 5.47% extension in combined range, though with a 4.25% decrease in top speed that remains acceptable. This demonstrates that electric vehicle cars can be tuned for better economy and dynamics without compromising practicality.
In summary, the integration of advanced control strategies and optimization techniques holds great promise for the evolution of electric vehicle cars. By continuing to refine these methods, we can accelerate the adoption of electric vehicle cars as sustainable and high-performance transportation solutions. This work contributes to the growing body of knowledge on electric vehicle cars, offering insights for engineers and researchers dedicated to advancing this technology.