
1. Introduction
The rapid transition toward sustainable transportation has placed the EV battery at the center of modern energy storage systems. The performance, safety, and reliability of an EV battery directly determine the driving experience and lifespan of electric vehicles. Among the numerous internal states that need to be monitored by the battery management system (BMS), the State of Charge (SOC) and State of Health (SOH) are the two critical quantities that reflect the short-term available energy and the long-term degradation status of the EV battery. Accurate SOC estimation ensures that the EV battery is neither over-charged nor over-discharged, while accurate SOH estimation provides essential information for maintenance scheduling and end-of-life prediction. Over the past decade, considerable efforts have been made to improve the precision and robustness of these estimators. However, the inherent nonlinearities, time-varying characteristics, and coupled aging mechanisms of the EV battery still pose significant challenges to existing methods.
In this thesis, I focus on the estimation of SOC and SOH for an EV battery, specifically a lithium titanate (LTO) power battery, through both model-based and data-driven approaches. I begin by analyzing the working principles of lithium-based EV batteries, including their internal composition and the major factors that influence their performance. Then, I establish a second-order equivalent circuit model and apply a particle swarm optimization (PSO) enhanced extended Kalman filter (EKF) to achieve accurate SOC tracking under dynamic test conditions. For SOH, I extract multiple health indicators from charging/discharging curves and incremental capacity (IC) curves, and design a Transformer-LSTM hybrid neural network optimized by the polar lights optimization (PLO) algorithm. Finally, I build a joint SOC-SOH estimation framework that couples the capacity fade and the open-circuit voltage (OCV) shift. The proposed methods are extensively validated on public datasets from NASA and CALCE, as well as on the LTO EV battery data I collected in the laboratory. Experimental results demonstrate that the proposed estimators achieve high accuracy and good generalization, making them suitable for practical BMS deployment in EV battery applications.
2. Fundamentals and Data Analysis for EV Battery
2.1 Working Principles of the Lithium Battery
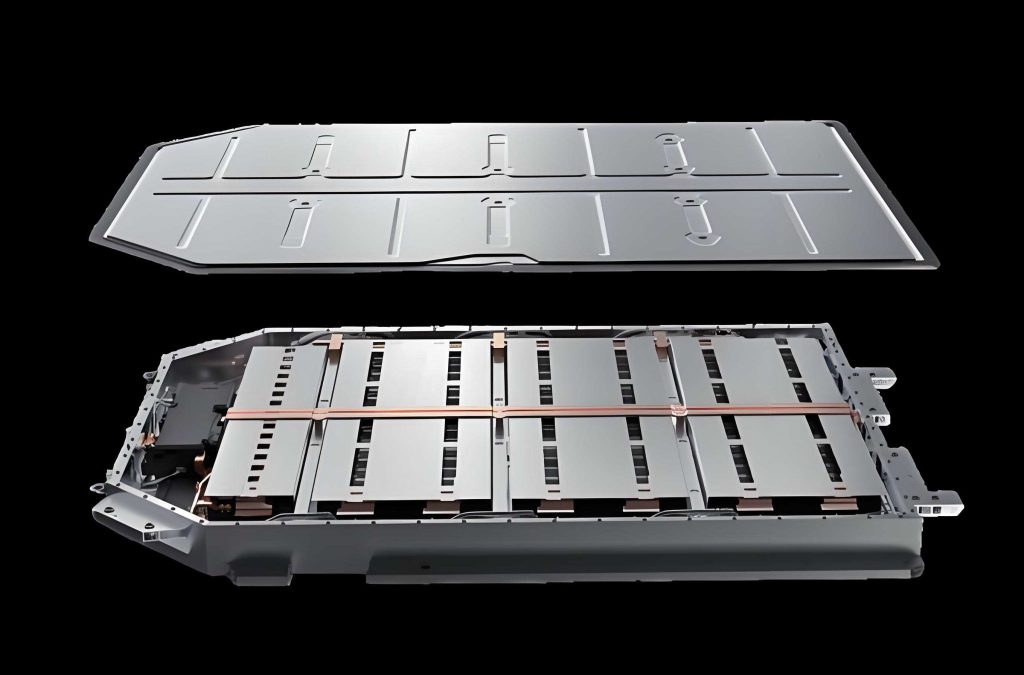
A typical lithium-ion EV battery consists of a positive electrode, a negative electrode, an electrolyte, a separator, and a casing. During charging, lithium ions are extracted from the positive electrode, migrate through the electrolyte and separator, and intercalate into the negative electrode. During discharge, the reverse process occurs and the ions flow back to the positive electrode while electrons traverse an external circuit to power the EV. The lithium titanate battery utilizes a spinel-structured Li₄Ti₅O₁₂ negative electrode, which is known as a zero-strain material. This characteristic provides excellent safety, good high-rate performance, and a long cycle life, making it increasingly attractive for high-power EV applications.
The performance of an EV battery is influenced by several factors. The charge/discharge current directly affects the lithium-ion diffusion rate, and excessive current can cause heat generation and capacity loss. The voltage window controls the electrochemical stability; operating beyond the specification can lead to electrolyte decomposition and structural damage. Temperature strongly influences the kinetics and mass transport inside the EV battery; both extremely low and high temperatures accelerate performance degradation. Consequently, accurate state estimation must account for current, voltage, and temperature measurements, and all of these variables are recorded in the experimental datasets that I use in this work.
2.2 Dataset Description and Preprocessing
To evaluate the proposed algorithms, I employ three categories of EV battery test data:
- NASA dataset: 18650 cells (B0005, B0006, B0007, B0018) cycled at room temperature with standard charge/discharge until the rated capacity dropped from 2 Ah to about 1.4 Ah.
- CALCE dataset: This includes dynamic stress test (DST) cycles, federal urban driving schedule (FUDS) cycles, and aging cycles for CS2 cells. For SOC verification, I use DST data with pulse/constant-current loads. For SOH evaluation, I exploit the long-term cycling data from CS2-35 to CS2-38 cells.
- LTO power battery data: I performed constant current-constant voltage (CC-CV) charge/discharge cycles on a 33 Ah lithium titanate cell designed for onboard backup power. The cycle life test continued until the capacity faded to 80% of its nominal value.
Since the raw measurements often contain missing values due to sensor interruptions, and outliers caused by electrical noise, I perform a careful preprocessing stage. Missing values are filled using mean or median imputation. Outliers are removed using a local outlier factor (LOF) algorithm, which compares the local density of each sample with that of its neighbors. This method is suitable for non-uniform distributions that are typical for EV battery operating data.
2.3 Data Cleaning for the EV Battery Measurements
Let a measured time series be denoted as \(x_1,x_2,\dots,x_n\). The mean imputation replaces a missing value by \(\bar{x} = (1/n)\sum_{i=1}^{n}x_i\). The LOF score is calculated through the following steps. First, the reachable distance is defined as
$$
RD_k(p,o) = \max\{d(p,o), d_k(o)\},
$$
where \(d(p,o)\) is the Euclidean distance and \(d_k(o)\) is the \(k\)-th nearest neighbor distance of \(o\). The local reachability density is then given by
$$
LRD_k(p) = \frac{N_k(p)}{\sum_{o \in N_k(p)} RD_k(p,o)},
$$
where \(N_k(p)\) is the set of \(k\)-nearest neighbors of \(p\). Finally, the local outlier factor is
$$
LOF_k(p) = \frac{\sum_{o \in N_k(p)} LRD_k(o)}{|N_k(p)| \, LRD_k(p)}.
$$
Samples with an LOF close to 1 are normal, whereas samples with high LOF values are marked as anomalies and replaced by a moving average of their neighbors. After preprocessing, the EV battery datasets are stable and consistent for subsequent model identification, feature extraction, and neural-network training.
3. SOC Estimation Using the PSO-EKF Algorithm for EV Battery
3.1 SOC Definition and Equivalent Circuit Model
SOC is defined as the percentage of remaining capacity in an EV battery relative to its nominal capacity. The theoretical expression is
$$
SOC = \frac{Q_r}{Q_I} \times 100\%,
$$
where \(Q_r\) is the residual charge and \(Q_I\) is the rated capacity. In practice, the reference SOC is often computed by ampere-hour integration:
$$
SOC(t) = SOC(0) – \frac{1}{Q_n}\int_0^t \eta I(\tau)\,d\tau,
$$
where \(Q_n\) is the current maximum available capacity, \(\eta\) is the Coulombic efficiency, and \(I(\tau)\) is the current (positive during discharge). Because the maximum available capacity decreases with aging, the capacity value should be corrected when the EV battery ages.
I use a second-order RC equivalent circuit model to describe the dynamic voltage behavior of the EV battery. The equivalent circuit is governed by the following differential equations:
$$
\begin{cases}
\dot U_1 = -\frac{U_1}{R_1 C_1} + \frac{I_L}{C_1},\\[2mm]
\dot U_2 = -\frac{U_2}{R_2 C_2} + \frac{I_L}{C_2},\\[2mm]
U_t = U_{OC}(SOC) – I_L R_0 – U_1 – U_2,
\end{cases}
$$
where \(U_{OC}\) is the open-circuit voltage, \(R_0\) is the ohmic resistance, \(R_1\) and \(C_1\) represent the electrochemical polarization, and \(R_2\) and \(C_2\) represent the concentration polarization. This model captures both the fast and slow voltage responses of the EV battery, which is essential for an accurate SOC observer.
3.2 Parameter Identification Based on the Recursive Least Squares Method
To identify the model parameters, I apply the recursive least squares method in the frequency domain. By taking the Laplace transform of the RC network, the transfer function between terminal voltage and current is
$$
G(s) = \frac{U_{OC}(s) – U_t(s)}{I_L(s)} = R_0 + \frac{R_1}{1 + s\tau_1} + \frac{R_2}{1 + s\tau_2},
$$
where \(\tau_1 = R_1 C_1\) and \(\tau_2 = R_2 C_2\). Billinear discretization with sampling interval \(T\) yields
$$
G(z^{-1}) = \frac{k_1 – k_2 z^{-1} – k_3 z^{-2}}{1 + k_4 z^{-1} – k_5 z^{-2}}.
$$
The unknown coefficients \(k_1\) through \(k_5\) are estimated online using the recursive least squares update:
$$
\begin{cases}
\theta(t+1) = \theta(t) + K(t+1)\varepsilon(t+1),\\[2mm]
K(t+1) = \frac{P(t)\phi(t+1)}{1 + \phi^T(t+1) P(t) \phi(t+1)},\\[2mm]
P(t+1) = P(t) – K(t+1)\phi^T(t+1) P(t),
\end{cases}
$$
where \(\varepsilon\) is the one-step prediction error and \(\phi(t)\) is the regressor vector composed of past outputs and inputs. The circuit parameters are then recovered from the identified coefficients. I validated the estimated parameters using a pulse discharge test in Simulink. The model voltage response tracks the measured voltage well and the error tends to zero after the transient, confirming the accuracy of the second-order equivalent model.
3.3 EKF for SOC Estimation and PSO Optimization
The EKF algorithm linearizes the nonlinear EV battery model by taking first-order Taylor expansions. The discrete state-space representation is chosen as
$$
x_k = \left[ SOC_k,\; U_{1,k},\; U_{2,k} \right]^T,
$$
with the state equation
$$
x_{k+1} = A_k x_k + B_k I_k + w_k,
$$
where \(w_k\) is the process noise with covariance \(Q_k\). The output equation is
$$
U_{t,k} = U_{OC}(SOC_k) – I_k R_0 – U_{1,k} – U_{2,k} + v_k,
$$
where \(v_k\) is the measurement noise with covariance \(R_k\). The state transition matrix \(A_k\) that includes the SOC dynamics and RC relaxation is
$$
A_k =
\begin{bmatrix}
1 & 0 & 0\\
0 & e^{-\Delta t/\tau_1} & 0\\
0 & 0 & e^{-\Delta t/\tau_2}
\end{bmatrix}.
$$
The EKF recursion follows the standard prediction-correction steps: time update, Kalman gain computation, measurement update, and covariance update. However, the noise covariance matrices \(Q_k\) and \(R_k\), which are often initialized based on experience, strongly affect the tracking performance. To make the estimator more adaptive, I exploit particle swarm optimization (PSO) to search for optimized covariance values. Each particle in PSO represents a candidate \((Q,R)\) pair and its velocity/position updates are given by
$$
\begin{cases}
v_{id}^{(t+1)} = w v_{id}^{(t)} + c_1 r_1 (p_{id} – x_{id}^{(t)}) + c_2 r_2 (p_{gd} – x_{id}^{(t)}),\\[2mm]
x_{id}^{(t+1)} = x_{id}^{(t)} + v_{id}^{(t+1)}.
\end{cases}
$$
The fitness function is chosen as the cumulative absolute voltage-prediction error over a sliding window:
$$
f_{itness} = \sum_{k=1}^{N} \left| \hat y_{k|k-1} – y_k \right|,
$$
where \(\hat y_{k|k-1}\) is the predicted terminal voltage and \(y_k\) is the measured voltage. The PSO algorithm minimizes the fitness value and returns the optimized \(Q\) and \(R\) matrices to the EKF. Therefore, the PSO-EKF estimator is able to adjust its noise model and produce a more reliable SOC estimate.
3.4 SOC Estimation Results and Analysis
To validate the proposed strategy, I use DST data from the CALCE EV battery dataset. The cell has a nominal capacity of \(Q_n = 1.456\,\text{Ah}\) and the discharge current is set to \(1.35\,\text{A}\), which corresponds to about 1C. The test begins at 0.8 SOC reference, while the filter is initialized with a 10% error (0.7) to examine convergence. The terminal-voltage tracking performance and the SOC estimation error are reported in the following table.
| Method | Voltage MAE | Voltage RMSE | SOC MAE | SOC RMSE |
|---|---|---|---|---|
| EKF | 0.0585 | 0.0241 | 0.0024 | 0.0064 |
| PSO-EKF | 0.0536 | 0.0227 | 0.0017 | 0.0060 |
The PSO-EKF method achieves lower voltage and SOC errors. More importantly, it converges faster at the beginning of the discharge because the optimized noise covariance prevents the filter from being too aggressive or too slow. In terms of terminal voltage estimation, the average relative error is less than 6% over the entire DST horizon. These results confirm that the second-order RC model combined with the PSO-EKF algorithm gives the EV battery a good foundation for model-based SOC estimation. Nevertheless, the SOC is a state observed over minutes or hours; the SOH evolves over weeks or months, and a separate data-driven method is necessary for the slower degradation dynamics.
4. SOH Estimation with a PLO-Optimized Transformer-LSTM Network
4.1 SOH Definition and Health Indicators
SOH indicates the current maximum capacity relative to the rated capacity of a fresh EV battery:
$$
SOH = \frac{Q_{max}}{Q_{rated}} \times 100\%,
$$
where \(Q_{max}\) is the maximum dischargeable capacity at the present cycle. To estimate SOH from currents and voltages, I extract various health indicators (HIs) from each charge/discharge cycle. These include the constant-current charging time, constant-voltage charging time, the voltage rise time between two SOC levels, the peak value of the incremental capacity curve, the voltage corresponding to the peak of the incremental capacity curve, the ratio of CC time to total charge time, and the maximum temperature during discharge.
The incremental capacity is defined as
$$
\frac{dQ}{dV} = \frac{I \Delta t}{\Delta V}.
$$
As the EV battery degrades, the IC curve peak decreases and the peak voltage moves to smaller values. The following table shows the Pearson correlation coefficients between the selected HIs and the SOH for the three different datasets used in this study.
| Dataset | HF1 | HF2 | HF3 | HF4 | HF5 |
|---|---|---|---|---|---|
| NASA | 0.9067 | 0.9151 | 0.9135 | -0.9353 | -0.8266 |
| CALCE | 0.9945 | 0.9695 | 0.9067 | -0.9133 | -0.8750 |
| LTO | 0.9254 | 0.9608 | 0.9038 | -0.9289 | -0.9732 |
Most of the selected features show absolute Pearson coefficients above 0.9, which proves their strong relevance to the degradation state of the EV battery. Redundant information among the features is removed by kernel principal component analysis (KPCA). The first three kernel principal components are kept to obtain a compact but informative feature set for the neural network.
4.2 Transformer-LSTM Model for EV Battery SOH Estimation
Long short-term memory (LSTM) networks have been widely used for SOH prediction because of their ability to learn temporal dependencies. However, the sequential structure of an LSTM still suffers from the long-term memorization problem. Transformer networks, which rely on a self-attention mechanism, can model global interactions in parallel. To combine the best of both worlds, I propose a Transformer-LSTM hybrid network. Specifically, the positional encodings and the multi-head self-attention layer from the Transformer encoder are retained, while the decoder part is replaced by an LSTM layer and a fully connected layer. The attention output is computed as
$$
\text{Attention}(Q,K,V) = \text{softmax}\left(\frac{QK^T}{\sqrt{d_k}}\right) V,
$$
where \(Q, K, V\) are the query, key, and value matrices, and \(d_k\) is the dimension of the keys. Multi-head attention concatenates several attention outputs:
$$
\text{MultiHead}(Q,K,V) = \text{Concat}(head_1,\dots,head_h) W_O.
$$
In my design, the attention part is followed by a residual connection, layer normalization, and then the LSTM layer to capture the dynamic recurrence in the EV battery aging sequence. The fully connected output layer maps the encoded features to the SOH value.
4.3 Polar Lights Optimization (PLO) for Hyperparameter Tuning
The performance of the Transformer-LSTM depends on several hyperparameters, including the number of attention heads, the learning rate, and the L2 regularization coefficient. Because manual tuning is tedious, I employ the polar lights optimization (PLO) algorithm. The PLO algorithm is inspired by the motion of solar particles in the Earth’s magnetic field. It combines rotation motion, elliptic orbit motion using Lévy flight, and particle collision. The position-update model is
$$
X_{new}(i,j) = X(i,j) + r_1 W_1 v(t) + r_2 W_2 Ao,
$$
where \(W_1\) and \(W_2\) are time-dependent weights, and \(Ao\) is the Levy-based elliptic term:
$$
Ao = Levy(d)\times\left(X_{avg}(j) – X(i,j)\right) + r\left(UB – LB\right).
$$
The weights are set as
$$
W_1 = 1 – \frac{e^{2(t/T)} – 1}{e^{2} – 1}, \quad W_2 = e^{-3(t/T)}.
$$
Particle collision allows the optimization to escape from local minima:
$$
X_{new}(i,j) = X(i,j) + r_3 \sin(\pi r_3) \left(X(i,j) – X(a,j)\right).
$$
I use the mean absolute percentage error as the fitness function for the PLO optimizer. The optimal parameters are obtained after convergence and then fed into the Transformer-LSTM for SOH training.
4.4 SOH Estimation Experiments
I investigated two experimental settings. The first setting considers the whole life-cycle SOH estimation. For the NASA dataset, I train the model with B0006, B0007, and B0018 cells and test with B0005. For the CALCE dataset, CS2-38, CS2-37, and CS2-36 are used for training, and CS2-35 is used for testing. The same data-splitting logic is applied to the LTO battery data. In the second setting, only the first 50% of cycles of the test battery are used as an initial training window, and the remaining cycles are predicted iteratively so as to evaluate the long-sequence extrapolation capability of the model. The benchmarking methods include the original Transformer-LSTM without PLO tuning, and a standard BP neural network.
| Dataset | Method | MAE | RMSE | R² |
|---|---|---|---|---|
| NASA | PLO-Transformer-LSTM (ours) | 0.0086 | 0.0106 | 0.9889 |
| Transformer-LSTM | 0.0128 | 0.0166 | 0.9732 | |
| CALCE | PLO-Transformer-LSTM (ours) | 0.0076 | 0.0089 | 0.9898 |
| Transformer-LSTM | 0.0235 | 0.0284 | 0.8975 | |
| LTO | PLO-Transformer-LSTM (ours) | 0.0063 | 0.0072 | 0.9910 |
| Transformer-LSTM | 0.0110 | 0.0157 | 0.9764 |
The proposed method consistently produces the lowest mean absolute error and root mean square error, while the coefficient of determination \(R^2\) is always above 0.98. It indicates that the PLO-tuned Transformer-LSTM can well capture the global degradation trend and also the short-term capacity regains that occur during the rest periods of an EV battery cycling protocol. In the 50%-starting-point experiment, the model is asked to infer the SOH for the unseen second half of life. The decision coefficients are still above 0.95 for all three data sets, as summarized below.
| Dataset | Method | MAE | RMSE | R² |
|---|---|---|---|---|
| NASA | PLO-Transformer-LSTM | 0.0058 | 0.0093 | 0.9520 |
| BP | 0.0184 | 0.0229 | 0.7068 | |
| CALCE | PLO-Transformer-LSTM | 0.0064 | 0.0093 | 0.9798 |
| BP | 0.0312 | 0.0447 | 0.7137 | |
| LTO | PLO-Transformer-LSTM | 0.0029 | 0.0048 | 0.9851 |
| BP | 0.0143 | 0.0220 | 0.7038 |
The experimental results prove that the attention-based global modeling of the EV battery aging procedure, combined with the LSTM temporal reasoning and the PLO hyperparameter optimization, significantly improves the accuracy and robustness of SOH estimation.
5. Joint SOC-SOH Estimation for EV Battery
5.1 Coupling mechanism between SOC and SOH
SOC and SOH have different time scales: SOC changes within a single charge or discharge cycle, while SOH slowly evolves over the lifetime of an EV battery. However, they are tightly coupled through the maximum available capacity \(Q_{max}\). The ampere-hour integration expression can be rewritten as
$$
SOC(t) = SOC_0 – \frac{1}{Q_{max}(t)}\int_0^t \eta I(\tau)\,d\tau.
$$
When SOH declines, \(Q_{max}\) decreases. If this decrease is not taken into account, the SOC reference produced by ampere-hour integration will be underestimated at the end-of-charge. Therefore, the SOH value estimated at cycle \(k\) can be used to correct the capacity term for the next cycle \(k+1\). In addition, the OCV-SOC characteristic curves shift as the EV battery ages. By measuring the OCV at different SOH levels, I can update the mapping table used in the equivalent-circuit model and in the EKF observation equation.
In the first stage of the joint approach, the SOH value is obtained from the PLO-optimized Transformer-LSTM model that was explained in the previous section. The SOH value is converted into the current maximum capacity by
$$
Q_{max} = SOH \times Q_{rated}.
$$
5.2 SOC correction and GPR SOC estimator
To obtain a more realistic SOC target, I apply the capacity correction method. Let the discharged ampere-hour be \(Q_t\). The corrected SOC reference is
$$
SOC’ = \frac{Q_{max} – Q_t}{Q_{max}} \times 100\%.
$$
In the pure data-driven branch of the joint estimation, the corrected SOC reference serves as the label for training a Gaussian process regression (GPR) model. The GPR model maps the voltage \(U\), current \(I\), and integrated charge into the SOC. I choose a rational quadratic kernel because it can capture both long-scale and short-scale variations present in an EV battery charge-discharge process:
$$
k(x_i,x_j) = \left(1 + \frac{\|x_i – x_j\|^2}{2\alpha l^2}\right)^{-\alpha},
$$
where \(l\) is the length-scale parameter and \(\alpha\) defines the relative weighting of large-scale and small-scale variations. The prediction of GPR at a new input vector is normally distributed with mean and variance, and the 95% confidence interval is computed accordingly.
5.3 Hybrid model-based and data-driven joint SOC-SOH estimation
Although the GPR-based data-driven method can model the nonlinear relationship between measurements and the corrected SOC, pure data-driven approaches might suffer from the availability and quality of training data. In addition, they do not explicitly incorporate the underlying electrochemical and physical constraints of the EV battery. Therefore, I further build a hybrid architecture that combines the model-based SOC estimation and the data-driven SOH estimation. The main idea is to feed the estimated SOH back into the SOC algorithm in the following ways:
- Capacity correction: update \(Q_{max}\) in the ampere-hour model and in the SOC state equation.
- OCV-SOC table update: use different fitted polynomial parameters for each SOH range so that the model represents the real open-circuit voltage of the aged EV battery.
- Noise covariance adjustment: because the battery operating conditions vary with aging, the process and measurement covariance in the EKF are periodically revised based on the estimated SOH value.
The joint framework can be represented by the following iterative equations. At cycle \(m\), let the trained Transformer-LSTM output be \(\widehat{SOH}_m\). Then
$$
\widehat{Q}_{max,m} = \widehat{SOH}_m \cdot Q_{rated}.
$$
The OCV-SOC relationship \(U_{OC} = f_m(SOC)\) is updated by interpolating the measured OCV at the current SOH level. Within this cycle, the PSO-EKF estimator uses the following discrete state-space model:
$$
\begin{aligned}
SOC_{k+1} &= SOC_k – \frac{\eta \Delta t}{\widehat{Q}_{max,m}} I_k + w_{SOC},\\
U_{1,k+1} &= e^{-\Delta t/\tau_1} U_{1,k} + R_1 (1-e^{-\Delta t/\tau_1}) I_k + w_1,\\
U_{2,k+1} &= e^{-\Delta t/\tau_2} U_{2,k} + R_2 (1-e^{-\Delta t/\tau_2}) I_k + w_2.
\end{aligned}
$$
The output model is
$$
U_{t,k} = f_m(SOC_k) – I_k R_0 – U_{1,k} – U_{2,k} + v_k.
$$
With this configuration, the SOC estimator automatically adapts to the current degradation level of the EV battery. At the end of the current cycle, the accumulated voltage curves and IC curves are processed to generate updated health indicators, which are then supplied to the SOH model for the next cycle. This closed loop enables an integrated SOC-SOH estimation that works on two time scales.
5.4 Experimental results and analysis
I performed experiments using the CALCE DST and FUDS cycles. The cells had already aged to approximately 90% SOH, meaning that the true SOC reference should be computed by dividing the remaining charge by the aged capacity. The filter was deliberately initialized with a SOC value of 90%, whereas the true SOC after the corrected reference was only 70%. Such a large start error is useful for testing the convergence and robustness of the developed joint estimator.
| Condition | Method | MAE | RMSE | R² |
|---|---|---|---|---|
| DST | GPR | 0.0084 | 0.1240 | 0.9971 |
| EKF (without SOH correction) | 0.1014 | 0.1016 | 0.7322 | |
| Joint estimation (ours) | 0.0080 | 0.0101 | 0.9974 | |
| FUDS | GPR | 0.0083 | 0.1190 | 0.9973 |
| EKF (without SOH correction) | 0.1044 | 0.1045 | 0.7894 | |
| Joint estimation (ours) | 0.0094 | 0.0108 | 0.9977 |
The table clearly shows that when the EV battery has degraded to 90% of its initial capacity, the standard EKF that relies on the nominal capacity produces a large SOC error. Conversely, both the GPR and the joint estimation successfully reduce the error by integrating the SOH information. The joint estimation method provides a better \(R^2\) than the pure GPR method in both DST and FUDS conditions. The slight difference between DST and FUDS arises from the different current profiles and thus different voltage excursions. Overall, the proposed SOC-SOH joint architecture gives the BMS a highly accurate and robust state awareness over the lifespan of the EV battery.
6. Conclusion
In this thesis, I have designed and experimentally validated state estimation algorithms for the SOC and SOH of an EV battery. For SOC, I used a second-order RC equivalent circuit model and identified its parameters through recursive least squares. The extended Kalman filter was enhanced by a particle swarm optimizer that selects the optimal process and measurement noise covariance matrices. Under dynamic stress test conditions, the PSO-EKF achieved a small voltage estimation error and an SOC mean absolute error of 0.0017, which is better than the conventional EKF. For SOH, I proposed a Transformer-LSTM network that combines a self-attention encoder with an LSTM memory decoder. A polar lights optimizer automatically tunes the number of heads, the learning rate, and the regularization coefficient. The model was trained on data from NASA, CALCE, and a 33 Ah lithium titanate power battery. The full life cycle estimation root mean square error was no larger than 0.01, and the coefficient of determination in the 50%-prediction-start experiment was always higher than 0.95. These results verify the superior ability of the Transformer-LSTM model to describe the nonlinear and stochastic aging process of an EV battery.
Finally I combined the model-based SOC filter and the data-driven SOH network into a unified joint SOC-SOH estimation framework. In this framework, the estimated SOH is used to update the maximum capacity and to adjust the OCV-SOC curve before the next cycle begins. The corrected parameters are then adopted by the PSO-EKF to produce SOC estimates that are close to the true remaining energy. The joint estimation method reduces the SOC error dramatically when the EV battery is at an aged state, as shown by experiments under DST and FUDS profiles. The proposed framework could therefore provide accurate and reliable state information for real-time BMS and future battery-health management systems.