
As the global demand for clean energy continues to grow, the new energy vehicle industry has expanded rapidly. The EV battery pack, as the core energy storage device, directly determines the driving range, safety, and overall cost of electric vehicles. Lithium-ion batteries are the dominant choice for EV battery pack systems due to their high energy density, long cycle life, and low self-discharge rate. However, during repeated charging and discharging, the EV battery pack undergoes irreversible chemical and physical changes, leading to capacity fade, internal resistance increase, and performance degradation. This degradation phenomenon is inevitable and significantly affects the reliability and safety of electric vehicles.
To ensure the safe operation of an EV battery pack, accurate monitoring of its degradation state is essential. Two critical indicators are widely used: State of Health (SOH) and Remaining Useful Life (RUL). SOH describes the current health condition of the battery relative to its initial state, while RUL predicts the remaining number of charge-discharge cycles before the battery reaches its end-of-life threshold. Traditional methods based on empirical formulas or simple threshold rules often fail to capture the complex nonlinear degradation behavior, especially in the later stages of battery life. Data-driven approaches, particularly deep learning and machine learning, have shown great potential in learning degradation patterns from historical data. However, a single data-driven model often struggles to handle the uncertainties caused by feature selection noise, data noise, and capacity regeneration phenomena. Therefore, multi-model fusion strategies have been proposed to combine the strengths of different models and improve prediction accuracy.
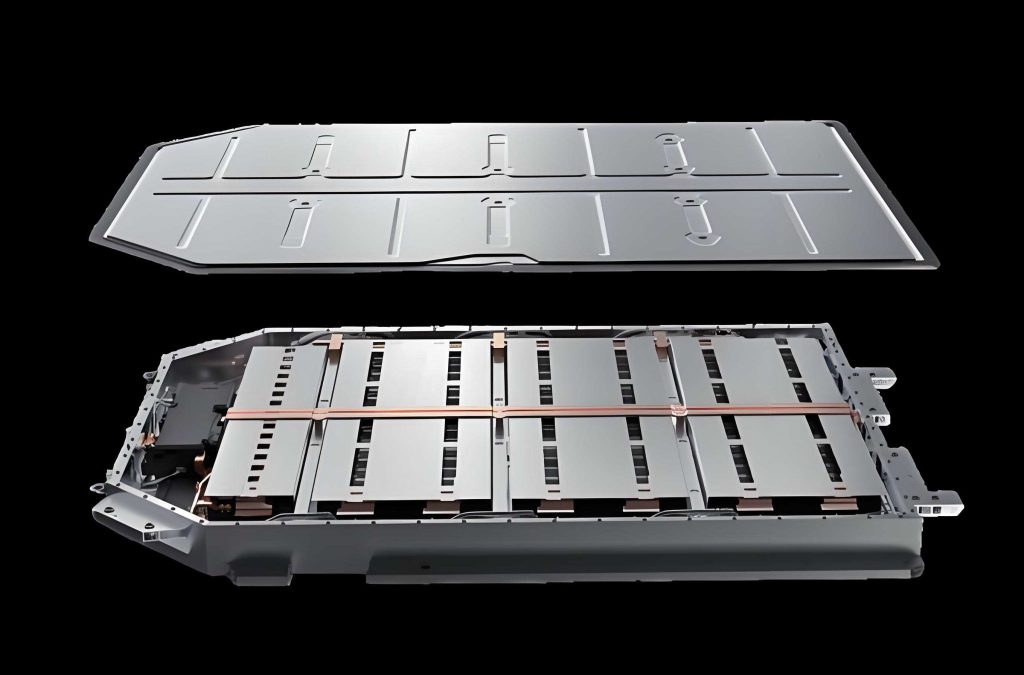
In this research, I develop a comprehensive framework for EV battery pack degradation state prediction based on multi-model fusion. The work is divided into three main parts: health factor analysis and selection, SOH estimation, and RUL prediction. I first analyze the charging and discharging curves of battery cells to extract reliable indirect health factors, which are then verified using Pearson correlation coefficients. Then, I propose a hybrid model combining a denoising autoencoder (DAE), self-attention mechanism, and extreme gradient boosting (XGBoost) for accurate SOH estimation. Finally, I present a decomposition-based fusion model that combines complete ensemble empirical mode decomposition with adaptive noise (CEEMDAN), bidirectional long short-term memory (BiLSTM), Gaussian process regression (GPR), and adaptive particle swarm optimization (APSO) for robust RUL prediction. The proposed methods are validated on public battery datasets, demonstrating high accuracy and excellent generalization capability.
Battery Structure and Degradation Mechanism
A thorough understanding of the EV battery pack structure and its degradation mechanisms is essential for building reliable prediction models. Lithium-ion batteries consist of positive and negative electrodes, an electrolyte, a separator, and a casing. The positive electrode is typically made of lithium metal oxides such as LiFePO4, LiCoO2, or LiNiMnCoO2, while the negative electrode is generally graphite or silicon-based materials. During charging, lithium ions deintercalate from the positive electrode, migrate through the electrolyte, and intercalate into the negative electrode. During discharge, the reverse process occurs. The overall electrochemical reaction is represented as follows:
For a LiFePO4/graphite battery, the charging reaction is:
$$
\begin{aligned}
\text{Positive: } & \mathrm{LiFePO_4} \rightarrow \mathrm{Li}^+ + e^- + \mathrm{FePO_4}\\
\text{Negative: } & \mathrm{C_6} + \mathrm{Li}^+ + e^- \rightarrow \mathrm{LiC_6}
\end{aligned}
$$
The discharge reaction is:
$$
\begin{aligned}
\text{Positive: } & \mathrm{LiFePO_4} + e^- \rightarrow \mathrm{Li}^+ + \mathrm{FePO_4}\\
\text{Negative: } & \mathrm{LiC_6} \rightarrow \mathrm{C_6} + \mathrm{Li}^+ + e^-
\end{aligned}
$$
Battery degradation arises from both internal and external factors. Internal factors include solid electrolyte interface (SEI) layer growth, electrode material structural degradation, and electrolyte decomposition. External factors include temperature, charge/discharge rate, and depth of discharge. These factors jointly cause capacity fade and impedance rise, which are the primary manifestations of EV battery pack degradation.
Health Factor Analysis and Selection
Accurate SOH estimation requires selecting health factors that are strongly correlated with battery capacity. Direct health factors such as capacity and internal resistance are difficult to measure in real time. Indirect health factors extracted from charge-discharge curves provide a practical alternative. In this study, I use two public datasets: the NASA battery dataset and the CALCE battery dataset. The NASA dataset includes batteries B0005, B0006, B0007, and B0018, while the CALCE dataset includes CS2_35, CS2_36, CS2_37, and CS2_38. All batteries undergo similar cycling tests, with a constant current (CC) charging phase, constant voltage (CV) charging phase, and CC discharge phase.
Before feature extraction, I preprocess the raw data to handle missing values and outliers. I apply the Isolation Forest algorithm to detect anomalies, and then replace the abnormal points using a moving-window average method. This preprocessing step reduces interference and improves data quality.
Taking battery B0005 as an example, I visualize the charge and discharge voltage, current, and temperature curves over different cycles. Table 1 lists the selected indirect health factors for the NASA dataset.
| Health factor | Description |
|---|---|
| HI1 | Charge-discharge cycle number |
| HI2 | Time to reach peak charging temperature |
| HI3 | Time to reach peak discharging temperature |
| HI4 | Time to reach constant voltage during charging |
| HI5 | Constant voltage charging duration |
| HI6 | Time to reach minimum voltage during discharging |
| HI7 | Constant current charging duration |
| HI8 | Constant current discharging duration |
For the CALCE dataset, the selected health factors are slightly different because the charging protocol is the same but the number of cycles is much larger. Table 2 lists the health factors for the CALCE battery dataset.
| Health factor | Description |
|---|---|
| HI1 | Charge-discharge cycle number |
| HI2 | Time to reach constant voltage during charging |
| HI3 | Constant voltage charging duration |
| HI4 | Time to reach minimum voltage during discharging |
| HI5 | Constant current charging duration |
| HI6 | Constant current discharging duration |
To verify the relevance of these health factors, I use the Pearson correlation coefficient (PCC), which measures the linear correlation between two variables. The PCC is calculated as:
$$
\lambda = \frac{\sum_{i=1}^{n} (X_i – \bar{X})(Y_i – \bar{Y})}{\sqrt{\sum_{i=1}^{n} (X_i – \bar{X})^2} \sqrt{\sum_{i=1}^{n} (Y_i – \bar{Y})^2}}
$$
where \( \lambda \) ranges from -1 to 1. A value close to 1 indicates a strong positive correlation, while a value close to -1 indicates a strong negative correlation. Table 3 presents the PCC values for battery B0005.
| HI | HI1 | HI2 | HI3 | HI4 | HI5 | HI6 | HI7 | HI8 |
|---|---|---|---|---|---|---|---|---|
| PCC | -0.9877 | 0.9966 | 0.9974 | 0.9597 | -0.9061 | 0.9976 | 0.9964 | 0.9977 |
Based on the PCC values and curve analysis, I select HI1, HI2, HI3, HI4, HI6, HI7, and HI8 for the NASA dataset, and HI1, HI2, HI4, HI5, and HI6 for the CALCE dataset. These selected health factors serve as input features for the SOH estimation model, thereby reducing the uncertainty caused by inappropriate feature selection.
SOH Estimation Based on Multi-Model Fusion
The SOH of an EV battery pack is defined as the ratio of the current maximum available capacity to the rated capacity:
$$
SOH = \frac{C_n}{C_0} \times 100\%
$$
where \( C_n \) is the current maximum capacity and \( C_0 \) is the rated capacity. Although capacity is a direct health indicator, it is difficult to measure online. Therefore, I use the selected indirect health factors as inputs to a regression model that estimates the SOH value.
Data noise is a common issue in battery measurements. Simple feature extraction methods may lose key information when noise is present. To address this, I propose a hybrid model named DAE-Attention-XGBoost, which combines a denoising autoencoder, a self-attention mechanism, and the XGBoost algorithm. The architecture is shown conceptually in the model framework.
In the DAE module, noise is added to the input data, and the encoder maps the corrupted input to a low-dimensional representation. The decoder then reconstructs the original input from this representation. The reconstruction loss is minimized using mean squared error. The self-attention mechanism computes attention weights to highlight the most relevant features. For a given feature vector \( h_i \), the query, key, and value vectors are computed as:
$$
\begin{aligned}
q_i &= W_Q h_i \\
k_i &= W_K h_i \\
v_i &= W_V h_i
\end{aligned}
$$
The attention score is:
$$
\text{AttentionScore} = \frac{q_i \cdot k_j}{\sqrt{d}}
$$
and the attention weights are obtained via softmax:
$$
\alpha_{ij} = \frac{\exp(\text{AttentionScore}_{ij})}{\sum_{k=1}^{N} \exp(\text{AttentionScore}_{ik})}
$$
The final representation is the weighted sum of value vectors:
$$
z_i = \sum_{j=1}^{N} \alpha_{ij} v_j
$$
After feature extraction, XGBoost is used to perform the regression task. XGBoost iteratively trains decision trees to minimize a loss function with regularization. The objective function is:
$$
L = \sum_{i=1}^{N} (y_i – \hat{y}_i)^2 + \sum_{k=1}^{K} \Omega(f_k)
$$
where \( \Omega(f_k) = \gamma T + \frac{1}{2} \lambda \sum_{j=1}^{T} w_j^2 \), with \( T \) being the number of leaves and \( w_j \) the leaf weights. The final prediction is:
$$
\hat{y}_i = \sum_{t=1}^{K} \eta f_t(x_i)
$$
where \( \eta \) is the learning rate.
To validate the effectiveness of the proposed model, I conduct experiments on the NASA dataset using three batteries as training data and one battery as test data. Table 4 shows the evaluation metrics for battery B0006.
| Metric | MSE | MAE | RMSE | R² |
|---|---|---|---|---|
| Value | 0.00012 | 0.00745 | 0.00936 | 0.99167 |
Ablation experiments are performed to verify the contribution of each module. Table 5 shows the results.
| DAE | Attention | XGBoost | MSE | MAE | RMSE | R² |
|---|---|---|---|---|---|---|
| √ | 0.00018 | 0.01087 | 0.01378 | 0.98753 | ||
| √ | √ | 0.00014 | 0.00824 | 0.01131 | 0.98901 | |
| √ | √ | √ | 0.00012 | 0.00745 | 0.00936 | 0.99167 |
I further compare the proposed model with several baseline models, including CNN, GRU, BiLSTM, CNN-GRU, CNN-BiLSTM, and DAE-Transformer. Table 6 summarizes the average metrics across four batteries.
| Model | MSE | MAE | RMSE | R² |
|---|---|---|---|---|
| CNN | 0.00045 | 0.01763 | 0.02104 | 0.95369 |
| GRU | 0.00049 | 0.01758 | 0.02165 | 0.95045 |
| BiLSTM | 0.00053 | 0.01889 | 0.02230 | 0.94905 |
| CNN-GRU | 0.00019 | 0.01027 | 0.01355 | 0.98043 |
| CNN-BiLSTM | 0.00018 | 0.01154 | 0.01381 | 0.97889 |
| DAE-Transformer | 0.00016 | 0.00982 | 0.01237 | 0.98214 |
| DAE-Attention-XGBoost | 0.00007 | 0.00559 | 0.00789 | 0.99226 |
The proposed model achieves the lowest errors and the highest R², demonstrating that the combination of DAE, Attention, and XGBoost can effectively handle noisy features and improve SOH estimation accuracy. To evaluate generalization, I also test the model on the CALCE dataset. Table 7 reports the metrics for the four CALCE batteries.
| Battery | MSE | MAE | RMSE | R² |
|---|---|---|---|---|
| CS2_35 | 0.00013 | 0.00710 | 0.01119 | 0.99633 |
| CS2_36 | 0.00019 | 0.01159 | 0.01376 | 0.99493 |
| CS2_37 | 0.00022 | 0.00712 | 0.01471 | 0.99366 |
| CS2_38 | 0.00016 | 0.00942 | 0.01266 | 0.99510 |
The consistent performance across different datasets confirms the robustness and generalization capability of the proposed SOH estimation method for EV battery pack applications.
RUL Prediction with Capacity Regeneration Handling
RUL is defined as the remaining number of cycles before the battery capacity falls below a failure threshold, typically 70% of the rated capacity. The actual RUL is:
$$
RUL = T_{eol} – T
$$
where \( T \) is the current cycle number and \( T_{eol} \) is the cycle number at end-of-life. Accurate RUL prediction requires capturing both the long-term degradation trend and the short-term fluctuations caused by capacity regeneration. Capacity regeneration is a phenomenon where the battery temporarily recovers some capacity after a rest period, introducing local fluctuations that severely affect prediction accuracy.
To address this issue, I propose a CEEMDAN-APSO-BiLSTM-GPR model. The capacity data is first decomposed by CEEMDAN into several intrinsic mode functions (IMFs). High-frequency IMFs contain short-term local variations and are modeled by BiLSTM, while low-frequency IMFs represent the main degradation trend and are modeled by GPR. The APSO algorithm is used to optimize the hyperparameters of both models.
The CEEMDAN decomposition process can be described as follows. Given the original capacity signal \( x(t) \), white noise \( n_i(t) \) is added to create multiple noisy signals:
$$
x_i(t) = x(t) + n_i(t)
$$
Each noisy signal is decomposed using EMD, and the first IMF is averaged to obtain \( \overline{IMF_1} \). The first residual is:
$$
r_1(t) = x(t) – \overline{IMF_1}
$$
The procedure is repeated on the residual with added noise until the residual is a monotonic function. The original signal is reconstructed as:
$$
x(t) = \sum_{k=1}^{K} \overline{IMF_k} + r_K(t)
$$
For the NASA B0005 battery, the decomposition yields three high-frequency IMFs and one low-frequency IMF. The Pearson correlation coefficients between each IMF and the original capacity are listed in Table 8.
| IMF | IMF1 | IMF2 | IMF3 | IMF4 |
|---|---|---|---|---|
| Correlation | 0.0690 | 0.2037 | 0.0007 | 0.9971 |
The high-frequency components (IMF1-IMF3) have low correlation, while the low-frequency component (IMF4) has a very high correlation, indicating that the degradation trend is well captured.
For BiLSTM, the forward hidden state and backward hidden state are computed as:
$$
\overrightarrow{h_t} = LSTM_{fwd}(x_t, \overrightarrow{h_{t-1}})
$$
$$
\overleftarrow{h_t} = LSTM_{bwd}(x_t, \overleftarrow{h_{t+1}})
$$
The final hidden state is the concatenation of the two directions:
$$
h_t = [\overrightarrow{h_t}; \overleftarrow{h_t}]
$$
The output is computed via a linear layer:
$$
\hat{y}_t = W_y h_t + b_y
$$
For GPR, the predictive distribution for a new input \( X_* \) is Gaussian with mean and variance:
$$
\mu_* = K_*^T (K + \sigma^2 I)^{-1} y
$$
$$
\sigma_*^2 = K_{**} – K_*^T (K + \sigma^2 I)^{-1} K_*
$$
where \( K \) is the kernel matrix, \( K_* \) is the kernel vector between test and training points, and \( K_{**} \) is the kernel at the test point. I use the radial basis function (RBF) kernel:
$$
k(x_i, x_j) = \sigma_f^2 \exp\left(-\frac{\|x_i – x_j\|^2}{2 l^2}\right)
$$
APSO dynamically adjusts the inertia weight and learning factors during the search process to find the optimal hyperparameters. The velocity update is:
$$
V_i^{t+1} = \omega V_i^t + c_1 r_1 (P_{best,i} – X_i^t) + c_2 r_2 (G_{best} – X_i^t)
$$
and the position update is:
$$
X_i^{t+1} = X_i^t + V_i^{t+1}
$$
The inertia weight \( \omega \) is updated as:
$$
\omega = \omega_{max} – \frac{\omega_{max} – \omega_{min}}{T} \cdot t
$$
where \( T \) is the maximum iteration number and \( t \) is the current iteration.
I first verify the feasibility of the proposed model on battery B0005 with a training cutoff at cycle 80. The predicted RUL and evaluation metrics are shown in Table 9.
| Metric | Actual RUL | Predicted RUL | AE | MAE | RMSE | R² |
|---|---|---|---|---|---|---|
| Value | 45 | 45 | 0 | 0.0015 | 0.0018 | 0.9994 |
I also test the model at different prediction starting points (70, 80, and 90 cycles) as shown in Table 10.
| Start | Actual RUL | Predicted RUL | AE | MAE | RMSE | R² |
|---|---|---|---|---|---|---|
| 70 | 55 | 54 | 1 | 0.0018 | 0.0024 | 0.9992 |
| 80 | 45 | 45 | 0 | 0.0015 | 0.0018 | 0.9994 |
| 90 | 35 | 35 | 0 | 0.0013 | 0.0015 | 0.9995 |
Ablation experiments are conducted to examine the contribution of each module. Table 11 presents the results for B0005 at the 80-cycle starting point.
| CEEMDAN | APSO | BiLSTM | GPR | AE | MAE | RMSE | R² |
|---|---|---|---|---|---|---|---|
| √ | √ | 5 | 0.0385 | 0.0479 | 0.7346 | ||
| √ | √ | 4 | 0.0265 | 0.0359 | 0.7976 | ||
| √ | √ | √ | 3 | 0.0067 | 0.0113 | 0.9196 | |
| √ | √ | √ | 2 | 0.0052 | 0.0093 | 0.9324 | |
| √ | √ | √ | √ | 0 | 0.0015 | 0.0018 | 0.9994 |
The comparison experiments on the NASA dataset are carried out against several state-of-the-art methods, including LSTM, BiLSTM, EEMD-GRU-MLR, EEMD-GRU-TCN-Attention, and VMD-LSTM-GPR. Table 12 lists the average AE, MAE, and RMSE for the four batteries.
| Model | AE (average) | MAE | RMSE |
|---|---|---|---|
| LSTM | 5.75 | 0.0331 | 0.0414 |
| BiLSTM | 3.75 | 0.0277 | 0.0339 |
| EEMD-GRU-MLR | 1.75 | 0.0081 | 0.0161 |
| EEMD-GRU-TCN-Attention | 0.67 | 0.0049 | 0.0065 |
| VMD-LSTM-GPR | 1.00 | 0.0117 | 0.0140 |
| CEEMDAN-APSO-BiLSTM-GPR | 0.00 | 0.0028 | 0.0038 |
The proposed model yields the lowest errors and exact RUL predictions, confirming its superiority in handling capacity regeneration and nonlinear degradation behaviors. The generalization capability is further validated on the CALCE dataset. For each battery, the training starts from cycle 1 to 400 (or 450 for CS2_37 and CS2_38), and the prediction starts from cycle 400 or 450. Table 13 shows the results.
| Battery | Start | Actual RUL | Predicted RUL | AE | MAE | RMSE | R² |
|---|---|---|---|---|---|---|---|
| CS2_35 | 400 | 240 | 239 | 1 | 0.0032 | 0.0047 | 0.9982 |
| CS2_36 | 400 | 245 | 246 | 1 | 0.0029 | 0.0042 | 0.9995 |
| CS2_37 | 450 | 267 | 266 | 1 | 0.0039 | 0.0059 | 0.9991 |
| CS2_38 | 450 | 306 | 305 | 0 | 0.0045 | 0.0063 | 0.9989 |
The consistent performance on both datasets demonstrates that the multi-model fusion framework is highly effective for EV battery pack RUL prediction, even under different cycling conditions and battery chemistries.
Conclusion
In this work, I have presented a comprehensive multi-model fusion approach for EV battery pack degradation state prediction, covering both SOH estimation and RUL prediction. For health factor selection, I systematically analyzed charge-discharge curves and used Pearson correlation coefficients to identify the most relevant indirect health factors, reducing the uncertainty caused by empirical feature selection. For SOH estimation, I developed a DAE-Attention-XGBoost model that combines denoising feature extraction with attention weighting and gradient boosting regression. The model effectively mitigates the impact of data noise and achieves superior estimation accuracy on the NASA and CALCE datasets. For RUL prediction, I designed a CEEMDAN-APSO-BiLSTM-GPR model that decomposes the capacity signal into trend and fluctuation components, models them separately, and fuses the predictions to obtain accurate RUL values. The proposed framework successfully addresses the challenges of capacity regeneration and nonlinear degradation, providing a robust solution for EV battery pack health management.
Future research may explore more advanced feature selection methods, integration of physics-based models with data-driven models, and deeper investigation of capacity regeneration mechanisms to further improve prediction accuracy and interpretability. The ultimate goal is to deploy the proposed framework in real-time battery management systems for enhanced safety and reliability of electric vehicles.