
My research focuses on the state estimation and lifetime prognosis of lithium-ion power batteries under dynamic operating conditions, which are critical for the safe and reliable operation of electric vehicle battery systems. The state of charge (SOC) and remaining useful life (RUL) are two core indicators in the battery management system (BMS) of any electric vehicle battery. Precise SOC estimation ensures optimal energy utilization and prevents over-charge/discharge, while accurate RUL prediction enables timely maintenance and replacement decisions. Through my investigation, I found that existing methods are predominantly developed under idealized laboratory conditions. When these methods are applied to real-world scenarios, which are characterized by dynamic load profiles, temperature variations, and aging effects, they often suffer from significant estimation errors and degraded robustness. This fundamental limitation poses potential safety hazards and reduces the practical reliability of electric vehicle battery systems.
To address these challenges, I conducted my research along two interconnected technical pathways: a hybrid SOC estimation framework that integrates model-driven filtering with deep residual learning, and a comprehensive RUL prediction methodology that combines multi-dimensional feature fusion with multi-scale decomposition and attention-enhanced deep learning. Throughout my experimental verification, I constructed two distinct datasets and evaluated my proposed methods under multiple dynamic driving cycles and wide temperature ranges. The experimental results demonstrate that my methods achieve superior accuracy, strong generalization capability, and robust performance in complex operating environments. This research provides a valuable theoretical basis and engineering reference for the intelligent health management of electric vehicle battery systems.
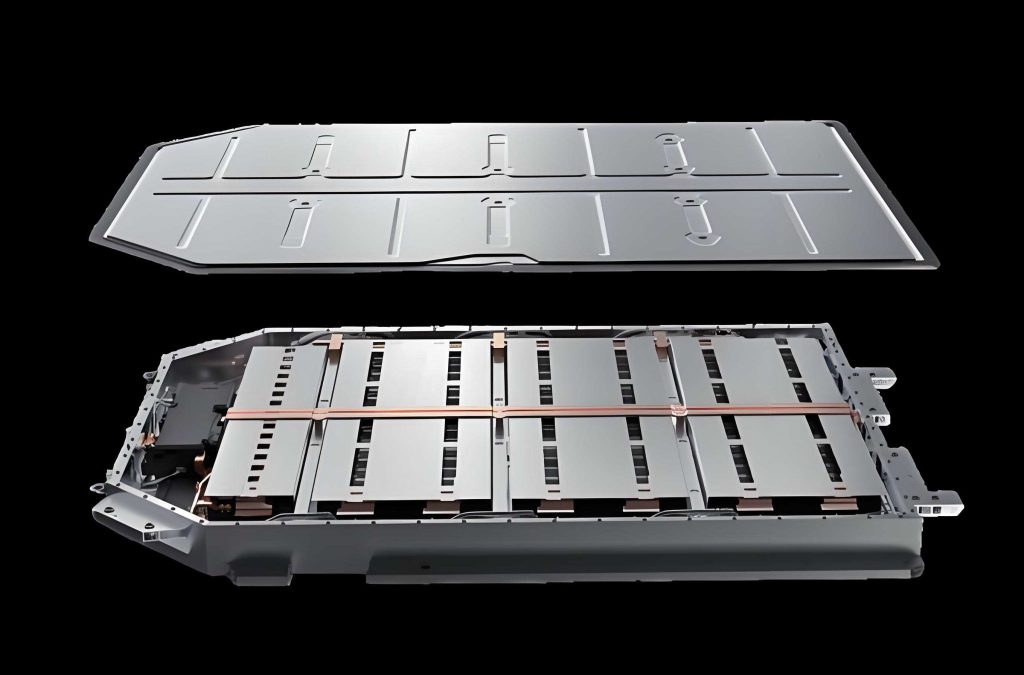
1. Introduction and Research Context
The global energy landscape is undergoing a profound transformation driven by the depletion of traditional fossil fuels and the urgent need to address climate change. In this context, the development of electric vehicles has emerged as a strategic priority for achieving green and low-carbon development. China has implemented a series of policies since the 13th Five-Year Plan period to promote the transition from conventional fuel vehicles to new energy vehicles. The “dual carbon” goals have further elevated the strategic importance of the electric vehicle battery industry. According to my analysis of industry statistics, new energy vehicle sales accounted for nearly 50% of total automobile sales in China by 2025, representing a remarkable increase from less than 0.1% in 2011. This rapid growth reflects not only technological maturity but also the profound impact of national energy strategies on the automotive industry.
The expanding market penetration of electric vehicles places higher demands on the safety, reliability, and intelligent management of electric vehicle battery systems. Unlike traditional vehicles, electric vehicles rely entirely on battery packs for propulsion energy. The performance of these batteries directly determines the vehicle’s driving range, acceleration capability, and overall safety. In practice, an electric vehicle battery must endure various operating conditions, including urban stop-and-go traffic, highway cruising, aggressive acceleration, and regenerative braking. Each of these conditions imposes different stress profiles on the battery, leading to complex electrochemical and thermal behaviors. Additionally, ambient temperature variations across different geographical regions and seasons introduce further complexity to battery state estimation.
Within the battery management system, SOC and RUL serve as fundamental parameters for operational control and lifecycle management. SOC indicates the remaining available energy as a percentage of the battery’s maximum capacity, providing the basis for energy distribution, range prediction, and protection against over-charge and over-discharge. RUL quantifies the remaining number of charge-discharge cycles before the battery degrades to its end-of-life threshold, guiding maintenance scheduling and replacement decisions. The mathematical definitions of these quantities are presented below.
The capacity-based SOC definition is most widely used and is expressed as:
$$ SOC(t) = \frac{C_{now}(t)}{C_{max}} \quad (1) $$
where \( C_{now}(t) \) is the remaining available capacity at time t, and \( C_{max} \) is the maximum available capacity under the current health state.
The ampere-hour integration form of SOC, commonly used in engineering practice, is given by:
$$ SOC(t) = SOC(t_0) – \frac{1}{C_n} \int_{t_0}^{t} \eta I(\tau) d\tau \quad (2) $$
where \( SOC(t_0) \) signifies the initial SOC value, \( I(\tau) \) is the current at time \( \tau \), \( \eta \) denotes the Coulombic efficiency, and \( C_n \) represents the rated capacity.
The RUL of an electric vehicle battery is mathematically defined as:
$$ RUL = Cycle_{EOL} – Cycle_{NOW} \quad (3) $$
where \( Cycle_{EOL} \) represents the total number of cycles at the end-of-life threshold and \( Cycle_{NOW} \) represents the current cycle number.
2. Literature Review and Research Gaps
2.1 SOC Estimation Research Status
SOC estimation methods for electric vehicle battery systems have evolved significantly over the past decades. Early approaches included ampere-hour counting and model-based filtering methods. My review indicates that the ampere-hour counting method suffers from cumulative current measurement errors and sensitivity to initial SOC values. To mitigate these limitations, researchers have combined ampere-hour integration with Kalman filtering techniques. For instance, some scholars proposed a hybrid method combining ampere-hour integration with Unscented Kalman Filter (UKF), which improved estimation accuracy by correcting the accumulated drift through voltage-based corrections.
In the category of model-based approaches, equivalent circuit models (ECM) coupled with Kalman filter variants are the most prevalent. The Extended Kalman Filter (EKF) was widely adopted but exhibits limitations when applied to strongly nonlinear systems due to first-order linearization errors. The Unscented Kalman Filter overcomes this limitation by propagating sigma points through the nonlinear system, achieving second-order accuracy. Studies have shown that UKF outperforms EKF in lithium-ion battery SOC estimation under dynamic conditions. However, my analysis revealed that both methods maintain fixed noise covariance matrices, which becomes a critical weakness when the electric vehicle battery operates under rapidly changing conditions where noise statistics are time-varying.
To address the time-varying noise issue, adaptive filtering techniques were introduced. My study found that noise adaptive estimation methods can update process noise covariance and measurement noise covariance online. Some researchers proposed adaptive dual extended Kalman filters that simultaneously estimate system states and model parameters while adapting noise statistics. In the realm of multi-model approaches, Multiple Model Adaptive Estimation (MMAE) constructs multiple parallel filters with different noise model assumptions and fuses their outputs based on posterior probabilities. This approach demonstrated improved robustness in handling model uncertainties and abrupt state changes.
With the advancement of machine learning, data-driven methods have gained considerable attention. Deep learning approaches, including Long Short-Term Memory (LSTM) networks, Gated Recurrent Unit (GRU) networks, and Convolutional Neural Networks (CNN), have been applied to learn the nonlinear mapping between battery measurable signals and SOC directly from data. These methods achieve high accuracy in capturing complex nonlinear patterns. However, my research revealed that pure data-driven methods face challenges in generalization across different operating temperatures and aging stages, often overfitting to the training data distribution. Hybrid models that combine the physical interpretability of filtering methods with the nonlinear fitting capacity of neural networks have emerged as a promising direction. In this context, I identified a critical research gap: existing hybrid methods are primarily optimized for normal temperature and steady-state conditions, lacking comprehensive validation under combined dynamic load profiles and wide temperature ranges.
2.2 RUL Prediction Research Status
The prediction of remaining useful life for an electric vehicle battery has been approached through three primary categories of methods: mechanism-based models, statistical and machine learning models, and data-driven deep learning models.
Mechanism-based approaches, such as the Single Particle Model and electrochemical impedance spectroscopy-based models, provide physical insights into battery degradation processes. However, these models require complex parameter identification and struggle to generalize across different battery chemistries and operating conditions. The computational complexity further limits their real-time deployment in BMS.
Statistical regression methods and traditional machine learning techniques have been widely explored. Gaussian Process Regression (GPR) offers probabilistic predictions with uncertainty quantification, while Support Vector Regression (SVR) and Relevance Vector Machine (RVM) have demonstrated reasonable accuracy in capacity fade prediction. Nevertheless, these methods often rely on manually selected health indicators and may not fully capture the multi-scale characteristics of battery degradation.
More recently, multi-scale signal decomposition techniques have been integrated into RUL prediction frameworks. Variational Mode Decomposition (VMD) provides an adaptive approach to decompose non-stationary signals into multiple intrinsic mode functions. My investigation found that combining VMD with LSTM networks allows for separate modeling of global degradation trends and local fluctuations, thereby improving prediction accuracy. Deep learning architectures, particularly BiLSTM networks and attention-based models, have shown remarkable performance in capturing long-term temporal dependencies within battery degradation sequences. The addition of dropout regularization helps mitigate overfitting, which is particularly important when training on limited battery aging datasets.
Despite these advances, my research identified persistent challenges: the selection of health indicators often lacks comprehensiveness, focusing either on global capacity trends or local voltage features separately; dynamic condition generalization remains under-explored; and many methods fail to adequately address the capacity recovery and sudden drop phenomena observed in real battery aging data. These gaps motivated me to develop an integrated RUL prediction framework that addresses these limitations through comprehensive feature engineering and advanced model design.
3. Experimental Platform and Dataset Construction
3.1 Lithium-ion Battery Fundamentals
Lithium-ion batteries are secondary batteries operating on the principle of reversible lithium-ion intercalation and deintercalation between the positive and negative electrodes. The performance characteristics of these batteries are primarily determined by the electrode material system, especially the positive electrode composition. Among the various types of lithium-ion batteries, ternary lithium batteries based on nickel-cobalt-manganese (NCM) or nickel-cobalt-aluminum (NCA) cathodes offer an optimal balance between energy density and power performance, making them the dominant choice for electric vehicle battery applications. Table 1 presents a comparison of different lithium-ion battery chemistries used in my research.
| Battery Type | Cathode Material | Operating Voltage (V) | Cycle Life (cycles) | Energy Density (Wh/kg) |
|---|---|---|---|---|
| Lithium Iron Phosphate | LiFePO₄ | 3.2-3.3 | 2000-4000 | 120-180 |
| Lithium Cobalt Oxide | LiCoO₂ | 3.6-3.7 | 500-1000 | 180-240 |
| Lithium Manganese Oxide | LiMn₂O₄ | 3.7-3.8 | 500-1500 | 100-150 |
| Ternary Lithium | NCM/NCA | 3.6-3.7 | 1000-2000 | 180-280 |
The structure of a lithium-ion battery for electric vehicle battery applications consists of positive electrode, negative electrode, electrolyte, separator, and current collectors. The positive electrode is typically composed of lithium metal oxide, while the negative electrode uses graphite-based carbon materials. The electrolyte, acting as the lithium-ion transport medium, is formed by dissolving lithium salts in organic solvents. The separator prevents direct contact between the electrodes while allowing lithium-ion migration. During the charging process, external power drives lithium ions to deintercalate from the positive electrode, migrate through the electrolyte and separator, and intercalate into the negative electrode lattice. Simultaneously, electrons flow through the external circuit from the positive to the negative electrode. The discharge process reverses these reactions, releasing stored energy. The electrochemical reactions occurring within the battery can be described by the following equations:
Positive electrode reaction:
$$ LiCoO_2 \xrightarrow[discharge]{charge} Li_{1-x}CoO_2 + xLi^+ + xe^- \quad (4) $$
Negative electrode reaction:
$$ C_6 + xLi^+ + xe^- \xrightarrow[discharge]{charge} Li_xC_6 \quad (5) $$
Overall reaction:
$$ LiCoO_2 + C_6 \xrightarrow[discharge]{charge} Li_{1-x}CoO_2 + Li_xC_6 \quad (6) $$
3.2 Experimental Setup
For my experimental research, I selected Samsung 18650 ternary lithium-ion power batteries as the primary test objects. These batteries provide a rated capacity of 3.4Ah with a nominal voltage of 3.7V. The charging cut-off voltage is 4.2V, and the discharge cut-off voltage is 2.75V. This battery model is widely used in electric vehicle battery applications, including vehicles from several major manufacturers. For the aging experiments, I additionally selected commercial 18650 ternary lithium-ion batteries with a rated capacity of 2.0Ah.
I constructed a comprehensive battery testing platform consisting of three main components: an Arbin multifunctional battery test system, a programmable constant temperature and humidity chamber, and an upper computer equipped with MITS Pro software. The Arbin system provided high-precision constant current constant voltage control and multi-channel parallel testing capabilities, enabling me to flexibly load various operating conditions and collect voltage, current, capacity, power, and time data at fixed sampling frequencies. The programmable temperature chamber offered a temperature range of -40°C to 60°C, allowing me to simulate diverse environmental conditions. The integration of these components, as illustrated in my experimental setup, enabled precise control and high-frequency data acquisition for subsequent SOC estimation and RUL prediction research.
3.3 SOC Characteristic Test under Complex Conditions
To comprehensively evaluate the dynamic performance of the electric vehicle battery under realistic operating scenarios, I designed SOC characteristic experiments incorporating four typical dynamic driving cycles. These include the Federal Urban Driving Schedule (FUDS), Dynamic Stress Test (DST), Worldwide Harmonized Light Vehicles Test Procedure (WLTP), and US06 high-acceleration aggressive driving cycle. Each cycle represents distinct current load patterns, collectively covering urban stop-and-go conditions, highway driving, and aggressive acceleration scenarios. My experiments were conducted systematically at three temperature levels — 0°C, 25°C, and 40°C — to examine the coupled effects of temperature and dynamic load on battery behavior.
The experimental procedure for each temperature-condition combination involved the following steps. The battery was first charged using a constant current of 1C to reach the upper cut-off voltage of 4.2V, followed by constant voltage charging until the current dropped below 0.02C. After a rest period of one hour, the battery was subjected to the specified dynamic cycle until the discharge cut-off voltage of 2.75V was reached. The battery was then rested for another hour before the next test. Throughout these experiments, I recorded complete voltage, current, and capacity profiles for each cycle, providing the foundational dataset for validating my SOC estimation framework.
My analysis of the capacity measurement data at different temperatures and operating conditions revealed several important patterns. At any given temperature, the WLTP cycle consistently yielded the lowest discharge capacity, while the FUDS and US06 cycles resulted in relatively higher capacities. This variation arises from the different power demand profiles embedded within each cycle. Furthermore, for a fixed operating cycle, capacity increased with increasing temperature, with the lowest values observed at 0°C and the highest at 40°C. This temperature dependence is attributed to increased internal resistance and restricted lithium-ion transport at low temperatures, while elevated temperatures facilitate more favorable electrochemical kinetics. These findings underscore the critical importance of considering both cycle characteristics and ambient temperature in SOC estimation for electric vehicle battery systems.
3.4 Aging Test and RUL Dataset Construction
To investigate the degradation characteristics of the electric vehicle battery under different discharge strategies, I designed two categories of aging experiments: rated current cycle aging and dynamic current cycle aging. For the rated current experiments, the battery underwent repeated charge-discharge cycles where charging was performed using the CC-CV protocol at 1A and discharging was conducted at 1C constant current. I recorded 210 consecutive cycles of aging data for this scenario. For the dynamic current experiments, I employed the FUDS dynamic profile as the discharge load to simulate real driving conditions, collecting 130 aging cycles.
In addition to my laboratory-generated dataset, I also utilized the publicly available NASA PCoE battery aging dataset to construct a differential validation framework. This resulted in two distinct datasets for my RUL prediction validation:
Dataset A: The NASA dataset contains full lifecycle data for 18650 lithium-ion batteries (B0005, B0006, B0007) subjected to standard charging (1.5A CC to 4.2V, then CV to 20mA) and discharging (2A CC to 2.75V) protocols. Each battery completed 168 aging cycles with the end-of-life threshold set to 80% of rated capacity (1.2Ah). My analysis of the capacity fade curves for these three batteries revealed a common pattern of slow initial degradation followed by accelerated decay in later cycles, accompanied by occasional capacity recovery and sudden drop phenomena.
Dataset B: This dataset comprises my laboratory-measured aging data from commercial 18650 ternary batteries. It includes 210 cycles of constant current discharge aging and 130 cycles of FUDS dynamic discharge aging. The differential nature of these two datasets enabled me to rigorously evaluate both the cross-individual generalization ability and the dynamic condition adaptability of my proposed RUL prediction framework.
4. SOC Estimation under Complex Operating Conditions
4.1 Baseline Model: ECM-UKF
The foundation of my SOC estimation framework is the equivalent circuit model (ECM) coupled with the Unscented Kalman Filter. I selected the second-order Thevenin equivalent circuit model for its ability to accurately characterize battery polarization effects and dynamic voltage responses while maintaining acceptable computational complexity. This model consists of an open-circuit voltage source (OCV), ohmic internal resistance \( R_0 \), and two RC networks that capture different time-constant polarization dynamics.
The voltage response of the model is given by:
$$ U_t = U_{OC}(SOC) – I R_0 – U_{RC1} – U_{RC2} \quad (7) $$
where \( U_t \) is the terminal voltage, \( U_{OC}(SOC) \) represents the open-circuit voltage as a nonlinear function of SOC, \( I \) is the discharge current, and \( U_{RC1} \) and \( U_{RC2} \) are the polarization voltages across the two RC branches. The dynamics of the RC branches are governed by:
$$ \dot{U}_{RC1} = -\frac{1}{R_1 C_1}U_{RC1} + \frac{1}{C_1}I \quad (8) $$
$$ \dot{U}_{RC2} = -\frac{1}{R_2 C_2}U_{RC2} + \frac{1}{C_2}I \quad (9) $$
I modeled the SOC dynamics based on charge conservation as:
$$ \dot{SOC} = -\frac{\eta I}{Q_n} \quad (10) $$
where \( \eta \) is the Coulombic efficiency and \( Q_n \) is the rated capacity. Combining these relations, I derived the continuous state-space representation:
$$ \dot{x} = f(x, u) + w \quad (11) $$
$$ y = h(x, u) + v \quad (12) $$
where the state vector is \( x = [SOC, U_{RC1}, U_{RC2}]^T \), input \( u = I \), output \( y = U_t \), and \( w \), \( v \) represent process and measurement noise, respectively.
After discretization, I derived the discrete state-space equations including the state transition matrix and observation matrix. The UKF algorithm was then applied for baseline SOC estimation. Unlike EKF, which requires Jacobian matrix computation, UKF employs the Unscented Transform (UT) to propagate a set of deterministically chosen sigma points through the nonlinear system. For an n-dimensional state \( x \), I used \( 2n+1 \) sigma points:
$$ \chi^0 = \hat{x}_k \quad (13) $$
$$ \chi^i = \hat{x}_k + (\sqrt{(n+\lambda)P_k})_i, \quad i=1,…,n \quad (14) $$
$$ \chi^{i+n} = \hat{x}_k – (\sqrt{(n+\lambda)P_k})_i, \quad i=1,…,n \quad (15) $$
These sigma points are propagated through the system dynamics, and the predicted state mean and covariance are computed via weighted sums. The measurement update follows the standard Kalman structure, with the Kalman gain calculated as:
$$ K_k = P_{xy}P_{yy}^{-1} \quad (16) $$
This baseline UKF estimation, referred to as G0 in my experiments, achieves an RMSE of 8.96% on the FUDS condition at 25°C. While this demonstrates the baseline model’s capability, my analysis identified significant room for improvement under dynamic conditions.
4.2 Adaptive DEKF for Time-Varying Noise
My investigation revealed that the UKF’s performance deteriorates significantly when noise statistics change, as frequently occurs in real electric vehicle battery operation due to temperature variations, load fluctuations, and battery aging. To address this limitation, I introduced the Time-Varying Noise Adaptive Dual Extended Kalman Filter (DEKF) as the first optimization branch in my framework.
The DEKF operates through two coupled estimation layers: a state estimation layer for SOC and polarization voltages, and a noise adaptation layer that continuously adjusts the process noise covariance \( Q_t \) and measurement noise covariance \( R_t \) based on innovation sequence statistics. The core updating equations are:
$$ Q_{t+1} = (1 – \gamma_Q)Q_t + \gamma_Q e_t e_t^T \quad (17) $$
$$ R_{t+1} = (1 – \gamma_R)R_t + \gamma_R (y_t – \hat{y}_{t|t-1})(y_t – \hat{y}_{t|t-1})^T \quad (18) $$
where \( \gamma_Q \) and \( \gamma_R \) are update weight coefficients, \( e_t \) represents the state prediction error, and \( y_t – \hat{y}_{t|t-1} \) is the innovation sequence. This dynamic adjustment mechanism enables the filter to adapt its gains in response to changing operating conditions, preventing error accumulation that occurs with fixed noise parameters.
The algorithmic procedure I implemented consists of the following steps: initialization of state estimation \( \hat{x}_0 \), covariance \( P_0 \), and initial noise matrices \( Q_0 \) and \( R_0 \); prediction of prior state and covariance through the system equations; computation of the innovation sequence from current measurements; adaptive adjustment of \( Q_t \) and \( R_t \); and re-computation of the Kalman gain for the final state update. In my experimental validation using FUDS data, this adaptive DEKF (referred to as G1) reduced the RMSE from 8.96% to 8.31%, demonstrating the effectiveness of noise adaptation.
4.3 MMAE for Multi-Model Robust Filtering
Despite the improvements achieved by DEKF, I recognized that a single adaptive filter may not provide sufficient robustness across all operating scenarios, particularly when facing abrupt condition changes or anomalous measurements. Therefore, I introduced the Multiple Model Adaptive Estimation (MMAE) approach as the second optimization branch. The core concept of MMAE is to run multiple parallel filters, each configured with different noise model assumptions, and dynamically fuse their outputs based on posterior probability weights.
Given a set of noise models \( M_i \) (\( i = 1, 2, \ldots, N \)), each filter produces its state estimate \( \hat{x}_i(k) \). The posterior probability weight for each model is updated as follows:
$$ \mu_i(k) = \frac{p(y_k | M_i) \mu_i(k-1)}{\sum_{j=1}^{N} p(y_k | M_j) \mu_j(k-1)} \quad (19) $$
The final fused estimate is computed as the weighted sum:
$$ \hat{x}(k) = \sum_{i=1}^{N} \mu_i(k) \hat{x}_i(k) \quad (20) $$
where the weights satisfy the constraint \( \sum_{i=1}^{N} \mu_i(k) = 1 \). In my implementation, each parallel filter employed the UKF framework with distinct process and measurement noise covariance matrices. The innovation sequence statistics were used to compute the Gaussian likelihood function for each model, allowing the weights to adapt dynamically to the current noise environment.
The MMAE filtering procedure (referred to as G2) yielded an RMSE of 7.98% on FUDS conditions at 25°C, slightly outperforming the DEKF. Notably, MMAE demonstrated better stability in tracking sudden changes, confirming its multi-model mechanism effectively handles model uncertainty and noise variability. The comparison between these two optimization branches is summarized in my subsequent analysis.
4.4 GRU Residual Correction Model
Despite the improvements achieved by DEKF and MMAE, my analysis demonstrated that both filtering methods retain inherent estimation errors due to the assumptions of Gaussian noise and simplified battery dynamics. To further suppress these residual errors, I introduced a deep residual correction layer based on Gated Recurrent Unit (GRU) networks. The GRU network architecture provides an excellent balance between modeling capability and computational efficiency, making it particularly suitable for real-time electric vehicle battery SOC estimation.
The GRU cell incorporates two essential gates: the update gate \( z_t \) and the reset gate \( r_t \). These gates control the flow of information through the network, addressing the vanishing gradient problem inherent in simple recurrent networks. The update gate determines how much of the previous hidden state should be retained:
$$ z_t = \sigma(W_z x_t + U_z h_{t-1} + b_z) \quad (21) $$
The reset gate controls the influence of the previous hidden state on the candidate state:
$$ r_t = \sigma(W_r x_t + U_r h_{t-1} + b_r) \quad (22) $$
The candidate hidden state is then computed as:
$$ \tilde{h}_t = \tanh(W_h x_t + U_h (r_t \odot h_{t-1}) + b_h) \quad (23) $$
Finally, the current hidden state is determined by:
$$ h_t = (1 – z_t) \odot h_{t-1} + z_t \odot \tilde{h}_t \quad (24) $$
In my SOC estimation framework, I constructed two GRU residual correction models: one for the DEKF branch (creating the G3 composite model) and one for the MMAE branch (creating the G4 composite model). The composite framework follows the formulation:
$$ SOC_{final}(t) = SOC_{filter}(t) + f_{GRU}(\mathbf{X}_t) \quad (25) $$
where \( SOC_{filter}(t) \) is the filtering output and \( f_{GRU}(\mathbf{X}_t) \) represents the GRU network’s nonlinear mapping. The input feature vector \( \mathbf{X}_t \) at each time step includes the terminal voltage, current, temperature, filtered SOC, voltage variation, current variation, and cycle index:
$$ \mathbf{X}_t = [V_t, I_t, T_t, SOC_{filter}(t), \Delta V_t, \Delta I_t, Cycle] \quad (26) $$
For training data construction, I used a sliding window approach with a window length of 10-20 time steps. The training target was defined as the difference between the reference SOC and the filter output:
$$ Target: SOC_{ref}(t) – SOC_{filter}(t) \quad (27) $$
The network was trained using the Adam optimizer with a learning rate of 1e-3, batch size of 64, and mean squared error as the loss function. Table 2 summarizes the training configuration for my GRU residual correction networks.
| Parameter | Value |
|---|---|
| Optimizer | Adam |
| Learning Rate | 1e-3 |
| Batch Size | 64 |
| Loss Function | Mean Squared Error |
| Training Epochs | 100 |
| Hidden Layer Units | 128 |
My experimental results on FUDS conditions at 25°C revealed a significant improvement after the GRU residual correction. The G3 model (DEKF-GRU) achieved an RMSE of 0.6745%, a dramatic improvement from the 8.31% RMSE of the DEKF alone. Interestingly, I observed that although MMAE (G2) slightly outperformed DEKF (G1) in the filtering stage, after GRU correction the DEKF-GRU (G3) outperformed MMAE-GRU (G4) with RMSE values of 0.6745% versus 0.9669%. My analysis suggests that DEKF produces smoother and more sequentially consistent residuals, which are more effectively learned by the GRU network, whereas MMAE’s residuals contain non-stationary structures due to model switching that reduce learning efficiency.
4.5 Evaluation Indicators and Comparative Analysis
To comprehensively evaluate the performance of my SOC estimation models, I employed four standard metrics: Root Mean Square Error (RMSE), Mean Absolute Error (MAE), Mean Absolute Percentage Error (MAPE), and the coefficient of determination (R²). These metrics are defined as follows:
$$ RMSE = \sqrt{\frac{1}{N}\sum_{i=1}^{N}(y_i – \hat{y}_i)^2} \quad (28) $$
$$ MAE = \frac{1}{N}\sum_{i=1}^{N}|y_i – \hat{y}_i| \quad (29) $$
$$ MAPE = \frac{100\%}{N}\sum_{i=1}^{N}\frac{|y_i – \hat{y}_i|}{y_i + \varepsilon} \quad (30) $$
$$ R^2 = 1 – \frac{\sum_{i=1}^{N}(y_i – \hat{y}_i)^2}{\sum_{i=1}^{N}(y_i – \bar{y})^2} \quad (31) $$
My comprehensive evaluation compared five model variants: G0 (ECM-UKF baseline), G1 (UKF-DEKF), G2 (UKF-MMAE), G3 (UKF-DEKF-GRU), and G4 (UKF-MMAE-GRU). The results for the four standard dynamic cycles at 25°C are presented in Table 3.
| Condition | Model | MAE (%) | RMSE (%) | MAPE (%) | R² |
|---|---|---|---|---|---|
| FUDS | G0 | 8.1324 | 8.9563 | 10.9645 | 0.9158 |
| G1 | 7.4854 | 8.3115 | 9.7632 | 0.9233 | |
| G2 | 7.1873 | 7.9774 | 10.5436 | 0.9393 | |
| G3 | 0.5996 | 0.6745 | 1.1634 | 0.9992 | |
| G4 | 0.8902 | 0.9669 | 1.3258 | 0.9989 | |
| DST | G0 | 5.9562 | 6.1258 | 15.8579 | 0.9567 |
| G1 | 5.1053 | 5.5840 | 15.4636 | 0.9642 | |
| G2 | 4.9039 | 5.3426 | 14.8736 | 0.9672 | |
| G3 | 0.2623 | 0.3753 | 1.3255 | 0.9998 | |
| G4 | 0.4676 | 0.4995 | 1.7894 | 0.9997 | |
| WLTP | G0 | 7.8542 | 8.2537 | 19.2458 | 0.9258 |
| G1 | 7.0540 | 7.5992 | 18.9424 | 0.9377 | |
| G2 | 7.0131 | 7.5515 | 18.7826 | 0.9385 | |
| G3 | 0.5107 | 0.5932 | 1.3207 | 0.9996 | |
| G4 | 0.5156 | 0.5655 | 1.3797 | 0.9996 | |
| US06 | G0 | 0.9847 | 1.5627 | 6.2573 | 0.9927 |
| G1 | 0.9567 | 1.2038 | 5.5188 | 0.9983 | |
| G2 | 0.9505 | 1.1887 | 4.7632 | 0.9983 | |
| G3 | 0.4540 | 0.6085 | 1.4351 | 0.9996 | |
| G4 | 0.4982 | 0.6263 | 2.5816 | 0.9995 |
The results clearly demonstrate the effectiveness of my proposed “filtering optimization + deep residual correction” strategy. The G3 and G4 models achieve remarkable accuracy improvements compared to the baseline G0 model. For instance, under FUDS conditions, G3 reduced the RMSE by 92.5% compared to G0, while G4 achieved a 89.2% reduction. The R² values consistently exceed 0.9990 for both corrected models across all operating conditions, indicating excellent fitting quality.
4.6 Multi-Condition and Multi-Temperature Validation
To comprehensively validate the environmental robustness of my proposed SOC estimation method, I extended my experimental verification to include multiple temperature conditions. My evaluation covered FUDS, DST, WLTP, and US06 cycles at both 0°C (low temperature) and 40°C (high temperature) scenarios, in addition to the standard 25°C condition. Table 4 presents the comprehensive estimation results.
| Condition | Model | Temperature | MAE (%) | RMSE (%) | R² |
|---|---|---|---|---|---|
| FUDS | G3 | 0°C | 0.5854 | 0.6571 | 0.9995 |
| 25°C | 0.5996 | 0.6745 | 0.9989 | ||
| 40°C | 0.5635 | 0.6475 | 0.9995 | ||
| G4 | 0°C | 0.8152 | 0.8673 | 0.9991 | |
| 25°C | 0.8902 | 0.9669 | 0.9989 | ||
| 40°C | 0.6864 | 0.7474 | 0.9993 | ||
| DST | G3 | 0°C | 0.3316 | 0.4770 | 0.9997 |
| 25°C | 0.2623 | 0.3753 | 0.9998 | ||
| 40°C | 0.3997 | 0.5474 | 0.9996 | ||
| G4 | 0°C | 0.4681 | 0.5054 | 0.9997 | |
| 25°C | 0.4676 | 0.4995 | 0.9997 | ||
| 40°C | 0.2585 | 0.2855 | 0.9998 | ||
| WLTP | G3 | 0°C | 0.1091 | 0.1575 | 0.9999 |
| 25°C | 0.5107 | 0.5932 | 0.9996 | ||
| 40°C | 0.5302 | 0.5951 | 0.9996 | ||
| G4 | 0°C | 0.0908 | 0.1151 | 0.9999 | |
| 25°C | 0.5156 | 0.5655 | 0.9996 | ||
| 40°C | 0.5302 | 0.5951 | 0.9996 | ||
| US06 | G3 | 0°C | 0.2932 | 0.3549 | 0.9998 |
| 25°C | 0.4540 | 0.6085 | 0.9996 | ||
| 40°C | 0.5033 | 0.6664 | 0.9995 | ||
| G4 | 0°C | 0.3193 | 0.3630 | 0.9998 | |
| 25°C | 0.4982 | 0.6263 | 0.9995 | ||
| 40°C | 0.4893 | 0.6239 | 0.9995 |
The results across all 24 combined condition-temperature scenarios demonstrate exceptional estimation performance. The RMSE values consistently remain below 1%, with R² values exceeding 0.9990 for all configurations. Noteworthy observations include the excellent performance at low temperatures, where the G3 model achieves an RMSE of 0.1575% under WLTP conditions at 0°C. I attribute this to the GRU network’s ability to learn residual patterns associated with increased battery internal resistance and reduced electrochemical kinetics at low temperatures. Similarly, at high temperatures of 40°C, where capacity fade and polarization effects are more pronounced, my model maintains RMSE values well below 0.7%. These findings confirm the excellent environmental adaptability of my proposed framework, which is essential for practical electric vehicle battery deployment across diverse climatic regions.
4.7 Benchmark Comparison
To further substantiate the superiority of my proposed method, I compared the best-performing SOC estimation results with several state-of-the-art methods reported in the literature. My comparison includes PSO-CNN-LSTM, IMOA-TCN-LSTM, IAFFRLS-AUKF, SVDUKF-EKF, and LSTM-Transformer methods. The comparison was conducted under DST conditions at 25°C, and the results are summarized in Table 5.
| Model | MAE (%) | RMSE (%) |
|---|---|---|
| G3 (My Proposed Method) | 0.2623 | 0.3753 |
| G4 (My Proposed Method) | 0.4676 | 0.4995 |
| PSO-CNN-LSTM | 0.52 | 0.73 |
| IMOA-TCN-LSTM | 0.613 | 0.698 |
| IAFFRLS-AUKF | 0.5144 | 0.6152 |
| SVDUKF-EKF | 0.87 | 0.99 |
| LSTM-Transformer | 0.49 | 0.58 |
The comparison clearly demonstrates that both of my proposed models achieve superior performance over the existing methods. The G3 model attains the lowest MAE and RMSE values among all compared methods, with improvements of 46.5% and 35.8% respectively over the best existing method. This comprehensive evaluation provides strong evidence for the practical superiority of my “filtering optimization + deep residual correction” framework in complex dynamic SOC estimation for electric vehicle battery systems.
5. RUL Prediction under Dynamic Operating Conditions
5.1 Degradation Feature Construction and Correlation Analysis
Accurate RUL prediction for an electric vehicle battery requires effective extraction of degradation features that comprehensively characterize the aging process. In my research, I identified a critical limitation in existing methods: many rely on a single health indicator, which fails to capture the multi-faceted nature of battery degradation. To address this gap, I developed a feature extraction methodology that considers both local dynamic response characteristics and global statistical accumulation characteristics of the discharge process.
From the local dynamic response dimension, I extracted two health indicators: HI1, representing the voltage variation from 3.8V to 1000 seconds, which captures the aging-induced voltage decay trend; and HI2, representing the voltage drop time from 3.6V to 3.2V, which directly characterizes the capacity fade rate. From the global statistical accumulation dimension, I extracted three additional indicators: HI3, the integrated discharge capacity, which directly reflects the capacity degradation trend; HI4, the average discharge voltage, which reflects the voltage platform evolution and reaction consistency; and HI5, the integrated discharge energy, which represents the energy output capability decline. Table 6 summarizes these degradation features and their physical meanings.
| Feature | Name | Physical Meaning |
|---|---|---|
| HI1 | Voltage variation from 3.8V to 1000s | Voltage value change trend during aging |
| HI2 | Voltage drop time from 3.6V to 3.2V | Represents the rate of capacity decline |
| HI3 | Integrated discharge capacity | Directly reflects the capacity degradation trend |
| HI4 | Average discharge voltage | Reflects voltage platform changes and reaction consistency |
| HI5 | Integrated discharge energy | Represents the energy output capability decline |
To quantitatively evaluate the relationship between these degradation features and RUL, I employed Spearman’s rank correlation coefficient, which is capable of capturing nonlinear yet monotonic associations:
$$ \rho_{Spearman} = \frac{\sum_{i=1}^{n}(P_i – \bar{P})(Q_i – \bar{Q})}{\sqrt{\sum_{i=1}^{n}(P_i – \bar{P})^2}\sqrt{\sum_{i=1}^{n}(Q_i – \bar{Q})^2}} \quad (32) $$
where P and Q represent the ranked variables for the two compared data sequences. The correlation results for the three batteries in Dataset A are presented in Table 7.
| HIs | B0005 | B0006 | B0007 |
|---|---|---|---|
| HI1 | 0.9927 | 0.9955 | 0.9971 |
| HI2 | 0.9904 | 0.9982 | 0.9941 |
| HI3 | 0.9994 | 0.9967 | 0.9950 |
| HI4 | 0.9746 | 0.9992 | 0.9982 |
| HI5 | 0.9932 | 0.9983 | 0.9543 |
All five degradation features exhibit extremely strong monotonic correlations with RUL, with coefficients generally exceeding 0.95. This confirms that my selected features effectively capture different facets of the battery degradation process. The complementary nature of these features provides a comprehensive representation of electric vehicle battery health state evolution.
5.2 Integrated Health Indicator via KPCA
Given the high-dimensional nature and nonlinear coupling among the extracted degradation features, I applied Kernel Principal Component Analysis (KPCA) to perform feature fusion and dimensionality reduction. KPCA extends traditional PCA by mapping the original feature space to a high-dimensional feature space through kernel functions, thereby capturing nonlinear structures within the data. For input samples \( \mathbf{x}_i \) and \( \mathbf{x}_j \), the kernel function computes their inner product in the high-dimensional space:
$$ K(\mathbf{x}_i, \mathbf{x}_j) = \langle \Phi(\mathbf{x}_i), \Phi(\mathbf{x}_j) \rangle \quad (33) $$
where \( \Phi(\cdot) \) is the nonlinear mapping function. Based on the kernel matrix, I performed eigen-decomposition to obtain the principal components ranked by variance contribution. I selected the first principal component, which accounted for nearly 100% of the total variance in my experiments, to construct the Integrative Health Indicator (IHI). This approach preserves the essential nonlinear degradation information while achieving effective dimensionality reduction.
Table 8 presents the Spearman correlation coefficients between the constructed IHI and RUL for the three NASA batteries.
| Battery | Spearman Correlation Coefficient |
|---|---|
| B0005 | 0.9927 |
| B0006 | 0.9854 |
| B0007 | 0.9946 |
The IHI evolution curves track the RUL degradation trends with remarkable consistency, accurately reproducing both the overall decline pattern and local fluctuation phenomena. The strong correlation values exceeding 0.985 confirm that IHI serves as a reliable quantitative indicator for characterizing battery health state, effectively integrating the complementary degradation information from multiple dimensions.
5.3 Multi-Scale Decomposition via VMD
Battery aging data often exhibit localized capacity recovery and sudden drop phenomena that can interfere with RUL prediction accuracy. To address this challenge, I applied Variational Mode Decomposition (VMD) to decompose the IHI signal into multiple intrinsic mode functions (IMFs) with distinct frequency characteristics. The VMD algorithm formulates signal decomposition as a constrained variational problem:
$$ \min_{\{u_k\},\{\omega_k\}} \left\{ \sum_{k=1}^{K} \left\| \partial_t \left[ \left( \delta(t) + \frac{j}{\pi t} \right) \ast u_k(t) \right] e^{-j\omega_k t} \right\|_2^2 \right\} \quad (34) $$
subject to the constraint:
$$ \sum_{k=1}^{K} u_k(t) = f(t) \quad (35) $$
where \( u_k(t) \) is the k-th modal component, \( \omega_k \) is its center frequency, \( \delta(t) \) is the Dirac delta function, and \( \ast \) denotes convolution. To solve this optimization problem, I introduced the quadratic penalty term \( \alpha \) and Lagrange multiplier \( \lambda \), yielding the updated modal components:
$$ \hat{u}_k^{n+1}(\omega) = \frac{\hat{f}(\omega) – \sum_{i\neq k} \hat{u}_i(\omega) + \frac{\hat{\lambda}(\omega)}{2}}{1 + 2\alpha(\omega – \omega_k)^2} \quad (36) $$
and the updated center frequencies:
$$ \omega_k^{n+1} = \frac{\int_0^{\infty} \omega |\hat{u}_k(\omega)|^2 d\omega}{\int_0^{\infty} |\hat{u}_k(\omega)|^2 d\omega} \quad (37) $$
In my implementation, I set the penalty factor \( \alpha \) to 2000, the number of modes K to 3, and the convergence threshold to 1e-6. The VMD decomposition separated the IHI signal into three components with distinct physical interpretations: IMF1 captures the global degradation trend with smooth, monotonic characteristics; IMF2 represents local capacity recovery and short-term fluctuation patterns; IMF3 contains high-frequency random perturbation components treatable as noise.
My correlation analysis of the decomposed components with RUL, as presented in Table 9, confirmed IMF1 exhibits exceptionally strong correlation while the other components show negligible correlation.
| Battery | Signal Component | Spearman Correlation |
|---|---|---|
| B0005 | IMF1 | 0.9985 |
| IMF2 | 0.0486 | |
| IMF3 | 0.0642 | |
| B0006 | IMF1 | 0.9846 |
| IMF2 | 0.0875 | |
| IMF3 | 0.0468 | |
| B0007 | IMF1 | 0.9962 |
| IMF2 | 0.0532 | |
| IMF3 | 0.0463 |
These results confirm that IMF1 effectively preserves the global degradation trend information while filtering out local fluctuations and noise. I therefore selected IMF1 as the input to my prediction model.
5.4 Dropout-BiLSTM-Attention Prediction Model
I constructed a hybrid deep learning model, designated as Dropout-BiLSTM-Attention (D-BiLSTM-A), to perform RUL prediction on the IMF1 component. This model synergistically integrates three architectural components, each addressing specific modeling requirements.
BiLSTM Layer: I employed a bidirectional Long Short-Term Memory network to capture temporal dependencies from both forward and backward directions. Each LSTM cell within the BiLSTM architecture contains input, forget, and output gates, governed by:
Input gate:
$$ i_t = \sigma(W_i [h_{t-1}, x_t] + b_i) \quad (38) $$
$$ \tilde{C}_t = \tanh(W_C [h_{t-1}, x_t] + b_C) \quad (39) $$
Forget gate:
$$ f_t = \sigma(W_f [h_{t-1}, x_t] + b_f) \quad (40) $$
Cell state update:
$$ C_t = f_t \odot C_{t-1} + i_t \odot \tilde{C}_t \quad (41) $$
Output gate:
$$ o_t = \sigma(W_o [h_{t-1}, x_t] + b_o) \quad (42) $$
$$ h_t = o_t \odot \tanh(C_t) \quad (43) $$
The BiLSTM structure combines forward and backward hidden states:
$$ h_t^{BiLSTM} = [h_t^{forward}, h_t^{backward}] \quad (44) $$
This bidirectional architecture enables the model to access both past and future context information, providing a more comprehensive understanding of the degradation sequence evolution.
Dropout Layer: To mitigate overfitting, particularly important when training with limited battery aging data, I inserted a Dropout layer that randomly deactivates a fraction of neurons during each training iteration. For each neuron, a Bernoulli random variable with probability \( p \) controls the dropout:
$$ z \sim Bernoulli(1-p) \quad (45) $$
$$ y = x \odot z \quad (46) $$
At test time, all neurons are retained with outputs scaled by \( 1/(1-p) \). My experiments confirmed that Dropout regularization significantly enhances the generalization capability of the model across different battery cells and operating conditions.
Attention Mechanism: Given that different time steps in the degradation sequence contribute unequally to the RUL prediction, I incorporated an attention mechanism that dynamically assigns weights to different time steps based on their relevance. The attention scores are computed as:
$$ e_{ij} = \frac{Q_i \cdot K_j}{\sqrt{d_k}} \quad (47) $$
The corresponding attention weights are obtained through Softmax normalization:
$$ \alpha_{ij} = Softmax(e_{ij}) = \frac{\exp(e_{ij})}{\sum_{k=1}^{n}\exp(e_{ik})} \quad (48) $$
The final context vector is the weighted sum:
$$ C_i = \sum_{j=1}^{n}\alpha_{ij} V_j \quad (49) $$
This attention-enhanced architecture enables the model to focus on critical degradation phases, such as the accelerated decay region near end-of-life, thereby improving prediction accuracy for the electric vehicle battery degradation trajectory.
5.5 Experimental Results and Comparative Analysis
For my RUL prediction validation, I first used Dataset A with the NASA batteries B0005, B0006, and B0007. I divided each battery’s aging cycles into a training set (first 30%) and a test set (remaining 70%). I designed ablation experiments comparing three model configurations: M1 (BiLSTM), M2 (BiLSTM-Attention), and M3 (Dropout-BiLSTM-Attention, i.e., my proposed D-BiLSTM-A model). Table 10 presents the prediction errors across the three models.
| Battery | Model | MAE (%) | RMSE (%) | R² |
|---|---|---|---|---|
| B0005 | M1 | 1.97 | 2.34 | 0.9286 |
| M2 | 1.79 | 2.04 | 0.9449 | |
| M3 | 1.58 | 1.65 | 0.9815 | |
| B0006 | M1 | 1.63 | 1.97 | 0.9642 |
| M2 | 1.16 | 1.74 | 0.9837 | |
| M3 | 0.97 | 1.26 | 0.9935 | |
| B0007 | M1 | 1.86 | 2.24 | 0.9398 |
| M2 | 1.62 | 1.84 | 0.9636 | |
| M3 | 1.10 | 1.62 | 0.9865 |
My results consistently demonstrate the superiority of the M3 model. Compared to M1, the M3 model achieves an average RMSE reduction of 30.1% and an average R² improvement of 0.05 across all three batteries. Compared to M2, the average RMSE reduction is 18.1%, and the average R² improvement is 0.03. These improvements confirm that the Dropout regularization effectively suppresses overfitting, while the Attention mechanism strengthens the model’s focus on critical degradation features, collectively enhancing RUL prediction accuracy for the electric vehicle battery.
5.6 RUL Prediction on Dataset B
To rigorously validate the generalization capability and condition adaptability of my proposed prediction framework, I further evaluated the D-BiLSTM-A model using my experimentally constructed Dataset B. This dataset includes two charging-discharging scenarios: rated current discharge and FUDS dynamic discharge.
Rated Current Discharge Condition: Using the 210-cycle aging data from constant current discharge experiments, I applied the same training-test division strategy (30% training, 70% testing). Table 11 presents the comparison results among the three models.
| Model | MAE (%) | RMSE (%) | R² |
|---|---|---|---|
| M1 | 2.16 | 3.87 | 0.9128 |
| M2 | 1.68 | 2.03 | 0.9763 |
| M3 | 0.56 | 1.03 | 0.9954 |
The M3 model achieves an RMSE of only 1.03% and a MAE of 0.56%, with R² reaching 0.9954. My model precisely captures the “slow early decline, rapid late decline” degradation pattern, including the significant capacity drop phenomenon observed around cycles 180-200.
FUDS Dynamic Discharge Condition: To validate the model under complex dynamic conditions, I utilized the 130-cycle aging data from FUDS discharge experiments. Table 12 presents the comparison results.
| Model | MAE (%) | RMSE (%) | R² |
|---|---|---|---|
| M1 | 4.92 | 6.61 | 0.8928 |
| M2 | 2.34 | 3.04 | 0.9773 |
| M3 | 1.28 | 1.56 | 0.9905 |
Even under the FUDS dynamic condition with pronounced current fluctuations and non-stationary signals, the M3 model maintains an RMSE of 1.56% and R² of 0.9905. Compared to M1, this represents a 76.4% reduction in RMSE; compared to M2, a 48.7% reduction. The model demonstrates strong adaptability to complex load variations without significant error accumulation or trend deviation. Table 13 provides a comprehensive summary of my model’s performance across all evaluated conditions.
| Battery Type | Condition | MAE (%) | RMSE (%) | R² |
|---|---|---|---|---|
| Ternary 18650 | Rated Current Discharge | 0.56 | 1.03 | 0.9954 |
| Ternary 18650 | FUDS Dynamic Condition | 1.28 | 1.56 | 0.9905 |
| B0005 | Public Dataset A | 1.58 | 1.65 | 0.9815 |
| B0006 | Public Dataset A | 0.97 | 1.26 | 0.9935 |
| B0007 | Public Dataset A | 1.10 | 1.62 | 0.9865 |
My comprehensive validation across three distinct condition categories — steady rated conditions, dynamic complex conditions, and cross-individual public conditions — consistently confirms the high accuracy and robust generalization capability of my proposed D-BiLSTM-A model. The framework effectively adapts to varying operating scenarios, individual battery differences, and divergent aging rates, demonstrating its practical value for electric vehicle battery health management.
6. Conclusion and Future Perspectives
In this thesis, I conducted systematic research on state-of-charge estimation and remaining useful life prediction for electric vehicle battery systems under dynamic operating conditions. My research addressed two fundamental challenges: the accuracy degradation of SOC estimation in complex real-world scenarios, and the insufficient generalization of RUL prediction methods across varying operating conditions.
For SOC estimation, I constructed a comprehensive experimental platform and designed multi-condition and multi-temperature experiments incorporating FUDS, DST, WLTP, and US06 driving cycles at 0°C, 25°C, and 40°C. My proposed SOC estimation framework integrates a model-driven filtering baseline with deep residual correction. Specifically, I implemented a three-tier architecture consisting of an ECM-UKF baseline estimation layer, dual filtering optimization branches based on adaptive DEKF and MMAE, and GRU-based deep residual correction. Through comprehensive experiments across 24 combined condition-temperature scenarios, my method consistently achieved R² values exceeding 0.9990 and RMSE values below 1%. The dual-branch design provides complementary advantages: DEKF-GRU demonstrates superior overall precision with smoother residuals suitable for GRU learning, while MMAE-GRU offers excellent multi-model adaptation capability. This hybrid framework significantly outperforms conventional filtering methods and pure deep learning approaches, offering a high-precision and robust solution for SOC estimation in practical electric vehicle battery operation.
For RUL prediction, I developed a comprehensive methodology combining multi-dimensional feature integration, multi-scale decomposition, and attention-enhanced deep learning. I extracted five degradation features spanning local dynamic responses and global statistical accumulations, and validated their strong correlations with RUL through Spearman correlation analysis. The KPCA-based feature fusion effectively constructed an integrated health indicator that comprehensively characterizes battery aging. VMD decomposition successfully separated the global degradation trend from local fluctuations and noise, enabling the model to focus on the dominant degradation signal. My proposed D-BiLSTM-A model achieves exceptional prediction performance across multiple datasets: on the NASA public dataset, RMSE consistently remains around 1.5%; on my own laboratory dataset under rated discharge conditions, RMSE reaches 1.03% with R² of 0.9954; and under FUDS dynamic conditions, RMSE maintains 1.56% with R² of 0.9905. The ablation experiments confirmed that the Attention mechanism’s critical feature focusing capability and Dropout’s overfitting suppression both contribute significantly to the overall prediction improvement.
Despite the significant advances achieved, several directions warrant further investigation. In terms of data coverage, my current research is primarily based on laboratory cycling data with limited condition diversity. Future studies could incorporate more realistic operating data from actual electric vehicle battery deployment, including varied charging protocols, wider temperature ranges, and battery pack-level operation. This would further validate and refine the models for real-world application. In the modeling dimension, my current approaches are primarily offline-trained. Future work could incorporate online learning or incremental updating mechanisms, enabling the model to adaptively adjust to evolving battery characteristics over long-term operation. This would enhance prediction stability and reliability in continuous service scenarios. Additionally, from an engineering perspective, the computational efficiency and real-time performance of the proposed algorithms need to be optimized for deployment on embedded BMS platforms. Model compression techniques and hardware-aware optimization could facilitate practical implementation. The integration of edge computing and cloud-based battery analytics could also provide new opportunities for enhanced battery health monitoring and lifecycle management of electric vehicle battery systems.