
1. Introduction
In the context of global energy transformation, the shift from traditional fossil fuels to green energy sources has become an inevitable trend driven by climate change concerns and the depletion of non-renewable resources. Electric vehicles, which utilize electric energy as their primary power source, have emerged as a pivotal solution to reduce greenhouse gas emissions and decrease dependence on petroleum. The electric vehicle battery serves as the fundamental energy storage unit in these vehicles, and its performance directly determines the driving range, safety, and overall efficiency of the vehicle.
Among all the parameters that characterize an electric vehicle battery, the State of Charge (SOC) is arguably the most critical indicator within the Battery Management System (BMS). The SOC represents the ratio of the remaining capacity to the maximum available capacity of the battery, typically expressed as a percentage. Accurate SOC estimation is essential for multiple reasons: it ensures safe battery operation by preventing over-charge and over-discharge, optimizes battery usage efficiency, extends the battery’s service life, and prevents hazardous situations such as thermal runaway and electrolyte leakage that can arise from improper charging and discharging.
However, SOC is an internal state variable that cannot be directly measured through physical sensors. It must be inferred from measurable quantities such as terminal voltage, current, and temperature through sophisticated estimation algorithms. The challenge is compounded by the fact that in real-world operating conditions, the noise characteristics of the electric vehicle battery system are often unknown but bounded, rather than following ideal Gaussian distributions. This observation has motivated the application of set-membership filtering approaches, which are inherently designed to handle bounded uncertainty descriptions.
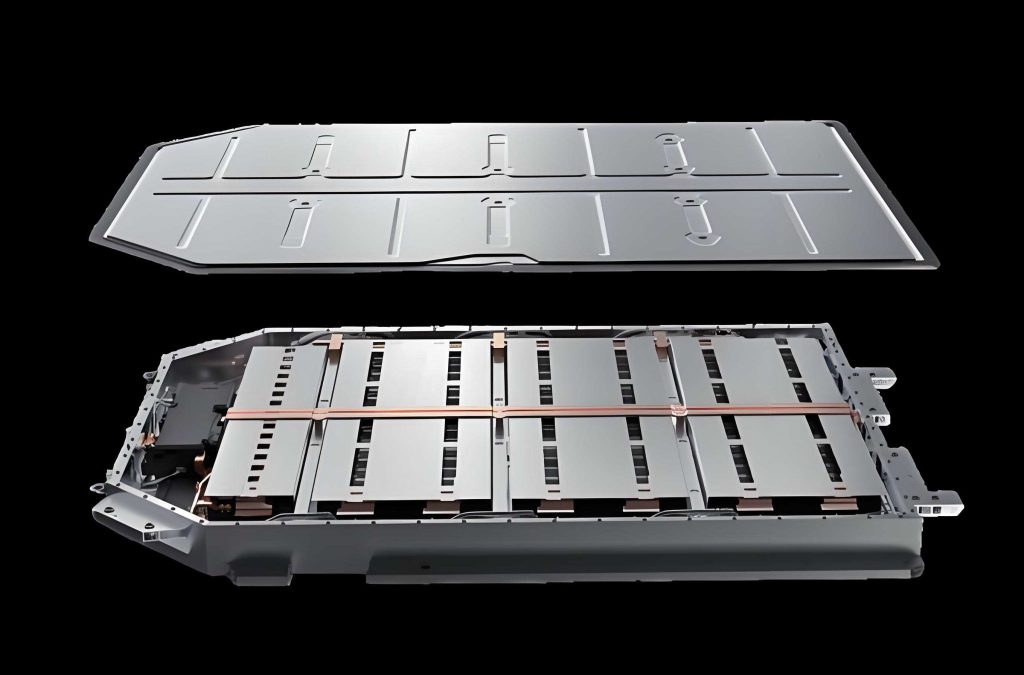
The primary objective of this research is to develop advanced filtering algorithms that can provide accurate and reliable SOC estimation for electric vehicle batteries under unknown-but-bounded noise conditions. I focus on parallelotope-based set-membership methods and their integration with particle filtering techniques to enhance estimation accuracy while maintaining computational feasibility.
2. Literature Review
2.1 SOC Estimation Methods for Electric Vehicle Battery
Several approaches have been developed for SOC estimation of electric vehicle batteries, each with distinct advantages and limitations:
| Method | Advantages | Limitations |
|---|---|---|
| Ampere-hour integration | Simple implementation, low computational cost | Susceptible to cumulative errors, requires accurate initial SOC |
| Open-circuit voltage method | High accuracy for offline calibration | Requires long rest periods, unsuitable for real-time estimation |
| Electrochemical impedance spectroscopy | Detailed internal state information | Expensive equipment, not suitable for online monitoring |
| Model-based Kalman filtering | Good accuracy under Gaussian noise | Degrades when noise is non-Gaussian |
| Particle filtering | Handles nonlinear/non-Gaussian systems | Computational complexity, particle degeneracy |
| Set-membership filtering | Appropriate for bounded noise | Conservative results with simple shapes |
2.2 Battery Equivalent Circuit Models
Equivalent circuit models provide a practical compromise between accuracy and computational complexity for electric vehicle battery SOC estimation. The most common configurations include:
- Rint model: Simplest model containing only an ideal voltage source and internal resistance, inadequate for capturing dynamic behavior.
- Thevenin model (first-order RC): Adds one RC parallel network to model polarization effects, providing good accuracy for normal operating conditions.
- Second-order RC model: Incorporates two RC networks to separately model electrochemical polarization and concentration polarization, offering improved accuracy at higher computational cost.
- PNGV model: Extends the first-order RC model with a storage capacitor to capture open-circuit voltage variations over time.
- Neural network models: Data-driven approaches requiring substantial training data and computational resources.
After careful consideration, I selected the first-order RC equivalent circuit model for this research, as it offers an optimal balance between modeling fidelity and parameter identification tractability for electric vehicle battery SOC estimation.
3. First-Order RC Equivalent Circuit Model
3.1 Model Formulation
The first-order RC equivalent circuit model discretized state-space representation is given by:
$$
\begin{cases}
U_k = U_{oc,k} – U_{p,k} – I_k \times R_0, \\
U_{p,k+1} = e^{-\frac{\Delta t}{R_p C_p}} U_{p,k} + \left(1 – e^{-\frac{\Delta t}{R_p C_p}}\right) R_p \times I_k,
\end{cases}
\tag{3.1}
$$
where $U_{oc,k}$ is the open-circuit voltage, $U_k$ is the terminal voltage, $R_0$ is the ohmic internal resistance, $R_p$ and $C_p$ are the polarization resistance and capacitance, $U_p$ is the voltage across the RC network, $I_k$ is the current, and $\Delta t$ is the sampling period.
Combining the ampere-hour integration method for SOC calculation:
$$
SOC(t) = SOC(0) – \frac{\eta}{Q} \int_{0}^{t} I(t)dt,
\tag{3.2}
$$
where $Q$ is the rated capacity and $\eta$ is the coulombic efficiency. Discretizing this equation yields:
$$
SOC_{k+1} = SOC_k – \frac{\eta \Delta t}{Q} \times I_k.
\tag{3.3}
$$
Defining the state vector as $x_k = [U_{p,k}, SOC_k]^T$ and the measurement as the terminal voltage $U_k$, I obtain the complete state-space model:
$$
\begin{cases}
\begin{bmatrix} U_{p,k+1} \\ SOC_{k+1} \end{bmatrix} = \begin{bmatrix} e^{-\frac{\Delta t}{\tau_p}} & 0 \\ 0 & 1 \end{bmatrix} \begin{bmatrix} U_{p,k} \\ SOC_k \end{bmatrix} + \begin{bmatrix} \left(1 – e^{-\frac{\Delta t}{\tau_p}}\right) R_p \\ -\frac{\eta \Delta t}{Q} \end{bmatrix} I_k + w_k, \\
U_k = f(SOC_k) – U_{p,k} – I_k R_0 + v_k,
\end{cases}
\tag{3.4}
$$
where $f(SOC_k)$ represents the nonlinear OCV-SOC relationship, $w_k$ is the process noise, and $v_k$ is the measurement noise.
3.2 Parameter Determination
I conducted experiments using a 18650-type lithium-ion battery cell with parameters listed below:
| Parameter | Value |
|---|---|
| Battery type | graphite-LiCoO2 |
| Rated voltage | 3.7 V |
| Rated capacity | 1.5 Ah |
| Upper/lower cutoff voltage | 4.2 V / 1.75 V |
| Test temperature | 25 ± 2 °C |
Using the battery rest method, I discharged the battery from full charge using a constant current of 1/2C rate. After each discharge interval corresponding to a 10% SOC reduction, the battery was allowed to rest for one hour to reach equilibrium before recording the terminal voltage, which equals the OCV. The measured OCV-SOC relationship is presented in the following table:
| SOC (%) | 0 | 10 | 20 | 30 | 40 | 50 | 60 | 70 | 80 | 90 | 100 |
|---|---|---|---|---|---|---|---|---|---|---|---|
| OCV (V) | 2.78 | 3.63 | 3.71 | 3.76 | 3.79 | 3.83 | 3.87 | 3.94 | 4.01 | 4.09 | 4.19 |
The identified model parameters obtained through recursive least squares are:
| Temperature (°C) | $R_0$ (Ω) | $R_p$ (Ω) | $C_p$ (F) |
|---|---|---|---|
| 25 | 0.0415 | 0.03068 | 2372.2 |
For the linear model, I fitted a first-order polynomial to the OCV-SOC data:
$$
OCV = f(SOC) \approx k_{SOC-OCV} \cdot SOC + b_{SOC-OCV} = 0.5293 \times SOC + 3.5821.
\tag{3.5}
$$
For the nonlinear model, I employed a cubic polynomial to better capture the nonlinear relationship:
$$
OCV = f(SOC) \approx 5.83 \times SOC^3 – 9.27 \times SOC^2 + 5.2 \times SOC + 2.943.
\tag{3.6}
$$
4. Particle Swarm Optimization-Based Orthogonal Parallelotope Filtering
4.1 Problem Formulation
For the linearized electric vehicle battery system, the state-space model can be written as:
$$
\begin{cases}
x_{k+1} = A x_k + B u_k + w_k, \\
y_k = C x_k + v_k,
\end{cases}
\tag{4.1}
$$
where $A = \begin{bmatrix} e^{-\Delta t/\tau_p} & 0 \\ 0 & 1 \end{bmatrix}$, $B = \begin{bmatrix} (1-e^{-\Delta t/\tau_p})R_p \\ -\eta\Delta t/Q \end{bmatrix}$, and $C = [-1, k_{SOC-OCV}]$.
The process noise $w_k$ and measurement noise $v_k$ are assumed to be unknown but bounded, with the following constraints: $w_{k,i} \in [-0.001, 0.001]$ for $i = 1,2$, and $v_k \in [-0.001, 0.001]$.
4.2 Parallelotope Set-Membership Filtering
A parallelotope in $n$-dimensional space can be defined as the intersection of $n$ non-parallel strip spaces:
$$
\mathbb{P} = \bigcap_{i=1}^{n} S(p_i, c_i) = \{\theta : \|P(\theta – \theta_c)\|_{\infty} \leq 1\},
\tag{4.2}
$$
where $P = [p_1, \cdots, p_n]^T$ is the shape matrix and $\theta_c = P^{-1}[c_1, \cdots, c_n]^T$ is the center. Alternatively, using the generator matrix $T = P^{-1}$, the parallelotope can be expressed as:
$$
\mathbb{P}(\theta_c, T) = \{\theta : \theta = \theta_c + T\alpha, \|\alpha\|_{\infty} \leq 1\}.
\tag{4.3}
$$
For the prediction step of the electric vehicle battery SOC estimation, given the parallelotope $\mathbb{P}(\theta_{c,k}, T_k)$ at time $k$, the predicted parallelotope at time $k+1$ is computed as:
$$
\hat{\theta}_{c,k+1} = A\theta_{c,k} + B u_k,
\tag{4.4}
$$
$$
\hat{T}_{k+1} = A T_k.
\tag{4.5}
$$
The measurement set that constrains the prediction is obtained from the measured voltage:
$$
S_{k+1} = \{\theta : |y_{k+1} – C\theta| \leq V\},
\tag{4.6}
$$
where $V = \text{diag}\{r_{v,1}, \cdots, r_{v,n_y}\}$ is the measurement noise bound matrix. Using the recursive optimal parallelotope outbounding algorithm, I compute the minimum-volume parallelotope that encloses the intersection of the predicted parallelotope and the measurement strip. For the single-output electric vehicle battery system, this yields the updated parallelotope $\mathbb{P}(\theta_{c,k+1}, T_{k+1})$ containing the true SOC state.
4.3 Construction of Orthogonal Parallelotope Search Space
The traditional parallelotope filtering approach often yields conservative estimation bounds. To improve the estimation accuracy for the electric vehicle battery SOC, I introduce particle swarm optimization to contract the estimation space. However, the complex geometry of a general parallelotope makes it difficult to directly define particle position bounds. I address this challenge through the following theorem:
Theorem 4.1: Given a parallelotope $\mathbb{P}(\theta_{c,k+1}, T_{k+1})$, there exists an orthogonal parallelotope $\mathbb{P}(\hat{\theta}^o_{c,k+1}, \hat{T}^o_{k+1})$ with identical boundary values in each dimension, constructed as:
$$
\hat{\theta}^o_{c,k+1} = \begin{bmatrix} \frac{\mu^{max}_{1,k+1}+\mu^{min}_{1,k+1}}{2} \\ \frac{\mu^{max}_{2,k+1}+\mu^{min}_{2,k+1}}{2} \\ \vdots \\ \frac{\mu^{max}_{n_x,k+1}+\mu^{min}_{n_x,k+1}}{2} \end{bmatrix},
\tag{4.7}
$$
$$
\hat{T}^o_{k+1} = \text{diag}\left\{\frac{\mu^{max}_{1,k+1}-\mu^{min}_{1,k+1}}{2}, \frac{\mu^{max}_{2,k+1}-\mu^{min}_{2,k+1}}{2}, \cdots, \frac{\mu^{max}_{n_x,k+1}-\mu^{min}_{n_x,k+1}}{2}\right\},
\tag{4.8}
$$
where $\mu^{max}_{d,k+1}$ and $\mu^{min}_{d,k+1}$ are the upper and lower bounds of $\mathbb{P}(\theta_{c,k+1}, T_{k+1})$ in the $d$-th dimension.
Proof: The vertices of the parallelotope $\mathbb{P}(\theta_{c,k+1}, T_{k+1})$ can be computed as $z_{i_z} = \theta_c + \sum_{i_p=1}^{n_x} t_{i_p}\alpha_{i_p}$, where $\alpha_{i_p} \in \{-1, 1\}$. Collecting all vertices into the matrix $Z_{k+1} \in \mathbb{R}^{n_x \times 2^{n_x}}$, I obtain the dimension-wise bounds:
$$
\begin{cases}
\mu^{max}_{d,k+1} = \max(Z_{k+1}(d, i_z)), \\
\mu^{min}_{d,k+1} = \min(Z_{k+1}(d, i_z)).
\end{cases}
\tag{4.9}
$$
For the constructed orthogonal parallelotope, the vertices are:
$$
z^o_{i_z} = \hat{\theta}^o_{c,k+1} + \sum_{i_p=1}^{n_x} t^o_{i_p}\alpha_{i_p},
\tag{4.10}
$$
which yields the same dimension-wise bounds as the original parallelotope. $\square$
This orthogonal parallelotope serves as the particle search space where each particle’s coordinate components have clear intervals per dimension:
$$
\mu^{min}_{d,k+1} \leq x_{i,d} \leq \mu^{max}_{d,k+1}.
\tag{4.11}
$$
4.4 Particle Swarm Optimization for Space Contraction
The particle swarm optimization algorithm updates particle velocities and positions according to:
$$
V^{l+1}_{i,k+1} = \omega V^l_{i,k+1} + c_1 r_1 (P^l_{best,k+1} – X^l_{i,k+1}) + c_2 r_2 (G^l_{best,k+1} – X^l_{i,k+1}),
\tag{4.12}
$$
$$
X^{l+1}_{i,k+1} = X^l_{i,k+1} + V^l_{i,k+1},
\tag{4.13}
$$
where $\omega$ is the inertia weight, $c_1$ and $c_2$ are learning factors (typically $c_1 = c_2 = 2$), and $r_1, r_2$ are random numbers in $[0, 1]$. The fitness function used to evaluate particle quality is based on the measurement prediction error:
$$
\text{fitness}(k+1) = \exp[-(y_{k+1} – \hat{y}^l_{i,k+1})^2],
\tag{4.14}
$$
where $\hat{y}^l_{i,k+1}$ is the predicted measurement of the $i$-th particle at iteration $l$.
When particles exceed the search space boundaries during iteration, I apply boundary correction:
- If $x^{l+1}_{d,i,k+1} > \mu^{max}_{d,k+1}$: $x^{l+1}_{d,i,k+1,new} = x^l_{d,i,k+1} + (\mu^{max}_{d,k+1} – x^l_{d,i,k+1}) \times \text{rand}$;
- If $x^{l+1}_{d,i,k+1} < \mu^{min}_{d,k+1}$: $x^{l+1}_{d,i,k+1,new} = x^l_{d,i,k+1} + (\mu^{min}_{d,k+1} – x^l_{d,i,k+1}) \times \text{rand}$.
After PSO iteration converges, I construct the contracted orthogonal parallelotope using linear programming:
$$
\beta^d_{k+1} = \max e^T_d X, \quad \text{s.t. } X \in A(k+1),
\tag{4.15}
$$
$$
\beta^{d+n_x}_{k+1} = \min e^T_d X, \quad \text{s.t. } X \in A(k+1),
\tag{4.16}
$$
where $A(k+1) = \{X_{1,k+1}, X_{2,k+1}, \cdots, X_{n,k+1}\}$ represents the final particle set after convergence. The final contracted orthogonal parallelotope is constructed with:
$$
\bar{\theta}^{o,d}_{c,k+1} = \frac{\beta^d_{k+1} + \beta^{d+n_x}_{k+1}}{2}, \quad \bar{T}^{o,d}_{k+1} = \frac{\beta^d_{k+1} – \beta^{d+n_x}_{k+1}}{2}.
\tag{4.17}
$$
This contracted orthogonal parallelotope $\mathbb{P}(\bar{\theta}^o_{c,k+1}, \bar{T}^o_{k+1})$ provides a tighter enclosure of the true electric vehicle battery SOC state compared to the original parallelotope filter.
4.5 Experimental Results and Analysis
I compared the proposed Particle Swarm Optimization-Orthogonal Hyperparallel Space Filtering (PSO-OHSF) algorithm against the Ellipsoidal Set Membership Filter (ESMF) and the Orthogonal Hyperparallel Space Set Membership Filter (OHSSMF). The simulation results demonstrate the superior performance of my approach:
| k (time step) | PSO-OHSF Interval Width | OHSSMF Interval Width | ESMF Interval Width |
|---|---|---|---|
| 100 | 0.012 | 0.025 | 0.10 |
| 200 | 0.010 | 0.022 | 0.09 |
| 500 | 0.008 | 0.018 | 0.08 |
| 800 | 0.007 | 0.015 | 0.07 |
The PSO-OHSF algorithm generates tighter SOC estimation bounds while maintaining reliable enclosure of the true state. The particle swarm optimization mechanism effectively drives particles toward the region near the true state, and the resulting orthogonal parallelotope exhibits significantly reduced conservatism compared to conventional approaches.
5. Particle Filtering Based on Parallelotope Space Optimization
5.1 Problem Formulation
For the nonlinear electric vehicle battery system, the state-space model can be expressed as:
$$
\begin{cases}
x_k = f(x_{k-1}, u_{k-1}) + w_{k-1}, \\
y_k = h(x_k, u_k) + v_k,
\end{cases}
\tag{5.1}
$$
where $f(\cdot)$ is the state transition function and $h(\cdot)$ is the measurement function. Both noise terms are assumed to be unknown but bounded.
5.2 Linearization and Error Bounding
I linearize the nonlinear functions using Taylor expansion at the current state estimate:
$$
f(x_{k-1}) = f(\hat{x}_{k-1}) + A_k(x_{k-1} – \hat{x}_{k-1}) + e_{k-1},
\tag{5.2}
$$
where $A_k$ is the Jacobian matrix and $e_{k-1}$ is the linearization error. To bound the linearization error, I employ Difference of Convex (DC) programming. Any continuous function can be expressed as the difference of two convex functions:
$$
f(x) = g_{1,i}(x) – g_{2,i}(x),
\tag{5.3}
$$
where $g_{1,i}(x) = f_i(x) + \alpha x^T x$ and $g_{2,i}(x) = \alpha x^T x$. The linearization error of each component can then be bounded as:
$$
e^i_{k-1,min} = \min_{x_{k-1} \in \mathbb{V}_P} \{g_{1,i}(x_{k-1}) – g_{2,i}(x_{k-1}) – f_{i,L}(x_{k-1})\},
\tag{5.4}
$$
$$
e^i_{k-1,max} = \max_{x_{k-1} \in \mathbb{V}_P} \{g_{1,i}(x_{k-1}) – g_{2,i}(x_{k-1}) – f_{i,L}(x_{k-1})\},
\tag{5.5}
$$
yielding the interval $e_{k-1} \in [e_{k-1,min}, e_{k-1,max}]$, which can be represented as a parallelotope:
$$
\mathbb{P}(\theta_{e_{k-1}}, \text{diag}\{r_{e_{k-1}}\}).
\tag{5.6}
$$
5.3 Prediction Step
Using the Minkowski sum of parallelotopes, I compute the prediction zonotope:
$$
\mathbb{Z}(\hat{x}_{k,k-1}, T_{k,k-1}) = \mathbb{P}(f(\hat{x}_{k-1}), A_k T_{k-1}) \oplus \mathbb{P}(\theta_{e_{k-1}}, \text{diag}\{r_{e_{k-1}}\}) \oplus \mathbb{P}(0, \text{diag}\{r_w\}).
\tag{5.7}
$$
Theorem 5.1: Given a zonotope $\mathbb{Z}(\theta_c, T)$, the minimum-volume bounding parallelotope is:
$$
\mathbb{P}(\theta_c, G) = \{\theta : \theta = \theta_c + G\alpha, \|\alpha\|_{\infty} \leq 1\},
\tag{5.8}
$$
where $G = ([\phi_1, \cdots, \phi_n]^T)^{-1}$ and $\phi_i = H^+_{v_{m_i}} / \Delta k_{v_{m_i}}$.
Proof sketch: The zonotope can be converted to half-space representation using Lemma 3.1. Each pair of parallel half-spaces forms a strip $S(\phi_l, d_l)$. Selecting $n$ strips from the $u = C^{n-1}_m$ available strips creates a bounding parallelotope. The minimum-volume parallelotope is obtained by evaluating all $C^n_u$ combinations and selecting the one with minimum volume $2^n|\det(G_j)|$. $\square$
Thus, the minimum-volume bounding parallelotope for the prediction step is:
$$
\mathbb{P}(\hat{x}_{k,k-1}, \hat{G}_{k,k-1}) = \{x_{k,k-1} : x_{k,k-1} = \hat{x}_{k,k-1} + \hat{G}_{k,k-1}\alpha, \|\alpha\|_{\infty} \leq 1\},
\tag{5.9}
$$
which serves as the feasible state domain in the prediction stage.
5.4 Update Step with Observation Strips
The measurement function is linearized similarly, yielding the measurement set:
$$
S_k = \{x : |B_k x_k – (y_k – h(\hat{x}_{k,k-1}) + B_k \hat{x}_{k,k-1} – \tau_{o_k})| \leq \text{diag}\{r_{o_k} + r_{v_k}\}\}.
\tag{5.10}
$$
Using the recursive optimal parallelotope outbounding algorithm, I compute the intersection of the prediction parallelotope with each measurement strip sequentially, obtaining the posterior particle feasible domain:
$$
\mathbb{P}(\hat{x}_{k,k}, G_{k,k}) = \{x : \|P_k(x – \hat{x}_{k,k})\|_{\infty} \leq 1\},
\tag{5.11}
$$
where $P_k = G^{-1}_{k,k}$.
5.5 Particle Screening and Regeneration
Theorem 5.2: Given the prior particle set $X^-_k = [x^{1,-}_k, x^{2,-}_k, \cdots, x^{N,-}_k]$ and the particle feasible domain $\mathbb{P}(\hat{x}_{k,k}, G_{k,k})$, the weights of particles outside the feasible domain are set to zero:
$$
w^i_k = 0, \quad \text{if } P_k(x^{i,-}_k – \hat{x}_{k,k}) > 1.
\tag{5.12}
$$
The retained particles are denoted as $x^{i,-}_{k,r}$, and discarded particles as $x^{i,-}_{k,d}$. To maintain the total particle count at $N$, I generate new valid particles $x^{i,-}_{k,new}$ by solving the optimization problem:
$$
\min_{x^{i,-}_{k,new} \in \mathbb{P}(\hat{x}_{k,k}, G_{k,k})} -\left( \log[p_{x^k_e}(x^{i,-}_{k,new} – x^{i,-}_k)] + \log\{p_{v_k}[y_k – h(x^{i,-}_{k,new})]\} \right),
\tag{5.13}
$$
where $x^k_e$ is the estimation error following distribution $p_{x^k_e}$, and $v_k$ is the measurement noise following distribution $p_{v_k}$.
Proof: Based on the Maximum A Posteriori (MAP) criterion, the posterior probability density function $p(x_k|Y_k)$ is maximized:
$$
\hat{x}_k = \arg\max_{x_k} p(x_k|Y_k) \propto \arg\max_{x_k} p(y_k|x_k)p(x_k|Y_{k-1}).
\tag{5.14}
$$
Substituting the explicit distributions and applying the log transformation converts the maximization to the minimization problem stated above. The constraint $x^{i,-}_{k,new} \in \mathbb{P}(\hat{x}_{k,k}, G_{k,k})$ ensures that regenerated particles remain within the verified feasible domain. $\square$
After particle regeneration, the posterior particle set is $X^+_k = [x^{1,-}_{k,r}, \cdots, x^{\gamma,-}_{k,r}, x^{1,-}_{k,new}, \cdots, x^{\eta,-}_{k,new}]$ with $\gamma + \eta = N$. The posterior weights are computed as:
$$
w^i_k = w^i_{k-1} p(y_k | x^{i,+}_k),
\tag{5.15}
$$
followed by normalization:
$$
w^i_k = \frac{w^i_k}{\sum_{i=1}^{N} w^i_k}.
\tag{5.16}
$$
The final SOC estimate is obtained as:
$$
\hat{x}_k = \sum_{i=1}^{N} w^i_k x^{i,+}_k.
\tag{5.17}
$$
5.6 Experimental Results and Analysis
I evaluated the proposed Parallelotope-Improved Particle Filter (P-IPF) against several established approaches including EKF, MCC-AEKF, EPSMF, traditional PF, and ESMPF. All particle-based methods used $N = 20$ particles. The RMSE comparison for SOC estimation is presented below:
| Algorithm | EKF | MCC-AEKF | EPSMF | PF | ESMPF | P-IPF |
|---|---|---|---|---|---|---|
| SOC RMSE | 0.0175 | 0.00526 | 0.00736 | 0.00879 | 0.00480 | 0.00319 |
The P-IPF algorithm achieves a 33.5% RMSE reduction compared to ESMPF, demonstrating that the parallelotope-based particle feasible domain provides tighter and more accurate state constraints than ellipsoidal domains.
I further examined the performance of P-IPF under incorrect initial SOC conditions. By setting the initial SOC to the correct value of 1.0 and an erroneous value of 0.7, I observed that the algorithm converges quickly to the true SOC trajectory even with significant initial error, confirming the robustness and practical applicability of the proposed method for electric vehicle battery management systems.
6. System Development for Electric Vehicle Battery Production Management
6.1 System Requirements Analysis
The system development project was based on the actual production management requirements of a leading battery company in China. The company operates multiple complete electric vehicle battery production lines and identified several key challenges:
- Data visualization gap: Production data were primarily recorded and stored manually, leading to inefficiencies in data retrieval and cross-departmental communication.
- Process parameter accessibility: Different battery models require different production process schemes, but the data for these schemes could not be directly queried.
- Production line management: Equipment failures were difficult to locate quickly across multiple production lines.
- SOC estimation difficulty: Accurate SOC estimation remained challenging, directly impacting the battery management system’s core functions.
6.2 System Architecture and Development Environment
I adopted the Browser/Server (B/S) architecture for the system, which centralizes computation and data processing on the server side while users access the system through web browsers. The technical stack includes:
| Component | Technology |
|---|---|
| Frontend framework | Vue.js with ECharts visualization library |
| Backend framework | SpringBoot with MyBatis |
| API style | RESTful API |
| Development environment | IntelliJ IDEA |
| Server operating system | Windows Server 2016 |
| Database | MySQL |
6.3 Functional Modules
The developed system integrates four primary functional modules to support electric vehicle battery production management and SOC estimation:
6.3.1 Manufacturing Activity Collection Module
This module visualizes critical manufacturing data through an interactive dashboard. It displays key production parameters such as mixing duration, coating surface density, and formation process data using interactive charts. Additionally, the module presents quality metrics including open-circuit voltage, constant-temperature resting duration, and cell test pass rates. A radar chart visualizes the current inventory levels versus required quantities for essential raw materials. The module also monitors equipment status and displays historical manufacturing capacity.
6.3.2 Process Data Module
This module enables users to search for battery performance data through fuzzy search functionality based on battery numbers. Detailed process parameters are displayed in tabular form, including positive electrode double-sided coating density, negative electrode double-sided coating density, positive electrode winding length, primary electrolyte injection volume, and secondary injection volume. A dedicated button retrieves historical production quality pass rates for the selected process.
6.3.3 Production Line Management Module
This module provides equipment status monitoring and scheduling capabilities. Key production equipment such as positive electrode winding machines, coating machines, and spreading machines are shown with their operational status indicated by color coding (green for normal, red for fault). Equipment downtime buttons enable remote management of failed devices. The module also visualizes order scheduling information and handles production schedule changes.
6.3.4 SOC Estimation Module
The SOC estimation module integrates the algorithms developed in this research. It retrieves battery parameters (model, rated voltage, rated capacity, cutoff voltages, and test temperature) from the production database through API interfaces. The estimation algorithms run on the server side, and results are displayed through bar charts showing the SOC values for different battery batches. The module also displays open-circuit voltage variations during discharge as line charts. Detailed battery parameter information is shown above the visualization for reference.
7. Conclusion and Future Work
This research addressed the electric vehicle battery SOC estimation problem under unknown-but-bounded noise conditions. I developed two novel filtering algorithms and implemented a comprehensive production management system. The key contributions are summarized as follows:
First, I established a first-order RC equivalent circuit model for electric vehicle battery SOC estimation, including comprehensive parameter identification through experiments. The model effectively captures the battery’s dynamic behavior while maintaining computational tractability for real-time applications.
Second, I proposed a Particle Swarm Optimization-based Orthogonal Hyperparallel Space Filtering algorithm. This algorithm constructs an orthogonal parallelotope search space with identical bounds as the conventional parallelotope, then employs PSO to iteratively drive particles toward the true SOC neighborhood. The final contracted orthogonal parallelotope provides significantly tighter SOC estimation bounds compared to ESMF and OHSSMF algorithms.
Third, I developed a Parallelotope-based Improved Particle Filter algorithm for nonlinear SOC estimation. By using DC programming to bound linearization errors and constructing minimum-volume bounding parallelotopes for particle feasible domains, the algorithm effectively addresses particle degeneracy and impoverishment issues. The P-IPF algorithm achieved the lowest SOC RMSE of 0.00319 among all compared methods.
Fourth, I developed a comprehensive electric vehicle battery production management and SOC estimation system using modern web technologies. The system integrates the proposed algorithms and provides intuitive visualization interfaces for manufacturing data, process parameters, production line management, and SOC monitoring, supporting the digital transformation of battery manufacturing enterprises.
Despite these contributions, several aspects warrant further investigation. Temperature effects on battery behavior should be incorporated into the model to enhance estimation accuracy under varying environmental conditions. Computational efficiency could be improved through algorithm optimization and hardware acceleration. Additionally, the system functionality could be extended to include battery health management, thermal monitoring, and fault diagnosis capabilities to provide a more comprehensive battery management solution.