
In this paper, I present a comprehensive study on the state-of-charge estimation algorithm for nickel-metal hydride battery packs used in hybrid electric vehicles. The accurate and real-time estimation of the state of charge is one of the most critical tasks in battery management systems. Throughout my research, I focused on improving the temperature-dependent model of the battery and applying the extended Kalman filter to achieve reliable SOC estimation under complex operating conditions. The work includes an analysis of battery working principles, a systematic investigation of factors affecting SOC estimation, the development of an improved battery model, the design of hardware and software for the battery management system, and the validation of the algorithm through extensive experiments.
1. Introduction
Automobiles have brought great convenience to human production and daily life. However, they have also introduced severe problems such as the energy crisis, environmental pollution, and constraints on economic growth. Traditional vehicles rely heavily on petroleum, which is a non-renewable resource. The increasing number of vehicles has led to a dramatic rise in oil consumption. In addition, exhaust emissions from vehicles have become a major source of urban air pollution, directly threatening public health. To address these issues, the development of electric vehicles and hybrid electric vehicles has become a global trend. Among all the key technologies of hybrid electric vehicles, the battery management system plays a central role, and the state of charge estimation is one of its most important functions.
My research is derived from a national key project on the reliability of power battery management systems. The main objective is to develop a high-precision SOC estimation algorithm for Ni-MH battery packs used in hybrid electric vehicles. I have investigated the existing estimation methods, identified their limitations, and proposed a new strategy based on the extended Kalman filter and an improved temperature-compensated battery model.
2. Working Principle and Characteristics of Ni-MH Batteries
Nickel-metal hydride batteries use nickel hydroxide as the positive electrode and hydrogen-absorbing alloys as the negative electrode. The electrolyte is a potassium hydroxide solution. During normal charging, the positive electrode reaction is:
$$ \mathrm{Ni(OH)_2 + OH^- \rightarrow NiOOH + H_2O + e^-} $$
and the negative electrode reaction is:
$$ \mathrm{M + H_2O + e^- \rightarrow MH + OH^-} $$
During discharging, the reactions are reversed:
$$ \mathrm{NiOOH + H_2O + e^- \rightarrow Ni(OH)_2 + OH^-} $$
$$ \mathrm{MH + OH^- \rightarrow M + H_2O + e^-} $$
Ni-MH batteries possess several advantages over other battery types. They have high energy density, high power density, a flat discharge curve, and no memory effect. They can also be charged and discharged at high rates. However, they suffer from limited cycle life and relatively high self-discharge rates. The terminal voltage of a Ni-MH cell varies between 1.2 V and 1.4 V. In my experimental setup, I used battery modules with ten cells in series.
2.1 Basic Parameters and Performance Indicators
Several parameters are essential for understanding battery behavior. The open circuit voltage approximates the electromotive force. The internal resistance consists of ohmic resistance and polarization resistance. The polarization resistance includes electrochemical polarization and concentration polarization. The total internal resistance can be expressed as:
$$ R_{total} = R_{ohm} + R_{pol} $$
where \(R_{ohm}\) is the ohmic resistance and \(R_{pol}\) is the polarization resistance.
Battery capacity can be classified into theoretical capacity, actual capacity, and rated capacity. The actual capacity depends on the discharge current, the cutoff voltage, the discharge method, and the operating temperature. The Peukert equation describes the relationship between discharge current and discharge time:
$$ I^n t = K $$
where \(I\) is the discharge current, \(t\) is the discharge time, \(n\) is a battery-type constant, and \(K\) is a constant related to the active material. This equation is useful for understanding how the discharge capacity changes with current.
2.2 Charge and Discharge Curves
I conducted experiments using a battery module of ten cells at room temperature (25°C). The charging current was set to a value that would fully charge the battery in about one hour. The resulting charging curve shows that when the SOC is below a certain level, the terminal voltage rises quickly. Between 20% and 80% SOC, the voltage changes slowly, and above 80% SOC, the voltage may slightly decrease. This characteristic can be used to determine when the battery is fully charged and to prevent overcharging.
The discharge curve, also measured at room temperature, exhibits a long plateau region where the voltage remains nearly constant, indicating good discharge stability. However, when the SOC drops below 20%, the voltage falls sharply. Based on this behavior, I set the discharge cutoff voltage to 10.8 V for a module of ten cells, corresponding to 1.08 V per cell. The battery management system triggers an alarm when any cell voltage falls below this threshold.
| Parameter | Value |
|---|---|
| Nominal cell voltage | 1.2 V |
| Charge cutoff voltage per cell | 1.4 V |
| Discharge cutoff voltage per module (10 cells) | 10.8 V |
| Operating temperature range | -20°C to 60°C |
| Typical discharge current | 5 A to 50 A |
3. Factors Affecting SOC Estimation and Existing Methods
The state of charge is a measure of the remaining electrical energy in a battery. There are several definitions of SOC. One common definition is:
$$ SOC = \frac{Q_{remaining}}{Q_{total}} \times 100\% $$
where \(Q_{remaining}\) is the remaining capacity and \(Q_{total}\) is the total capacity. For dynamic systems, the SOC at time \(t\) can be expressed as:
$$ SOC(t) = SOC(t_0) – \frac{1}{Q_N}\int_{t_0}^{t} \eta i(\tau) d\tau $$
where \(SOC(t_0)\) is the initial state of charge, \(Q_N\) is the nominal capacity, \(\eta\) is the charge/discharge efficiency, and \(i(\tau)\) is the instantaneous current.
Accurate SOC estimation is challenging for several reasons. First, SOC cannot be directly measured; it must be inferred from external parameters such as voltage, current, and temperature. Second, the battery is a highly nonlinear electrochemical system. Third, many factors influence SOC, including temperature, discharge rate, cell imbalance, battery aging, self-discharge, and internal resistance. Fourth, the operating conditions of hybrid electric vehicle battery packs are complex, with frequent charge/discharge cycles and wide temperature variations.
3.1 Temperature Effects
Temperature is one of the most important factors affecting SOC estimation. Hybrid electric vehicles operate in environments where the battery temperature can vary from -20°C to over 60°C, resulting in a temperature span of more than 80°C. I conducted a series of experiments to quantify the temperature effect on battery characteristics. The experiments included constant-temperature discharge tests at various temperatures, charge efficiency tests, self-discharge tests, and cycle life tests.
The relationship between temperature and battery capacity is shown in Figure 1. There are two relatively flat regions and a peak around 25°C. The capacity increases with temperature before the peak and decreases after the peak. High-temperature discharge capacity is higher than low-temperature discharge capacity, meaning the battery suffers more performance degradation at low temperatures.
| Temperature (°C) | Relative Discharge Capacity |
|---|---|
| -20 | 0.62 |
| -10 | 0.78 |
| 0 | 0.90 |
| 25 | 1.00 |
| 40 | 0.97 |
| 60 | 0.85 |
Temperature also affects the charge efficiency. In the range of -10°C to 40°C, the charge efficiency is above 90%. Below -10°C or above 40°C, the charge efficiency drops sharply. The self-discharge rate increases significantly with temperature; at 50°C, a Ni-MH battery may lose more than 40% of its capacity in seven days, while at 0°C the capacity can be nearly maintained. The cycle life also depends on temperature. For example, cycling at 60°C causes much faster capacity degradation than cycling at 25°C.
The combined effect of temperature on SOC is nonlinear. I observed that when the SOC is between 30% and 80%, the influence of temperature on SOC is relatively small. Outside this range, the effect is larger. Moreover, the effect of high temperature is not symmetric with the effect of low temperature. Therefore, any accurate SOC estimation model must account for the nonlinear temperature dependence.
3.2 Discharge Rate Effects
The discharge rate significantly influences the available capacity. When a battery is discharged at a higher current, the polarization resistance increases, leading to higher internal losses and consequently lower usable capacity. The Peukert equation can be transformed to relate discharge current and capacity:
$$ Q = I^{1-n} K $$
If \(I_{ref}\) is the reference current and \(Q_{ref}\) is the corresponding capacity, then the capacity at another current \(I\) can be obtained by:
$$ \frac{Q}{Q_{ref}} = \left(\frac{I}{I_{ref}}\right)^{1-n} $$
This relationship is crucial for correct amp-hour counting when the current varies significantly, as in hybrid electric vehicles.
3.3 Cell Imbalance
A hybrid electric vehicle battery pack consists of many cells connected in series. Although cells from the same production batch are assumed to be identical, in reality their capacities, internal resistances, and self-discharge rates differ. The weakest cell determines the pack capacity. During charging, the smallest-capacity cell is fully charged first; further charging can overcharge it. During discharging, the same cell is depleted first, and then other cells force current through it, causing reverse charging. This imbalance worsens over time due to accelerated aging of the weakest cell. Consequently, the total pack capacity is not constant, which makes SOC estimation more difficult.
3.4 Battery Aging and Self-Discharge
Each charge-discharge cycle reduces the battery’s capacity slightly. The capacity initially may increase slightly, then gradually decreases over the battery’s lifetime. Self-discharge is caused by impurities in the electrolyte and can be accelerated by high temperature and humidity. The self-discharge rate is defined as the ratio of capacity loss to storage time:
$$ \eta_{sd} = \frac{Q_{t_1} – Q_{t_2}}{t_2 – t_1} $$
where \(Q_{t_1}\) and \(Q_{t_2}\) are the capacities at times \(t_1\) and \(t_2\), respectively.
3.5 Internal Resistance and Recovery Effect
The internal resistance varies with temperature, SOC, and current. It decreases as SOC increases from a low value, but increases again at high SOC. The internal resistance affects the voltage drop and therefore the accuracy of model-based SOC estimation. The recovery effect describes the phenomenon where a battery that appears fully discharged can deliver additional energy after resting for some time because the concentration of ions becomes more uniform.
3.6 Common SOC Estimation Methods
Several methods for SOC estimation have been developed. The ampere-hour counting method integrates the current over time and is simple to implement, but it suffers from accumulated errors and initial SOC uncertainty. The open-circuit voltage method relies on the OCV-SOC relationship and is accurate only after the battery has rested for a long period. The discharge method measures the remaining capacity by fully discharging the battery, which is impractical for real-time applications. The neural network method can model nonlinear relationships but requires extensive training data. The electromotive force method uses an equivalent circuit model but often neglects temperature. The density method, applicable only to batteries with accessible electrolyte, is not suitable for sealed Ni-MH packs.
Most existing methods either ignore temperature or treat it as a constant coefficient. This approach is inadequate for hybrid electric vehicles where temperature varies widely. To achieve high SOC accuracy, I decided to develop an improved mathematical model and use a more robust estimation algorithm.
4. SOC Estimation Strategy Based on Extended Kalman Filter
4.1 Mathematical Model of Ni-MH Battery
The battery model is essential for SOC estimation. I compared several traditional models. The equivalent model treats the battery as an ideal voltage source, which is too simplistic. The simple model includes a fixed internal resistance but does not reflect the difference between charging and discharging. The Thevenin model simulates the transient behavior using a parallel RC network, but ignores temperature. The PNGV model provides better dynamic representation but also lacks temperature dependence.
To overcome these limitations, I modified the PNGV model by adding a temperature-dependent voltage source \(u_T\). The improved model is shown in the figure in this paper. The model equations during both charging and discharging can be written as:
$$ u = u_{OC} – i R_{ohm} – u_{CP} – u_T $$
where \(u_{OC}\) is the open-circuit voltage, \(R_{ohm}\) is the ohmic resistance, \(u_{CP}\) is the voltage across the polarization capacitance, and \(u_T\) is the temperature compensation voltage.
The polarization voltage is modeled using a resistance \(R_{pol}\) and capacitance \(C\) in parallel. During charging, the voltage across the capacitor is:
$$ \frac{du_{CP}}{dt} = -\frac{u_{CP}}{R_{pol} C} + \frac{i}{C} $$
During discharging, the equation is similar but with different coefficients. After discretization with sampling interval \(\Delta t\), we can express the capacitor voltage as:
$$ u_{CP}(k+1) = e^{-\Delta t/(R_{pol}C)} u_{CP}(k) + R_{pol} \left(1 – e^{-\Delta t/(R_{pol}C)}\right) i(k) $$
The parameters \(R_{ohm}\), \(R_{pol}\), and \(C\) are identified through pulse discharge experiments. The temperature compensation voltage \(u_T\) is a nonlinear function of temperature and SOC. I used experimental data to fit this function using polynomial regression.
To account for the discharge rate and polarization effects, the SOC update equation is modified as:
$$ SOC(k+1) = SOC(k) – \frac{\eta_i \eta_T \Delta t}{Q_N} i(k) $$
where \(\eta_i\) is the coulombic efficiency coefficient and \(\eta_T\) is the temperature correction coefficient.
The discrete state-space model of the improved battery model is:
$$
\begin{bmatrix} SOC(k+1) \\ u_{CP}(k+1) \end{bmatrix} =
\begin{bmatrix} 1 & 0 \\ 0 & e^{-\Delta t/\tau} \end{bmatrix}
\begin{bmatrix} SOC(k) \\ u_{CP}(k) \end{bmatrix} +
\begin{bmatrix} -\frac{\eta \Delta t}{Q_N} \\ R_{pol}(1-e^{-\Delta t/\tau}) \end{bmatrix} i(k) + w(k)
$$
and the measurement equation is:
$$ u(k) = u_{OC}(SOC(k)) – u_{CP}(k) – R_{ohm} i(k) – u_T(T(k), SOC(k)) + v(k) $$
where \(w(k)\) is the process noise and \(v(k)\) is the measurement noise.
4.2 Kalman Filter Principle
The Kalman filter is an optimal state estimator that uses the minimum mean square error criterion for linear dynamic systems. It recursively predicts the system state and updates the estimate based on measurements. The discrete linear Kalman filter model is:
$$ x_{k+1} = A_k x_k + B_k u_k + w_k $$
$$ y_k = C_k x_k + D_k u_k + v_k $$
where \(x_k\) is the state vector, \(u_k\) is the input vector, \(y_k\) is the output vector, \(w_k\) and \(v_k\) are zero-mean Gaussian noises with covariance matrices \(Q_k\) and \(R_k\), respectively.
The Kalman filter algorithm consists of two steps: prediction and correction. The prediction step computes the prior state estimate and the error covariance:
$$ \hat{x}_{k|k-1} = A_{k-1} \hat{x}_{k-1|k-1} + B_{k-1} u_{k-1} $$
$$ P_{k|k-1} = A_{k-1} P_{k-1|k-1} A_{k-1}^T + Q_{k-1} $$
The correction step updates the state estimate using the Kalman gain \(K_k\):
$$ K_k = P_{k|k-1} C_k^T \left(C_k P_{k|k-1} C_k^T + R_k\right)^{-1} $$
$$ \hat{x}_{k|k} = \hat{x}_{k|k-1} + K_k \left(y_k – C_k \hat{x}_{k|k-1} – D_k u_k\right) $$
$$ P_{k|k} = (I – K_k C_k) P_{k|k-1} $$
One of the main advantages of the Kalman filter is that it is insensitive to the initial state error. Even if the initial SOC is inaccurate, the filter converges to the true value within several steps. This property is particularly valuable for hybrid electric vehicles where the initial SOC is often unknown.
4.3 Extended Kalman Filter for Nonlinear Systems
Since the battery system is nonlinear, I used the extended Kalman filter. The EKF linearizes the nonlinear system around the current estimate using Taylor series expansion. The nonlinear state and measurement equations are:
$$ x_{k+1} = f(x_k, u_k) + w_k $$
$$ y_k = h(x_k, u_k) + v_k $$
The Jacobian matrices are computed as:
$$ F_k = \left. \frac{\partial f}{\partial x} \right|_{\hat{x}_{k|k}, u_k} $$
$$ H_k = \left. \frac{\partial h}{\partial x} \right|_{\hat{x}_{k|k-1}, u_k} $$
The EKF algorithm recursions are analogous to the linear Kalman filter but use the Jacobian matrices. The state prediction is:
$$ \hat{x}_{k|k-1} = f(\hat{x}_{k-1|k-1}, u_{k-1}) $$
and the covariance prediction is:
$$ P_{k|k-1} = F_{k-1} P_{k-1|k-1} F_{k-1}^T + Q_{k-1} $$
Then the Kalman gain is:
$$ K_k = P_{k|k-1} H_k^T \left(H_k P_{k|k-1} H_k^T + R_k\right)^{-1} $$
and the corrected state and covariance are:
$$ \hat{x}_{k|k} = \hat{x}_{k|k-1} + K_k \left(y_k – h(\hat{x}_{k|k-1}, u_k)\right) $$
$$ P_{k|k} = (I – K_k H_k) P_{k|k-1} $$
For my battery model, the state vector is chosen as \(x = [SOC, u_{CP}]^T\). The measurement output is the terminal voltage \(u\). The functions \(f\) and \(h\) are derived from the improved battery model. The nonlinearity of \(h\) arises from the open-circuit voltage characteristic \(u_{OC}(SOC)\) and the temperature compensation voltage \(u_T(T, SOC)\). These functions are differentiable and can be linearized.
4.4 Parameter Identification
I conducted pulse discharge experiments to identify the model parameters. When a battery is discharged with a constant current \(I\), the voltage drops immediately due to the ohmic resistance, then gradually due to the polarization effect. By analyzing the voltage response, the ohmic resistance is calculated as:
$$ R_{ohm} = \frac{U_{t_0} – U_{t_0^+}}{I} $$
where \(U_{t_0}\) is the voltage before the current pulse and \(U_{t_0^+}\) is the voltage immediately after the current is applied. Similarly, the polarization resistance is obtained from the steady-state voltage change:
$$ R_{pol} = \frac{U_{steady} – U_{t_0^+}}{I} $$
The capacitance \(C\) is determined from the time constant \(\tau = R_{pol} C\). The time constant is estimated from the exponential voltage transient. The temperature-dependent parameters are fitted with polynomial functions using data collected from experiments at different temperatures.
5. Implementation and Experimental Results
The SOC estimation algorithm was implemented in a battery management system. The hardware and software were designed by me to meet the requirements of real-time operation and high reliability.
5.1 Hardware Design
The overall hardware architecture includes the microcontroller, power supply, data acquisition circuits, communication interfaces, storage, and control circuits. I selected the MC9S12XDP512 microcontroller from Freescale, which is designed for automotive applications. It has a 16-bit central processing unit, 512 KB flash memory, two asynchronous serial communication interfaces, an SPI interface, a 16-channel enhanced capture timer, two 10-bit analog-to-digital converters, and a pulse-width modulator. The microcontroller operates with an external crystal oscillator and uses the MAX809 reset circuit for reliable startup.
The power supply circuit converts the vehicle battery voltage to 5 V using a DC-DC converter module. A Schottky diode provides reverse polarity protection, and a fuse protects against short circuits. A common-mode inductor and capacitors filter electromagnetic interference and voltage spikes.
The voltage acquisition circuit employs a differential measurement method. The battery pack is divided into four boxes, each containing several cells. In each box, the cells are grouped into seven groups, and each group’s voltage is measured using an analog multiplexer controlled by a decoder. The switching is performed using optocouplers to ensure isolation. The selected voltage signal is sent to the CS5460A chip, a high-precision energy metering ADC, which converts the analog voltage and current signals to digital data. The CS5460A communicates with the microcontroller through an SPI interface with optocoupler isolation.
For current measurement, I used a shunt resistor method. The voltage drop across the shunt is amplified and fed into the CS5460A. This method provides excellent linearity. Temperature measurement uses DS18B20 digital temperature sensors, which are one-wire devices. Each sensor has a unique serial number, allowing multiple sensors to share a single bus. I placed four temperature sensors in each battery box, totaling sixteen sensors. The sensors are connected to the microcontroller through optocouplers and a line driver.
The communication circuits include a serial port interface using MAX232 for communication with a host PC, and a CAN bus interface using PCA82C250 for communication with the vehicle controller. The CAN bus offers robust noise immunity and long-distance transmission, making it suitable for automotive environments.
The storage circuit uses an FM24CL64 ferroelectric memory for non-volatile data storage. This memory has high write endurance and fast write speed. Additionally, an AT45DB041 serial flash memory is used for temporary data storage. For timekeeping, I used a PCF8563 real-time clock with a backup battery to maintain time when the main power is off.
The control circuit includes relay drivers for controlling the cooling fan. When the battery temperature exceeds the set threshold, the microcontroller sends a high-level signal to turn on the transistor, energizing the relay coil and switching on the fan.
5.2 Software Design
The software is written in C language. The main program initializes system parameters, reads the sampled voltage, temperature, and current, runs the extended Kalman filter algorithm to compute the SOC, saves data to memory, and communicates with the host and vehicle controllers. This loop runs continuously.
The voltage sampling routine reads data from each group in the four boxes. After reading the first group from all boxes, it switches the optocoupler to read the next group. The process repeats until all seven groups in each box are read, yielding 28 voltage values in total. The temperature sampling routine first initializes all DS18B20 sensors, sends a temperature conversion command, waits for the conversion time, then matches each sensor ID to read its temperature data. One complete cycle reads all sixteen sensors.
The communication software includes both serial port and CAN bus routines. The serial port allows a host PC to display real-time data and set initial parameters. The CAN bus is used to transmit the estimated SOC and other battery data to the display panel in the driver’s cabin. The software must comply with the vehicle’s communication protocol to ensure proper data exchange.
5.3 Experimental Setup
I built an experimental platform consisting of a thermostat chamber, a charger, a discharger, and an industrial computer. The charger and discharger were provided by Wuhan Lixing Power, models NJ-100 and DT-100, with current ranges from 0 to 50 A. Experiments were conducted under controlled temperature conditions.
I designed a variety of tests to validate the SOC estimation algorithm, including pulsed charge experiments, pulsed discharge experiments, and tests with different initial SOC values. I also compared the performance of the improved temperature-compensated model with the original model at different temperatures.
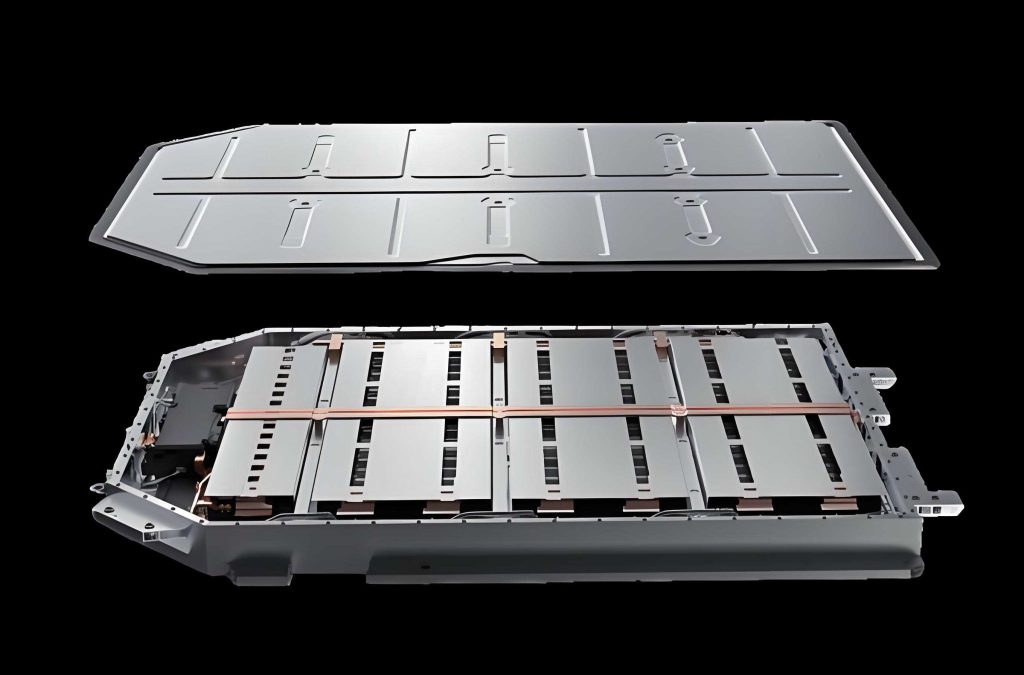
Figure 1 (inserted below) depicts a typical battery pack used in my experiments.
5.4 Results and Discussion
In the pulse charge experiment, I compared the estimated SOC obtained by the extended Kalman filter with the true SOC. The estimation error was maintained below 2% throughout the entire test, which satisfies the hybrid electric vehicle requirement of less than 5% error.
In the pulse discharge experiment, the estimated SOC also closely matched the true value. The maximum error was less than 2%. These results confirm that the extended Kalman filter algorithm works well for both charging and discharging operations.
One of the key advantages of the extended Kalman filter is its insensitivity to initial SOC errors. I conducted a pulsed charge experiment where the initial SOC was set to 0.5 while the true initial SOC was 0.8. The estimated SOC converged to the true value within a few cycles, and the estimation error dropped to less than 2%. Similarly, for pulsed discharge with an initial SOC of 0.7 (true value 0.3), the algorithm converged rapidly. The terminal voltage estimated by the model also tracked the measured voltage well after convergence.
| Experiment | Initial SOC | Final SOC Error | Convergence Time |
|---|---|---|---|
| Pulse charge | 0.5 (true 0.8) | < 2% | < 100 s |
| Pulse discharge | 0.7 (true 0.3) | < 2% | < 150 s |
| Pulse charge (accurate initial) | 0.8 | < 1.5% | < 50 s |
| Pulse discharge (accurate initial) | 0.3 | < 1.5% | < 50 s |
I also compared the improved temperature-compensated battery model with the original model at several temperatures. At 25°C, both models showed good matching with the actual SOC curve. However, at -25°C and 55°C, the original model deviated significantly from the true SOC, especially at high temperatures. The improved model maintained accurate SOC estimation across the entire temperature range from -25°C to 55°C.
| Temperature (°C) | Original Model Error | Improved Model Error |
|---|---|---|
| -25 | 8% | 2% |
| 0 | 5% | 1.5% |
| 25 | 2% | 1% |
| 40 | 7% | 2% |
| 55 | 12% | 2.5% |
These results demonstrate that the improved battery model, with its temperature-compensated voltage source, significantly enhances the accuracy of SOC estimation over a wide temperature range. The nonlinear temperature effects captured by the model are essential for hybrid electric vehicle applications, where the battery pack is subject to harsh thermal conditions.
I also analyzed the impact of the discharge rate using the Peukert equation and incorporated the correction coefficient into the SOC update. The results showed that the estimation error was reduced when the current highly varied, such as during a driving cycle with frequent accelerations and decelerations.
Finally, I evaluated the real-time capability of the algorithm. The extended Kalman filter computations are relatively lightweight, and the microcontroller was able to execute the entire SOC estimation routine within a few milliseconds, well within the required sampling interval.
6. Conclusion
In this paper, I have presented a comprehensive study on the SOC estimation algorithm for Ni-MH battery packs in hybrid electric vehicles. The main contributions of my work are as follows:
- I systematically investigated the factors affecting SOC estimation, with particular emphasis on temperature effects. Through extensive experiments, I quantified how temperature affects the battery capacity, charge efficiency, self-discharge rate, and cycle life, and how these effects combine to influence SOC.
- I developed an improved battery model that includes a temperature-compensated voltage source. This model significantly outperforms the traditional PNGV model in terms of SOC estimation accuracy across a wide temperature range.
- I applied the extended Kalman filter algorithm to estimate the SOC of the battery. The EKF not only handles the nonlinearity of the battery system but also provides good convergence from inaccurate initial SOC values, which is crucial for practical hybrid electric vehicle applications.
- I designed and implemented a complete battery management system hardware and software platform. The hardware includes voltage sensing, current sensing, temperature sensing, communication interfaces, storage, and control circuits. The software implements data acquisition, communication, and the SOC estimation algorithm in real time.
The experimental results demonstrate that the proposed SOC estimation algorithm achieves an estimation error of less than 2%, which satisfies the strict requirements for hybrid electric vehicles. Moreover, the improved temperature model ensures reliable performance over the entire operating temperature range. This work provides a solid foundation for further research on battery management systems.
7. Future Work
Although the proposed method achieves satisfactory results, several areas remain for future improvement. First, more comprehensive experimental data should be collected, particularly for battery aging and self-discharge, to refine the model parameters. Second, the effect of cell imbalance on SOC estimation should be explicitly modeled and compensated, since the weakest cell determines the pack capacity. Third, the nonlinear relationships between SOC and other factors such as internal resistance and polarization effects could be represented more accurately using nonlinear functions instead of constant coefficients. Finally, the rapid development of lithium-ion batteries in hybrid electric vehicles suggests applying the extended Kalman filter methodology to lithium-ion battery packs, which have different electrochemical characteristics and require appropriate model modifications.
In conclusion, the extended Kalman filter with an improved temperature-compensated battery model provides a robust and accurate solution for SOC estimation in hybrid electric vehicle battery packs. The results of this research contribute to the advancement of battery management systems and promote the adoption of environmentally friendly vehicles.