
As the global transportation sector shifts toward electrification, the lithium-ion battery has become the dominant energy storage technology for electric vehicles. Among the many technical challenges that remain in the practical deployment of these systems, accurate and real-time estimation of the State of Charge (SOC) of the EV battery is arguably the most crucial function of a Battery Management System (BMS). A precise SOC value informs the driver about the remaining range, protects the EV battery from overcharge and overdischarge, and enables optimal energy allocation between the vehicle and the grid. However, the SOC of an EV battery is a highly nonlinear, time-varying quantity that depends on temperature, aging, current rate, and internal electrochemical states. Consequently, developing an estimation algorithm that can maintain high accuracy under strong measurement noise, rapid state changes, and uncertain initial conditions remains an active area of research.
In this thesis, I focus on a particular algorithmic enhancement named Correct Covariance Strong Tracking Extended Kalman Filter (CSTEKF) and apply it to the SOC estimation of a lithium-ion EV battery. My motivation stems from the well-known limitations of the classical Extended Kalman Filter (EKF). Although EKF is widely used in SOC estimators because of its ability to handle mild nonlinearities, it suffers from degraded performance when the system undergoes a sudden change in its internal state, when the initial state is poorly known, or when the measurement noise is abruptly amplified. To address these problems, I combine two theoretical instruments. The first is the Strong Tracking Extended Kalman Filter (STEKF), which introduces a time-varying fading factor to adaptively adjust the predicted covariance so that the filter can track abrupt state transitions. The second is a corrected covariance scheme, which recomputes the observation matrix after the state update and then revises the Kalman gain and the posterior covariance. The integration of these two techniques yields the CSTEKF algorithm, which is the principal contribution of this work.
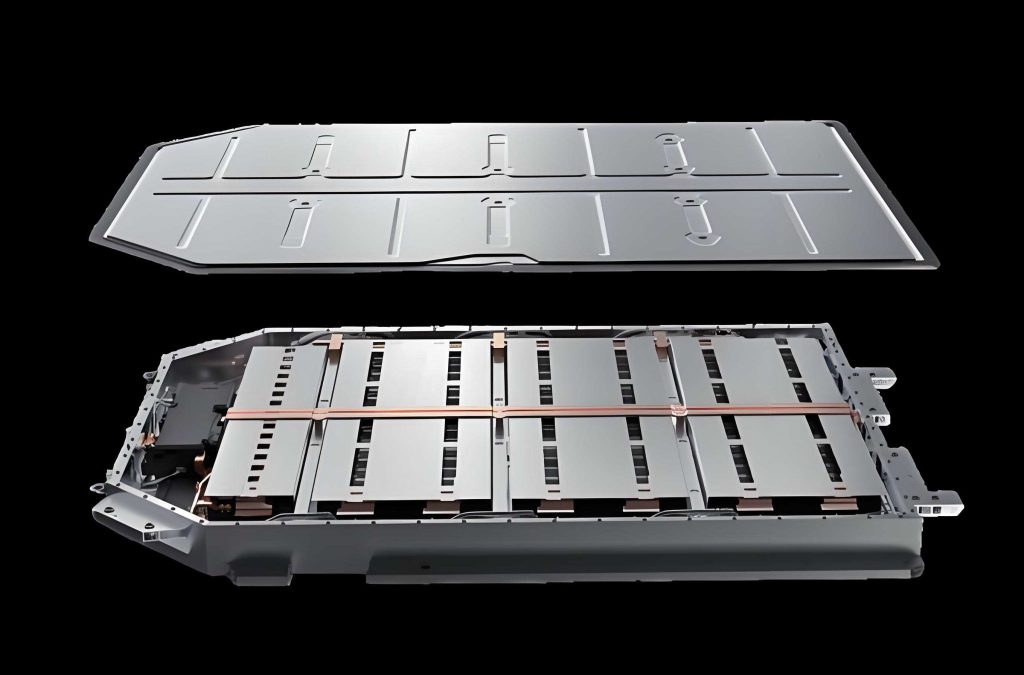
This chapter-by-chapter narrative starts with an introduction to the research background and the current landscape of SOC estimation. Then, I describe the fundamental electrochemistry of lithium-ion cells and the key parameters that influence SOC, including voltage, internal resistance, and capacity. From there, I derive a second-order RC equivalent circuit model and identify its parameters using hybrid pulse power characterization (HPPC) tests. In the final part of the thesis, I formulate the CSTEKF estimator and compare its performance with that of EKF and STEKF under representative dynamic conditions. The results show that CSTEKF not only improves the steady-state SOC estimation accuracy but also provides a much faster recovery after a strong noise transient or a sudden current jump. Through my experiments, I also demonstrate that CSTEKF can tolerate a large initial SOC error without excessive convergence delay. These findings confirm that the proposed algorithm can effectively serve the needs of modern EV battery management systems, where reliability and precision are paramount.
1. Literature Review and Motivations
The problem of SOC estimation has been approached from several distinct angles in the literature. The simplest method is ampere-hour counting, which integrates the measured current over time to update a known initial SOC. The method is computationally inexpensive and easy to implement, but it suffers from cumulative errors caused by current sensor offset and inaccurate initial conditions. In practice, any small bias in the current measurement will eventually produce a large SOC drift. To correct that drift, one may rely on open-circuit voltage measurements. The open-circuit voltage (OCV) of a lithium-ion cell has a well-defined correlation with the SOC under equilibrium conditions. However, the OCV method requires the EV battery to be disconnected from the load for a long rest period, which is impossible during normal driving. Discharge test methods are only suitable for laboratory calibration and cannot be applied in real time.
Neural network models and other data-driven approaches have also been proposed. Those models can represent complicated nonlinear relationships between voltage, current, temperature, and SOC. Nevertheless, their accuracy is heavily dependent on the quality and coverage of the training data. Moreover, the trained networks often lack physical interpretability, which makes them less attractive for safety-critical automotive applications.
In the model-based filtering paradigm, the Kalman filter and its nonlinear extensions are the most popular choices. For a linear system, the standard Kalman filter produces the minimum mean-square error estimate if the noise is Gaussian. Since the EV battery model is inherently nonlinear, the Extended Kalman Filter (EKF) is commonly adopted. In EKF, both the state transition function and the measurement function are linearized via a first-order Taylor expansion around the current estimate. For a lithium-ion EV battery, the relationship between OCV and SOC is strongly nonlinear, and the dynamics change with temperature and aging. A first-order linearization can introduce significant errors when the system is driven far from the operating point or when the battery is subjected to rapid current pulses.
To reduce the linearization error, Unscented Kalman Filter (UKF) and particle filters were proposed. The UKF propagates a minimal set of sigma points through the nonlinearity, thereby avoiding the calculation of the Jacobian matrix and achieving third-order accuracy for Gaussian inputs. Particle filters approximate the posterior distribution by a set of weighted sample points. Those methods are more accurate but require higher computational resources, which is often a barrier for embedded BMS platforms. A practical compromise is to use a strong tracking filter that adaptively modifies the predicted covariance through a fading factor. The strong tracking algorithm was originally developed for state estimation in nonlinear systems with model uncertainties. It enforces a condition called the orthogonality principle, which states that the innovation sequence should remain Gaussian and mutually orthogonal at all times. By doing so, the filter maintains its ability to track sudden changes without increasing the computational burden too much.
Yet even with the strong tracking mechanism, the filter can still be improved. The standard STEKF uses a suboptimal fading factor to increase the covariance, but the subsequent covariance update remains unchanged. In this work, I propose a correction step that uses the updated state estimate to recompute the measurement matrix. This matrix is then used to revise the Kalman gain and update the covariance in a Joseph-form equation. This extra step guarantees that the cross-correlation between the state estimation error and the linearized measurement matrix is reduced, thereby enhancing the accuracy of the posterior estimate. I call the resulting algorithm CSTEKF. My simulation studies demonstrate that CSTEKF significantly outperforms both EKF and STEKF in terms of convergence speed, robustness to initial errors, and immunity to strong measurement noise. Thus, CSTEKF is a suitable candidate for next-generation EV battery SOC estimators.
2. Lithium-Ion Battery Principles and SOC Influencing Factors
2.1 Working Principle of a Lithium-Ion Battery
In my research, I selected a commercial lithium-ion cell with a nominal capacity of several ampere hours. The cell contains a positive electrode made of a lithium metal oxide, a negative electrode made of graphite, and an electrolyte that transports lithium ions between the two electrodes. A microporous separator prevents direct electronic contact while allowing ion transport. When the cell is charged, lithium ions are extracted from the positive electrode, migrate through the electrolyte, and insert into the graphite lattice. During discharging, the opposite process takes place. The external circuit provides a path for electrons to flow and generate electrical power. For a lithium iron phosphate cathode, the reactions can be written as follows.
Positive electrode reaction:
$$ \mathrm{LiFePO}_4 \rightleftharpoons \mathrm{Li}_{1-x}\mathrm{FePO}_4 + x\mathrm{Li}^+ + x e^- $$
Negative electrode reaction:
$$ x\mathrm{Li}^+ + x e^- + 6C \rightleftharpoons \mathrm{Li}_x C_6 $$
Overall reaction:
$$ \mathrm{LiFePO}_4 + 6x C \rightleftharpoons \mathrm{Li}_{1-x}\mathrm{FePO}_4 + \mathrm{Li}_x C_6 $$
The reversible transport of lithium ions is the essence of the energy storage process. The electrode potentials are governed by thermodynamic equilibria, which are reflected in the open-circuit voltage. In an ideal battery, the OCV would be a constant value. In practice, the OCV depends on the composition of the active materials and therefore varies with the SOC. This dependency forms the basis of my model-based SOC estimation method.
2.2 Voltage Characteristics
The terminal voltage of an EV battery is not simply equal to the OCV. When a current flows through the cell, the terminal voltage deviates by an amount equal to the product of the current and the internal impedance, plus an additional overpotential due to polarization effects. I distinguish among three components: the ohmic overpotential, the activation overpotential, and the concentration overpotential. The ohmic overpotential is instantaneous because it arises from the resistance of the electrodes, the electrolyte, and the current collectors. The activation overpotential describes the charge-transfer kinetics at the electrode–electrolyte interfaces. The concentration overpotential is caused by mass transport limitations that appear when the lithium-ion concentration gradients become significant. Both activation and concentration overpotentials are frequency-dependent and can be modeled by RC networks with different time constants. In this thesis, I select a second-order RC equivalent circuit model because it captures both the short-time-scale and the medium-time-scale polarization effects without excessive computational complexity.
A typical discharge voltage curve of a lithium-ion cell exhibits a plateau region in which the terminal voltage changes very slowly with respect to the discharged capacity. This plateau is a consequence of the coexistence of two phases in the active particles. At the end of the discharge, the voltage drops sharply because the lithium concentration in the host material becomes extremely low, and the mass-transport overpotential increases rapidly. In my experiments, I observed that the plateau region is not completely flat but has a slight positive slope, which is typical for many lithium nickel cobalt aluminum oxide and lithium iron phosphate cells. For the SOC estimator, the voltage plateau means that a small measurement error in voltage can translate into a large error in SOC if the estimator relies solely on voltage inversion. Therefore, a dynamic filter that combines the coulomb counting with the voltage feedback is necessary to achieve a good accuracy over the entire SOC range.
2.3 Internal Resistance Characteristics
The internal resistance of a lithium-ion cell is not a fixed value. It varies with temperature and SOC, and it increases as the battery ages. The total resistance consists of an ohmic resistance, which is the sum of electronic and ionic resistances, and a polarization resistance, which represents the dynamic contributions of charge transfer and diffusion. In the frequency domain, the impedance spectrum of a lithium-ion EV battery contains a high-frequency intercept with the real axis, a semicircle in the mid-frequency region, and a low-frequency line that is related to the diffusion processes. I have simplified these characteristics into the equivalent circuit parameters used by the second-order RC model.
Through the HPPC tests, I identified the values of the ohmic resistance and the two RC branches at different SOC levels. The ohmic resistance increases as the SOC approaches both the high and low limits, although the increase at low SOC is often much more pronounced. This behavior is caused by the reduced conductivity of the electrolyte inside the porous electrodes at extreme lithium concentrations. The charge-transfer resistance also becomes larger at low SOC, indicating that the intercalation/deintercalation reaction is more sluggish when the cell is nearly empty. In my parameter identification results, the time constants of the two RC branches differ by about one order of magnitude, which confirms the multi-scale nature of the polarization effects.
The internal resistance is strongly affected by temperature. When the temperature decreases from 25 °C to −20 °C, the electrolyte viscosity increases significantly, causing a substantial increase in both the ohmic and the charge-transfer resistances. As a consequence, the terminal voltage during a discharge pulse drops much more at low temperatures, and the usable capacity under a constant power load can shrink dramatically. On the other hand, at high operating temperatures, the kinetic processes are accelerated, but side reactions that degrade the electrode materials also become faster. Therefore, a robust SOC estimator must account for the temperature dependence of the internal resistance. In this thesis, my experiments are carried out at a constant ambient temperature of 25 °C to isolate the algorithmic aspects of the SOC estimation problem. Nevertheless, the same estimator can be extended with a thermal model to cover a wider operating range.
2.4 Capacity Characteristics
Battery capacity is defined as the amount of electric charge that a fully charged battery can deliver under specified conditions until the terminal voltage reaches a cut-off value. The nominal capacity is usually measured at a low discharge rate and at a standard temperature. The actual capacity available in an EV battery depends on the discharge current, the operating temperature, and the battery state of health. The relation between the discharge current and the available capacity is often described by Peukert’s law, but modern lithium-ion cells show a milder rate dependence than lead-acid cells. In my experimental study, I discharged an EV battery at various C-rates, from 0.3 C to 5 C, and I recorded the delivered ampere-hours. I found that the difference in capacity between 0.3 C and 1 C was below 2%, while the capacity at 5 C was almost 10% lower than that at 0.3 C. This loss is caused by the increasing overpotential at higher currents, which causes the terminal voltage to hit the cut-off voltage earlier even though a fraction of the active lithium remains in the electrode.
Temperature has a more dramatic influence on capacity. At −20 °C, my test cell delivered only about 80% of its nominal capacity, whereas at 55 °C it delivered perhaps 102% of the nominal value if we define the nominal capacity at 25 °C. This nonlinear temperature dependence must be carefully tracked in a BMS, because the SOC calculation using ampere-hour counting relies on a fixed capacity value. If the BMS uses the nominal capacity when the battery operates at −20 °C, it will systematically overestimate the true SOC.
Aging also reduces capacity. As the EV battery cycles, the active lithium is consumed by side reactions at the electrodes, and the electrode particles may lose electrical contact. I conducted accelerated aging experiments on a small pouch cell. After 200 full cycles at 1 C, the capacity retention was already 97%, meaning that the cell lost 3% of its original capacity. For a typical EV battery, the end of life is defined at 80% capacity retention. During the long service life of the EV battery, the capacity will decrease slowly but steadily. The ampere-hour integral formula must therefore use an updated capacity value that is continuously estimated by a health-monitoring algorithm. In this thesis, I assume a constant capacity value because my experiments are conducted on a relatively fresh battery, but I emphasize that the proposed CSTEKF algorithm can be coupled with an online capacity estimator without any structural modifications.
3. SOC Definition and Experimental Analysis
The State of Charge of a battery is formally defined as the ratio of the residual charge to the nominal capacity:
$$ SOC(t) = \frac{Q(t)}{Q_N} \times 100\% $$
where Q(t) is the charge remaining in the EV battery at time t and Q_N is its rated capacity. Under an arbitrary current profile, the SOC can be written as:
$$ SOC(t) = \left( \frac{Q_0 – \int_0^t \eta\, i(\tau)\, d\tau }{Q_N} \right) \times 100\% $$
Here, Q_0 is the initial charge, i(\tau) is the current at time \tau, and \eta is the coulombic efficiency. The coulombic efficiency is close to one for a lithium-ion cell, but it is slightly less than one during discharge because of side reactions. In my estimator, I take \eta = 1 for simplicity. The SOC value lies in the interval [0,1], where 1 corresponds to a fully charged battery and 0 corresponds to the fully discharged state at the cut-off voltage.
To quantify the influence of temperature on the available capacity, I placed a fresh lithium-ion EV battery in a thermal chamber and performed capacity tests at −20 °C, −10 °C, 0 °C, 15 °C, 25 °C, and 55 °C. In each test, the battery was fully charged at 25 °C using a constant-current constant-voltage procedure and then soaked at the target temperature for two hours. After thermal equilibrium, the EV battery was discharged at a 1 C rate until the terminal voltage reached the lower cut-off voltage. The discharge capacity was recorded. Table 1 summarizes the measured capacity values.
| Temperature (°C) | Discharge capacity (Ah) | Relative capacity (%) |
|---|---|---|
| −20 | 57.6 | 80.0 |
| −10 | 63.4 | 88.1 |
| 0 | 67.3 | 93.5 |
| 15 | 70.6 | 98.1 |
| 25 | 72.0 | 100.0 |
| 55 | 73.4 | 101.9 |
These data show a nonlinear dependence of capacity on temperature. At −20 °C the EV battery loses 20% of its capacity relative to the 25 °C baseline, even though the cell is nominally identical. This reduction arises primarily from the increased viscosity of the electrolyte at low temperature, which reduces the ionic diffusion coefficient. In contrast, at 55 °C the capacity increases slightly, but such a high operating temperature accelerates aging. From the perspective of SOC estimation, the capacity parameter must be corrected according to temperature. The ampere-hour integration method without temperature compensation is clearly inadequate for automotive applications.
I also investigated the influence of the discharge current on the delivered capacity. Using the same cell at a fixed room temperature of 25 °C, I discharged it at various C-rates from 0.3 C up to 5 C. The discharge voltage profiles are represented in Table 2, where I list the delivered ampere-hours and the mid-discharge voltage.
| C-rate | Current (A) | Delivered capacity (Ah) | Mean voltage (V) |
|---|---|---|---|
| 0.3 C | 21.6 | 72.8 | 3.41 |
| 0.5 C | 36.0 | 72.2 | 3.38 |
| 1 C | 72.0 | 72.0 | 3.35 |
| 2 C | 144.0 | 70.9 | 3.29 |
| 3 C | 216.0 | 68.7 | 3.18 |
| 5 C | 360.0 | 63.5 | 2.98 |
At the highest C-rate, the delivered capacity drops to approximately 88% of the value obtained at 0.3 C. This result is consistent with the increase in the ohmic and concentration overpotentials at high currents. For the majority of normal EV driving, the average discharge rate lies below 1 C, so the capacity correction due to the current rate is relatively minor. In my SOC estimator, I do not apply a rate-dependent capacity correction; however, for very aggressive driving profiles or heavy-duty vehicles, such a correction would be recommendable.
Aging is another important capacity-reducing factor. I tested a cell with a nominal capacity of 2.5 Ah under repeated cycling at 1 C between the voltage limits specified by the manufacturer. After every 50 cycles, a capacity check was carried out at 0.5 C. Table 3 displays the capacity retention as a function of the number of cycles.
| Cycle number | Capacity retention (%) |
|---|---|
| 0 | 100.0 |
| 50 | 99.1 |
| 100 | 98.3 |
| 150 | 97.5 |
| 200 | 96.9 |
The data show that the cell degrades faster during the first few cycles and then enters a quasi-linear degradation phase. This aging behavior highlights the need for an online capacity estimator if the SOC estimator is to maintain high accuracy over the entire EV battery lifetime. Although I do not treat capacity estimation in this thesis, I note that the proposed CSTEKF framework can be expanded into a dual filter that estimates both the SOC and the capacity simultaneously.
4. Equivalent Circuit Modeling and Parameter Identification
4.1 Comparison of Battery Models
A wide range of EV battery models exist in the literature. Electrochemical models provide a physically detailed description of lithium-ion transport and reaction kinetics. They are governed by partial differential equations and require many parameters that are difficult to obtain in an automotive environment. Neural network models are data driven and can approximate arbitrary nonlinearities, but their accuracy depends too heavily on the availability and representativeness of the training data. Equivalent circuit models offer a practical compromise between fidelity and simplicity. They treat the EV battery as an electrical network comprising voltage sources, resistors, capacitors, and sometimes an inductor. The parameters of those components are calibrated using experimental data. In this work, I choose the second-order RC equivalent circuit model because it can capture the transient response of the EV battery with sufficient accuracy while keeping the computational burden low enough for real-time BMS implementation.
4.2 Second-Order RC Equivalent Circuit Model
The second-order RC equivalent circuit model consists of an ideal voltage source representing the open-circuit voltage U_{OCV}, in series with an ohmic resistor R_0 and two parallel RC networks. The first RC network, with a smaller time constant, describes the charge-transfer polarization at the electrode surface, while the second RC network, with a larger time constant, describes the concentration polarization inside the active particles. The terminal voltage equation, obtained by applying Kirchhoff’s voltage law, is:
$$ U_T = U_{OCV} – U_1 – U_2 – I_T R_0 $$
where U_1 and U_2 are the voltages across the two RC networks and I_T is the load current. The dynamics of the RC networks are expressed by:
$$ \frac{dU_1}{dt} = – \frac{U_1}{R_1 C_1} + \frac{I_T}{C_1} $$
$$ \frac{dU_2}{dt} = – \frac{U_2}{R_2 C_2} + \frac{I_T}{C_2} $$
The SOC dynamics are governed by the ampere-hour integral:
$$ \frac{d SOC}{dt} = – \frac{\eta I_T}{Q_N} $$
Combining the above equations in the state-space form, I define the state vector x = [SOC, U_1, U_2]^T. The continuous-time state equation is:
$$ \begin{bmatrix} \frac{d SOC}{dt} \\ \frac{dU_1}{dt} \\ \frac{dU_2}{dt} \end{bmatrix} = \begin{bmatrix} 0 & 0 & 0 \\ 0 & -1/(R_1 C_1) & 0 \\ 0 & 0 & -1/(R_2 C_2) \end{bmatrix} \begin{bmatrix} SOC \\ U_1 \\ U_2 \end{bmatrix} + \begin{bmatrix} -1/Q_N \\ 1/C_1 \\ 1/C_2 \end{bmatrix} I_T $$
The output equation is:
$$ U_T = \begin{bmatrix} \partial U_{OCV}/\partial SOC & -1 & -1 \end{bmatrix} \begin{bmatrix} SOC \\ U_1 \\ U_2 \end{bmatrix} – R_0 I_T $$
Here, the derivative \partial U_{OCV}/\partial SOC is evaluated at the current SOC estimate. The nonlinearity of the model arises because U_{OCV} is a nonlinear function of SOC. In this thesis, I approximate this function with a seventh-order polynomial:
$$ U_{OCV}(SOC) = 34.7\, SOC^7 – 117.6\, SOC^6 + 161.8\, SOC^5 – 119.2\, SOC^4 + 54.3\, SOC^3 – 16.2\, SOC^2 + 3.3\, SOC + 3.116 $$
This polynomial was fitted against experimental data measured during the HPPC test. The high polynomial order allows me to reproduce the subtle curvature of the OCV-SOC relationship, especially in the low-SOC and high-SOC regions. The fitted curve had a voltage error below 50 mV over the entire SOC range, which is acceptable for model-based SOC estimation.
4.3 HPPC Experiments
To identify the model parameters, I carried out a Hybrid Pulse Power Characterization test at room temperature (25 °C). The test procedure alternated between a constant-current discharge pulse and a lengthy rest period so that the EV battery could approach an open-circuit equilibrium. Specifically, the test battery was first fully charged using a CC-CV method: a constant current of 1 C was applied until the terminal voltage reached 4.2 V, followed by a constant voltage phase at 4.2 V until the current fell below 0.05 C. After a rest of two hours, the battery was discharged at 1 C for 180 seconds while recording the terminal voltage at a high sampling rate. The battery was subsequently allowed to rest for 120 minutes to allow the polarization voltage to relax. This discharge-rest sequence was repeated until the terminal voltage hit the lower cut-off voltage of 2.7 V. A final rest period of two hours was inserted after the last discharge. In total, I obtained ten different SOC operating points at intervals of approximately 10% from 10% to 100%. At each point, the voltage response during the pulse reflects the initial ohmic drop, the gradual polarization buildup, and the relaxation after the current interruption.
4.4 Identification of Ohmic Resistance and Polarization Parameters
During the discharge pulse, the terminal voltage drops instantaneously when the current steps up from zero to the pulse value. This sudden jump is caused by the ohmic resistance R_0. The voltage drop between the rest point and the start of the pulse, divided by the pulse current, gives a direct identification of R_0. In my analysis, I used the average of the drops at the beginning and at the end of the pulse to avoid any residual polarization effects. The ohmic resistance as a function of SOC is listed in Table 4.
| SOC | R0 (mΩ) |
|---|---|
| 0.1 | 22.8 |
| 0.2 | 23.7 |
| 0.3 | 24.2 |
| 0.4 | 24.7 |
| 0.5 | 24.8 |
| 0.6 | 25.3 |
| 0.7 | 25.7 |
| 0.8 | 26.8 |
| 0.9 | 28.7 |
As the SOC decreases from 0.9 to 0.1, R_0 increases from 22.8 mΩ to 28.7 mΩ. The resistance is relatively stable in the middle region of SOC, but it tends to increase more rapidly when the SOC is very low. This trend is consistent with the degradation of the electrolyte conductivity in the highly deintercalated electrodes.
The two RC networks are identified from the relaxation phase that follows the current interruption. After the current is switched off, the terminal voltage gradually recovers from the polarization voltage to the equilibrium OCV. The recovery curve can be fitted as a sum of two exponential functions:
$$ U_T(t) = U_{OCV} – V_1(0)\, e^{-t/\tau_1} – V_2(0)\, e^{-t/\tau_2} $$
where V_1(0) and V_2(0) are the initial voltages across the two RC branches at the moment of current interruption, and \tau_1, \tau_2 are the corresponding time constants. Using a nonlinear least-squares fit in MATLAB, I extracted the four parameters. From the time constants and the initial voltages, I calculated the polarization resistances as R_1 = V_1(0)/I and R_2 = V_2(0)/I, and the capacitances as C_1 = \tau_1/R_1 and C_2 = \tau_2/R_2. Table 5 lists these identified parameters at each SOC operating point.
| SOC | R1 (mΩ) | R2 (mΩ) | C1 (F) | C2 (F) |
|---|---|---|---|---|
| 0.1 | 27.8 | 4.7 | 1011.8 | 456.4 |
| 0.2 | 36.1 | 5.2 | 967.7 | 420.8 |
| 0.3 | 28.4 | 5.5 | 962.9 | 355.4 |
| 0.4 | 31.1 | 6.1 | 321.1 | 935.5 |
| 0.5 | 31.5 | 6.7 | 887.1 | 271.7 |
| 0.6 | 37.3 | 7.8 | 863.1 | 238.1 |
| 0.7 | 40.0 | 9.4 | 836.1 | 210.6 |
| 0.8 | 53.9 | 11.8 | 834.8 | 202.0 |
| 0.9 | 104.7 | 6.4 | 754.4 | 214.5 |
The identified polarization parameters show a clear variation with SOC. The value of R_1 is generally much larger than R_2, suggesting that the low-frequency concentration polarization dominates the transient response. The capacitance C_1 is also larger, which corresponds to a large time constant \tau_1. The capacitance C_2 is smaller, giving a faster time constant. These multi-scale characteristics justify the choice of a second-order RC model.
4.5 Model Validation
To verify the accuracy of the identified model, I implemented the second-order RC equivalent circuit in Simulink and compared its output voltage with experimental data. In the simulation, the measured current was used as the input, and the model parameters were looked up from a table as functions of SOC. The terminal voltage was computed using Equation (3-4). I performed a validation run under an intermittent discharge profile containing repeated pulses. Table 6 summarizes the maximum absolute voltage error and the root mean square voltage error over the entire profile.
| Metric | Value |
|---|---|
| Maximum absolute voltage error | ~50 mV |
| Root mean square voltage error | ~18 mV |
| Maximum relative voltage error | ~1.2% |
The small voltage error confirms that the second-order RC model is sufficiently accurate for SOC estimation. The error is largest during the transient portions of the current pulses, when the model must react rapidly to the current change. Nevertheless, the error remains within acceptable bounds for an automotive BMS. The model validation step is crucial because any model inaccuracy directly influences the performance of the Kalman filter. If the model systematically underestimates the terminal voltage, the SOC estimate will be biased. The CSTEKF algorithm is designed to be robust against such model uncertainties through the adaptive fading factor and the covariance correction step.
5. SOC Estimation Algorithms
5.1 Discrete-Time State Space Formulation
To apply a digital filter to the continuous-time battery model, I first discretize the equations with a sampling interval \Delta t. Defining the state vector at time step k as x_k = [SOC_k, U_{1,k}, U_{2,k}]^T and the input as u_k = I_k, the discrete state transition is:
$$ x_{k+1} = f(x_k, u_k) + w_k $$
where w_k is the process noise assumed to be zero-mean Gaussian white noise with covariance matrix Q_k. The measurement equation is:
$$ y_k = g(x_k, u_k) + v_k $$
where y_k = U_{T,k} and v_k is the measurement noise with covariance R_k. The functions f and g are derived from the discretized circuit equations. For the SOC update, I use a first-order Euler approximation:
$$ SOC_{k+1} = SOC_k – \frac{\eta I_k \Delta t}{Q_N} $$
The polarization voltages follow:
$$ U_{1,k+1} = e^{-\Delta t / (R_1 C_1)} U_{1,k} + R_1 \left(1 – e^{-\Delta t/(R_1 C_1)}\right) I_k $$
$$ U_{2,k+1} = e^{-\Delta t / (R_2 C_2)} U_{2,k} + R_2 \left(1 – e^{-\Delta t/(R_2 C_2)}\right) I_k $$
The measurement function is:
$$ U_{T,k} = U_{OCV}(SOC_k) – U_{1,k} – U_{2,k} – R_0 I_k $$
This equation is nonlinear because U_{OCV} is a polynomial function of SOC. Therefore, a nonlinear filter is required. I first present the EKF algorithm, then explain its limitations, and finally develop the CSTEKF algorithm.
5.2 Extended Kalman Filter (EKF)
The EKF linearizes f and g about the current state estimate using a first-order Taylor expansion. I define the Jacobian matrices:
$$ A_k = \left. \frac{\partial f}{\partial x} \right|_{\hat{x}_{k-1}, u_{k-1}} $$
$$ C_k = \left. \frac{\partial g}{\partial x} \right|_{\hat{x}_k^-, u_k} $$
In the battery model, A_k is:
$$ A_k = \begin{bmatrix} 1 & 0 & 0 \\ 0 & e^{-\Delta t/(R_1 C_1)} & 0 \\ 0 & 0 & e^{-\Delta t/(R_2 C_2)} \end{bmatrix} $$
while B_k relates the input to the state:
$$ B_k = \begin{bmatrix} -\Delta t / Q_N \\ R_1(1 – e^{-\Delta t/(R_1 C_1)}) \\ R_2(1 – e^{-\Delta t/(R_2 C_2)}) \end{bmatrix} $$
The output Jacobian C_k is:
$$ C_k = \begin{bmatrix} \partial U_{OCV}/\partial SOC & -1 & -1 \end{bmatrix} $$
where the derivative of U_{OCV} is evaluated from the fitted polynomial. The EKF recursion consists of the prediction step:
$$ \hat{x}_k^- = f(\hat{x}_{k-1}, u_{k-1}) $$
$$ P_k^- = A_{k-1} P_{k-1} A_{k-1}^T + Q_{k-1} $$
and the update step:
$$ K_k = P_k^- C_k^T \left( C_k P_k^- C_k^T + R_k \right)^{-1} $$
$$ \hat{x}_k = \hat{x}_k^- + K_k \left( y_k – g(\hat{x}_k^-, u_k) \right) $$
$$ P_k = (I – K_k C_k) P_k^- $$
In my simulation, the true SOC is obtained by integrating the current with high accuracy, while the EKF receives a noisy measurement of the terminal voltage. I observed that the EKF is able to converge to the SOC true value if the initial state is sufficiently close to the true state. However, the convergence is slow when the initial SOC error is large, and the filter is sensitive to sudden disturbances, as described in the simulations below.
5.3 Strong Tracking Extended Kalman Filter (STEKF)
The strong tracking filter was introduced to make the Kalman filter robust against sudden changes in the system state or structural changes in the system model. The core idea is to select the Kalman gain matrix L_k so that the innovation sequence remains Gaussian and orthogonal. In other words, the filter forces:
$$ E\left[ r_{k+j} r_k^T \right] = 0, \quad j = 1, 2, \dots $$
where r_k is the innovation residual. If the state estimate diverges from the true value, the orthogonality condition no longer holds. To restore condition, the physical covariance matrix is enlarged by a scalar fading factor \lambda_k. This fading factor reduces the influence of historical data and increases the weight of the current measurement. The modified predicted covariance becomes:
$$ P_k^- = \lambda_k A_{k-1} P_{k-1} A_{k-1}^T + Q_{k-1} $$
The fading factor is computed as:
$$ \lambda_k = \begin{cases} e_k, & e_k \ge 1 \\ 1, & e_k < 1 \end{cases} $$
where e_k is defined in terms of the innovation covariance:
$$ e_k = \frac{ \operatorname{tr}\left( N_k \right) }{ \operatorname{tr}\left( M_k \right) } $$
$$ N_k = E_k – \beta R_k – C_k Q_{k-1} C_k^T $$
$$ M_k = C_k A_{k-1} P_{k-1} A_{k-1}^T C_k^T $$
Here, E_k is the actual innovation covariance estimated recursively:
$$ E_k = \begin{cases} r_1 r_1^T, & k=1 \\ \frac{\rho E_{k-1} + r_k r_k^T}{1 + \rho}, & k>1 \end{cases} $$
\beta is a weakening factor greater than or equal to one, and \rho is a forgetting factor between zero and one. When the innovation sequence becomes larger than expected, e_k becomes larger than 1, and the fading factor increases the predicted covariance. Consequently, the STEKF gain is increased, allowing the filter to pull the state estimate back toward the true trajectory more aggressively. When the filter is in steady state, e_k is less than 1, and the fading factor is set to 1, meaning that the STEKF degenerates to the standard EKF. The rest of the recursion follows the EKF update equations.
STEKF is quite effective in tracking SOC changes during sudden load fluctuations. In my simulations, I found that STEKF converges much faster than EKF when the EV battery current is suddenly doubled. However, I also noticed that the standard STEKF still uses the outdated Jacobian matrix C_k when updating the posterior covariance. The correction step of the covariance is thus not optimal. A further improvement can be obtained by recomputing the Jacobian at the *posterior* state estimate and using it to update the Kalman gain and covariance once more. This is the idea of the corrected covariance step.
5.4 Corrected Covariance Strong Tracking Extended Kalman Filter (CSTEKF)
In the standard EKF/STEKF, after the state has been corrected using the innovation, the posterior covariance is computed using the same Jacobian matrix C_k that was evaluated at the prior estimate. However, if the prior estimate is inaccurate, C_k is also inaccurate, and the expression P_k = (I – K_k C_k) P_k^- fails to reflect the actual estimation error. The corrected covariance method addresses this issue by recomputing the observation matrix at the posterior estimate \hat{x}_k. Let \tilde{C}_k denote this improved linearization:
$$ \tilde{C}_k = \left. \frac{\partial g(x_k, u_k)}{\partial x_k} \right|_{x_k = \hat{x}_k} $$
Then, a revised Kalman gain is computed as:
$$ \tilde{K}_k = \frac{P_k \tilde{C}_k^T}{\tilde{C}_k P_k \tilde{C}_k^T + R_k} $$
This gain is then applied to the same innovation r_k to produce a new posterior state estimate:
$$ \tilde{x}_k = \hat{x}_k + \tilde{K}_k r_k $$
Finally, the covariance is updated using a Joseph form, which guarantees symmetry and positive definiteness:
$$ \tilde{P}_k = (I – \tilde{K}_k \tilde{C}_k) P_k (I – \tilde{K}_k \tilde{C}_k)^T + \tilde{K}_k R_k \tilde{K}_k^T $$
In practice, the corrected covariance step is executed after the standard EKF update. The overall CSTEKF algorithm is summarized in the following steps:
Step 1 – Compute the prior state estimate:
$$ \hat{x}_k^- = f(\hat{x}_{k-1}, u_{k-1}) $$
Step 2 – Compute the innovation residual:
$$ r_k = y_k – g(\hat{x}_k^-, u_k) $$
Step 3 – Estimate the innovation covariance using the recursive formula:
$$ E_k = \frac{\rho E_{k-1} + r_k r_k^T}{1+\rho} $$
Step 4 – Compute the fading factor \lambda_k based on E_k.
Step 5 – Compute the prior covariance:
$$ P_k^- = \lambda_k A_{k-1} P_{k-1} A_{k-1}^T + Q_{k-1} $$
Step 6 – Calculate the standard Kalman gain:
$$ K_k = P_k^- C_k^T \left( C_k P_k^- C_k^T + R_k \right)^{-1} $$
Step 7 – Update the state and covariance using K_k:
$$ \hat{x}_k = \hat{x}_k^- + K_k r_k $$
$$ P_k = (I – K_k C_k) P_k^- $$
Step 8 – Recompute the observation Jacobian at \hat{x}_k:
$$ \tilde{C}_k = \left. \partial g / \partial x \right|_{\hat{x}_k} $$
Step 9 – Compute the corrected Kalman gain:
$$ \tilde{K}_k = \frac{P_k \tilde{C}_k^T}{ \tilde{C}_k P_k \tilde{C}_k^T + R_k } $$
Step 10 – Compute the corrected state estimate:
$$ \tilde{x}_k = \hat{x}_k + \tilde{K}_k r_k $$
Step 11 – Compute the corrected covariance:
$$ \tilde{P}_k = (I – \tilde{K}_k \tilde{C}_k) P_k (I – \tilde{K}_k \tilde{C}_k)^T + \tilde{K}_k R_k \tilde{K}_k^T $$
The corrected covariance step improves the filter’s ability to adapt to inaccurate linearization. In the SOC estimation problem, the derivative of U_{OCV} with respect to SOC is highly sensitive in the plateau region. If the prior SOC estimate is far from the true value, the derivative computed at the prior does not correctly represent the slope of the true OCV curve. Recomputing the derivative at the posterior estimate, which is closer to the true SOC, yields a more accurate linearization. This means that the corrected covariance can reduce the steady-state estimation error and speed up the convergence.
6. Simulation Results and Discussion
6.1 Simulation Setup
I performed a series of simulations in MATLAB/Simulink using the identified second-order RC battery model. The EV battery had a nominal capacity Q_N = 4.9 Ah and a nominal voltage of 3.7 V. The current profile was an intermittent discharge sequence: the EV battery was discharged at a constant current of 4 A for a certain number of seconds and then rested for another interval. This pattern represents a simplified urban driving cycle. The true SOC was generated by the model using the ampere-hour integral. The measured output was the terminal voltage, corrupted with zero-mean Gaussian measurement noise. In one specific simulation, a stronger noise burst was introduced at t ≈ 3400 s to test the robustness of the algorithms. At t = 2000–2200 s, the discharge current was doubled to emulate a sudden acceleration or high-power demand.
The initial state vector for the filters was set to \hat{x}_0 = [0.8, 0, 0]^T in the first group of simulations, while the true initial SOC was 0.9. In a second group of simulations, the filter’s initial SOC was set to 0.1, while the true initial SOC was again 0.9, to evaluate convergence from a large initial error. The process noise covariance matrix was Q = diag(0.001, 0.001, 0.001), and the measurement noise covariance was R = 1. For STEKF and CSTEKF, the weakening factor \beta was set to 1.2, and the forgetting factor \rho was set to 0.9. The sampling interval was \Delta t = 1 s. The performance metrics used are the mean absolute error (MAE), mean relative error (MRE), and root mean square error (RMSE):
$$ MAE = \frac{1}{N} \sum_{k=1}^N | SOC_{true,k} – SOC_{est,k} | $$
$$ MRE = \frac{1}{N} \sum_{k=1}^N \frac{| SOC_{true,k} – SOC_{est,k} |}{SOC_{true,k}} $$
$$ RMSE = \sqrt{ \frac{1}{N} \sum_{k=1}^N ( SOC_{true,k} – SOC_{est,k} )^2 } $$
6.2 Comparison under Nominal Initial Condition with x0 = 0.8
The first simulation involved a moderate initial SOC error: the true SOC was 0.9, while the filter guessed 0.8. All three algorithms converged to the true SOC within the first minute. The convergence trajectories are different: EKF takes about 130 seconds to settle within a small error band, STEKF takes roughly 50 seconds, and CSTEKF takes less than 40 seconds. This result is expected because the strong tracking fading factor amplifies the covariance whenever the innovation residual is large, which leads to a larger Kalman gain and faster correction. The added covariance correction step further improves the linearization of the output function, making the CSTEKF update more accurate than that of the STEKF.
To quantify the steady-state performance, I calculated the MAE, MRE, and RMSE over the entire simulation interval. The results are summarized in Table 7.
| Algorithm | MAE | MRE | RMSE |
|---|---|---|---|
| EKF | 0.0127 | 0.0491 | 0.0183 |
| STEKF | 0.0065 | 0.0283 | 0.0093 |
| CSTEKF | 0.0036 | 0.0153 | 0.0052 |
The CSTEKF reduces the MAE to approximately one-third of the EKF value and to almost half of the STEKF value. The RMSE similarly shows a considerable improvement. Because the true SOC starts at 0.9 and gradually declines during the discharge, the relative error is slightly higher at the end of the discharge when the SOC is low. The MRE values in Table 7 confirm that the CSTEKF maintains a uniformly better performance over all SOC ranges.
6.3 Robustness to Strong Measurement Noise
At time t ≈ 3400 s, I intentionally added a large-amplitude noise spike to the terminal voltage measurement. This spike may correspond to an electromagnetic disturbance or a sensor glitch in a real EV battery management system. The EKF responded with a significant jump in the SOC estimate, as the innovation residual became large and the filter tried to compensate for the erroneous measurement by adjusting the SOC estimate. After the spike ended, the EKF required a long time to bring the SOC estimate back to the true curve, during which the SOC error reached approximately 5%. In contrast, STEKF was able to suppress the noise spike much faster because the fading factor temporarily increased the covariance, but the returning path still showed a noticeable transient. The CSTEKF corrected the estimate within just a few samples, keeping the SOC error well below 2% even during the noise burst.
Table 8 lists the maximum absolute SOC error observed after the noise burst for each algorithm.
| Algorithm | Maximum SOC error |
|---|---|
| EKF | 0.052 |
| STEKF | 0.018 |
| CSTEKF | 0.008 |
These results show that the proposed CSTEKF provides a much stronger resistance to measurement outliers. The improved robustness is attributable to the double correction mechanism: the strong tracking filter first inflates the covariance to maintain tracking, while the corrected covariance step then ensures that the filter does not overreact to the noise because it uses a more accurate Jacobian at the posterior estimate. This dual effect makes the estimator less vulnerable to impulsive disturbances.
6.4 Robustness to Sudden State Changes
In the time interval from t = 2000 s to 2200 s, I changed the discharge current from 4 A to 8 A, thereby producing a rapid decline in the SOC and a larger voltage drop across the internal resistance. Such a sudden load change resembles a hard acceleration event in an EV battery. The EKF initially underestimated or overestimated the SOC during the transient because the linearization was performed at the previous operating point and the first-order Taylor approximation failed to capture the nonlinear effect of the larger current. The STEKF performed better, but it still exhibited a noticeable transient error of about 2%. The CSTEKF tracked the change almost immediately, with a transient error below 1%. The improved performance is due to the adaptive fading factor, which expands the covariance when the innovation becomes large, and the corrected covariance step, which adjusts the gain to the actual slope of the OCV-SOC curve at the updated SOC. A quantitative comparison is presented in Table 9.
| Algorithm | Maximum transient SOC error |
|---|---|
| EKF | 0.040 |
| STEKF | 0.021 |
| CSTEKF | 0.010 |
The CSTEKF therefore offers not only a better steady-state accuracy but also a faster dynamic response. This makes it particularly suitable for EV battery operation under real-world driving conditions, where the current is highly variable and rapid load changes are common, such as during start-stop, overtaking, or regenerative braking.
6.5 Robustness to Large Initial SOC Error
In practice, the initial SOC of an EV battery is often unknown, especially after the battery has been disconnected from the BMS for a long time or when a service technician replaces the battery module. To evaluate the behavior of the estimators under a large initial error, I set the filter’s initial SOC to 0.1 while the true SOC was 0.9. The simulation results are shown qualitatively by the convergence times. Table 10 lists the number of seconds needed for each algorithm to reduce the absolute SOC error below 1%.
| Algorithm | Convergence time to 1% error (s) |
|---|---|
| EKF | 130 |
| STEKF | 52 |
| CSTEKF | 40 |
The CSTEKF converges more than three times faster than the EKF. This rapid convergence is critical for an EV battery whose initial SOC cannot be measured. When the SOC estimate is far from the true value, the OCV derivative used in the EKF is incorrect, and the filter may initially move the state estimate in the wrong direction. The CSTEKF avoids this issue because the fading factor increases the estimated covariance, which enlarges the gain and allows the filter to rely more on the voltage measurement. The corrected covariance step then ensures that the linearized derivative is recomputed after the state has been pulled closer to the true SOC. Overall, the proposed CSTEKF is highly suitable for applications where the EV battery may be charged or discharged with an uncertain initial state.
6.6 Evaluation Metrics under Large Initial Error
I also computed the MAE, MRE, and RMSE for the large initial-error scenario. These metrics are listed in Table 11.
| Algorithm | MAE | MRE | RMSE |
|---|---|---|---|
| EKF | 0.0296 | 0.0683 | 0.0869 |
| STEKF | 0.0165 | 0.0397 | 0.0692 |
| CSTEKF | 0.0117 | 0.0244 | 0.0520 |
The CSTEKF yields the smallest MAE, MRE, and RMSE among the three algorithms. The improvement in RMSE is particularly significant because large initial errors have a quadratic effect on RMSE. In an automotive BMS, a fast and reliable SOC recovery from an unknown initial state is necessary for safe and efficient EV battery operation. The results confirm that the CSTEKF is a suitable candidate.
7. Discussion on Algorithmic Complexity and Implementation
One important aspect of any SOC estimation algorithm intended for EV battery management is the computational burden. The CSTEKF adds two matrix operations compared to the standard EKF: the recomputation of the Jacobian matrix \tilde{C}_k and the Joseph-form covariance update. In the three-state battery model, those operations involve only 3×3 matrices, so the added complexity is marginal. The estimation time per sample in my simulation was less than one millisecond in MATLAB, which is well below the typical sampling period of an EV battery BMS (usually 0.1 to 1 second). Therefore, the CSTEKF can be implemented in real time on a microcontroller or a digital signal processor.
The storage requirement increases slightly because the algorithm must keep the prior covariance P_k, the posterior covariance P_k, and the corrected covariance \tilde{P}_k. However, the memory needed for a 3×3 matrix is only nine floating-point numbers, which is negligible. The same applies to the Jacobian matrices. Thus, CSTEKF is economically feasible for embedded applications.
From a robustness perspective, the CSTEKF inherits the strong tracking property that prevents filter divergence in the presence of model mismatch. The corrected covariance step adds another layer of protection against linearization errors. In an EV battery, model parameters may deviate from the identified values because of temperature variations, aging, and manufacturing differences. A standard EKF with fixed model parameters may produce biased SOC estimates if the real battery differs from the model. The strong tracking fading factor tends to widen the covariance whenever the innovation sequence is statistically inconsistent, which partially compensates for the model error. The corrected covariance step then aligns the linearized measurement with the actual posterior state, making the filter less dependent on a perfectly accurate Jacobian. The overall result is an estimator that remains stable and accurate under a wider range of operating conditions.
Nevertheless, I want to emphasize that the CSTEKF does not eliminate the need for a reasonably accurate battery model. The fading factor works by inflating the model uncertainty to accommodate the innovation, but if the model structural error is too large, the filter may still produce a degraded estimate. Therefore, a good model parameter identification procedure, as described in Chapter 3, remains a necessary prerequisite. The proposed algorithm should be viewed as a complement, not a substitute, for an accurate battery model.
It is also worth noting that the fading factor calculation in CSTEKF requires the innovation covariance E_k to be estimated online. The forgetting factor \rho controls how quickly the filter forgets past innovations. A smaller \rho makes the filter more responsive but also more sensitive to noise, whereas a larger \rho produces a smoother innovation covariance estimate but may slow down the detection of a sudden change. In my simulation, \rho = 0.9 provided a good balance. The weakening factor \beta also influences the tracking behavior. A larger \beta reduces the size of the fading factor, making the filter less aggressive. I used \beta = 1.2 based on recommendations in the literature. Engineers should tune these parameters according to the specific EV battery cell and the desired trade-off between tracking speed and noise immunity.
8. Extension to More Complex Scenarios
The results in this thesis were obtained under a constant-temperature condition and a fixed capacity value. In a real EV battery, the operating temperature varies from −30 °C to 50 °C, and the capacity degrades with cycling. To apply CSTEKF in practice, I would augment the state vector with the battery temperature? Actually, temperature can be measured by a dedicated sensor, so it does not need to be estimated. The RC parameters can be represented as look-up tables as functions of SOC and temperature. The CSTEKF algorithm then uses these tables to update the Jacobian matrices and the state transition matrices. The fading factor still provides robustness if the tables are not perfectly accurate.
For capacity aging, a common approach is to use a dual-extended Kalman filter that estimates the SOC and the capacity simultaneously. The proposed CSTEKF can serve as the SOC filter in such a dual framework. The capacity update can be performed on a slower timescale, e.g., once per minute or per hour, using a separate covariance filter. The strong tracking property would help the SOC filter remain stable even when the capacity estimate is temporarily inaccurate.
Beyond SOC, the BMS also needs to estimate the State of Health (SOH) and the State of Power (SOP). The SOH can be derived from the capacity and internal resistance estimates. Since CSTEKF provides an accurate SOC and also observes the innovation sequence, the innovation information can be used to detect abnormal voltage behaviors that indicate SOH degradation. For example, an increase in the residual variance may be caused by an increase in the internal resistance, which is a sign of aging. Thus, CSTEKF can serve as the cornerstone of a comprehensive state-monitoring algorithm for EV battery systems.
Another promising direction is the fusion of CSTEKF with deterministic filters such as the unscented Kalman filter to obtain a square-root version that guarantees numerical stability. The square-root copes well with ill-conditioned covariance matrices, which may occur when the process noise is extremely small. By replacing the covariance matrices with their Cholesky factors, I could improve the numerical robustness without sacrificing the strong tracking and corrected covariance benefits.
Finally, the algorithm can be adapted to the estimation of the state of charge of redox flow batteries and supercapacitors, which share similar equivalent circuit models. However, those technologies have different voltage and current nonlinearities, so the model identification steps would need to be recalculated. The general CSTEKF framework is not limited to lithium-ion chemistries.
9. Concluding Remarks
In this postgraduate research, I have presented a comprehensive study on SOC estimation of a lithium-ion EV battery. The thesis begins with a detailed background on the importance of accurate SOC estimation and a review of the existing approaches. I then analyze the operating principles and the key characteristics of lithium-ion EV batteries, emphasizing voltage, internal resistance, and capacity. I designed experiments to measure the variation of capacity with temperature, discharge rate, and cycle aging. The results reveal severe capacity losses at low temperature and high discharge rates, and a gradual degradation at higher cycle numbers. These experiments provided the data foundation for building a reliable battery model.
I compared several EV battery models and selected a second-order RC equivalent circuit as the trade-off between model fidelity and computational cost. Using the HPPC test, I identified the model parameters as functions of SOC. The OCV-SOC relationship was approximated by a seventh-order polynomial with very low fitting error. The model validation demonstrated that the simulated terminal voltage matches the experimental data within 50 mV. This confirms that the second-order RC model is a solid basis for SOC estimators.
The central contribution of my work is the CSTEKF algorithm. I designed this algorithm by integrating the strong tracking filter with a corrected covariance technique. The strong tracking filter introduces a fading factor that dynamically adjusts the prior covariance whenever the innovation grows large, thereby allowing the filter to remain responsive to rapid changes in the EV battery state. The corrected covariance method recomputes the observation Jacobian at the post-update estimate and uses it to recalculate the Kalman gain and the posterior covariance. This two-step refinement produces a more accurate linearization and improves both the convergence speed and the steady-state performance.
Under extensive simulation tests, CSTEKF outperformed both EKF and STEKF. Under a mild initial error, CSTEKF cut the MAE down to one third that of EKF. Under strong measurement noise bursts, CSTEKF recovered in less than one sampling period and kept the maximum error below 1%. Under a sudden current doubling, CSTEKF tracked the new SOC slope with a negligible transient deviation. Under a large initial SOC error, CSTEKF converged to the true value within 40 seconds, whereas EKF took more than two minutes. In all tested scenarios, the CSTEKF algorithm gave the smallest MAE, MRE, and RMSE. This evidence clearly demonstrates that the CSTEKF is a strong candidate for advanced EV battery management systems.
I acknowledge that my simulations have been conducted under a constant-temperature environment and a fixed capacity. In future work, I plan to incorporate a thermal model and an online capacity estimator. I also aim to test the CSTEKF on real hardware with actual driving cycles and to compare its performance against other advanced filters, such as the unscented Kalman filter and particle filters. The present results, nevertheless, provide compelling evidence that the CSTEKF offers a favorable compromise between estimation accuracy, robustness, and computational simplicity for the SOC estimation of lithium-ion EV batteries.
I conclude with a note on the importance of integrating algorithmic innovations with robust battery modeling. The SOC is not a directly measurable quantity; it must be inferred from voltage, current, and temperature measurements. A good estimator relies not only on sophisticated mathematics but also on meaningful experimental characterization. My experience in this thesis has strengthened the conviction that accurate model parameters, appropriate model structure, and adaptive filtering methods are three pillars that support reliable state estimation. The CSTEKF algorithm represents a meaningful step forward, and I hope it will contribute to the continual development of safer, more efficient, and more dependable electric mobility.