
With the rapid expansion of the electric vehicle market, the safety and durability of traction batteries have become central technical challenges. The power battery pack of an electric vehicle must operate inside a narrow temperature window to avoid accelerated aging, capacity loss, and in severe cases thermal runaway. Traditional fin structures inserted in phase change material usually use straight rectangular profiles that have been designed from empirical rules rather than mathematical optimization. These fins often suffer from low material efficiency and insufficient thermal spreading. In my research, I applied density-based topology optimization to design phase-change-material composite fins for traction battery cooling. The objective was to minimize the volume-averaged temperature of the battery cell during the discharge process. I numerically evaluated the optimized fins in both rectangular and cylindrical traction battery cells, then combined the optimized fins with air cooling strategies, and finally assessed their ability to suppress thermal runaway propagation.
The importance of an optimized thermal management system for traction batteries cannot be overstated. Traction batteries are expected to deliver high discharge rates during acceleration and regenerative braking, which generates significant heat. If that heat cannot be released quickly, the battery may suffer from local hot spots, uneven current distribution, and degradation. When a traction battery module contains dozens of cells, the temperature difference among cells becomes a serious issue because cells with higher temperature degrade faster, reducing the pack capacity and increasing internal resistance. In extreme scenarios, a failed cell can trigger chain reactions and cause fires. Therefore, the central objective of my study was to improve the thermal performance of a traction battery pack without adding excessive weight or sacrificing phase change material volume.
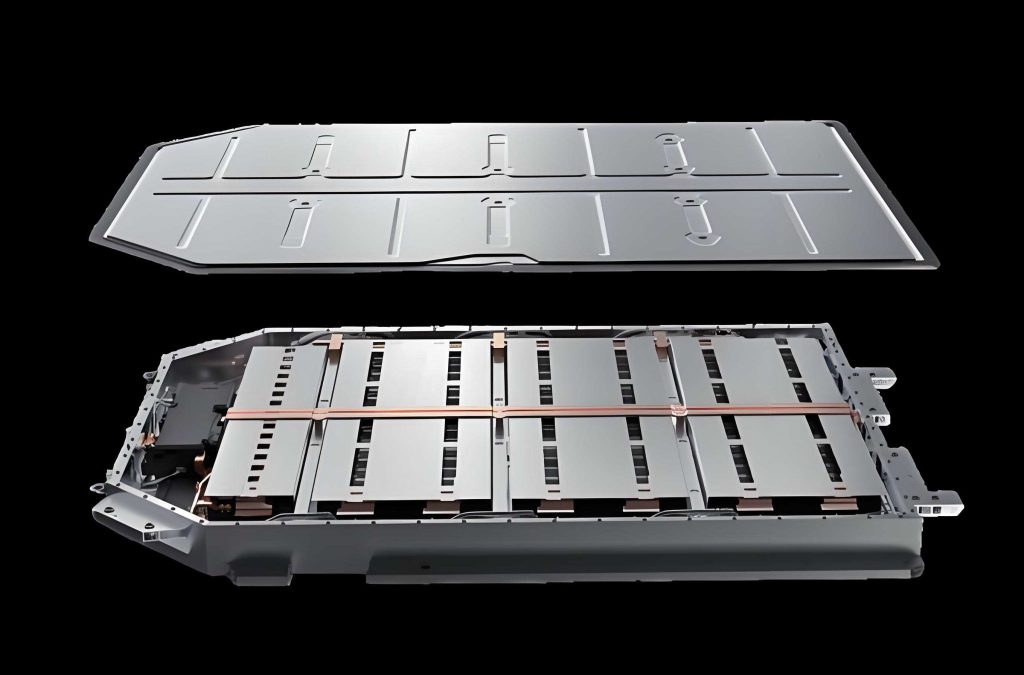
In the following sections, I describe the heat generation model of the battery, the topology optimization framework used to generate the fin layouts, the numerical results under different volume ratios, the hybrid air cooling optimization, and the thermal runaway suppression analysis. Throughout the article, the central theme is the application of topological design to the thermal management of the traction battery, with special attention given to material distribution in the phase change region.
Heat generation and thermal model of the traction battery
A reliable thermal model is the foundation for any numerical optimization of the traction battery cooling structure. I selected two common commercial cell formats for my work: a prismatic ternary lithium-ion cell with 51 Ah capacity and a cylindrical 18650 cell with 2.6 Ah capacity. The prismatic cell has dimensions of 148 mm x 27 mm x 91 mm, whereas the cylindrical cell has a radius of 18 mm and a height of 65 mm. The governing heat conduction equation inside the solid battery and the composite cooling structure is
$$ \rho c_p \frac{\partial T}{\partial t} = \nabla \cdot (k \nabla T) + \dot{q} $$
where \( \rho \) is density, \( c_p \) is specific heat capacity, \( T \) is temperature, \( k \) is the thermal conductivity tensor, and \( \dot{q} \) is the volumetric heat source from electrochemical reactions and internal resistances. Since the dominant heat transfer path in the composite is through the fin and phase change material, the thermal conductivity is anisotropic for the cell. For the prismatic cell, the in-plane conductivity was 14 W/(m K) and the through-plane conductivity was 1.31 W/(m K). For the cylindrical cell, the radial conductivity was only 0.2 W/(m K), while the axial conductivity was 37.6 W/(m K). Table 1 summarizes the key thermophysical properties used in my model.
| Parameter | Prismatic cell | Cylindrical cell |
|---|---|---|
| Capacity (Ah) | 51 | 2.6 |
| Weight (g) | 816.47 | 47.5 |
| Dimensions (mm) | 148 x 27 x 91 | R=18, H=65 |
| Density (kg/m³) | 2245.3 | 2873.5 |
| Specific heat (J/(kg K)) | 1050.31 | 1200 |
| Thermal conductivity (W/(m K)) | k_x,y=14, k_z=1.31 | k_r=0.2, k_z=37.6 |
The rate of heat generation during charge and discharge was calculated with the Bernardi model, which is widely accepted for electrochemical energy storage systems:
$$ \dot{q} = \frac{I}{V_c} \left( U_{ocv} – U – T \frac{\partial U_{ocv}}{\partial T} \right) $$
where \( I \) is the current, \( V_c \) is the cell volume, \( U_{ocv} \) is the open-circuit voltage, \( U \) is the operating voltage, and \( \frac{\partial U_{ocv}}{\partial T} \) is the entropic heat term. In the three-dimensional numerical model, the current collector, active material, separator and electrolyte were treated as a homogeneous solid with effective properties. This simplification is acceptable because the spatial distribution of internal current is not the focus of this study; instead, I investigated the external cooling performance, for which cell-level heat generation is sufficient.
I validated the heat generation model against published experimental data for the prismatic traction battery at discharge rates of 1C, 2C and 3C. The simulation was carried out in a constant environment of 25 °C with natural convection on all outer surfaces. The maximum relative error between the simulated surface temperature and the experimental measurement was below 5% for all tested rates. Therefore, the model can accurately reproduce the temperature rise of the traction battery during high-rate discharge. For the cylindrical cell, I applied the same Bernardi formulation with the corresponding discharge current and internal resistance data.
The phase change material I selected was n-eicosane, which has a melting temperature around 36 °C. Its thermophysical properties are listed in Table 2. The latent heat is 241 kJ/kg, which gives a high heat buffering capability during the discharge event. However, the thermal conductivity of n-eicosane is very low: 0.39 W/(m K) in the solid state and 0.157 W/(m K) in the liquid state. This poor conductivity severely limits the heat flow into the phase change material. I therefore added aluminum fins to the composite structure. Aluminum has a density of 2700 kg/m³, a specific heat of 900 J/(kg K), and a thermal conductivity of 238 W/(m K), as given in Table 3.
| Property | Solid | Liquid |
|---|---|---|
| Melting temperature (°C) | 35 | 37 |
| Density (kg/m³) | 810 | 770 |
| Specific heat (kJ/(kg K)) | 1.9 | 2.2 |
| Thermal conductivity (W/(m K)) | 0.39 | 0.157 |
| Latent heat (kJ/kg) | 241 | |
| Property | Value |
|---|---|
| Density (kg/m³) | 2700 |
| Specific heat (J/(kg K)) | 900 |
| Thermal conductivity (W/(m K)) | 238 |
Topology optimization formulation for fins
Topology optimization is a mathematical technique that seeks the optimal distribution of material inside a design domain subject to certain constraints and objective functions. For the traction battery phase change cooling system, the design domain is the volume occupied by phase change material and aluminum fins. I used the solid isotropic material with penalization method, introducing a pseudo-density variable \( \gamma \) in each element of the design domain. The pseudo-density ranges from zero to one; a value of zero corresponds to pure phase change material and a value of one corresponds to pure aluminum fin. The effective thermal conductivity, density, and volumetric heat capacity are interpolated as
$$ k(\gamma) = k_{pcm} + \gamma^p (k_{fin} – k_{pcm}) $$
$$ \rho(\gamma) = \rho_{pcm} + \gamma (\rho_{fin} – \rho_{pcm}) $$
$$ \left(\rho c_p\right)(\gamma) = \left(\rho c_p\right)_{pcm} + \gamma \left[\left(\rho c_p\right)_{fin} – \left(\rho c_p\right)_{pcm}\right] $$
where \( p \) is a penalty factor that drives the pseudo-density toward 0 or 1. The thermal conductivity interpolation uses a power law penalty to suppress intermediate densities. In my implementation, the model domain was first solved with the heat conduction equation, and the objective function was computed. The sensitivity of the objective to the pseudo-density was then used by the optimizer to update the design. The iterative process is terminated when the change in objective function becomes smaller than a tolerance.
However, a direct element-wise density field often produces mesh-dependent patterns and checkerboard artifacts. To avoid these numerical instabilities, I applied a Helmholtz-type filter to the design variables:
$$ \gamma_f = \gamma_c + r^2_{\min} \nabla^2 \gamma_f $$
where \( \gamma_c \) is the raw design variable, \( \gamma_f \) is the filtered density, and \( r_{\min} \) is the filter radius. This filter smooths the design field. After filtering, a hyperbolic tangent projection was used to sharpen the structural boundaries and reduce gray-scale transitional elements:
$$ \bar{\gamma} = \frac{\tanh(\beta \gamma_\beta) + \tanh(\beta(\gamma_f-\gamma_\beta))}{\tanh(\beta \gamma_\beta) + \tanh(\beta(1-\gamma_\beta))} $$
In my study, the projection slope \( \beta \) was set to 8 and the projection point \( \gamma_\beta \) was 0.5. This combination achieved a clear separation between solid fin regions and phase change material regions while maintaining stable convergence.
Two objective functions were tested. The first objective is minimizing the thermal compliance:
$$ J_1 = \int_{\Omega} q T \, d\Omega $$
and the second objective is minimizing the volume-averaged temperature:
$$ J_2 = \frac{1}{\Omega}\int_{\Omega} T \, d\Omega $$
where \( \Omega \) is the design domain and \( q \) is the volumetric heat source. For a constant heat generation rate, minimizing thermal compliance has a similar effect to minimizing the average temperature, but differences appear when the heat source is non-uniform. In my discharging battery model, the heat source is uniform within the battery, but the temperature distribution in the phase change material is highly non-uniform due to the low thermal conductivity and the moving melting front. I compared the optimized structures obtained from the two objectives for volume ratios of 0.1, 0.2 and 0.3. The average temperature objective consistently yielded a slightly lower peak cell temperature than the thermal compliance objective. Consequently, I selected the volume-averaged temperature minimization as the objective for the rest of the study.
Design of phase change material volume
Before topology optimization, it is necessary to determine the volume of phase change material that can absorb the heat released by the traction battery during the worst-case discharge. I selected a 3C discharge lasting 1200 s as the design condition because 3C represents a high load for a commercial electric vehicle traction battery. The required phase change material volume was calculated by equating the total generated heat with the latent heat stored during melting:
$$ V_{pcm} = \frac{\int_{0}^{1200} q(t) dt}{Q_{latent} \rho_{pcm}} $$
where \( Q_{latent} \) is the latent heat per unit mass and \( \rho_{pcm} \) is the solid density. For the prismatic cell, the calculated volume was 23.144 cm³, and for the cylindrical cell it was 13.715 cm³. The amount of sensible heat stored below the melting temperature was ignored because it is much smaller than the latent heat contribution. This volume is kept constant for every topology optimization case. When the volume ratio \( \omega \) between aluminum fin and phase change material changes, the total height or side length of the composite region changes so that the phase change material volume remains fixed. For the prismatic cell, the composite region length was adjusted; for the cylindrical cell, both square and hexagonal arrangement regions were considered.
Optimized fin structures for the prismatic traction battery
I first optimized the fin layout around the prismatic traction battery. The optimization was performed on a two-dimensional cross-section containing one cell and its surrounding phase change material volume. A straight rectangular fin structure with the same volume ratio was used as the baseline for comparison. Figure 1, which I have not reproduced here, showed the topology optimized structures for six volume ratios from 0.1 to 0.6. In general, the optimizer produced tree-like branched fins with main roots attached to the battery surface and several branches extending into the phase change material. These branch channels allow heat to penetrate the entire phase change material volume instead of remaining concentrated near the cell surface. The straight fin geometry, on the other hand, has a uniform narrow blade that only heats a thin rectangular zone around the fin. Many regions far from the straight fin never reach the melting point, so the phase change material is underutilized.
Once the two-dimensional optimized geometries were obtained, I replicated them along the height direction of the prismatic cell to build a three-dimensional model. The transient thermal behavior during a 3C discharge was simulated with the phase change material melting enabled. The phase transition was modeled by an equivalent heat capacity formulation that gives a peak in the apparent specific heat around the melting temperature. The boundary conditions in the initial comparison were adiabatic on all outer surfaces, except for the top and bottom natural convection, to isolate the effect of the fins.
Table 4 presents the final battery temperatures at the end of the 3C discharge for the straight fin and the topology optimized fin at two volume ratios. At a volume ratio of 0.1, the straight fin structure resulted in a cell temperature of 44.3 °C, while the topology optimized structure yielded 40.3 °C. This corresponds to a reduction of 8.15%. At a volume ratio of 0.6, the straight fin yielded 41.3 °C and the optimized fin yielded 37.1 °C, representing a reduction of 10.14%. The topology optimized fins are disconnected at the midpoint between adjacent cells, which prevents direct heat conduction from one cell to its neighbor through the metal fin. This feature is especially useful for limiting thermal interactions among cells in a traction battery module.
| Volume ratio ω | Straight fin temperature (°C) | Topology optimized fin temperature (°C) | Percentage reduction (%) |
|---|---|---|---|
| 0.1 | 44.3 | 40.3 | 8.15 |
| 0.3 | 42.1 | 38.0 | 9.70 |
| 0.6 | 41.3 | 37.1 | 10.14 |
I also analyzed the influence of the volume ratio on the temperature of the traction battery. Figure 3 in the original text indicated that the temperature after discharge decreased monotonically from 40.3 °C at \( \omega = 0.1 \) to 37.1 °C at \( \omega = 0.6 \). The reduction rate gradually became smaller when \( \omega \) exceeded 0.4. For example, the battery temperatures at ω = 0.4, 0.5, and 0.6 were 37.5, 37.2 and 37.1 °C, respectively. Continuing to increase the fin fraction beyond 0.4 only reduces the phase change material volume and sacrifices the latent heat capacity. From an economic and performance point of view, the optimum volume ratio is around 0.4 for the prismatic cell.
Optimized fin structures for the cylindrical traction battery
For the cylindrical traction battery, the surrounding phase change material can be arranged in either a square packing or a hexagonal packing pattern inside the cell module. These two arrangements change the shape of the design domain, leading to different topology optimized fins. I considered a two-dimensional unit cell with one centrally placed cylindrical cell. The phase change material volume was kept at 13.715 cm³ while the side length of the square or hexagonal unit cell was increased as the volume ratio increased from 0.1 to 0.5. The length or side of the phase change region increased from about 15.6 mm at ω=0.1 to 22.4 mm at ω=0.5 for the square arrangement. For the hexagonal arrangement, the equivalent dimensions changed accordingly.
At the same volume ratio, the topology optimized fins around a cylindrical cell exhibit multiple radial branches emanating from the circular cell surface. Many branches have a curved shape that follows the shape of the circular cell. Some branches are longer than others so that heat is delivered to the corners of the square or hexagonal design domain. The optimizer often divides a long branch into a secondary bifurcation before reaching the corner, enabling a more uniform temperature field in the phase change material.
The discharge simulation at 3C showed that the straight fin around the cylindrical cell with ω=0.1 led to a cell temperature of 45.4 °C in square arrangement. The topology optimized fin reduced the temperature to 42.7 °C, a decrease of about 6%. In the hexagonal arrangement, the straight fin gave 45.2 °C at ω=0.1, whereas the optimized fin gave 41.7 °C, which corresponds to a 7.8% reduction. The improved performance of the optimized fin is particularly clear in the hexagonal packing because the complex geometry of the domain benefits more from the free-form topology design.
Table 5 summarizes the final temperatures for the two arrangement patterns and different volume ratios. The topology optimized fins generally perform better than the straight fins, and the hexagonal arrangement results in lower cell temperatures than the square arrangement for every volume ratio. At ω=0.5, the square arrangement yielded 40.1 °C and the hexagonal arrangement yielded 39.7 °C. The difference between the two arrangements narrows as ω increases, but the hexagonal packing still has an advantage because it allows a more symmetric distribution of phase change material around each cell and reduces the volume of dead zones in the corners of the module.
| Volume ratio ω | Square arrangement (°C) | Hexagonal arrangement (°C) |
|---|---|---|
| 0.1 | 42.7 | 41.7 |
| 0.2 | 41.6 | 40.9 |
| 0.3 | 40.5 | 40.2 |
| 0.4 | 40.2 | 39.6 |
| 0.5 | 40.1 | 39.7 |
In the square arrangement, increasing the volume ratio from 0.1 to 0.5 produced a 6.2% reduction in the battery temperature. In the hexagonal arrangement, the corresponding reduction was 4.8%. The fact that the hexagonal arrangement has a smaller absolute reduction is due to its already lower temperature at the initial volume ratio. The recommended volume ratio for the cylindrical traction battery is again about 0.4, because the temperature reduction from ω=0.4 to ω=0.5 is only 0.1 °C. This behavior is consistent with the observation that once the fin branches cover the phase change material sufficiently, adding more aluminum only reduces the phase change material mass and yields diminishing returns.
Geometric reconstruction and simplified three-dimensional model
The topology optimized fins obtained from the two-dimensional optimization have jagged digital boundaries and discontinuous branches, which are difficult to manufacture with conventional rolling or extrusion processes. To make the fins manufacturable and to include air cooling passages, I reconstructed the raw topology output into a simple straight-edged geometry. The reconstructed fins keep the main branch distribution and the connectivity to the cell, but the curved and serrated edges are replaced by rectilinear edges. The inner region of the composite block contains vertical fin plates that extend along the height of the battery. A portion of each fin extends above the phase change material block to form a fin array that can be exposed to air flow.
I compared the reconstructed geometry with the original topology optimized geometry for the prismatic traction battery at ω=0.4 and 3C discharge. The average cell temperature of the reconstructed model was 40.5 °C, while the original topology model gave 40.6 °C. Therefore, the geometric simplification has a negligible effect on the thermal performance. The small straight-edged fins still provide sufficient conduction paths to activate the phase change material. This simplified geometry was used for all subsequent air cooling simulations.
Three-dimensional air cooling model
The objective of combining phase change material with fins is not only to buffer heat, but also to transport the absorbed heat to an external cooling medium. Since phase change material alone cannot release heat forever, a secondary active cooling mechanism is necessary. I coupled the phase change material composite fin module to air cooling channels. The three-dimensional computational domain consists of the prismatic traction battery, the phase change material block with embedded fins, and an air domain above the block. Part of the fins are exposed to the air stream and act as extended surfaces. The top of the model is open, while the bottom and sides are thermally insulated or set to a natural convection coefficient of 10 W/(m² K) as appropriate. The heat transfer in the air domain is described by the incompressible Navier-Stokes equations and the energy equation. However, because the air velocities are low and the flow is laminar, I used the conjugated heat transfer interface in the finite element solver.
I performed a mesh independence study to ensure the accuracy of the numerical results. The model with an exposed fin height of 5 mm and a single-sided air cooling arrangement was meshed with tetrahedral elements. I tested six mesh densities from 170,000 elements to 850,000 elements. The average cell temperature at the end of discharge varied by less than 0.1 °C when the mesh count increased from 440,000 to 850,000. Based on this convergence, I selected a mesh of about 440,000 elements for the prismatic cell model. For models with different fin heights or air cooling schemes, I adjusted the local mesh density at the fin tips and boundary layers to maintain a similar resolution.
Influence of fin extension height
The fin extension height above the phase change material block is one of the most important design parameters for the hybrid cooling system. A larger extension height increases the air-side heat transfer area but also increases the airflow blockage and the amount of fin material. I simulated five extension heights: 0, 5, 10, 15 and 20 mm. The inlet air velocity was fixed at 1.5 m/s. The phase change material volume and volume ratio were kept constant at ω=0.4. For a cylinder of phase change material with a given volume, changing the exposed fin height does not change the internal phase change material volume because the total height of the composite block is adjusted to preserve the material volume.
The final average battery temperatures are listed in Table 6. With no extension height, the battery temperature reached 39.8 °C after a 3C discharge. When the fin extension height was increased to 5 mm, the temperature dropped to 38.8 °C. At 10 mm, it dropped further to 38.3 °C. Extending the fin from 10 to 20 mm only decreased the temperature by 0.5 °C. This diminishing return indicates that after 10 mm, the fin heat transfer area has reached a point where additional fin material no longer significantly improves the overall thermal resistance. The extra surface area is exposed to air that has already been warmed by upstream fins, and any further height increase mainly adds weight and pressure drop.
| Fin extension height (mm) | Battery average temperature (°C) |
|---|---|
| 0 | 39.8 |
| 5 | 38.8 |
| 10 | 38.3 |
| 15 | 38.0 |
| 20 | 37.8 |
I chose 10 mm as the optimal extension height because it provides a good compromise between cooling performance and compactness. This height is sufficiently small that the total battery module height does not increase excessively. In the following air cooling scheme study, the fin extension height was fixed at 10 mm.
Comparison of air cooling schemes
The direction and position of the cooling air stream can significantly affect the temperature uniformity inside a traction battery pack. I investigated three air cooling configurations for the phase change material composite fin module:
- Single-sided air cooling: air flows over the exposed fins only on one side of the battery pack;
- Double-sided co-current air cooling: air flows over the exposed fins on both sides, with the inlet and outlet arranged in the same direction on both sides;
- Double-sided counter-current air cooling: air flows over the exposed fins on both sides, but the inlet direction on one side is opposite to the inlet direction on the other side.
In all three configurations, the air domain above the phase change composite block is modeled with an inlet length of 30 mm and an outlet length of 30 mm. The inlet air temperature is 25 °C. Five inlet velocities were simulated: 1.0, 1.5, 2.0, 2.5 and 3.0 m/s. The phase change volume ratio and geometry were identical in every case. The target variables are the maximum cell temperature and the maximum temperature difference between the two batteries in the module.
The temperature distribution inside the phase change region during the discharge always shows a thermal buffering effect: the phase change material adjacent to the battery is completely melted and remains near the melting temperature, while the outer regions are colder. When the air speed increases, more heat is removed from the top of the fins, which causes the solidification front to progress faster at the top of the phase change material block. However, because the latent heat capacity is large, the cell temperature is still controlled by the melting process during the early discharge transients.
Table 7 compares the final battery temperatures under the three cooling schemes at the selected wind speed of 2.5 m/s. Single-sided cooling yields an average temperature of 38.0 °C. Both double-sided co-current and double-sided counter-current schemes yield almost the same average temperature, around 37.0 °C. The two-sided cooling arrangements reduce the cell temperature by about 1 K compared with single-sided cooling, because they provide twice the air-side heat transfer area.
| Cooling scheme | Average cell temperature (°C) | Temperature difference between cells (°C) |
|---|---|---|
| Single-sided air cooling | 38.0 | 0.175 |
| Double-sided co-current air cooling | 37.0 | 0.185 |
| Double-sided counter-current air cooling | 37.0 | 0.01 |
The most striking difference appears in the temperature difference between the two battery cells. In single-sided cooling, the upstream cell is cooled strongly by fresh cold air while the downstream cell sees warmer air, so the cells develop a noticeable temperature difference that increases with air velocity. At 3.0 m/s, the single-sided scheme produces a maximum difference of about 0.20 °C. In double-sided co-current cooling, both sides of every cell are cooled by air flowing in the same direction; the left and right cells are exposed to the same airflow pattern, but the air is heated along the flow direction, which creates a temperature gradient along the air path. This leads to a cell-to-cell temperature difference that is even slightly higher than in single-sided cooling, with a maximum of 0.19 °C at high velocity.
The double-sided counter-current scheme completely changes the temperature behavior. Air enters from opposite directions on the two sides of the pack. Therefore, the cold spot caused by the inlet on one side is compensated by a cold spot caused by the inlet on the other side. The two battery cells experience nearly identical average cooling conditions, so the temperature difference remains below 0.01 °C for all tested velocities. Looking only at the average temperature, counter-current and co-current are equivalent. Looking at temperature uniformity, the counter-current arrangement outperforms the others by almost 90% reduction in the inter-cell temperature difference. For a traction battery pack, temperature uniformity is crucial because it prevents capacity imbalance and unequal aging among cells. I therefore conclude that the double-sided counter-current air cooling is the optimal scheme for this phase change material composite fin module.
Thermal runaway propagation suppression
Thermal runaway is the most dangerous failure mode of a traction battery. When one cell enters thermal runaway, it can release a huge amount of energy and cause neighboring cells to exceed the runaway trigger temperature. I simulated the propagation of thermal runaway through the phase change material composite fins to examine whether the topology optimized structure can suppress this chain reaction. The simulations were performed on a two-dimensional model containing two adjacent prismatic traction battery cells surrounded by phase change material and fins. The fin arrangement was either a straight connected fin, a straight fin with a gap in the middle, or a topology optimized disconnected fin. The volume ratio was fixed at 0.4. For the straight connected fin, the aluminum fin connects the two batteries from the left to the right, thus acting as a heat bridge. For the straight disconnected fin and topology optimized fin, the fin is interrupted between the batteries to break the direct heat conduction path.
The thermal runaway trigger temperature was set to 150 °C, which is a commonly accepted lower limit for the onset of exothermal side reactions in a fully charged lithium-ion battery. For the cylindrical cell, the thermal runaway heat generation was 129.3 MW/m³, and for the prismatic cell it was 136.3 MW/m³. In the simulation, both cells were initially discharging at a 3C rate for 60 seconds. After 60 seconds, the left cell was set to the thermal runaway heat generation rate for 10 seconds, after which it was allowed to cool naturally. The right cell continued with ordinary 3C heat generation. The entire process was simulated for 500 seconds.
The temperature evolution results for the prismatic battery are summarized in Table 8. The normal battery in the connected straight fin case reaches 150 °C very quickly, meaning that thermal runaway is triggered in the neighboring cell. When the straight fin is disconnected, the normal battery temperature at the end of the simulation is 92.6 °C. Moreover, the topology optimized fin limits the normal battery temperature to 67.2 °C. The topology optimized fin has a more branched structure than the straight disconnected fin, so it stores more heat by virtue of the surrounding phase change material. At the same time, because the fin branches are discontinuous, the heat cannot flow directly through the fin from the runaway cell to the normal cell.
| Fin structure | Normal battery maximum temperature (°C) |
|---|---|
| Straight fin connected | >150 (runaway) |
| Straight fin disconnected | 92.6 |
| Topology optimized fin | 67.2 |
In the cylindrical traction battery arrangement, the same analysis was conducted with square packing. The runaway cell reached a peak temperature above 500 °C and then gradually cooled. In the straight fin structure, the normal battery reached a maximum temperature of 88.9 °C at the end of 500 seconds. In the topology optimized structure, the normal battery maximum temperature was 83.2 °C. The difference is less dramatic than in the prismatic case because the straight fin in the cylindrical arrangement has a smaller cross-sectional area. Still, the topology optimized cylindrical fins reduce the normal cell temperature by about 5.7 °C compared to the straight fin. This improvement indicates that the optimized fin geometry makes it more difficult for heat to cross through the phase change material and reach neighboring cells.
| Fin structure | Normal battery temperature (°C) | Runaway battery temperature (°C) |
|---|---|---|
| Straight fin | 88.9 | 171.3 |
| Topology optimized fin | 83.2 | 184.3 |
A deeper observation from the thermal runaway simulation is that the runaway battery cools faster when the fin structure provides a low thermal resistance path to the neighbor. In the straight connected fin case, the runaway battery transfers a large amount of heat through the aluminum fin, which accelerates both the neighbor’s heating and the runaway battery’s cooling. The topology optimized fin, on the other hand, stores heat locally in the phase change material and only releases it slowly. The difference in the final runaway battery temperatures reflects this phenomenon: in the cylindrical simulation, the runaway battery in the straight fin case cooled to 171.3 °C, while in the topology optimized case it remained at 184.3 °C. Higher temperature in the runaway cell after 500 seconds is not a disadvantage with respect to suppressing the chain reaction, because the important factor is the heat flux transferred from the failed cell to the healthy cells. The optimized fin reduces that flux substantially.
Thus, the topology optimized fins provide a dual benefit for the traction battery thermal management system. In normal operation, they increase the effective thermal conductivity of the phase change material and promote more uniform melting. During abuse conditions, they restrict the thermal contact between adjacent cells and therefore act as thermal fuses. Combined with the disconnected design and the low thermal conductivity of the phase change material itself, the topological fins effectively break the direct metal path that would otherwise promote thermal runaway propagation.
Conclusion
From my numerical investigation of the traction battery phase change cooling structure, I can draw the following conclusions. First, the topology optimized fin structures offer a substantial improvement over traditional straight fins. For the prismatic traction battery, the optimized fin reduces the final temperature by more than 8% at a low volume ratio of 0.1 and by more than 10% at a volume ratio of 0.6. For cylindrical traction batteries, the hexagonal packing of phase change material gives better results than square packing. The topology optimized fins in the hexagonal arrangement lower the cell temperature from 41.7 °C at ω=0.1 to 39.7 °C at ω=0.5, with the recommended volume ratio around 0.4 because the law of diminishing returns is reached above that value.
Second, the cooling performance of the phase change composite can be further improved by adding air flow over the exposed fins. Increasing the fin extension height from 0 to 10 mm reduces the battery temperature by about 2 °C. Higher extensions give limited extra benefit. Among the investigated air cooling schemes, double-sided counter-current cooling shows the same average temperature reduction as double-sided co-current cooling, but the former dramatically improves the temperature uniformity inside the module. The temperature difference between cells can be lowered by nearly 90% when the two air streams flow in opposite directions. This is a critical advantage for the reliability and state-of-health of the traction battery pack.
Third, the topology optimized fin design significantly improves the safety of the traction battery in a thermal runaway scenario. In the prismatic cell model, the healthy cell adjacent to a runaway cell only reaches 67.2 °C when the optimized fins are used, which is well below the thermal runaway trigger temperature. In contrast, a straight connected fin allows the healthy cell to exceed 150 °C and enter thermal runaway. The cylinder cell model also shows that the optimized fins keep the healthy cell temperature lower than the conventional straight fin arrangement.
Altogether, the work presented here establishes a systematic methodology for designing high-performance phase change cooling structures for traction batteries by using topology optimization. The resulting fins are not only lighter and more efficient than their straight counterparts, but they also introduce a built-in mechanism to suppress thermal runaway propagation. Future research should focus on experimental validation of the optimized fin structures using metal additive manufacturing and on extending the optimization to three-dimensional multi-physics problems that include natural convection inside the liquid phase change material. The integration of topology optimized fins with active air cooling provides a practical and scalable solution for the next generation of high-power traction battery thermal management systems.