
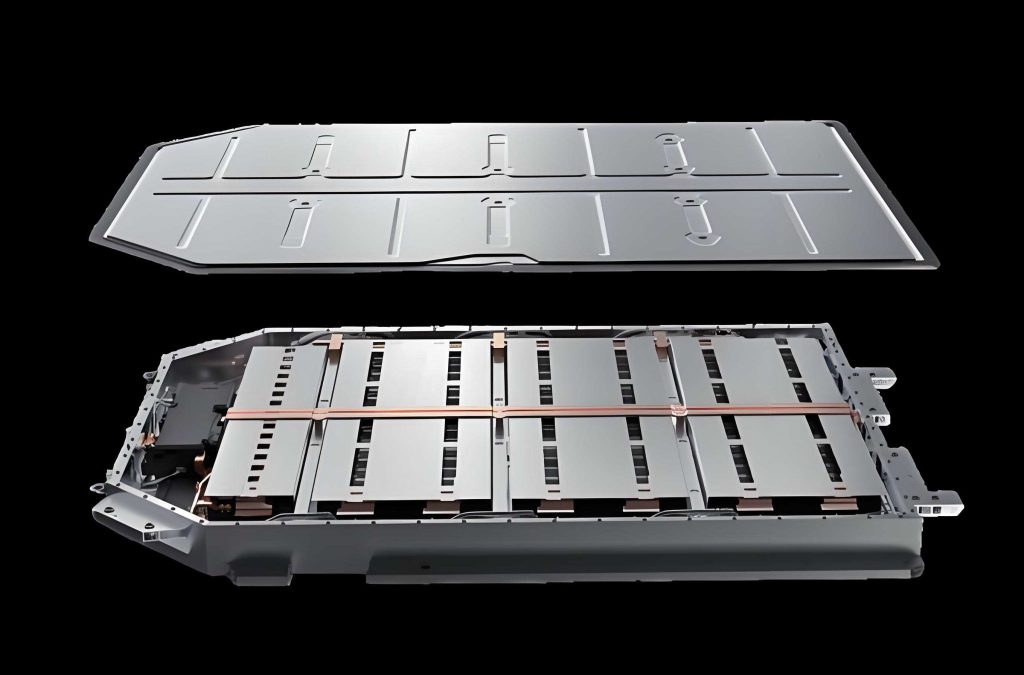
I begin with the observation that the rapid global adoption of electric vehicles is driven by the urgent need to reduce environmental pollution and dependence on fossil fuels. The electric vehicle battery pack is the central energy storage component, and lithium-ion batteries dominate this application because of their high energy density, low self-discharge rate, long cycle life, and wide operating temperature range. Among the various chemistries, lithium iron phosphate (LiFePO4) is particularly attractive for electric vehicle battery packs due to its excellent thermal stability, flat open-circuit voltage plateau, and low cost. However, the electric vehicle battery pack remains vulnerable to internal and external short circuits. A soft short circuit (SSC) is an early-stage short circuit that produces only mild voltage anomalies, making it difficult to detect. If an SSC is not diagnosed in time, it can evolve into a hard short circuit and trigger thermal runaway. My research focuses on developing an interpretable, data-driven SSC diagnosis method for electric vehicle battery packs using full-dimensional statistical analytics. I propose a complete diagnostic framework that includes an improved voltage measurement scheme, an eigen-decomposition-based fault detection indicator, a control-limit self-tuning rule derived from quantitative fault signature analysis, and a parallel fault localization strategy that corrects detection results in real time.
I have observed that the transportation sector accounts for a significant fraction of global oil consumption and greenhouse gas emissions. The electric vehicle battery pack is therefore not only an energy storage device but also a safety-critical component. Thermal runaway in an electric vehicle battery pack can be triggered by mechanical abuse, electrical abuse, or thermal abuse. In all cases, an internal short circuit is a necessary intermediate stage. The evolution from a soft short circuit to a hard short circuit can take minutes to hours, depending on the severity and the operating conditions. Detecting the SSC at an early stage provides a sufficient time margin for control actions such as isolating the faulted cell, reducing the charging current, or activating the cooling system. My work addresses this need by designing a diagnostic method that is sensitive to millivolt-level voltage anomalies while remaining robust to the inherent parameter inconsistency among cells in a series-connected electric vehicle battery pack.
The structure of this article is as follows. I first review the basic principles of LiFePO4 batteries and equivalent circuit models. I then analyze the impact of parameter inconsistency on voltage measurement in an electric vehicle battery pack. Next, I present my virtual voltage measurement scheme, which includes near-cut-off voltage alignment and a virtual transformation matrix. After that, I derive the fault detection indicator based on eigen-decomposition of the covariance matrix of differential voltage data. I then establish a quantitative relationship between the detection threshold and the original fault signature, enabling control-limit self-tuning. I also present a fault localization method based on eigenvalue contribution and explain how it runs in parallel with detection. Finally, I validate the proposed method on a 14-cell series-connected LiFePO4 electric vehicle battery pack under the World Light Vehicle Test Cycle (WLTC), and I compare its performance with two recently proposed data-driven methods.
Table 1. Comparison of cathode materials for lithium-ion batteries used in electric vehicle battery packs.
| Parameter | LiCoO2 | LiMn2O4 | NCM | LiFePO4 |
|---|---|---|---|---|
| Nominal voltage (V) | 3.7 | 3.8 | 3.6 | 3.2 |
| Specific energy (Wh/kg) | 145 | 100 | 145 | 125 |
| Safety | Poor | Good | Good | Very good |
| Thermal stability | Fair | Good | Good | Very good |
| Cycle life (cycles) | >600 | >600 | >600 | >800 |
| Raw material cost | High | Low | Low | Very low |
I now describe the fundamental structure and working principle of a LiFePO4 cell. A lithium-ion cell consists of a positive electrode, a negative electrode, a separator, an electrolyte, and current collectors. During charging, lithium ions deintercalate from the positive electrode, migrate through the electrolyte and separator, and intercalate into the negative electrode. During discharging, the reverse process occurs. The overall chemical reaction for a LiFePO4 cell can be written as:
$$
\mathrm{LiFePO_4 + C_6 \rightleftharpoons FePO_4 + LiC_6}
$$
The open-circuit voltage (OCV) of a LiFePO4 cell exhibits a very flat plateau over most of the state-of-charge (SOC) range, which is beneficial for energy delivery but makes voltage-based fault detection challenging. The terminal voltage of a cell can be modeled using equivalent circuit models. The simplest model is the Rint model:
$$
U = U_{oc} – I R_0
$$
where \(U\) is the terminal voltage, \(U_{oc}\) is the open-circuit voltage, \(I\) is the current (positive for discharge), and \(R_0\) is the ohmic internal resistance. A more accurate model is the Thevenin model, which adds an RC parallel branch to capture polarization:
$$
U = U_{oc} – I R_0 – U_p
$$
where \(U_p\) is the polarization voltage across the RC branch. The second-order RC model further improves accuracy by including two RC branches:
$$
U = U_{oc} – I R_0 – U_{p1} – U_{p2}
$$
In an electric vehicle battery pack, many cells are connected in series and parallel to meet power and energy requirements. I treat the electric vehicle battery pack as a series string of \(n\) cells, where each cell may itself be a parallel group. The voltage measurement topology uses \(n\) voltage sensors, each connected across one cell. At time \(k\), the measured voltage vector can be expressed as:
$$
V_k^s = A_m V_k^c + R_b I_{p,k}
$$
where \(V_k^s \in \mathbb{R}^n\) is the sensor voltage vector, \(V_k^c \in \mathbb{R}^n\) is the true cell voltage vector, \(A_m\) is a measurement matrix that accounts for interconnect resistances, \(R_b\) is a diagonal matrix of bus and connector resistances, and \(I_{p,k}\) is the pack current. The true cell voltage is given by:
$$
V_{i,k}^c = V_{oc,i,k}(SOC) – I_{p,k} R_{s,i,k}(SOC)
$$
where \(V_{oc,i,k}\) and \(R_{s,i,k}\) are the OCV and internal resistance of cell \(i\), respectively. Because of manufacturing tolerances, aging, and temperature gradients, the cells in an electric vehicle battery pack inevitably exhibit parameter inconsistency. This inconsistency causes additional differential voltage fluctuations that can mask the weak signature of an SSC. I therefore propose a virtual voltage measurement scheme to suppress these fluctuations.
The first step in my measurement scheme is differential voltage computation. For a series-connected electric vehicle battery pack, the differential voltage vector is defined as:
$$
\Delta V_k^s = A_d V_k^s = A_d (V_{oc,k} – I_{p,k} R_{s,k})
$$
where \(A_d \in \mathbb{R}^{(n-1) \times n}\) is the differential operator matrix:
$$
A_d =
\begin{bmatrix}
1 & -1 & 0 & \cdots & 0 \\
0 & 1 & -1 & \cdots & 0 \\
\vdots & \vdots & \vdots & \ddots & \vdots \\
0 & 0 & 0 & \cdots & -1
\end{bmatrix}
$$
Differential voltage computation eliminates common-mode noise and emphasizes cell-to-cell differences. However, it also amplifies the effect of parameter inconsistency. In particular, the dynamic internal resistance of a LiFePO4 cell varies significantly with SOC, especially near the low-SOC and high-SOC regions where the OCV curve is steep. The inconsistency in dynamic resistance and capacity among cells produces a differential voltage fluctuation \(\Delta V_{IR}\) that can be comparable to or larger than the SSC signature. To address this, I introduce two measures: near-cut-off voltage alignment (NCVA) in the time domain and a virtual transformation matrix in the spatial domain.
The NCVA method aligns the cell voltages near the cut-off voltage before a charging or discharging cycle. For LiFePO4 cells, the OCV plateau is very flat between roughly 20% and 80% SOC. By aligning the cells at a voltage near the lower knee of the OCV curve, for example 2.94 V per cell, the subsequent voltage divergence during normal operation is significantly reduced. Once the cells are aligned, the battery management system disables active balancing for the remainder of the cycle. This operation does not negatively affect the usable energy because the cells quickly enter the steep OCV region near the end of discharge anyway. The virtual transformation matrix \(A_v\) then reorders the measurement channels so that cells with similar dynamic resistance are placed adjacent to each other in the differential voltage vector. The transformed differential voltage is:
$$
\Delta V_k^{sv} = A_d A_v V_k^c
$$
The virtual transformation matrix \(A_v\) is a permutation matrix that satisfies:
$$
a_{i,j}^v =
\begin{cases}
1, & \text{if } V_i^s \text{ is assigned to position } j \\
0, & \text{otherwise}
\end{cases}
$$
I determine the optimal permutation by using a binary-coded discrete swarm intelligence optimization that minimizes the maximum standard deviation among all differential channels. The transformed differential voltage vector is then split into two sub-vectors for subsequent eigen-decomposition because the rank of \(A_d\) is \(n-1\). The two sub-vectors are chosen to have overlapping elements so that the fault signature is observed by both sub-vectors. A simple grouping scheme is:
$$
\Phi_1 = \{1,2,\ldots,n-1\}, \quad \Phi_2 = \{\lfloor n/2 \rfloor+1, \ldots, n, 1, \ldots, \lfloor n/2 \rfloor\}
$$
Table 2. Standard deviation (SD) and mean deviation (MD) of differential channels under three measurement schemes for a 14-cell electric vehicle battery pack. The SOC range is 83.3%.
| Channel | Scheme 1 SD (mV) | Scheme 2 SD (mV) | Scheme 3 SD (mV) |
|---|---|---|---|
| 1 | 3.380 | 0.742 | 0.923 |
| 2 | 4.073 | 1.030 | 0.742 |
| 3 | 4.284 | 1.152 | 0.837 |
| 4 | 3.269 | 0.990 | 0.816 |
| 5 | 2.318 | 0.997 | 0.811 |
| 6 | 2.181 | 1.435 | 0.999 |
| 7 | 0.932 | 1.078 | 0.828 |
| 8 | 1.088 | 0.732 | 1.014 |
| 9 | 2.911 | 1.208 | 0.995 |
| 10 | 2.314 | 0.927 | 0.893 |
| 11 | 4.761 | 1.029 | 1.122 |
| 12 | 3.367 | 0.634 | 0.814 |
| 13 | 2.975 | 0.749 | 0.997 |
| MD | 0.880 | 0.170 | 0.094 |
Scheme 1 uses standard charging without balancing. Scheme 2 uses NCVA charging without virtual transformation. Scheme 3 uses both NCVA and virtual transformation. The results in Table 2 show that Scheme 3 reduces the mean deviation of standard deviations to 0.094 mV, which is 89.3% lower than Scheme 1 and 44.7% lower than Scheme 2. The maximum standard deviation is also reduced to 1.122 mV. These improvements confirm that my virtual voltage measurement scheme effectively suppresses the differential voltage fluctuations caused by parameter inconsistency in the electric vehicle battery pack.
After the measurement scheme, I design the fault detection indicator. I use a sliding window of width \(w\) to sample the transformed differential voltage stream. At time \(k\), the windowed data matrix is:
$$
X_k =
\begin{bmatrix}
x_{1,1} & x_{1,2} & \cdots & x_{1,w} \\
x_{2,1} & x_{2,2} & \cdots & x_{2,w} \\
\vdots & \vdots & \ddots & \vdots \\
x_{n-1,1} & x_{n-1,2} & \cdots & x_{n-1,w}
\end{bmatrix}
$$
I standardize each differential channel using the mean and standard deviation obtained from historical fault-free data. The standardized matrix is:
$$
\bar{X}_k = \Sigma_0^{-1} (X_k – \mu_0)
$$
where \(\mu_0 \in \mathbb{R}^{n-1}\) is the reference mean vector and \(\Sigma_0 = \mathrm{diag}\{\sigma_{x_1}, \ldots, \sigma_{x_{n-1}}\}\) is the reference standard deviation matrix. I then compute the covariance matrix:
$$
C_k = \frac{1}{w} \bar{X}_k \bar{X}_k^T = V_k \Lambda_k V_k^T
$$
where \(\Lambda_k = \mathrm{diag}\{\lambda_{1,k}, \lambda_{2,k}, \ldots, \lambda_{n-1,k}\}\) is the diagonal matrix of eigenvalues and \(V_k\) is the matrix of corresponding eigenvectors. The eigenvalues represent the variance of the data along the principal directions. When an SSC occurs, the fault signature introduces an additional component that increases the largest eigenvalue. I therefore define the fault detection indicator as the normalized largest eigenvalue:
$$
DI_k = \max_{1 \leq j \leq n-1} \left| \frac{\lambda_{j,k} – \mu_{\lambda_j^*}}{\sigma_{\lambda_j^*}} \right|
$$
where \(\mu_{\lambda_j^*}\) and \(\sigma_{\lambda_j^*}\) are the mean and standard deviation of the \(j\)-th eigenvalue under fault-free conditions. The indicator \(DI_k\) is a scalar that measures how many standard deviations the largest eigenvalue deviates from its normal value. Because the covariance matrix is real and symmetric, its eigenvectors are orthogonal, and the eigenvalues capture the full-dimensional statistical structure of the differential voltage data. This makes the indicator highly sensitive to small anomalies while remaining robust to normal fluctuations.
I now analyze the detectability of the proposed indicator. When an SSC occurs in cell \(i\), the differential voltage vector can be written as:
$$
x = A s + \xi f_{sc}
$$
where \(A\) is the virtual measurement coefficient matrix, \(s\) is the cell voltage vector, \(\xi\) is a fault direction vector, and \(f_{sc}\) is the fault signature amplitude. After windowing and standardization, the covariance matrix becomes:
$$
C_k = C_{1,k} + C_{2,k} + C_{3,k}
$$
where
$$
C_{1,k} = \frac{1}{w} Y_k Y_k^T, \quad
C_{2,k} = \frac{1}{w} (Y_k f_{sc,k}^T A^T + A f_{sc,k} Y_k^T), \quad
C_{3,k} = \frac{1}{w} f_{sc,k} f_{sc,k}^T A^T A
$$
Here, \(Y_k\) is the fault-free standardized data matrix, and \(f_{sc,k} \in \mathbb{R}^w\) is the fault vector over the sliding window. Taking the expectation of the trace of \(C_k\), I obtain:
$$
\mathbb{E}\{\mathrm{Tr}(C_k)\} = \sum_{i=1}^{n-1} \mu_{\lambda_i^*} + \frac{t_f}{w} f_{sc}^2 \max_{l \in [1,n-1]} \{a_l^T a_l\}
$$
where \(t_f\) is the fault duration within the window. To ensure that the detection indicator exceeds the threshold \(\delta_{sc}\) when an SSC of amplitude \(f_{sc}\) occurs, I require:
$$
\delta_{sc} \geq \frac{\sum_{i=1}^{n-1} \mu_{\lambda_i^*} + \sum_{i=1}^{n-1} \sigma_{\lambda_i^*}}{1 – \frac{f_{sc} t_f}{w} \max_{l \in [1,n-1]} \{a_l^T a_l\}}
$$
This inequality reveals a quantitative relationship between the detection threshold and the original fault signature amplitude. It allows me to self-tune the control limit based on the maximum tolerable fault signature. Conversely, if the control limit is fixed, I can estimate the minimum detectable fault amplitude. The fault signature itself can be expressed as:
$$
f_{sc}(t) \approx \frac{\Delta V_l^{sv}(t)}{R_{sc}(t)} + f_{ocv}(SOC) \frac{R_s(t)}{R_{sc}(t)}
$$
where \(R_{sc}(t)\) is the equivalent short-circuit resistance, \(\Delta V_l^{sv}(t)\) is the differential voltage in the faulted channel, and \(f_{ocv}(SOC)\) is the OCV difference between the faulted cell and a normal cell. This expression shows that the fault signature depends on both the short-circuit resistance and the SOC-dependent OCV difference. For a LiFePO4 cell, the flat OCV plateau means that \(f_{ocv}\) is small over most of the SOC range, which makes the SSC detection challenging but also means that the fault signature is dominated by the resistive component.
In practice, I determine the control limit \(\delta_d\) by choosing a significance level \(\alpha\) and using kernel density estimation or an empirical method on fault-free historical data. I then set:
$$
\delta_d = \max\{\delta_{sc,1}, \delta_{sc,2}\}
$$
where \(\delta_{sc,1}\) and \(\delta_{sc,2}\) correspond to the two sub-vectors of the differential voltage. This self-tuning capability is a key advantage of my method because it makes the detection threshold interpretable and adaptable to different electric vehicle battery pack applications.
Fault localization is performed in parallel with fault detection. For the covariance matrix \(C_k\), each eigenvalue \(\lambda_{m,k}\) has a corresponding eigenvector \(v_{m,k}\). The contribution of the \(i\)-th element to the eigenvalue is defined as:
$$
\eta^{(i)} = \frac{(v_{j,k}(i))^2}{\sum_{m=1}^{n-1} (v_{j,k}(m))^2}
$$
where \(j\) is the index of the largest normalized eigenvalue. The contribution vector \(\eta\) has elements that sum to one. For a faulted cell, the contribution of the corresponding differential channel is significantly larger than that of the other channels. I set a contribution threshold \(\eta_{th}\) and identify the faulted cell as the one with the largest contribution. Because the eigenvalue decomposition produces both eigenvalues and eigenvectors simultaneously, the localization result is available at the same time as the detection result. This parallel operation allows the localization to correct false alarms from the detection stage. For example, under high-current conditions, the differential voltage variance increases, which can cause the detection indicator to exceed the threshold even without a fault. However, the contribution vector remains relatively uniform because the increased variance is distributed across all channels. By requiring both the detection indicator and the contribution threshold to be satisfied, I can effectively reduce the false alarm rate. Moreover, this correction mechanism allows me to lower the detection control limit without increasing false alarms, thereby improving the detection speed.
Table 3. Summary of equivalent impedances in the experimental electric vehicle battery pack.
| Impedance type | Value (mΩ) | Obtained from |
|---|---|---|
| Static internal resistance | ~6 | Impedance tester |
| Nickel strip connection resistance | ~6.6 | Impedance tester |
| Filtered dynamic resistance | [8, 17] | OCV and IR curves |
| Fault connection resistance | ~7 | Impedance tester |
| Steady-state polarization resistance | ~8 | Dataset and literature |
I validated my method on an experimental electric vehicle battery pack consisting of 14 series-connected LiFePO4 cells. The battery specifications are given in Table 4. The cells were connected by spot-welded nickel strips. A commercial battery management system prototype was used for voltage monitoring and active balancing. The analog front end was based on a multi-cell monitoring chip, and the main controller was a digital signal processor. Voltage data were sampled at 10 Hz and uploaded to a host computer via a CAN bus. Current and temperature were measured using an external data acquisition device with a Hall-effect current sensor and PT-100 thermocouples. A bidirectional DC power supply was used to impose the WLTC driving cycle. The maximum discharge rate was 2C, corresponding to a current of approximately 5 A. The SOC range covered 83% of the full range.
Table 4. Specifications of the LiFePO4 cells used in the electric vehicle battery pack.
| Parameter | Value | Parameter | Value |
|---|---|---|---|
| Nominal voltage (V) | 3.3 | Nominal capacity (Ah) | 2.5 |
| Internal resistance (mΩ) | 6 | Standard charge rate | 1C |
| Voltage range (V) | [2.0, 3.6] | Maximum discharge rate | 28C |
For fault injection, I connected a time-varying resistor in parallel with a target cell. This method is widely used to emulate internal soft short circuits. The equivalent short-circuit resistance \(R_{sc}\) can be constant for a momentary SSC or time-varying for a cumulative SSC. I modeled the cumulative SSC using a smooth transition function:
$$
R_{sc}(t) = R_{sc,\min} + \frac{K}{1 + e^{-r(t-t_0)}}
$$
where \(K = R_{sc,\max} – R_{sc,\min}\), \(R_{sc,\max} = 1000 R_{sc,\min}\), and \(r\) controls the transition rate. The fault current is:
$$
I_{ssc,k} = \frac{V_{i,k}^{ssc}}{R_{sc,i,k}}
$$
and the remaining capacity is updated as:
$$
C_{k+t}^{\Delta, SSC} = C_{k-1}^{\Delta} + \sum_{j=1}^{t} (I_{p,k+j} + I_{ssc,k+j}) \Delta t
$$
I compared the experimental differential voltage response with the simulated response and found good agreement, confirming the validity of the fault injection method.
Table 5. Performance comparison of three data-driven SSC diagnosis methods for the electric vehicle battery pack.
| Fault type | Method | Detection time (s) | Continuous alarm | Alarm after removal | Fault cell | Detection rate (%) |
|---|---|---|---|---|---|---|
| Momentary SSC | ICA-VC | 9.9 | No | Yes | 11 | 0.0294 |
| VCS | 80.1 | No | No | 11 | 0.00015 | |
| Proposed | 109.6 | Yes | Yes | 11 | 98.4 | |
| Cumulative SSC | ICA-VC | 649.8 | No | No | – | 0 |
| VCS | – | No | No | – | 0 | |
| Proposed | 171.3 | Yes | Yes | 11 | 97.6 |
The results in Table 5 show that my method achieves high detection rates for both momentary and cumulative SSCs. For the momentary SSC, the detection time is 109.6 s, and the method maintains a continuous alarm during the fault and after the fault is removed. This is important because the cumulative effect of an SSC can persist even after the short-circuit resistance is removed. The ICA-VC and VCS methods detect the momentary SSC faster but fail to maintain a continuous alarm and cannot detect the cumulative SSC. The reason is that these methods do not fully exploit the cumulative nature of SSC faults and are not sensitive enough to millivolt-level voltage anomalies. My method, in contrast, uses full-dimensional statistical analytics to capture the fault signature across all differential channels and over the sliding window.
I also evaluated the effect of lowering the detection control limit. As shown in Table 6, when the confidence interval is relaxed from \(\alpha = 1 – 10^{-6}\) to \(\alpha = 0.998\), the detection threshold decreases significantly. The detection time for the momentary SSC is reduced by 101.8 s, and the detection time for the cumulative SSC is reduced by 106 s. This corresponds to a reduction of at least 61.9% in detection time. Importantly, the false alarm rate does not increase because the localization stage corrects false positives. The localization stage uses the contribution vector to verify that the fault is concentrated in a single channel. When the detection threshold is lowered, the detection stage becomes more sensitive, but the localization stage filters out the false alarms caused by high-current differential voltage fluctuations.
Table 6. Effect of lowering the detection control limit on detection time for the electric vehicle battery pack.
| Confidence level | Control limit \(\delta_d\) | Detection time momentary SSC (s) | Detection time cumulative SSC (s) | False alarm rate |
|---|---|---|---|---|
| \(1 – 10^{-6}\) | 15.0414 | 109.6 | 171.3 | Very low |
| 0.998 | 8.122 | 7.8 | 65.3 | Very low |
The theoretical minimum detectable fault amplitude can be calculated from the control limit. For \(\delta_d = 15.0414\), the minimum detectable fault signature is 10.7 mV, which corresponds to an equivalent short-circuit resistance of 11.8 \(\Omega\). For \(\delta_d = 8.122\), the minimum detectable fault signature is lower, but the exact value depends on the fault duration and the current profile. The experimental results confirm that the proposed method can detect millivolt-level SSC faults within a few minutes, even under the WLTC driving cycle with a maximum current of 2C.
I further analyzed the impact of the virtual voltage measurement scheme on the diagnosis performance. The differential voltage fluctuations caused by parameter inconsistency are the main obstacle to SSC detection. By using NCVA and virtual transformation, I reduced the standard deviation of the differential channels by a factor of 2 to 3. This reduction directly improves the signal-to-noise ratio of the fault signature. The quantitative relationship between the control limit and the fault signature shows that a smaller differential voltage variance allows a lower control limit for the same fault amplitude, which in turn reduces the detection time. Therefore, the measurement scheme is not just a preprocessing step but a fundamental enabler of the high detection performance.
The proposed method has several advantages over existing data-driven methods. First, it provides an interpretable detection indicator. The indicator is based on the largest eigenvalue of the covariance matrix, which has a clear statistical meaning. The quantitative relationship between the control limit and the fault signature allows the threshold to be set according to the desired fault sensitivity. Second, the method performs fault detection and localization in parallel. The localization stage not only identifies the faulted cell but also corrects false alarms from the detection stage. This parallel operation improves the robustness of the diagnosis. Third, the method is computationally efficient. The covariance matrix is updated recursively using rank-one modifications, which reduces the computational cost of the eigenvalue decomposition. This makes the method suitable for online implementation in an electric vehicle battery pack management system.
Despite these advantages, there are limitations to my work. The method assumes that the parameter inconsistency among cells is approximately uniform. If a cell has a significantly different impedance or capacity, the differential voltage fluctuation may be misinterpreted as a fault. In practice, the battery management system can update the virtual transformation matrix periodically to account for aging. Another limitation is that the method requires a sufficient amount of fault-free historical data to compute the reference mean and standard deviation. If such data are not available, the control limit may be less accurate. However, the parallel localization stage can partially compensate for this by correcting false alarms. Future work will focus on extending the method to other battery chemistries, such as nickel-cobalt-manganese (NCM) cells, which do not have a flat OCV plateau. For NCM cells, the OCV varies more steeply with SOC, so the NCVA method may need to be adapted. I will also investigate more effective ways to suppress current-related differential voltage fluctuations under high discharge rates.
In conclusion, I have developed a full-dimensional statistical analytics method for soft short circuit diagnosis in electric vehicle battery packs. The method includes a virtual voltage measurement scheme that reduces parameter inconsistency, an eigen-decomposition-based fault detection indicator, a control-limit self-tuning rule derived from quantitative fault signature analysis, and a parallel fault localization strategy. Experimental validation on a 14-cell LiFePO4 electric vehicle battery pack under the WLTC driving cycle demonstrates that the method can detect millivolt-level SSC faults within a few minutes and maintain continuous alarms during and after the fault. The method outperforms two recently proposed data-driven methods in terms of detection rate and robustness. The interpretability of the detection indicator and the parallel operation of detection and localization make the method promising for practical implementation in electric vehicle battery pack management systems. I believe that this work contributes to the safety and reliability of electric vehicles and helps accelerate the transition to sustainable transportation.