
In my research, I focus on the high-precision torque estimation problem of the permanent magnet synchronous motor, especially the interior permanent magnet synchronous motor used in electric vehicle drive systems. The permanent magnet synchronous motor has become a central actuator in modern electrified transportation because it offers high power density, high efficiency, a wide speed range, and strong controllability. However, in real driving conditions, the permanent magnet synchronous motor is repeatedly exposed to rapid acceleration, steep-road climbing, high-speed cruising, regenerative braking, and sudden load changes. Under such conditions, magnetic saturation and cross-coupling effects become significant, and the d-axis inductance and q-axis inductance no longer remain constant. Instead, they behave as nonlinear, time-varying parameters that depend on current amplitude, current phase, and magnetic history. This dynamic behavior directly damages the accuracy of torque estimation methods that rely on fixed inductance values. Therefore, I develop a closed-loop framework that combines online inductance identification, parameter-adaptive extended flux observation, and real-time torque estimation for the permanent magnet synchronous motor.
My central objective is to answer a practical and theoretical question: how can the electromagnetic torque of a permanent magnet synchronous motor be estimated accurately when the d-axis and q-axis inductances change dynamically? I treat inductance variation not as a disturbance to be rejected, but as a state-dependent phenomenon to be tracked. This perspective is important because conventional observers and controllers often separate parameter identification from state observation. Such separation creates persistent model mismatch when the permanent magnet synchronous motor operates under heavy load, deep flux weakening, or fast transient conditions. In my method, the identified inductances are embedded directly into an extended flux observer, so the torque estimator continuously adapts to the actual magnetic state of the permanent magnet synchronous motor.
Research Context and Motivation
The global energy transition and the rapid growth of electric vehicles have made the drive system a decisive factor in vehicle performance, energy consumption, smoothness, and reliability. Among candidate machines, the permanent magnet synchronous motor, particularly the interior permanent magnet synchronous motor, is widely selected because its rotor saliency produces reluctance torque in addition to permanent-magnet torque. This saliency is beneficial for torque density, but it also makes the permanent magnet synchronous motor more sensitive to inductance variation. In an interior permanent magnet synchronous motor, the d-axis and q-axis magnetic paths are asymmetric. When the stator current increases, the iron core approaches saturation, and the magnetic permeability decreases. At the same time, the d-axis and q-axis fields interact with each other, producing cross-coupling. As a result, both the d-axis inductance and the q-axis inductance vary nonlinearly with operating point.
For a permanent magnet synchronous motor under maximum torque per ampere control, the d-axis current is usually negative and the q-axis current is positive. This operating pattern means that inductance errors can generate direct torque estimation errors. If I use fixed inductances in the torque equation, the estimated torque may deviate significantly from the actual torque, especially under high load and high-speed flux-weakening conditions. The deviation degrades torque feedback accuracy, weakens dynamic response, and may cause torque ripple, inefficient current distribution, or unstable speed regulation. Thus, online inductance identification is not an optional refinement for the permanent magnet synchronous motor; it is a necessary condition for high-performance torque estimation.
Control Strategies for the Permanent Magnet Synchronous Motor
I reviewed the main control strategies used for the permanent magnet synchronous motor: direct torque control, model predictive control, and field-oriented control. Each strategy has different implications for torque estimation accuracy and parameter sensitivity. My study adopts field-oriented control with maximum torque per ampere because it provides a clear dq-axis framework and allows the torque equation to be expressed directly in terms of inductance parameters.
| Control strategy | Core principle | Main advantage | Main limitation for permanent magnet synchronous motor |
|---|---|---|---|
| Direct torque control | Stator flux orientation with hysteresis comparators and switching table | Fast torque response and simple structure | Torque and flux ripple; switching table sensitivity |
| Model predictive control | Finite-horizon optimization using a discrete model | Multivariable and multi-objective capability | High dependence on model parameters and computation |
| Field-oriented control | dq-axis current decoupling through coordinate transformation | High steady-state performance and smooth torque | Requires accurate flux and inductance information |
Direct torque control was historically attractive for the permanent magnet synchronous motor because it avoids complex coordinate transformations and can achieve fast dynamic response. However, the hysteresis comparators create unavoidable torque and flux pulsations. Improved schemes increase the number of voltage vectors, refine sector division, or introduce space vector pulse width modulation. Model predictive control can handle multiple constraints and objectives, but its performance depends heavily on the accuracy of the permanent magnet synchronous motor model. When the inductances vary, the prediction horizon may become inaccurate. Field-oriented control remains the most widely used industrial solution because it transforms the three-phase permanent magnet synchronous motor into an equivalent dq-axis model. Nevertheless, field-oriented control still needs reliable flux and inductance information for precise torque estimation.
Mathematical Model of the Permanent Magnet Synchronous Motor
I begin with the natural abc coordinate system. The three-phase voltage equation of the permanent magnet synchronous motor is:
$$
\begin{bmatrix}
u_a \\
u_b \\
u_c
\end{bmatrix}
=
R_s
\begin{bmatrix}
i_a \\
i_b \\
i_c
\end{bmatrix}
+
\frac{d}{dt}
\begin{bmatrix}
\psi_a \\
\psi_b \\
\psi_c
\end{bmatrix}
$$
The flux equation can be written as:
$$
\begin{bmatrix}
\psi_a \\
\psi_b \\
\psi_c
\end{bmatrix}
=
\begin{bmatrix}
L_{aa} & L_{ab} & L_{ac} \\
L_{ba} & L_{bb} & L_{bc} \\
L_{ca} & L_{cb} & L_{cc}
\end{bmatrix}
\begin{bmatrix}
i_a \\
i_b \\
i_c
\end{bmatrix}
+
\begin{bmatrix}
\psi_{fa} \\
\psi_{fb} \\
\psi_{fc}
\end{bmatrix}
$$
The electromagnetic torque of the permanent magnet synchronous motor in the abc frame can be expressed through the magnetic co-energy derivative:
$$
T_e = \frac{3}{2} n_p \mathbf{i}_s^T \frac{\partial \boldsymbol{\psi}_s}{\partial \theta_m}
$$
The mechanical motion equation is:
$$
J \frac{d\omega_m}{dt} = T_e – T_L – B\omega_m
$$
$$
\frac{d\theta_m}{dt} = \omega_m
$$
Although the abc model is physically direct, it is not convenient for torque estimation because the inductances are position-dependent and coupled. I therefore use coordinate transformation. The Clark transformation maps the abc quantities into the stationary αβ frame:
$$
\begin{bmatrix}
u_\alpha \\
u_\beta
\end{bmatrix}
=
\frac{2}{3}
\begin{bmatrix}
1 & -\frac{1}{2} & -\frac{1}{2} \\
0 & \frac{\sqrt{3}}{2} & -\frac{\sqrt{3}}{2}
\end{bmatrix}
\begin{bmatrix}
u_a \\
u_b \\
u_c
\end{bmatrix}
$$
The Park transformation maps the stationary αβ frame into the rotating dq frame:
$$
\begin{bmatrix}
u_d \\
u_q
\end{bmatrix}
=
\begin{bmatrix}
\cos\theta_e & \sin\theta_e \\
-\sin\theta_e & \cos\theta_e
\end{bmatrix}
\begin{bmatrix}
u_\alpha \\
u_\beta
\end{bmatrix}
$$
In the dq rotating frame, the voltage equations of the permanent magnet synchronous motor become:
$$
u_d = R_s i_d + \frac{d\psi_d}{dt} – \omega_e \psi_q
$$
$$
u_q = R_s i_q + \frac{d\psi_q}{dt} + \omega_e \psi_d
$$
The flux linkage equations are:
$$
\psi_d = L_d i_d + \psi_f
$$
$$
\psi_q = L_q i_q
$$
The electromagnetic torque of the permanent magnet synchronous motor is:
$$
T_e = \frac{3}{2} n_p \left[ \psi_f i_q + (L_d – L_q) i_d i_q \right]
$$
This torque equation is the foundation of my estimation method. It shows that the torque of the permanent magnet synchronous motor contains a permanent-magnet component and a reluctance component. The reluctance component depends explicitly on the difference between the d-axis inductance and the q-axis inductance. Therefore, any error in either inductance produces an error in the estimated torque.
| Symbol | Meaning | Role in my torque estimation |
|---|---|---|
| u_d, u_q | dq-axis stator voltages | Inputs for observer and identification |
| i_d, i_q | dq-axis stator currents | Drive torque and magnetic saturation |
| L_d | d-axis inductance | Reluctance torque and flux observer parameter |
| L_q | q-axis inductance | Reluctance torque and observer parameter |
| psi_f | permanent-magnet flux linkage | Main torque component |
| omega_e | electrical angular speed | Coupling and observer gain scheduling |
| T_e | electromagnetic torque | Target quantity for estimation |
Space Vector Pulse Width Modulation
I use space vector pulse width modulation to drive the three-phase inverter of the permanent magnet synchronous motor. The basic idea is to synthesize the desired voltage vector by combining the available inverter voltage vectors during each switching period. For a two-level three-phase inverter, there are eight switching states: six active vectors and two zero vectors. I divide the stationary plane into six sectors. The reference voltage vector is generated by calculating the dwell times of adjacent vectors and then arranging the switching sequence.
| Switching state | Vector name | Magnitude relation | Sector role |
|---|---|---|---|
| 000 | U0 | 0 | Zero vector |
| 100 | U4 | 2Udc/3 | Active vector |
| 110 | U6 | 2Udc/3 | Active vector |
| 010 | U2 | 2Udc/3 | Active vector |
| 011 | U3 | 2Udc/3 | Active vector |
| 001 | U1 | 2Udc/3 | Active vector |
| 101 | U5 | 2Udc/3 | Active vector |
| 111 | U7 | 0 | Zero vector |
The dwell times of two adjacent active vectors in a sector can be obtained from volt-second balance:
$$
T_s \mathbf{u}_{out} = T_1 \mathbf{U}_1 + T_2 \mathbf{U}_2 + T_0 \mathbf{U}_0
$$
$$
T_s = T_1 + T_2 + T_0
$$
For sector I, the dwell times are:
$$
T_4 = \frac{\sqrt{3} T_s}{U_{dc}} \left( \frac{\sqrt{3}}{2} u_\alpha – \frac{1}{2} u_\beta \right)
$$
$$
T_6 = \frac{\sqrt{3} T_s}{U_{dc}} u_\beta
$$
$$
T_0 = T_s – T_4 – T_6
$$
I use a seven-segment switching pattern to reduce harmonic content and switching loss. The voltage utilization of space vector pulse width modulation is higher than that of sinusoidal pulse width modulation, which helps the permanent magnet synchronous motor achieve better dynamic performance under a limited dc bus voltage.
Maximum Torque Per Ampere Control of the Permanent Magnet Synchronous Motor
To improve efficiency, I apply maximum torque per ampere control to the permanent magnet synchronous motor. The dq-axis currents are related to the current vector magnitude and angle by:
$$
i_d = -i_s \sin\beta
$$
$$
i_q = i_s \cos\beta
$$
Substituting these into the torque equation gives:
$$
T_e = \frac{3}{2} n_p i_s \left[ \psi_f \cos\beta – (L_d – L_q) i_s \sin\beta \cos\beta \right]
$$
For maximum torque per ampere, I solve:
$$
\frac{\partial T_e}{\partial \beta} = 0
$$
The optimal current angle satisfies:
$$
\psi_f \sin\beta + (L_d – L_q) i_s \cos 2\beta = 0
$$
The resulting current angle is:
$$
\beta = \arcsin \left( \frac{-\psi_f + \sqrt{\psi_f^2 + 8(L_d – L_q)^2 i_s^2}}{4(L_d – L_q)i_s} \right)
$$
In my implementation, the maximum torque per ampere strategy generates the d-axis and q-axis current references. Because the inductances change with operating point, the current angle calculated from fixed inductances is only approximate. This further motivates the online inductance identification and adaptive torque estimation developed in my work.
Torque Estimation Error Caused by Fixed Inductance
I now quantify the torque estimation error of the permanent magnet synchronous motor when fixed inductances are used. Let the true torque be:
$$
T_e = \frac{3}{2} n_p \left[ \psi_f i_q + (L_d – L_q) i_d i_q \right]
$$
Let the estimated torque with fixed base inductances be:
$$
\hat{T}_e = \frac{3}{2} n_p \left[ \psi_f i_q + (L_{d0} – L_{q0}) i_d i_q \right]
$$
The absolute torque estimation error is:
$$
\Delta T_e = T_e – \hat{T}_e
$$
Substituting the two torque expressions yields:
$$
\Delta T_e = \frac{3}{2} n_p i_d i_q \left[ (L_d – L_{d0}) – (L_q – L_{q0}) \right]
$$
Define the inductance deviations as:
$$
\Delta L_d = L_d – L_{d0}
$$
$$
\Delta L_q = L_q – L_{q0}
$$
Then the torque estimation error becomes:
$$
\Delta T_e = \frac{3}{2} n_p i_d i_q (\Delta L_d – \Delta L_q)
$$
The relative torque estimation error is:
$$
\delta_{Te} = \frac{\Delta T_e}{T_e} \times 100\%
$$
When only the d-axis inductance changes, I obtain:
$$
\Delta T_e = \frac{3}{2} n_p i_d i_q \Delta L_d
$$
When only the q-axis inductance changes, I obtain:
$$
\Delta T_e = -\frac{3}{2} n_p i_d i_q \Delta L_q
$$
Because the permanent magnet synchronous motor under maximum torque per ampere control usually has negative d-axis current and positive q-axis current, the product i_d i_q is negative. This sign relationship determines whether the estimated torque becomes larger or smaller than the actual torque. Under heavy load, the q-axis magnetic path saturates, so L_q decreases significantly. Cross-coupling also reduces L_d. The combined effect produces a torque estimation error that grows with load. Under high-speed flux weakening, the large negative d-axis current changes the saturation state, and the inductance deviations again introduce error. Therefore, fixed-inductance torque estimation cannot maintain accuracy over the full operating range of the permanent magnet synchronous motor.
| Operating condition | Inductance behavior | Torque estimation consequence |
|---|---|---|
| Low-speed light load | L_d and L_q close to base values | Small torque estimation error |
| Low-speed heavy load | L_q drops strongly; L_d drops due to cross-coupling | Estimated torque becomes biased; error grows with load |
| High-speed flux weakening | L_d increases or shifts; L_q changes with saturation relief | Error increases with flux-weakening depth |
| Fast load step | L_d and L_q exhibit transient nonlinear shifts | Fixed-parameter estimator cannot track the transient state |
Variable-Step Adaptive Linear Neuron for Inductance Identification
To track the dynamic inductances of the permanent magnet synchronous motor, I design an online identification algorithm based on a variable-step adaptive linear neuron. The adaptive linear neuron is a single-layer linear neural network. Its weights can be updated online by a least mean square rule. In my method, the weights correspond to the d-axis and q-axis inductances of the permanent magnet synchronous motor. The network input is constructed from measured voltages, currents, current derivatives, and electrical angular speed. The network output is compared with the expected voltage-related quantity, and the error drives the weight update.
I reconstruct the dq-axis voltage equations into a linear parameterized form:
$$
\begin{bmatrix}
u_d – R_s i_d \\
u_q – R_s i_q – \omega_e \psi_f
\end{bmatrix}
=
\begin{bmatrix}
\frac{di_d}{dt} & -\omega_e i_q \\
\omega_e i_d & \frac{di_q}{dt}
\end{bmatrix}
\begin{bmatrix}
L_d \\
L_q
\end{bmatrix}
$$
The input vector is:
$$
X(k) =
\begin{bmatrix}
\frac{di_d(k)}{dt} \\
-\omega_e(k) i_q(k) \\
\omega_e(k) i_d(k) \\
\frac{di_q(k)}{dt}
\end{bmatrix}
$$
The expected output vector is:
$$
d(k) =
\begin{bmatrix}
u_d(k) – R_s i_d(k) \\
u_q(k) – R_s i_q(k) – \omega_e(k)\psi_f
\end{bmatrix}
$$
The weight vector is:
$$
W(k) =
\begin{bmatrix}
L_d(k) \\
L_q(k)
\end{bmatrix}
$$
The network output is:
$$
O(k) = W(k)X(k)
$$
The error is:
$$
\varepsilon(k) = d(k) – O(k)
$$
I use a variable step size to balance convergence speed and steady-state accuracy. The step size is related to the squared error:
$$
\eta(k) = \beta \left( 1 – \frac{1}{1 + \alpha \varepsilon^2(k)} \right)
$$
The weight update law is:
$$
W(k+1) = W(k) + 2\eta(k)X(k)\varepsilon(k)
$$
For convergence, the step size must satisfy:
$$
0 < 2\eta(k) \|X(k)\|^2 < 1
$$
The variable step size is large when the error is large, which improves dynamic tracking during load changes. It becomes small when the error is small, which suppresses noise and improves steady-state identification precision. This behavior is especially important for the permanent magnet synchronous motor because the inductances change continuously under magnetic saturation and cross-coupling.
| Parameter | Value in my simulation | Purpose |
|---|---|---|
| Dc bus voltage | 610 V | Inverter supply |
| Stator resistance | 0.02 ohm | Voltage reconstruction |
| Permanent-magnet flux linkage | 0.1 Wb | Torque and voltage model |
| Rated speed | 1800 r/min | High-speed condition |
| Rated torque | 80 N m | Load condition |
| Pole pairs | 4 | Electrical frequency |
| Base d-axis inductance | 9.8 mH | Initial identification value |
| Base q-axis inductance | 21.9 mH | Initial identification value |
I tested the variable-step adaptive linear neuron identification under three conditions: a high-speed ramp load, a high-speed step load, and a low-speed step load. In the high-speed ramp condition, the permanent magnet synchronous motor accelerates to 1800 r/min and then receives a load that rises uniformly to 70 N m. The d-axis inductance falls from about 9.8 mH to about 7.5 mH, and the q-axis inductance falls from about 21.9 mH to about 18.8 mH. My identification method tracks both changes with steady-state errors within about plus or minus 2 percent. The ordinary least squares method shows larger errors, approximately plus or minus 3.5 percent for L_d and plus or minus 4 percent for L_q.
In the high-speed step condition, the permanent magnet synchronous motor operates at 1800 r/min and then receives a step load of 80 N m. The d-axis inductance drops to about 6.3 mH, and the q-axis inductance drops to about 15.9 mH. The step change causes a transient overshoot in both identification methods. However, my variable-step adaptive linear neuron reduces the overshoot and converges faster. The steady-state errors of my method remain within about plus or minus 2 percent in simulation, while the ordinary least squares method reaches about plus or minus 5 percent.
In the low-speed step condition, the permanent magnet synchronous motor operates at 300 r/min and receives a step load of 30 N m. The inductance variation is smaller, but the identification is still challenging because the back electromotive force is low and the signal-to-noise ratio is reduced. My method maintains steady-state identification errors within about plus or minus 2 percent. The ordinary least squares method shows errors around plus or minus 3 to 4 percent. These results confirm that the variable-step adaptive linear neuron is effective for the permanent magnet synchronous motor under different speed and load conditions.
| Condition | Speed | Load | My L_d error | My L_q error | OLS L_d error | OLS L_q error |
|---|---|---|---|---|---|---|
| Ramp load | 1800 r/min | 0 to 70 N m | within 1.8 percent | within 1.9 percent | within 3.5 percent | within 4 percent |
| Step load | 1800 r/min | 0 to 80 N m | within 1.9 percent | within 2 percent | within 5 percent | within 4.8 percent |
| Low-speed step | 300 r/min | 0 to 30 N m | within 1.9 percent | within 1.9 percent | within 3.5 percent | within 2.9 percent |
Extended Flux Observer for the Permanent Magnet Synchronous Motor
After identifying the inductances, I embed them into an extended flux observer. The extended flux concept is useful for the permanent magnet synchronous motor because it combines the permanent-magnet flux and the saliency-related flux into a single vector. In the stationary αβ frame, I transform the dq voltage equations and obtain:
$$
\begin{bmatrix}
u_\alpha \\
u_\beta
\end{bmatrix}
=
\begin{bmatrix}
R_s + D L_q & 0 \\
0 & R_s + D L_q
\end{bmatrix}
\begin{bmatrix}
i_\alpha \\
i_\beta
\end{bmatrix}
+
D
\begin{bmatrix}
\psi_{1\alpha} \\
\psi_{1\beta}
\end{bmatrix}
$$
where D is the differential operator. The extended flux is defined as:
$$
\begin{bmatrix}
\psi_{1\alpha} \\
\psi_{1\beta}
\end{bmatrix}
=
\left[ (L_d – L_q)i_d + \psi_f \right]
\begin{bmatrix}
\cos\theta_e \\
\sin\theta_e
\end{bmatrix}
$$
The extended flux is therefore aligned with the rotor d-axis. It contains both the permanent-magnet excitation and the reluctance-related inductance difference. The stator flux of the permanent magnet synchronous motor can be reconstructed from the extended flux and the q-axis inductance term:
$$
\begin{bmatrix}
\psi_\alpha \\
\psi_\beta
\end{bmatrix}
=
\begin{bmatrix}
\psi_{1\alpha} \\
\psi_{1\beta}
\end{bmatrix}
+
L_q
\begin{bmatrix}
i_\alpha \\
i_\beta
\end{bmatrix}
$$
The electromagnetic torque can be expressed using the extended flux:
$$
T_e = \frac{3}{2} n_p \left( \psi_\alpha i_\beta – \psi_\beta i_\alpha \right)
$$
I design a minimal-order state observer for the extended flux. The state equation in the stationary frame is:
$$
D \boldsymbol{\psi}_{1\alpha\beta} = \omega_e J \boldsymbol{\psi}_{1\alpha\beta}
$$
where:
$$
J =
\begin{bmatrix}
0 & -1 \\
1 & 0
\end{bmatrix}
$$
The output equation is:
$$
\mathbf{y} = \omega_e J \boldsymbol{\psi}_{1\alpha\beta} = \mathbf{u}_{\alpha\beta} – R_s \mathbf{i}_{\alpha\beta} – L_q D \mathbf{i}_{\alpha\beta}
$$
The state observer is:
$$
\dot{\hat{\mathbf{x}}} = A\hat{\mathbf{x}} + B\mathbf{u} + K(\mathbf{y} – \hat{\mathbf{y}})
$$
For the extended flux, the observer becomes:
$$
\dot{\hat{\boldsymbol{\psi}}}_{1\alpha\beta} =
\omega_e J \hat{\boldsymbol{\psi}}_{1\alpha\beta}
+
K \left( \mathbf{y} – \omega_e J \hat{\boldsymbol{\psi}}_{1\alpha\beta} \right)
$$
The observer error dynamics are:
$$
\dot{\tilde{\boldsymbol{\psi}}}_{1\alpha\beta} =
-(A – KC)\tilde{\boldsymbol{\psi}}_{1\alpha\beta}
$$
I choose the feedback matrix K to eliminate coupling between the α-axis and β-axis flux observations:
$$
K =
\begin{bmatrix}
1 & -k \\
k & 1
\end{bmatrix}
$$
With this choice, the error equation becomes:
$$
\frac{d}{dt}
\begin{bmatrix}
\tilde{\psi}_{1\alpha} \\
\tilde{\psi}_{1\beta}
\end{bmatrix}
=
-k\omega_e
\begin{bmatrix}
\tilde{\psi}_{1\alpha} \\
\tilde{\psi}_{1\beta}
\end{bmatrix}
$$
The solution is:
$$
\tilde{\boldsymbol{\psi}}_{1\alpha\beta}(t) =
\tilde{\boldsymbol{\psi}}_{1\alpha\beta}(0) e^{-k\omega_e t}
$$
Thus, when k is positive, the extended flux observation error decays exponentially. The convergence speed is controlled by k and the electrical angular speed. If k is too small at low speed, the convergence becomes slow. If k is too large at high speed, noise may be amplified. Therefore, I schedule k as a function of speed and torque using a two-dimensional lookup table.
| Region | Speed range | Torque range | Optimization weights | k range |
|---|---|---|---|---|
| I | 0 to 300 r/min | 0 to 20 N m | 0.6, 0.3, 0.1 | 1.8 to 3.5 |
| II | 0 to 300 r/min | 20 to 80 N m | 0.4, 0.5, 0.1 | 2.2 to 4.0 |
| III | 300 to 900 r/min | 0 to 30 N m | 0.3, 0.3, 0.4 | 1.0 to 2.7 |
| IV | 300 to 900 r/min | 30 to 80 N m | 0.4, 0.4, 0.2 | 1.4 to 3.2 |
| V | 900 to 1800 r/min | 0 to 40 N m | 0.2, 0.3, 0.5 | 0.6 to 1.8 |
| VI | 900 to 1800 r/min | 40 to 80 N m | 0.3, 0.4, 0.3 | 0.9 to 2.4 |
The gain scheduling follows three principles. First, at low speed, I increase k to compensate for the small back electromotive force. Second, at high speed, I decrease k to suppress noise amplification. Third, under heavy load, I increase k to strengthen robustness against parameter mismatch and magnetic saturation. This two-dimensional scheduling makes the extended flux observer suitable for the full operating range of the permanent magnet synchronous motor.
Integrated Torque Estimation Framework
I integrate the variable-step adaptive linear neuron inductance identification and the extended flux observer into a closed-loop torque estimation framework for the permanent magnet synchronous motor. The sequence is as follows: first, I measure the dq-axis voltages, currents, and electrical speed; second, I identify L_d and L_q online using the variable-step adaptive linear neuron; third, I feed the identified inductances into the extended flux observer; fourth, I reconstruct the stator flux and calculate the electromagnetic torque. This structure directly addresses the parameter mismatch that arises from magnetic saturation and cross-coupling in the permanent magnet synchronous motor.
| Step | Function | Input | Output |
|---|---|---|---|
| 1 | Signal acquisition | Voltages, currents, speed, position | dq-axis quantities |
| 2 | Online inductance identification | u_d, u_q, i_d, i_q, omega_e | L_d, L_q estimates |
| 3 | Extended flux observation | u_alpha, u_beta, i_alpha, i_beta, L_q | Extended flux estimates |
| 4 | Torque estimation | Flux and current estimates | Electromagnetic torque estimate |
| 5 | Feedback adaptation | Identification and observation errors | Updated weights and observer gain |
I compared my integrated method with two alternatives: a torque estimation method based on ordinary least squares inductance identification, and a torque estimation method based on fixed inductances. I embedded all three inductance sources into the same extended flux observer so that the comparison focused on the effect of inductance accuracy. In the high-speed ramp condition, my method keeps the steady-state torque estimation error within about plus or minus 1.8 percent in simulation. The ordinary least squares method stays within about plus or minus 4 percent, and the fixed-inductance method stays within about plus or minus 6 percent. In the high-speed step condition, my method remains within about plus or minus 2 percent, while the ordinary least squares method reaches about plus or minus 5 percent and the fixed-inductance method reaches about plus or minus 8 percent. In the low-speed step condition, my method remains within about plus or minus 1.9 percent, the ordinary least squares method within about plus or minus 4 percent, and the fixed-inductance method within about plus or minus 5 percent.
| Simulation condition | My method torque error | OLS-based torque error | Fixed-inductance torque error |
|---|---|---|---|
| 1800 r/min ramp load | within 1.8 percent | within 4 percent | within 6 percent |
| 1800 r/min step load | within 2 percent | within 5 percent | within 8 percent |
| 300 r/min step load | within 1.9 percent | within 4 percent | within 5 percent |
Experimental Validation
I implemented the proposed algorithms on a laboratory permanent magnet synchronous motor drive platform. I used automatic code generation to convert the identification and observation algorithms into embedded C code. The control code runs on an automotive-grade 32-bit microcontroller. The platform includes a power inverter, voltage and current sampling circuits, an encoder interface, and a torque sensor. The torque sensor provides the reference electromagnetic torque for evaluating the estimation accuracy. I used the same permanent magnet synchronous motor parameters as in my simulation model. To obtain reliable inductance references, I performed offline calibration of the d-axis and q-axis inductances over the operating range. These calibrated values serve as the baseline for evaluating online identification accuracy.
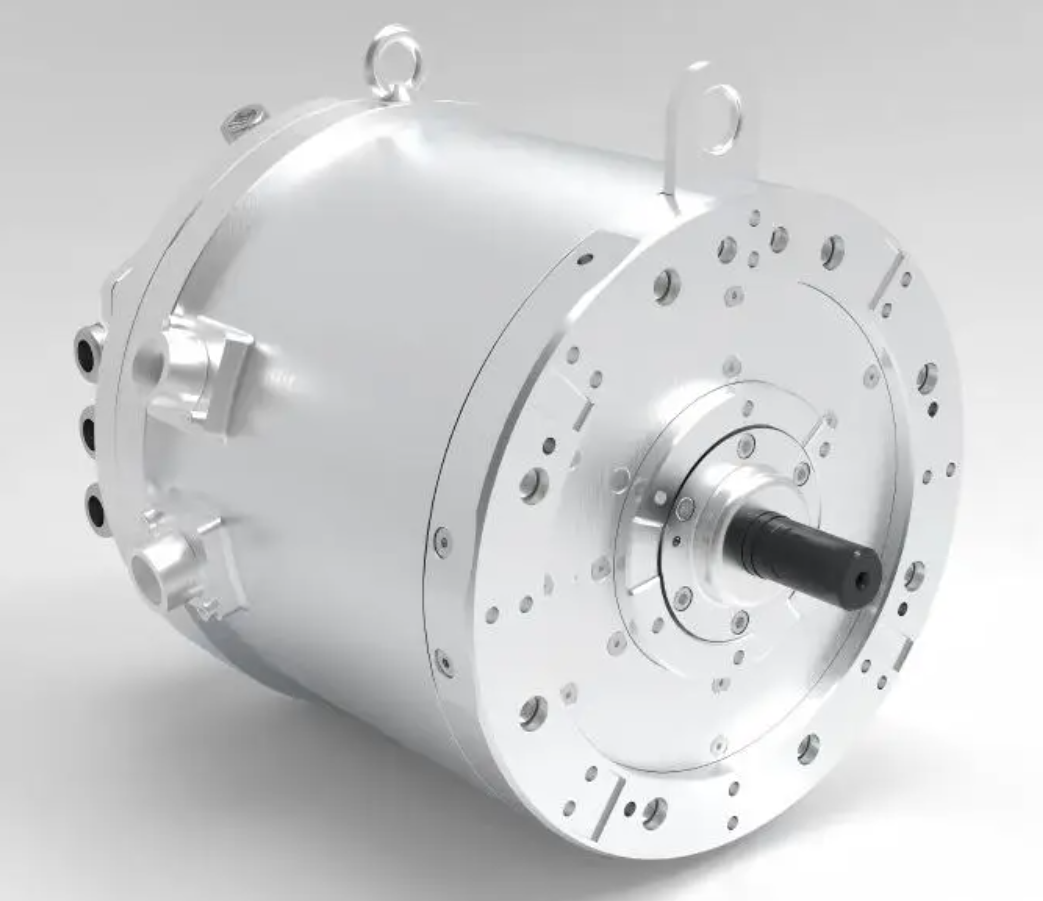
I conducted three experimental groups. In the first group, the permanent magnet synchronous motor operates at 1800 r/min and receives a ramp load up to 70 N m. In the second group, the permanent magnet synchronous motor operates at 1800 r/min and receives a step load of 80 N m. In the third group, the permanent magnet synchronous motor operates at 300 r/min and receives a step load of 30 N m. In each group, I compare my method, the ordinary least squares identification method, and the fixed-inductance method. I record speed response, d-axis inductance, q-axis inductance, and estimated torque.
| Experimental condition | Speed | Load | Purpose |
|---|---|---|---|
| High-speed ramp load | 1800 r/min | 0 to 70 N m | Continuous saturation and tracking |
| High-speed step load | 1800 r/min | 0 to 80 N m | Transient robustness |
| Low-speed step load | 300 r/min | 0 to 30 N m | Low back electromotive force and noise |
In the high-speed ramp load experiment, the permanent magnet synchronous motor accelerates to 1800 r/min with a small overshoot and then recovers to the target speed. When the load rises uniformly to 70 N m, the speed drops briefly and then recovers. The d-axis inductance decreases from about 9.8 mH to about 6.6 mH, and the q-axis inductance decreases from about 21.9 mH to about 16.4 mH. My variable-step adaptive linear neuron tracks these nonlinear changes with steady-state errors within about plus or minus 2.8 percent. The ordinary least squares method shows errors within about plus or minus 5 percent. For torque estimation, my method maintains a steady-state error within about plus or minus 2.5 percent. The ordinary least squares method remains within about plus or minus 5 percent, and the fixed-inductance method reaches about plus or minus 7.5 percent.
| High-speed ramp experiment | L_d steady error | L_q steady error | Torque steady error |
|---|---|---|---|
| My method | within 2.8 percent | within 2.8 percent | within 2.5 percent |
| OLS method | within 5 percent | within 5 percent | within 5 percent |
| Fixed inductance | not applicable | not applicable | within 7.5 percent |
In the high-speed step load experiment, the permanent magnet synchronous motor operates at 1800 r/min and receives an 80 N m step load. The d-axis inductance falls to about 6.3 mH, and the q-axis inductance falls to about 15.9 mH. My method has a d-axis overshoot of about 7.2 mH and a q-axis overshoot of about 8.5 mH. The ordinary least squares method has a d-axis overshoot of about 8.3 mH and a q-axis overshoot of about 9.5 mH. My steady-state identification accuracy is within about plus or minus 2.7 percent for L_d and within about plus or minus 2.9 percent for L_q. The ordinary least squares method stays within about plus or minus 6.6 percent for L_d and within about plus or minus 6.4 percent for L_q. For torque estimation, my method maintains a steady-state error within about plus or minus 2.8 percent, while the ordinary least squares method reaches about plus or minus 7.5 percent and the fixed-inductance method reaches about plus or minus 10 percent.
| High-speed step experiment | L_d error | L_q error | L_d overshoot | L_q overshoot | Torque error |
|---|---|---|---|---|---|
| My method | within 2.7 percent | within 2.9 percent | 7.2 mH | 8.5 mH | within 2.8 percent |
| OLS method | within 6.6 percent | within 6.4 percent | 8.3 mH | 9.5 mH | within 7.5 percent |
| Fixed inductance | not applicable | not applicable | not applicable | not applicable | within 10 percent |
In the low-speed step load experiment, the permanent magnet synchronous motor operates at 300 r/min and receives a 30 N m step load. The d-axis inductance remains around 9.6 mH, and the q-axis inductance remains around 21.2 mH. My method has a d-axis overshoot of about 0.8 mH and a q-axis overshoot of about 1.1 mH. The ordinary least squares method has a d-axis overshoot of about 1.1 mH and a q-axis overshoot of about 1.3 mH. My steady-state identification accuracy is within about plus or minus 2.6 percent for L_d and within about plus or minus 3 percent for L_q. The ordinary least squares method stays within about plus or minus 4 percent for L_d and within about plus or minus 3.9 percent for L_q. For torque estimation, my method maintains a steady-state error within about plus or minus 2.6 percent. The ordinary least squares method reaches about plus or minus 4 percent, and the fixed-inductance method reaches about plus or minus 6 percent.
| Low-speed step experiment | L_d error | L_q error | L_d overshoot | L_q overshoot | Torque error |
|---|---|---|---|---|---|
| My method | within 2.6 percent | within 3 percent | 0.8 mH | 1.1 mH | within 2.6 percent |
| OLS method | within 4 percent | within 3.9 percent | 1.1 mH | 1.3 mH | within 4 percent |
| Fixed inductance | not applicable | not applicable | not applicable | not applicable | within 6 percent |
Discussion of Results
The simulation and experimental results consistently show that inductance variation is a dominant source of torque estimation error in the permanent magnet synchronous motor. When I use fixed inductances, the torque estimate is biased because the actual magnetic state differs from the nominal state. The bias becomes severe under heavy load and high-speed operation. The ordinary least squares method improves the situation by identifying inductances online, but it suffers from noise sensitivity and limited dynamic tracking. In contrast, my variable-step adaptive linear neuron adjusts its learning rate according to the error magnitude. This mechanism provides fast tracking during transients and low noise sensitivity at steady state. When the identified inductances are embedded into the extended flux observer, the torque estimation error is reduced to within about plus or minus 2.8 percent in the experiments.
The extended flux observer also contributes to the accuracy. By expressing the permanent magnet synchronous motor voltage equation in the stationary αβ frame with a symmetric coefficient matrix, I avoid some of the coupling difficulties of the dq frame. The minimal-order observer estimates the extended flux directly. The pole placement eliminates αβ-axis coupling and ensures exponential convergence. The scheduled gain k adapts to speed and torque, so the observer performs well at both low speed and high speed. This is particularly important for the permanent magnet synchronous motor because the ratio of back electromotive force to resistive voltage drop changes widely across the speed range.
| Performance aspect | Fixed inductance | OLS identification | My method |
|---|---|---|---|
| Steady-state torque accuracy | Poor under saturation | Moderate | High |
| Dynamic tracking of inductance | None | Limited | Strong |
| Noise sensitivity | Low but biased | High | Reduced by variable step |
| Observer adaptability | Fixed parameters | Partially adaptive | Fully parameter adaptive |
| Applicability to permanent magnet synchronous motor | Only near nominal point | Moderate range | Wide operating range |
Contributions
My work makes several contributions to torque estimation for the permanent magnet synchronous motor. First, I quantify how d-axis and q-axis inductance deviations affect electromagnetic torque estimation. The derived error expression shows that the torque error is proportional to the product of d-axis and q-axis currents and to the difference between the inductance deviations. Second, I design a variable-step adaptive linear neuron that reconstructs the voltage equation into a linear parameterized form and identifies both inductances online. Third, I construct a parameter-adaptive extended flux observer that uses a minimal-order structure, pole placement, and scheduled gain. Fourth, I integrate identification, observation, and torque estimation into a closed-loop scheme for the permanent magnet synchronous motor. Fifth, I validate the method through both simulation and experiments under ramp, high-speed step, and low-speed step conditions.
Practical Implications
For electric vehicle traction, the permanent magnet synchronous motor must deliver accurate torque under rapidly changing loads. An inaccurate torque estimate can cause poor acceleration feel, torque ripple, and inefficient current control. My method improves torque accuracy by continuously tracking inductance changes. For industrial servo drives, the permanent magnet synchronous motor often operates near saturation during high-torque tasks. The proposed method reduces parameter mismatch and improves motion smoothness. For renewable energy generation, the permanent magnet synchronous motor may operate over a wide speed range. The scheduled observer gain and online inductance identification help maintain stable flux observation and torque estimation.
| Application area | Challenge for permanent magnet synchronous motor | Benefit of my method |
|---|---|---|
| Electric vehicles | Fast torque changes and magnetic saturation | High-accuracy torque feedback |
| Industrial servo | Torque ripple and parameter mismatch | Smooth torque estimation |
| Renewable generation | Wide speed range and varying load | Adaptive flux observation |
| Embedded control | Limited computation and noise | Low-order observer and variable step |
Limitations and Future Work
Although my method performs well in the tested conditions, several limitations remain. The variable-step adaptive linear neuron still depends on current derivative calculation, which can be noisy in low-speed operation. The extended flux observer assumes that the permanent-magnet flux linkage is constant, but temperature variation can change it. The observer gain scheduling uses a two-dimensional table, which requires calibration effort. In future work, I plan to introduce sliding-mode or extended-state observation to improve disturbance rejection. I also plan to include resistance variation, flux linkage drift, measurement noise, and temperature effects in the evaluation. Moreover, I intend to test the permanent magnet synchronous motor at higher speeds and deeper flux-weakening operation. Model predictive and intelligent learning methods may also be combined with my framework to further improve robustness.
Conclusion
I have studied high-precision torque estimation for the permanent magnet synchronous motor under dynamic inductance variation. I established multi-coordinate mathematical models, analyzed the torque error caused by fixed inductances, designed a variable-step adaptive linear neuron for online d-axis and q-axis inductance identification, and constructed a parameter-adaptive extended flux observer. The identified inductances are embedded into the observer, forming a closed loop of online inductance identification, extended flux observation, and torque estimation. Simulation and experimental results show that my method tracks inductance changes accurately and keeps steady-state torque estimation error within about plus or minus 2.8 percent. It outperforms both the ordinary least squares identification method and the fixed-inductance method. These results confirm that dynamic inductance awareness is essential for accurate torque estimation in the permanent magnet synchronous motor and that the proposed framework is a practical solution for high-performance drive systems.