
In this study, I investigate the thermal performance of an electric vehicle battery pack by coupling heat pipes with a liquid cooling structure. The electric vehicle battery pack is built from prismatic lithium iron phosphate cells. I select a 3.2 V, 180 Ah cell and arrange twenty-four cells in a 3 × 8 layout as a 1P24S electric vehicle battery pack. My main objective is to control the maximum temperature, temperature difference, and pressure drop of the electric vehicle battery pack under 1C discharge. I first establish an NTGK electrochemical heat generation model, then couple it with a fluid model and a heat pipe model. I compare a parallel flow channel and a serpentine flow channel before and after heat pipe coupling. Based on these results, I design a new series-parallel flow channel and optimize its structural parameters through a Taguchi experiment and grey relational multi-objective analysis. The results show that the proposed coupled cooling structure can significantly reduce the maximum temperature and pressure drop of the electric vehicle battery pack while maintaining good temperature uniformity.
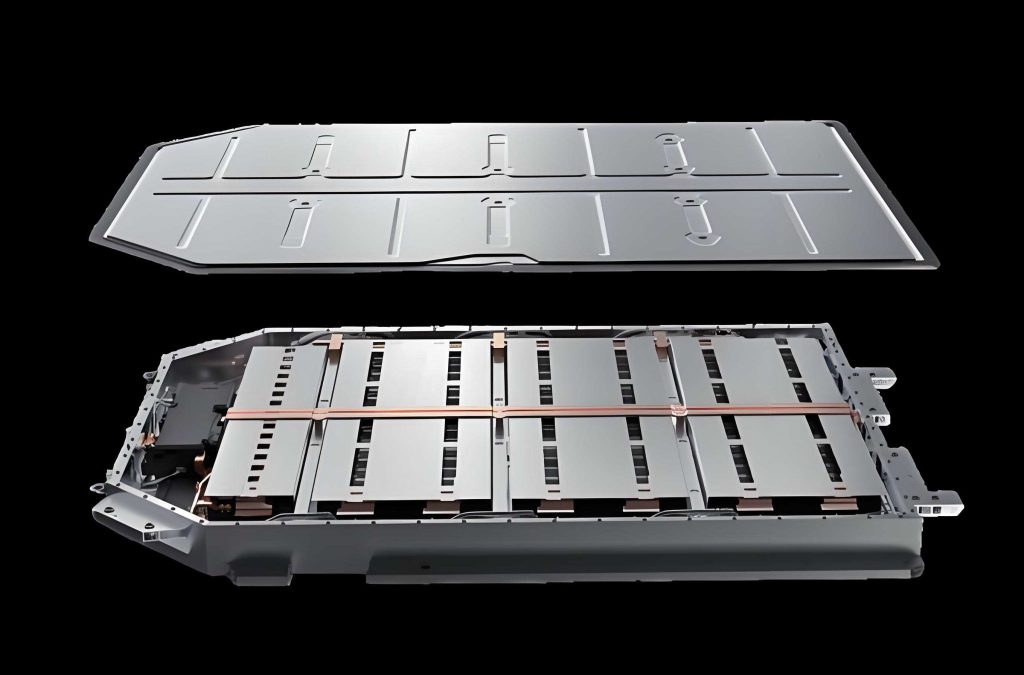
The electric vehicle battery pack is the core energy storage unit of an electric vehicle, and its thermal state directly affects efficiency, cycle life, and safety. During charging and discharging, the electric vehicle battery pack generates heat through electrochemical reactions, ohmic resistance, and polarization. If this heat cannot be removed in time, the temperature of the electric vehicle battery pack rises, local hot spots form, and thermal runaway risk increases. Therefore, I treat thermal management as a coupled problem involving electrochemistry, heat transfer, and fluid flow.
I use a prismatic lithium iron phosphate cell because it offers high safety, long cycle life, and good spatial utilization. The main physical parameters of the electric vehicle battery pack cell are listed below.
| Parameter | Value |
|---|---|
| Cell type | Prismatic LiFePO4 cell |
| Nominal voltage | 3.2 V |
| Nominal capacity | 180 Ah |
| Cell dimensions | 207 mm × 174 mm × 72 mm |
| Pack configuration | 1P24S |
| Cell density | 2248 kg/m3 |
| Specific heat | 850 J/(kg·K) |
| Thermal conductivity | 15 / 15 / 1 W/(m·K) |
| Maximum discharge rate | 3C |
| Operating temperature | -34 °C to 65 °C |
For the thermal model of the electric vehicle battery pack, I assume that each cell is a homogeneous body with anisotropic thermal conductivity. I also assume that density, specific heat, and thermal conductivity remain constant during the discharge process. These assumptions allow me to focus on the coupled thermal behavior of the electric vehicle battery pack without introducing excessive computational complexity.
The heat generation of the electric vehicle battery pack can be decomposed into electrochemical reaction heat, ohmic heat, polarization heat, and side reaction heat. Because side reaction heat is small under normal operation, I neglect it in this study. The main heat generation terms are expressed as follows:
$$ Q = Q_r + Q_\Omega + Q_p + Q_s $$
$$ Q_r = n F T \frac{\partial E}{\partial T} $$
$$ Q_\Omega = I^2 R_o $$
$$ Q_p = I \eta $$
Here, \(Q_r\) is the electrochemical reaction heat, \(Q_\Omega\) is the ohmic heat, \(Q_p\) is the polarization heat, \(Q_s\) is the side reaction heat, \(n\) is the number of transferred electrons, \(F\) is Faraday’s constant, \(T\) is temperature, \(E\) is equilibrium potential, \(I\) is current, \(R_o\) is ohmic resistance, and \(\eta\) is polarization voltage.
For the energy balance inside the electric vehicle battery pack, I use the following conduction-convection energy equation:
$$ \rho c_p \left( \frac{\partial T}{\partial t} + \mathbf{u} \cdot \nabla T \right) = \nabla \cdot (k \nabla T) + S_h $$
In this equation, \(\rho\) is density, \(c_p\) is specific heat, \(\mathbf{u}\) is velocity, \(k\) is thermal conductivity, and \(S_h\) is the volumetric heat source. For the solid regions of the electric vehicle battery pack, \(\mathbf{u}=0\), so the energy equation reduces to transient heat conduction.
I use the NTGK electrochemical model to describe the electrical behavior of the electric vehicle battery pack. The volumetric current transfer rate is calculated as:
$$ J_{ech} = a Y \left[ U – (\phi_+ – \phi_-) \right] $$
where \(a\) is the specific surface area, \(U\) is the open-circuit potential function, \(Y\) is the model parameter, and \(\phi_+\) and \(\phi_-\) are the positive and negative phase potentials. The parameters \(U\) and \(Y\) are functions of depth of discharge and temperature. I use polynomial forms:
$$ U = \sum_{n=0}^{5} a_n \mathrm{DOD}^{n} $$
$$ Y = \sum_{n=0}^{5} b_n \mathrm{DOD}^{n} $$
The depth of discharge is defined as:
$$ \mathrm{DOD} = \frac{1}{3600 Q_{Ah}} \int I \, dt $$
where \(Q_{Ah}\) is the capacity of the electric vehicle battery pack in ampere-hours. The electrochemical heat source is then written as:
$$ S_{ech} = J_{ech} \left[ U – (\phi_+ – \phi_-) – T \frac{\partial U}{\partial T} \right] $$
This heat source is applied to the active cell region of the electric vehicle battery pack. The busbars and tabs are treated as conductive solids with Joule heating.
| Parameter | Coefficient | Value |
|---|---|---|
| U | a0 | 4.12 |
| U | a1 | -0.804 |
| U | a2 | 1.075 |
| U | a3 | -1.177 |
| U | a4 | 0 |
| U | a5 | 0 |
| Y | b0 | 1168.59 |
| Y | b1 | -8928 |
| Y | b2 | 52504.6 |
| Y | b3 | -136231 |
| Y | b4 | 158531.7 |
| Y | b5 | -67578.5 |
For the liquid cooling side of the electric vehicle battery pack, I use a 50% ethylene glycol aqueous solution as the coolant. I treat the coolant as an incompressible Newtonian fluid with constant properties. The coolant properties and the aluminum cold plate properties are summarized below.
| Material | Density (kg/m3) | Specific heat (J/(kg·K)) | Thermal conductivity (W/(m·K)) | Dynamic viscosity (Pa·s) |
|---|---|---|---|---|
| 50% ethylene glycol aqueous solution | 1069 | 3494 | 0.419 | 0.00315 |
| Aluminum | 2702 | 903 | 237 | — |
The flow state in the liquid cooling channel is evaluated by the Reynolds number. For a rectangular channel, I use:
$$ \mathrm{Re} = \frac{\rho_w v_w}{\mu} \frac{2ab}{a+b} $$
where \(\rho_w\) is coolant density, \(v_w\) is coolant velocity, \(\mu\) is dynamic viscosity, and \(a\) and \(b\) are the channel cross-sectional dimensions. At the maximum coolant velocity of 0.6 m/s, the Reynolds number remains below 2300, so the flow in the liquid cooling structure is laminar. Therefore, I solve the laminar mass, momentum, and energy equations for the coolant.
$$ \frac{\partial \rho}{\partial t} + \nabla \cdot (\rho \mathbf{u}) = 0 $$
$$ \frac{\partial (\rho \mathbf{u})}{\partial t} + \nabla \cdot (\rho \mathbf{u}\mathbf{u}) = -\nabla p + \nabla \cdot \boldsymbol{\tau} + \rho \mathbf{F} $$
$$ \frac{\partial (\rho e)}{\partial t} + \nabla \cdot (\rho e \mathbf{u}) = -\nabla \cdot \mathbf{q} + \boldsymbol{\tau} : \nabla \mathbf{u} + Q $$
Here, \(p\) is pressure, \(\boldsymbol{\tau}\) is viscous stress tensor, \(\mathbf{F}\) is body force, \(e\) is internal energy, \(\mathbf{q}\) is heat flux, and \(Q\) is volumetric heat source. For the solid cold plate, I solve only heat conduction.
I model the heat pipe as a very high effective thermal conductor. This is a common and efficient approach when the main purpose is to capture the heat transport effect of the heat pipe inside the electric vehicle battery pack. The effective thermal conductivity is set as:
$$ k_{hp} = 5000 \ \mathrm{W/(m \cdot K)} $$
Each prismatic cell in the electric vehicle battery pack is coupled with L-shaped heat pipes. The evaporator section contacts the cell surface, while the condenser section contacts the liquid cooling channel. The heat pipes are arranged in an alternating pattern so that heat from the interior of the electric vehicle battery pack can be transferred to the cold plate at the bottom. This layout avoids direct contact between the coolant and the cells, reducing leakage risk in the electric vehicle battery pack.
The boundary and initial conditions used for the coupled simulation are listed below. The initial temperature of the electric vehicle battery pack and the coolant is 298 K. The outer walls exchange heat with the ambient environment by natural convection. The solid-fluid interfaces are set as coupled walls. The inlet is a velocity inlet, and the outlet is a pressure outlet.
| Condition | Value or setting |
|---|---|
| Initial temperature | 298 K |
| Discharge rate | 1C |
| Ambient convective coefficient | 5 W/(m2·K) |
| Coolant inlet type | Velocity inlet |
| Coolant outlet type | Pressure outlet |
| Coolant flow state | Laminar |
| Time step | 20 s |
| Total discharge time | 3600 s |
| Maximum iterations per step | 20 |
Before performing the coupled analysis, I verify mesh independence for the electric vehicle battery pack model. The maximum temperature and pressure drop are monitored as the mesh size changes. The results are shown below.
| Mesh count (×10^5) | Maximum temperature (K) | Temperature change | Pressure drop (Pa) | Pressure change |
|---|---|---|---|---|
| 5.14 | 330.50 | — | 394.51 | — |
| 7.06 | 337.19 | 1.96% | 405.86 | 2.80% |
| 14.4 | 327.46 | -2.97% | 416.45 | 2.61% |
| 21.5 | 327.49 | 0.01% | 406.74 | -2.33% |
| 38.1 | 326.33 | -0.35% | 412.33 | 1.37% |
| 76.7 | 323.60 | -0.85% | 411.16 | -0.28% |
| 210.8 | 321.71 | -0.59% | 400.40 | -2.62% |
| 1215.1 | 321.45 | -0.08% | 400.37 | -0.01% |
The maximum temperature and pressure drop become stable when the mesh count reaches approximately \(2.108 \times 10^6\). Further refinement changes the maximum temperature by less than 0.1% and the pressure drop by less than 0.01%. Therefore, I use this mesh level for the subsequent simulations of the electric vehicle battery pack.
I also validate the numerical model against published experimental data for a similar liquid-cooled electric vehicle battery pack. The comparison includes a 1C discharge case with a coolant flow rate of 0.5 L/min and an inlet temperature of 20 °C. The error is within about 2%, which supports the reliability of my model.
| Condition | Experimental result (°C) | Numerical result (°C) | Error |
|---|---|---|---|
| Maximum temperature | 36.31 | 36.72 | 1.13% |
| Outlet coolant temperature | 32.37 | 33.02 | 2.01% |
After model validation, I study two traditional liquid cooling channel structures for the electric vehicle battery pack: a parallel flow channel and a serpentine flow channel. I evaluate each structure with and without heat pipe coupling. The performance indicators are the maximum temperature of the electric vehicle battery pack, the temperature difference of the electric vehicle battery pack, and the pressure drop in the liquid cooling channel.
For the parallel flow channel without heat pipes, the coolant velocity ranges from 0.1 m/s to 0.6 m/s. The results show that increasing velocity reduces the maximum temperature slightly, but it also increases pressure drop significantly. The temperature difference changes only modestly.
| Velocity (m/s) | Maximum temperature (K) | Temperature difference (K) | Pressure drop (Pa) |
|---|---|---|---|
| 0.1 | 323.30 | 3.68 | 20.15 |
| 0.2 | 322.33 | 3.77 | 71.31 |
| 0.3 | 321.91 | 3.93 | 149.08 |
| 0.4 | 321.63 | 4.09 | 262.60 |
| 0.5 | 321.41 | 4.12 | 418.50 |
| 0.6 | 321.25 | 4.19 | 585.01 |
For the parallel flow channel with heat pipe coupling, the maximum temperature of the electric vehicle battery pack decreases by about 4 K to 8 K compared with the no-heat-pipe case. The temperature difference is also improved at most velocities. The pressure drop remains almost the same because it is dominated by the liquid channel geometry and coolant velocity.
| Velocity (m/s) | Maximum temperature (K) | Temperature difference (K) | Pressure drop (Pa) |
|---|---|---|---|
| 0.1 | 317.14 | 1.87 | 20.15 |
| 0.2 | 315.04 | 1.63 | 71.31 |
| 0.3 | 314.98 | 3.77 | 149.08 |
| 0.4 | 314.28 | 3.67 | 262.60 |
| 0.5 | 312.13 | 2.38 | 418.50 |
| 0.6 | 313.49 | 3.64 | 585.01 |
For the serpentine flow channel without heat pipes, the pressure drop is much higher than that of the parallel channel. The maximum temperature decreases only slightly as velocity increases. The temperature difference remains relatively large. This shows that the serpentine channel improves heat exchange area and contact time, but its flow resistance is a serious penalty for the electric vehicle battery pack.
| Velocity (m/s) | Maximum temperature (K) | Temperature difference (K) | Pressure drop (Pa) |
|---|---|---|---|
| 0.1 | 323.29 | 4.82 | 223.75 |
| 0.2 | 322.09 | 4.98 | 942.64 |
| 0.3 | 321.57 | 5.06 | 2174.33 |
| 0.4 | 321.27 | 5.11 | 3945.49 |
| 0.5 | 321.07 | 5.15 | 6054.63 |
| 0.6 | 320.93 | 5.17 | 8874.06 |
For the serpentine flow channel with heat pipe coupling, the maximum temperature of the electric vehicle battery pack drops by about 8 K to 9 K. The temperature difference is also reduced significantly. This confirms that heat pipes can compensate for the thermal resistance between the cells and the liquid cooling plate. However, the pressure drop of the serpentine channel remains high.
| Velocity (m/s) | Maximum temperature (K) | Temperature difference (K) |
|---|---|---|
| 0.1 | 316.04 | 2.10 |
| 0.2 | 314.03 | 3.78 |
| 0.3 | 313.08 | 3.70 |
| 0.4 | 312.54 | 3.65 |
| 0.5 | 312.20 | 3.64 |
| 0.6 | 311.96 | 3.62 |
I also study the effect of coolant inlet temperature on the electric vehicle battery pack. Lower inlet temperature increases the heat transfer driving force, but it may also increase the temperature difference across the electric vehicle battery pack. The results for the parallel and serpentine channels show the same trend: a lower inlet temperature reduces the maximum temperature but can worsen temperature uniformity if the cooling distribution is not well designed.
| Inlet temperature (K) | Maximum temperature (K) | Temperature difference (K) |
|---|---|---|
| 298 | 313.49 | 3.64 |
| 293 | 308.95 | 2.48 |
| 288 | 305.80 | 2.53 |
| 283 | 304.10 | 3.58 |
| 278 | 300.88 | 3.38 |
| Inlet temperature (K) | Maximum temperature (K) | Temperature difference (K) |
|---|---|---|
| 298 | 311.96 | 3.62 |
| 293 | 308.62 | 3.59 |
| 288 | 305.05 | 3.48 |
| 283 | 301.49 | 3.28 |
| 278 | 298.47 | 4.44 |
The comparison between the parallel and serpentine channels shows that heat pipe coupling is highly effective for the electric vehicle battery pack. Under different coolant velocities, the average maximum temperature reduction is about 7.5 K for the parallel channel and about 8.5 K for the serpentine channel. Under different inlet temperatures, the average maximum temperature reduction is about 11.5 K for the parallel channel and about 12 K for the serpentine channel. These results confirm that a heat pipe coupled liquid cooling system can improve the thermal performance of an electric vehicle battery pack.
| Channel type | Average maximum temperature reduction under different velocities (K) | Average maximum temperature reduction under different inlet temperatures (K) |
|---|---|---|
| Parallel flow channel | 7.5 | 11.5 |
| Serpentine flow channel | 8.5 | 12.0 |
Although the serpentine channel provides better temperature control, its pressure drop is extremely high. The parallel channel has low pressure drop but weaker heat exchange. Therefore, I design a series-parallel flow channel for the electric vehicle battery pack. This new channel combines the low flow resistance of the parallel structure with the improved contact and heat exchange of the serpentine structure.
The series-parallel channel has a main inlet, multiple branch channels, and a converging outlet. The coolant first enters the main channel, then distributes into several branch channels, and finally converges to the outlet. The branch channels are placed in contact with the condenser sections of the heat pipes. This design increases the contact area between the coolant and the heat pipe condenser while keeping the pressure drop at a moderate level.
I first determine the best coolant velocity and inlet temperature for the series-parallel channel by a control variable method. The velocity is varied from 0.1 m/s to 0.6 m/s, and the inlet temperature is varied from 298 K to 278 K. The results are shown below.
| Velocity (m/s) | Temperature difference (K) | Maximum temperature (K) | Pressure drop (Pa) |
|---|---|---|---|
| 0.1 | 4.89 | 321.36 | 111.78 |
| 0.2 | 6.93 | 319.61 | 481.07 |
| 0.3 | 6.86 | 318.53 | 1106.89 |
| 0.4 | 6.81 | 317.90 | 1995.40 |
| 0.5 | 6.78 | 317.21 | 3165.14 |
| 0.6 | 6.77 | 317.50 | 4582.90 |
The maximum temperature reaches its minimum at 0.5 m/s. When the velocity increases to 0.6 m/s, the maximum temperature rises slightly because the residence time of the coolant becomes too short for complete heat exchange. The pressure drop continues to increase with velocity. Therefore, I select 0.5 m/s as the best coolant velocity for the series-parallel channel in the electric vehicle battery pack.
| Inlet temperature (K) | Temperature difference (K) | Maximum temperature (K) |
|---|---|---|
| 298 | 6.78 | 317.50 |
| 293 | 6.68 | 313.85 |
| 288 | 6.24 | 310.21 |
| 283 | 6.51 | 306.58 |
| 278 | 7.52 | 303.65 |
As the inlet temperature decreases, the maximum temperature decreases. However, the temperature difference first decreases and then increases. The minimum temperature difference occurs at 288 K. Therefore, I select 288 K as the best inlet temperature for the series-parallel channel in the electric vehicle battery pack.
After fixing the coolant velocity and inlet temperature, I optimize the structural parameters of the series-parallel channel. I use the number of branch channels \(N\), the branch channel width \(D_1\), the spacing \(D_2\), and the thickness \(D_3\) as design factors. The objective functions are the temperature difference of the electric vehicle battery pack and the pressure drop of the coolant in the channel. A Taguchi experiment is used to reduce the number of simulations while maintaining statistical representativeness.
| Level | Number of branch channels \(N\) | Branch width \(D_1\) (mm) | Spacing \(D_2\) (mm) | Thickness \(D_3\) (mm) |
|---|---|---|---|---|
| 1 | 2 | 15 | 30 | 2 |
| 2 | 3 | 20 | 36 | 3 |
| 3 | — | 25 | 44 | 4 |
| 4 | — | 30 | 50 | 5 |
I use an L32 orthogonal array to arrange the experiments. For each design combination, I build the corresponding electric vehicle battery pack cooling model and run the coupled simulation. The response values are the maximum temperature, the temperature difference, and the pressure drop.
| Run | \(N\) | \(D_1\) | \(D_2\) | \(D_3\) | Maximum temperature (K) | Temperature difference (K) | Pressure drop (Pa) |
|---|---|---|---|---|---|---|---|
| 1 | 2 | 15 | 30 | 2 | 308.04 | 4.42 | 3150.66 |
| 2 | 2 | 15 | 36 | 3 | 306.25 | 3.57 | 3159.78 |
| 3 | 2 | 15 | 44 | 4 | 305.47 | 3.31 | 3719.57 |
| 4 | 2 | 15 | 50 | 5 | 305.25 | 3.23 | 3603.73 |
| 5 | 2 | 20 | 30 | 2 | 309.48 | 5.28 | 2933.53 |
| 6 | 2 | 20 | 36 | 3 | 306.09 | 3.48 | 3152.66 |
| 7 | 2 | 20 | 44 | 4 | 306.30 | 3.93 | 3105.48 |
| 8 | 2 | 20 | 50 | 5 | 305.69 | 3.69 | 2746.01 |
| 9 | 2 | 25 | 30 | 3 | 307.81 | 4.28 | 2548.24 |
| 10 | 2 | 25 | 36 | 2 | 312.28 | 6.93 | 2179.57 |
| 11 | 2 | 25 | 44 | 5 | 310.08 | 4.20 | 2678.60 |
| 12 | 2 | 25 | 50 | 4 | 305.33 | 3.23 | 1962.44 |
| 13 | 2 | 30 | 30 | 3 | 306.08 | 3.32 | 2661.06 |
| 14 | 2 | 30 | 36 | 2 | 305.95 | 3.36 | 2390.11 |
| 15 | 2 | 30 | 44 | 5 | 307.86 | 4.11 | 2376.79 |
| 16 | 2 | 30 | 50 | 4 | 306.06 | 3.77 | 927.75 |
| 17 | 3 | 15 | 30 | 5 | 307.21 | 3.76 | 2912.72 |
| 18 | 3 | 15 | 36 | 4 | 306.04 | 4.33 | 2786.14 |
| 19 | 3 | 15 | 44 | 3 | 305.42 | 3.48 | 2390.25 |
| 20 | 3 | 15 | 50 | 2 | 306.46 | 3.90 | 1665.56 |
| 21 | 3 | 20 | 30 | 5 | 308.55 | 4.43 | 2910.49 |
| 22 | 3 | 20 | 36 | 4 | 305.57 | 3.85 | 2633.19 |
| 23 | 3 | 20 | 44 | 3 | 305.69 | 3.58 | 1968.11 |
| 24 | 3 | 20 | 50 | 2 | 307.32 | 4.02 | 939.55 |
| 25 | 3 | 25 | 30 | 4 | 309.21 | 4.09 | 2795.90 |
| 26 | 3 | 25 | 36 | 5 | 305.40 | 3.13 | 2440.17 |
| 27 | 3 | 25 | 44 | 2 | 306.70 | 4.73 | 854.02 |
| 28 | 3 | 25 | 50 | 3 | 309.07 | 4.00 | 606.99 |
| 29 | 3 | 30 | 30 | 4 | 308.51 | 4.06 | 2309.17 |
| 30 | 3 | 30 | 36 | 5 | 305.71 | 3.37 | 828.45 |
| 31 | 3 | 30 | 44 | 2 | 308.09 | 4.77 | 694.73 |
| 32 | 3 | 30 | 50 | 3 | 310.08 | 4.60 | 590.94 |
The maximum temperature of the electric vehicle battery pack changes by only about 1.5% among the thirty-two cases, while the temperature difference changes by about 26.9% and the pressure drop changes by about 84.1%. This means that the structural parameters of the series-parallel channel mainly affect temperature uniformity and pressure drop, while the maximum temperature is less sensitive. Therefore, I focus the multi-objective optimization on temperature difference and pressure drop.
I use the signal-to-noise ratio for smaller-the-better characteristics:
$$ \eta_{S/N} = -10 \log_{10} \left( \frac{1}{n} \sum_{i=1}^{n} y_i^2 \right) $$
where \(n\) is the number of observations and \(y_i\) is the response value. A higher signal-to-noise ratio indicates better performance. The response tables for temperature difference and pressure drop are shown below.
| Objective | Level | \(N\) | \(D_1\) | \(D_2\) | \(D_3\) |
|---|---|---|---|---|---|
| Temperature difference | 1 | -16.26 | -16.29 | -16.49 | -17.03 |
| Temperature difference | 2 | -16.50 | -16.49 | -16.50 | -16.22 |
| Temperature difference | 3 | — | -16.34 | -16.32 | -15.83 |
| Temperature difference | 4 | — | -16.38 | -16.20 | -16.43 |
| Temperature difference | Range | 0.24 | 0.20 | 0.30 | 1.20 |
| Pressure drop | 1 | -68.29 | -69.09 | -68.84 | -64.13 |
| Pressure drop | 2 | -63.88 | -67.62 | -67.22 | -65.14 |
| Pressure drop | 3 | — | -65.03 | -65.78 | -67.50 |
| Pressure drop | 4 | — | -62.06 | -62.51 | -67.58 |
| Pressure drop | Range | 4.41 | 6.48 | 6.33 | 3.46 |
For temperature difference, the most influential factor is \(D_3\), followed by \(D_2\), \(N\), and \(D_1\). For pressure drop, the most influential factor is \(D_1\), followed by \(D_2\), \(N\), and \(D_3\). The single-objective optima are different: the temperature difference is minimized when \(N=2\), \(D_1=15\) mm, \(D_2=50\) mm, and \(D_3=4\) mm, while the pressure drop is minimized when \(N=3\), \(D_1=30\) mm, \(D_2=50\) mm, and \(D_3=2\) mm. This conflict requires a multi-objective compromise for the electric vehicle battery pack.
| Optimization basis | Maximum temperature (K) | Temperature difference (K) | Pressure drop (Pa) |
|---|---|---|---|
| Temperature difference as the only objective | 303.78 | 3.40 | 3531.02 |
| Pressure drop as the only objective | 308.54 | 4.35 | 680.63 |
To balance temperature difference and pressure drop, I use grey relational analysis. I treat the lowest temperature difference and the lowest pressure drop as the reference sequence. After normalizing the data, I calculate the grey relational coefficient for each response:
$$ \xi_i(k) = \frac{\min_i \min_k |y_0(k)-y_i(k)| + \zeta \max_i \max_k |y_0(k)-y_i(k)|}{|y_0(k)-y_i(k)| + \zeta \max_i \max_k |y_0(k)-y_i(k)|} $$
where \(\zeta\) is the distinguishing coefficient, set to 0.5. The grey relational grade for each experiment is then obtained by averaging the coefficients:
$$ \gamma_i = \frac{1}{m} \sum_{k=1}^{m} \xi_i(k) $$
For the two objectives, I also use a combined grade:
$$ \gamma = \sqrt{ \frac{\gamma_{\Delta T}^2 + \gamma_{\Delta P}^2}{2} } $$
This combined grade allows me to evaluate each structural parameter set as a multi-objective solution for the electric vehicle battery pack. The factor-level grey relational coefficients are shown below.
| Level | \(N\) | \(D_1\) | \(D_2\) | \(D_3\) |
|---|---|---|---|---|
| 1 | 0.5000 | 0.4281 | 0.7767 | 0.4528 |
| 2 | 1.0000 | 0.5660 | 0.5857 | 0.8144 |
| 3 | — | 0.8498 | 0.5976 | 0.7906 |
| 4 | — | 0.8339 | 0.7453 | 0.4678 |
According to the grey relational grades, the optimal structural parameters for the series-parallel channel are \(N=3\), \(D_1=25\) mm, \(D_2=30\) mm, and \(D_3=3\) mm. This combination provides the largest grey relational coefficient and achieves a balanced improvement in temperature uniformity and pressure drop for the electric vehicle battery pack.
I build the optimized series-parallel channel model and perform the coupled simulation. The optimized channel reduces the maximum temperature of the electric vehicle battery pack to 303.22 K. The temperature difference is 3.24 K, and the pressure drop is 1956.156 Pa. Compared with the initial series-parallel design, the maximum temperature is reduced by 2.33 K, the temperature difference is reduced by 6.10%, and the pressure drop is reduced by 38.20%.
| Case | Maximum temperature (K) | Temperature difference (K) | Pressure drop (Pa) |
|---|---|---|---|
| Initial series-parallel channel | 305.56 | 3.45 | 3165.14 |
| Optimized series-parallel channel | 303.22 | 3.24 | 1956.16 |
| Improvement | 2.33 K | 6.10% | 38.20% |
I also compare the optimized series-parallel channel with the traditional channels. The maximum temperature is 2.58 K lower than that of the parallel channel. The temperature difference is 6.94% lower than that of the serpentine channel. The pressure drop is 67.69% lower than that of the serpentine channel. Compared with the original battery heat generation model without an optimized cooling system, the maximum temperature of the electric vehicle battery pack is reduced by 21.78 K.
| Comparison | Maximum temperature | Temperature difference | Pressure drop |
|---|---|---|---|
| Optimized versus parallel channel | 2.58 K lower | — | — |
| Optimized versus serpentine channel | — | 6.94% lower | 67.69% lower |
| Optimized versus original heat generation model | 21.78 K lower | — | — |
The optimized series-parallel channel demonstrates that heat pipe coupling and liquid cooling can be combined effectively in an electric vehicle battery pack. The heat pipes reduce the thermal resistance between the cell core and the cold plate, while the series-parallel channel distributes the coolant more uniformly and avoids excessive pressure drop. The Taguchi method reduces the number of simulations, and the grey relational analysis resolves the conflict between temperature difference and pressure drop. This workflow provides a practical design route for thermal management of an electric vehicle battery pack.
In my analysis, the most important physical mechanisms in the electric vehicle battery pack are as follows. First, the electrochemical heat generation in the cell core creates a temperature gradient from the center to the surface. Second, the heat pipe transfers heat from the cell surface to the condenser region with very low thermal resistance. Third, the liquid cooling channel removes heat from the condenser region and carries it to the outlet. Fourth, the flow distribution in the channel controls both the local heat transfer coefficient and the pressure drop. When the channel is poorly designed, some heat pipes receive less coolant flow, and the electric vehicle battery pack develops hot spots. When the channel is well designed, the heat pipes operate closer to their ideal isothermal behavior, and the electric vehicle battery pack maintains a more uniform temperature.
The pressure drop is also a critical design constraint in the electric vehicle battery pack. A high pressure drop increases pump power and reduces system efficiency. In the serpentine channel, the pressure drop can reach several thousand pascals, which is much higher than that of the parallel channel. The optimized series-parallel channel reduces the pressure drop by more than one third compared with the initial series-parallel design, and by more than two thirds compared with the serpentine design. This improvement is important because the coolant pump is part of the parasitic load of the electric vehicle battery pack thermal management system.
For temperature uniformity, the optimized channel keeps the temperature difference at 3.24 K. This value is lower than the initial series-parallel design and lower than the serpentine design under comparable conditions. A small temperature difference is beneficial because it reduces cell-to-cell imbalance in the electric vehicle battery pack. When cells operate at different temperatures, their internal resistance and aging rates differ, which can reduce the usable capacity and lifetime of the electric vehicle battery pack. Therefore, the optimized design supports both safety and durability.
The maximum temperature of the electric vehicle battery pack is also well controlled. At a 1C discharge rate, the optimized system maintains the maximum temperature near 303 K, which is within a favorable operating range. The heat pipe coupling prevents the cell core from becoming too hot, and the liquid cooling plate removes heat from the condenser sections. Because the coolant does not directly contact the cells, the risk of leakage-induced short circuits is reduced. This architecture is especially attractive for a high-capacity electric vehicle battery pack where safety and reliability are essential.
I can summarize the main thermal resistances in the electric vehicle battery pack as a series network:
$$ R_{total} = R_{cell} + R_{interface} + R_{hp} + R_{plate} + R_{convection} $$
where \(R_{cell}\) is the conductive resistance inside the cell, \(R_{interface}\) is the contact resistance between the cell and the heat pipe, \(R_{hp}\) is the effective heat pipe resistance, \(R_{plate}\) is the cold plate conduction resistance, and \(R_{convection}\) is the convective resistance between the plate and the coolant. The heat pipe strongly reduces \(R_{hp}\), while the series-parallel channel improves the coolant distribution and reduces \(R_{convection}\). The optimized design seeks a balance between these resistances rather than minimizing only one of them.
The coolant temperature rise along the channel also affects the electric vehicle battery pack. As the coolant absorbs heat, its temperature increases, and the local heat transfer driving force decreases. If the flow distribution is uneven, downstream regions receive warmer coolant and may experience higher temperatures. The series-parallel channel reduces this problem by splitting the flow into multiple branches, so each branch receives a smaller heat load and a more uniform coolant temperature. This is one reason why the optimized channel improves temperature uniformity in the electric vehicle battery pack.
The heat pipe layout is another important factor. In my design, the heat pipes are arranged in an alternating pattern along the cells. The evaporator sections are in contact with the large faces of the prismatic cells, and the condenser sections are inserted into the liquid cooling region. This arrangement increases the contact area and reduces the distance between the heat source and the heat sink. It also allows the heat pipes to bypass the poor thermal conductivity of the cell stack in the vertical direction. As a result, the electric vehicle battery pack can transfer heat from the interior to the bottom cold plate more effectively.
From a modeling perspective, the NTGK electrochemical model provides a reasonable balance between accuracy and computational cost for the electric vehicle battery pack. It captures the dependence of current transfer on depth of discharge and potential difference, and it supplies the volumetric heat source for the thermal model. The fluid model solves the laminar flow and heat transfer in the cooling channel. The heat pipe model uses a high effective thermal conductivity. The coupled solution therefore includes electrochemical heat generation, solid conduction, heat pipe transport, and coolant convection in one simulation framework.
The Taguchi method is useful because the full factorial design would require many more simulations. With four factors and mixed levels, a full experiment would be expensive for the electric vehicle battery pack. The L32 orthogonal array captures the main effects of the design factors with a manageable number of runs. The signal-to-noise ratio identifies which factors dominate each objective. The grey relational analysis then combines the objectives into a single grade. This hybrid method is well suited to thermal management design because temperature and pressure drop often conflict in an electric vehicle battery pack.
The optimized design parameters can be interpreted physically. The number of branch channels \(N=3\) provides enough flow paths to distribute the coolant without excessive branching. The branch width \(D_1=25\) mm reduces local velocity and pressure drop compared with narrower channels, while still providing sufficient heat transfer area. The spacing \(D_2=30\) mm aligns the branches with the heat pipe condenser positions and reduces maldistribution. The thickness \(D_3=3\) mm provides a good balance between channel cross-sectional area and plate thermal mass. Together, these parameters improve the overall thermal performance of the electric vehicle battery pack.
I also note that the coolant velocity should not be increased without limit. At 0.6 m/s, the maximum temperature of the electric vehicle battery pack is slightly higher than at 0.5 m/s in the series-parallel channel. This indicates that beyond a certain velocity, the coolant does not have enough residence time to absorb heat effectively from the channel walls. In addition, the pressure drop rises steeply with velocity. Therefore, 0.5 m/s is a practical operating point for the electric vehicle battery pack cooling system.
The inlet temperature should also be selected carefully. A lower inlet temperature reduces the maximum temperature, but it can increase the temperature difference if the cooling becomes too aggressive near the inlet. In my series-parallel channel study, 288 K gives the smallest temperature difference and a strong reduction in maximum temperature. This result shows that the optimal inlet temperature is not necessarily the lowest possible value. Instead, it should be chosen to balance heat removal and temperature uniformity in the electric vehicle battery pack.
Overall, my study shows that a heat pipe coupled liquid cooling structure can significantly improve the thermal performance of an electric vehicle battery pack. The heat pipes reduce the maximum temperature and temperature difference, while the liquid cooling channel removes heat from the condenser sections. The series-parallel channel combines low pressure drop with good flow distribution. The Taguchi and grey relational optimization further improves the design and provides a systematic method for parameter selection. The optimized electric vehicle battery pack cooling system achieves a maximum temperature of 303.22 K, a temperature difference of 3.24 K, and a pressure drop of 1956.16 Pa under the selected operating conditions.
In future work, I would extend the model to include more realistic cell properties, such as temperature-dependent internal resistance and thermal conductivity. I would also study higher discharge rates and fast-charging conditions, because these conditions place greater stress on the electric vehicle battery pack. Experimental testing of the optimized heat pipe and liquid cooling structure would be valuable for further validation. In addition, a detailed heat pipe model with separate evaporator, adiabatic, and condenser sections could provide a more accurate representation of transient behavior. These extensions would help move the proposed design closer to practical application in an electric vehicle battery pack.
The main conclusion of my work is that thermal management of an electric vehicle battery pack should be treated as a coupled design problem. The heat pipe, liquid cooling plate, and flow channel cannot be optimized independently. The heat pipe determines how heat reaches the cold plate, the channel determines how heat is removed by the coolant, and the operating parameters determine the balance between cooling capacity and energy consumption. By combining these elements in a single numerical framework and using multi-objective optimization, I obtain a cooling structure that improves temperature control, temperature uniformity, and hydraulic performance for the electric vehicle battery pack.