
In this article, I present a systematic numerical study of a phase-change-material composite fin structure that I designed with topology optimization for the thermal management of a vehicle traction battery. A vehicle traction battery often generates intense heat during high-rate discharging. If that heat is not removed or buffered, the cell temperature rises rapidly, capacity fades, and safety risks such as thermal runaway may appear. The work I report here combines two key ideas: the latent-heat buffering ability of a phase-change material and the high-conductivity pathway provided by topology-optimized aluminum fins. The aim is to reduce battery temperature, improve temperature uniformity, and suppress thermal-runaway propagation in a vehicle traction battery pack.
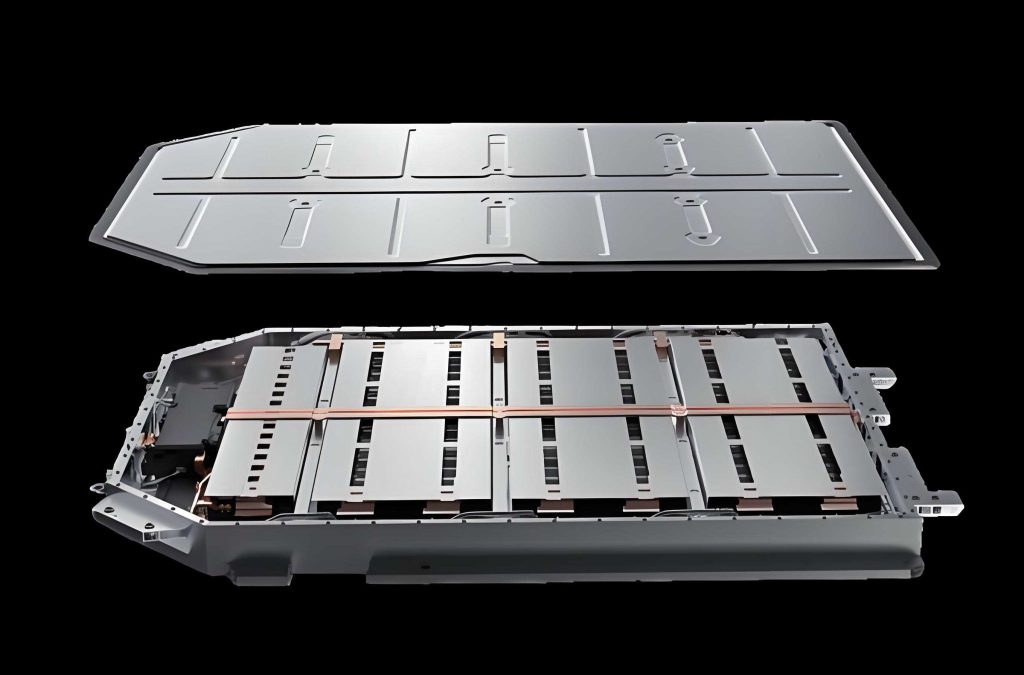
My research was motivated by the frequent statement that lithium-ion batteries have a preferred operating range of 293.15 K to 323.15 K. In addition, the temperature difference between cells in a module should generally be less than 5 K. For a vehicle traction battery, both the maximum temperature and the temperature gradient must be controlled. I therefore built models of a square lithium-ion cell and a cylindrical 18650 cell, calculated the heat-production rate under different discharge rates, and validated the model against measured temperature curves. After validation, I used density-based topology optimization to change the spatial distribution of aluminum fins inside the phase-change material. I then inserted the optimized fin geometry into a cell module and compared its performance with a conventional straight-fin geometry. I also studied the combined effect of air cooling. Finally, I numerically triggered thermal runaway in one cell and investigated how well the optimized fin blocks the propagation of heat to a neighboring healthy cell.
1. Thermal Limits and Heat-Transfer Mechanisms of a Vehicle Traction Battery
Temperature strongly affects the life and safety of a vehicle traction battery. The electrochemical reaction rate, internal resistance, and lithium plating tendency are all temperature dependent. When the battery is discharged at high C-rates, the irreversible Joule heat and the reversible entropic heat raise the core temperature. A conventional air-cooled module without phase-change material can suffer from large gradients because air heats up along the flow path. A liquid-cooled cold plate is effective, but it adds weight, pumping power, and leak risk. A phase-change material can absorb large amounts of heat at an almost constant temperature, but its low thermal conductivity often prevents the heat from penetrating into the whole volume. Therefore, I combined phase-change material with conductive fins. The role of the fin is to create a thermal bridge between the battery surface and the phase-change material. The conventional straight fin is simple but not necessarily optimal in a limited PCM domain. In my thesis, I sought a non-intuitive and more efficient fin layout by solving a topology-optimization problem rather than by a trial-and-error approach.
Table 1 summarizes the representative thermal-management options that I consider relevant for a vehicle traction battery.
| Strategy | Advantages | Limitations |
|---|---|---|
| Air cooling | Simple, light, easy to integrate | Lower heat-transfer coefficient, high fan power at large flow rate |
| Liquid cooling | High heat-transfer coefficient, compact cold plate | Leak risk, pump power, additional heat exchanger |
| Phase-change material cooling | Passive, high latent heat, uniform temperature | Low thermal conductivity, limited total heat storage |
| PCM-fin hybrid cooling | Combines latent heat and high conductivity | Fin shape and distribution need optimization |
| Topology-optimized PCM-fin | Non-intuitive fin paths can reduce thermal resistance | Requires numerical optimization and advanced manufacturing |
2. Cell Geometry and Heat-Generation Model
I used two cell geometries in the study. The first is a prismatic square lithium-ion cell with nominal dimensions 148 mm by 27 mm by 91 mm. The second is a cylindrical 18650 cell with a height of 65 mm and a radius of 18 mm. The heat-generation model was based on the general energy balance for a lithium-ion battery. I treated each cell as a homogeneous heat source in the simplified module-level calculation. Although real cells have layered internal structure, the module-level thermal management problem is dominated by the bulk heat-generation rate and by the heat-conduction resistance from the core to the outer surface.
The local energy equation in the solid domains is
$$ \rho c_p \frac{\partial T}{\partial t} = \nabla \cdot \left( k \nabla T \right) + q_v, $$
where \( \rho \) is density, \( c_p \) is specific heat capacity, \( k \) is thermal conductivity, \( T \) is temperature, and \( q_v \) is the volumetric heat source. In the PCM domain, the equation includes the latent-heat contribution through an equivalent heat-capacity formulation during the melting interval. I treated the melting temperature interval as 308.15 K to 310.15 K, corresponding to the phase-change range of the chosen PCM.
The heat source inside the battery was written with a simplified Bernardi expression:
$$ q_v = \frac{I}{V_c} \left[ \left( U_{ocv} – V_{cell} \right) + T \frac{d U_{ocv}}{dT} \right], $$
where \( I \) is discharge current, \( V_c \) is the cell volume, \( U_{ocv} \) is the open-circuit voltage, and \( V_{cell} \) is the operating voltage. The first term represents irreversible heat caused by internal resistance, while the second term represents reversible entropic heat. For high C-rates, the irreversible heat dominates. In the model validation stage, I fitted the cell resistance and entropy coefficient from hybrid pulse power characterization data. The fitting produced a ninth-order polynomial in time for each discharge rate. For the 3C discharge, the heat-production power can be represented by the following polynomial relation:
$$ q_{3C}(t) = 16.868 + 0.347 t – 3.34 \times 10^{-5} t^2 + 1.47 \times 10^{-8} t^3 + 3.65 \times 10^{-11} t^4 – 5.28 \times 10^{-14} t^5 + 4.42 \times 10^{-17} t^6 – 1.98 \times 10^{-20} t^7 + 3.66 \times 10^{-24} t^8 – 1.08 \times 10^{-27} t^9, $$
where \( t \) is the discharge time in seconds and \( q_{3C} \) is expressed in watts. I used this expression to set the heat generation in all battery simulations at 3C. The model predictions were compared with measured surface temperatures under 1C, 2C, and 3C discharge conditions. The maximum deviation between the simulated and measured cell temperatures remained below 5%. Therefore, the model was considered sufficiently accurate for the subsequent optimization and comparison.
| Property | Square cell | Cylindrical 18650 cell |
|---|---|---|
| Nominal capacity, Ah | 51 | 2.6 |
| Mass, g | 816.5 | 47.5 |
| Specific heat, J kg⁻¹ K⁻¹ | 1050.3 | 1200 |
| In-plane thermal conductivity, W m⁻¹ K⁻¹ | 14 | 0.2 |
| Through-plane thermal conductivity, W m⁻¹ K⁻¹ | 1.31 | 37.6 |
| Density, kg m⁻³ | 2245.3 | 2873.5 |
For the phase-change material, I chose n-eicosane because its melting temperature is close to the desirable operating temperature of a vehicle traction battery. The solid phase has a higher density and thermal conductivity than the liquid phase, while the latent heat is large enough to absorb the heat released during a discharge transient.
| Property | Solid PCM | Liquid PCM | Aluminum fin |
|---|---|---|---|
| Density, kg m⁻³ | 810 | 770 | 2700 |
| Specific heat, J kg⁻¹ K⁻¹ | 1900 | 2200 | 900 |
| Thermal conductivity, W m⁻¹ K⁻¹ | 0.39 | 0.157 | 238 |
| Latent heat, kJ kg⁻¹ | 241 | 241 | — |
| Phase-change temperature, K | 308.15 | 310.15 | — |
3. Topology-Optimization Framework
Topology optimization is a systematic method for distributing material within a design domain. I introduced a dimensionless design variable \( \gamma \) in the PCM-fin domain. The value \( \gamma = 0 \) represents pure phase-change material, while \( \gamma = 1 \) represents aluminum fin. Between these values, a penalized interpolation is used. I used a solid isotropic material with penalization, commonly abbreviated as SIMP, to obtain a nearly black-and-white design. The local thermal conductivity is expressed as
$$ k(\gamma) = k_{\mathrm{PCM}} + \gamma^p \left( k_{\mathrm{fin}} – k_{\mathrm{PCM}} \right), $$
with the penalty exponent \( p=3 \). I applied the same interpolation to density and volumetric heat capacity:
$$ \rho(\gamma) = \rho_{\mathrm{PCM}} + \gamma^p \left( \rho_{\mathrm{fin}} – \rho_{\mathrm{PCM}} \right), $$
$$ c_p(\gamma) = c_{p,\mathrm{PCM}} + \gamma^p \left( c_{p,\mathrm{fin}} – c_{p,\mathrm{PCM}} \right). $$
If no filter is used, topology optimization can produce mesh-dependent checkerboard patterns. I therefore used a Helmholtz filter to smooth the design field. The filtered field \( \gamma_f \) is obtained from the raw field \( \gamma_c \) by
$$ \gamma_f = \gamma_c + r_{\mathrm{min}}^2 \nabla^2 \gamma_f, $$
where \( r_{\mathrm{min}} \) controls the minimum feature size. After filtering, I used a hyperbolic-tangent projection to sharpen the interface and remove gray elements:
$$ \bar{\gamma} = \frac{ \tanh\left( \beta \left( \gamma_f – \gamma_\beta \right) \right) + \tanh\left( \beta \gamma_\beta \right) }{ \tanh\left( \beta \left( 1 – \gamma_\beta \right) \right) + \tanh\left( \beta \gamma_\beta \right) }, $$
where \( \beta \) is the projection slope and \( \gamma_\beta \) is the projection point. In my calculations, I used \( \beta = 8 \) and \( \gamma_\beta = 0.5 \). The projection significantly reduced intermediate densities and produced a final structure that can be more easily interpreted for manufacturing.
The topology-optimization problem was solved with two objective functions. The first objective was thermal compliance, defined as
$$ J_c = \int_\Omega q_v T \, d\Omega. $$
The second objective was average temperature in the design domain:
$$ J_T = \frac{1}{|\Omega|} \int_\Omega T \, d\Omega. $$
I minimized one of these objectives subject to a volume constraint on the fin material. The constraint was written as
$$ \int_\Omega \bar{\gamma} \, d\Omega \leq f_{\mathrm{vol}} |\Omega|, $$
where \( f_{\mathrm{vol}} \) is the allowable volume fraction of aluminum in the design domain. In the following discussion, I use \( \omega \) to denote the fin-to-PCM volume ratio \( V_{\mathrm{fin}} / V_{\mathrm{PCM}} \). For a given PCM volume, an increase in \( \omega \) means more aluminum and less available latent heat if the total domain volume remains unchanged. To maintain a constant PCM volume in my comparison, I expanded the physical dimensions of the PCM-fin region when the fin volume fraction was increased.
Figure 2 shows that the optimized structures are not simple straight fins; they contain multiple thermally conductive branches that resemble tree-shaped networks. Comparing the average-temperature objective with the thermal-compliance objective, I found that the average-temperature objective gave lower final cell temperatures for the same \( \omega \). This result was especially clear at lower fin volume ratios. The difference between objectives was reduced at higher volume ratios, because a larger fin volume can compensate for a less favorable arrangement. I therefore selected the average-temperature objective as the main optimization function throughout the study.
Table 4 lists the PCM volumes that I computed for the square-cell and cylindrical-cell modules based on the total heat released during a complete 3C discharge. Only the latent heat was considered in this first estimation; sensible heat was ignored for sizing purposes.
| Parameter | Square battery module | Cylindrical battery module |
|---|---|---|
| Discharge rate used for sizing | 3C | 3C |
| Discharge duration, s | 1200 | 1200 |
| PCM volume, cm³ | 23.144 | 13.715 |
| Design objective | Average temperature | Average temperature |
| Selected base volume ratio \( \omega \) | 0.4 | 0.4 |
4. Square Cell Results: Topology-Optimized Fins Versus Straight Fins
I optimized six different volume ratios for the square-cell configuration: \( \omega = 0.1, 0.2, 0.3, 0.4, 0.5, \text{ and } 0.6 \). I then transferred the optimized fins from the two-dimensional topology domain to a full battery model and compared the temperature evolution at 3C discharge. The straight-fin model was created with the same volume ratio as a baseline. In the straight-fin case, the aluminum ribs run from one side of the PCM domain to the other in a regular parallel pattern. In the topology-optimized case, the ribs are arranged in branched paths, and the central part of the domain is often occupied by disconnected islands of high-conductivity material.
At the end of the 3C discharge, the straight-fin module had a maximum temperature of about 44.3 °C at \( \omega = 0.1 \), while the topology-optimized fin module reached a much lower value of about 40.3 °C. At \( \omega = 0.6 \), the straight-fin module reached around 41.3 °C, while the topology-optimized module reached about 37.1 °C. Thus, topology optimization lowered the final cell temperature by roughly 8–10% compared with the straight-fin design. The improvement was not caused by adding more fin material; both designs had exactly the same amount of PCM and fin material. Instead, the optimized routing distributed the high-conductivity paths toward the regions where thermal gradients were largest.
I also observed that increasing the volume ratio \( \omega \) from 0.1 to 0.6 reduced the cell temperature monotonically. The reduction was significant from 0.1 to about 0.3, but it became almost saturated after \( \omega = 0.4 \). The terminal temperatures at \( \omega = 0.4, 0.5, \text{ and } 0.6 \) were close to each other. Taking both performance and manufacturing cost into account, I chose \( \omega = 0.4 \) as the recommended configuration for the square-cell module.
| Volume ratio \( \omega \) | Straight fin final temperature, °C | Topology-optimized final temperature, °C | Observed trend |
|---|---|---|---|
| 0.1 | 44.3 | 40.3 | Branched fins reduce the hot-spot temperature |
| 0.2 | Intermediate | Lower than straight fin | More branches appear in the corner regions |
| 0.3 | Intermediate | Further temperature reduction | Thermal diffusion becomes more uniform |
| 0.4 | Not calculated | 37.4 | Recommended compromise |
| 0.5 | Not calculated | 37.2 | Marginal improvement |
| 0.6 | 41.3 | 37.1 | Near saturation |
The temperature-evolution curve could be divided into three stages. At the start of discharge, the PCM has not reached its melting temperature, so the battery heats up quickly. Once the PCM begins to melt, a large amount of heat is absorbed as latent heat, and the rate of temperature rise decreases. In the third stage, a large portion of the PCM has already melted, the effective heat-absorption capacity decreases, and the cell temperature tends to rise more quickly again. The topology-optimized fin structure did not alter this physical behavior, but it shifted the phase-change process to a more uniform state by allowing heat to reach a larger fraction of the PCM volume.
5. Cylindrical Cell Results and Arrangement Effects
For the cylindrical cell, the PCM domain can be arranged in different patterns around the cells. I considered two common pack-level arrangements: a square lattice and a regular hexagonal lattice. The PCM volume was held constant, and the fin-to-PCM ratio was varied from 0.1 to 0.5 for both arrangements. The optimized fin topology again showed branched structures. At the smaller volume ratios, the fins were thin and concentrated near the cell surface; at the larger volume ratios, more and thicker branches reached deep into the PCM region, including the corners of the computational domain.
In the square-lattice arrangement, the straight-fin baseline reached a final temperature of about 45.4 °C at \( \omega = 0.1 \), while the topology-optimized structure reached about 42.7 °C. Increasing \( \omega \) to 0.5 reduced the final temperature of the optimized module to roughly 40 °C. In the hexagonal-lattice arrangement, the straight-fin baseline reached about 45.2 °C at \( \omega = 0.1 \), and the optimized structure reached a lower value of approximately 41.7 °C. At \( \omega = 0.5 \), the hexagonal optimized module reached about 39.5 °C. The hexagonal arrangement consistently provided slightly lower temperatures than the square arrangement. I attribute this improvement to the more compact packing and the better ability of the hexagonal domain to distribute heat around the entire circumference of the cylindrical cell.
The comparison between square and hexagonal arrangements is summarized in Table 6. I selected \( \omega = 0.4 \) as the recommended volume ratio for the cylindrical cell because the difference between 0.4 and 0.5 was small.
| Arrangement | Volume ratio \( \omega \) | Straight-fin cell temperature, °C | Topology-optimized cell temperature, °C | Temperature reduction |
|---|---|---|---|---|
| Square lattice | 0.1 | 45.4 | 42.7 | Approx. 6% |
| Square lattice | 0.5 | — | 40.0 | Lower than straight fin |
| Hexagonal lattice | 0.1 | 45.2 | 41.7 | Approx. 7.8% |
| Hexagonal lattice | 0.5 | — | 39.5 | Further reduction |
The conclusion from this section is that topology optimization of the PCM-fin structure provides a meaningful improvement for both square-cell and cylindrical-cell vehicle traction battery modules. The improvement is not simply due to adding fins; it arises from the optimized distribution of finite fin volume. In the square cell, the optimized fins resemble a network of main trunks and side branches. In the cylindrical cell, the branches surround the cell periphery and deliver heat toward the outer boundary of the PCM domain.
6. Three-Dimensional Reconstruction and Air-Cooling Integration
Although the topology-optimized fins performed well in the numerical experiments, their irregular tree-like boundaries are difficult to manufacture by conventional extrusion. In preparation for practical engineering, I reconstructed the optimized topologies into simpler shapes with straight edges and similar cross-sectional distributions. The reconstruction inevitably reduced the surface area and changed some conductive paths, but I found that the temperature difference between the original optimized fin and the reconstructed fin was small. I therefore used the reconstructed fins for all three-dimensional air-cooling simulations.
The computational model consisted of two prismatic cells, a central PCM-fin region, an upper air region, and optionally a lower air region depending on the cooling mode. The cells were surrounded by the PCM-fin structure, and a portion of the fin extended above the PCM surface into the air channel. Natural convection was modeled on selected external surfaces with a heat-transfer coefficient of 10 W m⁻² K⁻¹. Air was forced through the channel at a prescribed inlet velocity and a fixed inlet temperature of 25 °C. The heat sources in the cells were identical to those used in the two-dimensional cases.
Because natural convection and forced convection create different local flow patterns, I used an unstructured tetrahedral mesh. I first checked mesh independence. Table 7 lists the computed average battery temperature for six mesh sizes. The difference between 320,000 elements and 850,000 elements was less than 0.1%, so I selected 320,000 elements as the baseline mesh. This mesh was fine enough to resolve the boundary layer around the extended fins while remaining computationally efficient for the many cases studied.
| Number of elements | Average battery temperature, °C |
|---|---|
| 170,000 | 38.76 |
| 200,000 | 38.73 |
| 320,000 | 38.70 |
| 440,000 | 38.68 |
| 590,000 | 38.67 |
| 850,000 | 38.66 |
6.1 Fin Extension Height
In the first three-dimensional study, I kept the airflow velocity constant at 1.5 m/s and changed the fin extension height from 0 mm to 20 mm. A zero height means that the fins do not protrude into the air channel; heat can only be removed from the upper face of the composite structure. When the fin height was increased, the air-contact area increased, providing a more direct path for heat to flow from the PCM into the airflow. I observed a clear decrease in battery temperature as the height increased from 0 mm to 10 mm. Increasing the height above 10 mm still improved the heat transfer, but the additional reduction became smaller. At a very large height, the added surface area is located far from the heat source, and the boundary layer on the long fin surface becomes less effective.
Based on the simulation results, I selected a fin extension height of 10 mm as the recommended value for the vehicle traction battery module. Table 8 summarizes the effect of fin height on the final average cell temperature.
| Fin extension height, mm | Battery temperature change | Observation |
|---|---|---|
| 0 | Baseline | Small air-contact area, high cell temperature |
| 5 | Reduction of about 0.6 K | Extended fins begin to contribute |
| 10 | Reduction of about 2 K | Good compromise between heat transfer and additional material |
| 15 | Further reduction, but much smaller | Thermal boundary layer limits benefit |
| 20 | Almost saturated | Material cost and pressure drop increase |
6.2 Air-Cooling Configurations
I then studied three air-cooling schemes with the reconstructed fins: single-side air cooling, double-side air cooling with the same flow direction, and double-side air cooling with opposite flow directions. The fin extension height was fixed at 10 mm. For each scheme, I varied the air velocity from 1.0 m/s to 3.0 m/s. The main thermal-management metrics were the average battery temperature and the temperature difference between the two cells at the end of the 3C discharge.
In the single-side air-cooling scheme, air enters from one side, passes over the exposed fin tips, and leaves from the other side. The battery near the air inlet is cooled more effectively because the incoming air has a lower temperature. The downstream air is warmer, so the corresponding cell has a higher temperature. When the airflow velocity is increased, the average cell temperature decreases, but the temperature difference between the inlet side and the outlet side tends to increase because more heat is absorbed along the first part of the channel. At 1.0 m/s, the final cell temperature was about 38.6 °C, while at 3.0 m/s it was about 37.8 °C. Increasing the velocity from 2.5 m/s to 3.0 m/s produced only a very small temperature drop, indicating that 2.5 m/s is near the practical upper limit.
The double-side same-direction air-cooling scheme supplies air to both sides of the battery module in the same streamwise direction. Because both surfaces are cooled, the overall heat-transfer area is doubled. The cell temperature at 1.0 m/s was about 37.7 °C, and at 3.0 m/s it was about 36.9 °C. Compared with single-side cooling, double-side same-direction cooling reduced the average cell temperature by roughly 1 K at the same velocity. However, because both cooling ducts have the same flow direction, the temperature gradient across the pack remains present. The cell on the common inlet side is coldest, while the cell on the common outlet side is warmest.
The double-side opposite-flow cooling scheme uses two air ducts with opposing flow directions. One duct feeds air from the left, and the other duct feeds air from the right. The overall heat-transfer area is the same as that of the double-side same-direction scheme, so the average cell temperature is very similar. At 1.0 m/s, the cell temperature was about 37.7 °C, and at 3.0 m/s it was about 36.9 °C. The key advantage is temperature uniformity. Because the two streams flow in opposite directions, the temperature gradient in one duct tends to cancel the gradient in the other duct. As a result, the temperature difference between the two cells remained almost constant and was reduced by nearly 90% compared with the single-side and same-direction double-side schemes. Table 9 summarizes the three cooling arrangements.
| Cooling scheme | Battery temperature at 1 m/s, °C | Battery temperature at 3 m/s, °C | Cell-to-cell temperature difference |
|---|---|---|---|
| Single-side | 38.6 | 37.8 | Moderate and increases with air velocity |
| Double-side same direction | 37.7 | 36.9 | Slightly larger than single-side |
| Double-side opposite direction | 37.7 | 36.9 | Very small, below about 0.01 °C |
The results show that the average cell temperature is controlled mainly by the cooling surface area and the airflow rate, while the temperature uniformity is controlled by the direction of the airflow. For a vehicle traction battery, both the maximum temperature and the maximum temperature difference matter. The double-side opposite-flow air cooling scheme therefore became the recommended final configuration. It combines the thermal mass of the PCM with the high-conductivity topology-optimized fins and an actively balanced airflow. This integrated solution can keep the battery temperature low and uniform during sustained high-rate discharge.
7. Thermal-Runaway Propagation Suppression
Thermal runaway is one of the most severe safety concerns for a lithium-ion vehicle traction battery. If one cell is heated to a critical temperature, exothermic side reactions inside the cell release a very large amount of heat in a short time. The neighboring healthy cells can then be heated above their own runaway threshold, causing a chain reaction. The PCM and fins around the cells can either accelerate or impede this process. A continuous metal fin is a good heat conductor, but it also provides a direct path for heat to propagate from the thermal-runaway cell to the adjacent normal cell. I therefore tested three configurations: a connected straight fin, a disconnected straight fin, and a topology-optimized fin. The volume ratio was fixed at 0.4.
I triggered thermal runaway in the left cell by applying a very high heat-generation power for 10 seconds after the first 60 seconds of normal 3C discharge. The right cell was assumed to remain electrically healthy and was simulated with the normal 3C heat source. The runaway trigger temperature was set to 150 °C. The runaway heat-generation power was 136.3 MW m⁻³ for the square cell and 129.3 MW m⁻³ for the cylindrical cell. The total simulation time was 500 seconds.
For the square-cell module with a connected straight fin, the normal cell temperature increased quickly and reached the critical runaway threshold around the end of the simulation. The fin acted as a heat channel that transferred the runaway heat directly from the abused cell to the healthy cell. For the disconnected straight fin, the physical separation interrupted the direct conduction path, but the heat still moved through the surrounding PCM and along the remaining fin segments. At the final simulation time, the normal cell temperature was about 92.6 °C. For the topology-optimized fin, the normal cell temperature was only about 67.2 °C. The optimized fin created multiple branched paths that delivered heat away from the cell surface toward the PCM, but the central disconnected islands also acted as thermal barriers to slow down the direct propagation from one cell to another.
| Fin configuration | Normal cell final temperature, °C | Propagation suppression effect |
|---|---|---|
| Connected straight fin | Near 150 °C or above | Weak; heat channel accelerates propagation |
| Disconnected straight fin | 92.6 | Moderate |
| Topology-optimized fin | 67.2 | Strong; delayed and reduced temperature rise |
The cylindrical-cell simulations showed the same trend. At the end of the 500 s simulation, the normal cell in the straight-fin module reached about 88.9 °C, while the normal cell in the topology-optimized module reached about 83.2 °C. The abused-cell temperature in the topology-optimized module was slightly higher because less heat was transferred to the normal cell. This behavior confirms that the topology-optimized fin was more effective at confining the thermal-runaway heat within the abused cell region. The optimized structure allowed heat to spread into the adjacent PCM, but limited the fast conductive bridge between the two cells.
| Fin configuration | Abused cell final temperature, °C | Normal cell final temperature, °C |
|---|---|---|
| Straight fin | 171.3 | 88.9 |
| Topology-optimized fin | 184.3 | 83.2 |
The thermal-runaway study demonstrates that topology optimization is not only useful for normal discharge cooling. It can also be used to design fins with deliberate discontinuities and branching paths that reduce the thermal coupling between cells. For a vehicle traction battery, this is an important feature because it provides additional response time before a local thermal event grows into a full-pack event.
8. Design Recommendations for a Vehicle Traction Battery
Based on my numerical study, I can propose the following design recommendations for a vehicle traction battery using topology-optimized PCM-fin structures:
| Design parameter | Square-cell module | Cylindrical-cell module |
|---|---|---|
| PCM material | n-eicosane | n-eicosane |
| Fin material | Aluminum | Aluminum |
| PCM volume | 23.144 cm³ | 13.715 cm³ |
| Fin-to-PCM volume ratio | 0.4 | 0.4 |
| Optimization objective | Minimum average temperature | Minimum average temperature |
| Fin extension height | 10 mm | 10 mm |
| Recommended air-cooling scheme | Double-side opposite flow | Double-side opposite flow |
| Practical air velocity range | 2.0–2.5 m/s | 2.0–2.5 m/s |
The topology-optimized fin layout is more complex than a conventional straight-fin layout. In an actual vehicle traction battery pack, it could be manufactured by metal additive manufacturing, stamping, or investment casting depending on the cell format and production volume. The numerical results indicate that the extra manufacturing cost could be justified by the improved temperature uniformity, lower peak temperature, and enhanced thermal-runaway resistance.
I also found that the topology-optimized fin geometry should be interpreted together with the PCM volume and the physical shape of the cooling domain. The optimized layout for a square cell is not transferable directly to a cylindrical cell because the heat-transfer boundary conditions and geometric constraints are different. Therefore, designers of a vehicle traction battery should solve the topology-optimization problem separately for each specific module layout.
9. Conclusions
In this article, I have studied the topology optimization of phase-change cooling structures for a vehicle traction battery. The main conclusions are the following.
First, I verified a lumped heat-generation model for square and cylindrical lithium-ion cells. The simulation results agreed with the measured temperature curves within 5% uncertainty for 1C, 2C, and 3C discharges. This model provided a reliable basis for later optimization work. Second, I demonstrated that topology-optimized fins outperform straight fins for the same volume of material. In the square-cell module, the optimized fin lowered the final battery temperature by about 8% to 10% compared with the straight fin, depending on the volume ratio. In the cylindrical-cell module, the hexagonal arrangement produced slightly lower temperatures than the square arrangement. The optimized fins generated a branched heat-flow pattern that better used the latent heat of the phase-change material.
Third, the integrated air-cooling study showed that the average battery temperature decreases significantly when the fin extension height is increased up to 10 mm. Beyond 10 mm, the additional benefit is small. Among the three air-cooling schemes, double-side opposite-flow air cooling provided the best combination of low average temperature and low cell-to-cell temperature difference. At an air velocity of 2.5 m/s, the double-side opposite-flow scheme reduced the cell temperature by about 1 K compared with single-side cooling and nearly eliminated the temperature difference between cells.
Fourth, the thermal-runaway simulations confirmed that the topology-optimized fin improves the safety of a vehicle traction battery. In the square-cell module, the normal cell temperature remained at 67.2 °C when protected by the optimized fin, while the disconnected straight fin produced a value of 92.6 °C. In the cylindrical-cell module, the optimized fin kept the normal cell at 83.2 °C, whereas the straight fin led to 88.9 °C. The optimized design suppresses the fast conductive heat bridge between cells and gives the battery cooling system extra time to respond.
Overall, the combination of topology-optimized fins and phase-change material is a promising solution for the thermal management of a vehicle traction battery. It offers a passive heat-buffering mechanism, an active or semi-passive convective removal path, and a non-intuitive fin architecture that reduces temperature gradients. Future work should focus on experimental validation of the reconstructed fins, study of the long-term cycling behavior, and extension of the topology-optimization framework to include natural convection and pack-level manifolds. The same methodology could be applied to other cell formats and cooling conditions in a large vehicle traction battery pack.
I believe that topology optimization will become an increasingly useful design tool in battery thermal management. By integrating source terms, heat-transfer constraints, manufacturability filters, and safety requirements into one optimization process, engineers can design fins that are not simply straight or shaped by intuition. The optimized fins shown in this study are one example of how a vehicle traction battery can be made cooler, more uniform, and safer without increasing the amount of fin material. This idea is central to the continuing development of next-generation electric vehicles.