
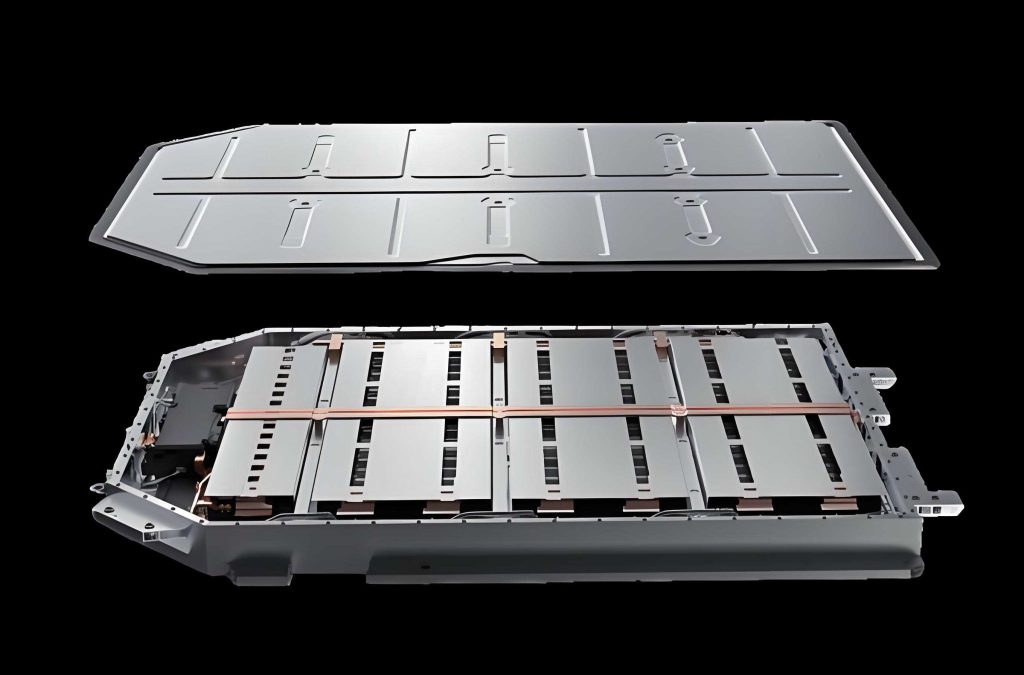
This paper presents a comprehensive study on the charging and protection circuits for a lithium traction battery pack, specifically designed for medium and small electric power tools and electric bicycles. The research is motivated by the growing market demand for electric traction vehicles and the need to replace lead-acid batteries with high-performance lithium iron phosphate (LiFePO₄) traction battery systems. My work focuses on the system architecture, hardware design, control strategies, and battery management functionalities, aiming to improve the safety, reliability, and efficiency of traction battery systems.
The main parameters of the traction battery pack used in this research are listed below:
| Parameter | Value |
|---|---|
| Nominal voltage | 48 V |
| Number of series cells | 15 |
| Rated capacity | 20 Ah |
| Maximum charge current | 20 A (2C pulse) |
| Maximum discharge current | 20 A |
| Operating temperature | 0–50 °C |
My design includes two main sections: the charging power stage consisting of an active power factor correction (PFC) circuit followed by a DC/DC converter, and the protection/control stage based on an embedded microcontroller. The protection system supervises voltage, current, temperature, internal resistance, and state-of-charge (SOC) of the traction battery pack. Communication is implemented using the SMBus protocol, which allows the traction battery management system to interface with external devices, such as a host computer or an intelligent charger.
1. Introduction and Research Background
With the rapid increase in the number of combustion vehicles, the greenhouse effect and air pollution caused by exhaust gas have become serious. Statistics show that motor vehicles emit more than 200 million tons of harmful gases every year, which accounts for over 60% of total atmospheric pollution. Moreover, the shortage of petroleum resources is a global challenge. Therefore, many countries have invested substantial resources in developing electric traction vehicles. As the energy source of an electric traction vehicle, the traction battery must provide high power and long cycle life. However, traditional lead-acid batteries are heavy, bulky, have low specific energy, and their lead content causes severe environmental pollution. In contrast, lithium-ion batteries, especially lithium iron phosphate based traction batteries, have become promising candidates due to their high safety, long cycle life, high discharge current capability, and excellent thermal stability.
Despite these advantages, the application of traction battery systems still faces technical obstacles, particularly in charging control and circuit protection. The characteristics of a lithium traction battery are different from those of conventional batteries, and therefore the charging and protection circuits must be carefully tailored. My research aims to design a high-performance, cost-effective charge and protection circuit for a 48 V, 20 Ah LiFePO₄ traction battery pack. The system must manage the complete charging process while providing multi-level protection to guarantee safe operation under all conditions.
2. Introduction to the Traction Battery
The traction battery is an energy storage device capable of delivering high power for a relatively long time. In my design, the core is a LiFePO₄ lithium traction battery. LiFePO₄ has an olivine crystal structure and exhibits a nominal voltage of 3.2 V per cell, with a charge cut-off voltage of 3.6 V and a discharge cut-off voltage of 2.1 V. It shows a flat voltage plateau that simplifies SOC estimation. Compared with other cathode materials, LiFePO₄ offers superior safety, long cycle life, high thermal stability, and low cost. The following table compares several common cathode materials for lithium traction batteries:
| Cathode material | Theoretical capacity (mAh/g) | Actual capacity (mAh/g) | Voltage range (V) | Safety | Cost |
|---|---|---|---|---|---|
| LiCoO₂ | 274 | 140–150 | 3.7 | Medium | High |
| LiNiO₂ | 274 | 190–210 | 2.5–4.2 | Poor | Medium |
| LiMn₂O₄ | 148 | 90–120 | 3.0–4.0 | Good | Low |
| LiMnO₂ | 286 | 200 | 3–4.5 | Good | Low |
| LiFePO₄ | 170 | 110–165 | 3.2 | Very good | Low |
My measurements and reported experimental studies show that LiFePO₄ can be discharged continuously at high rates, reaching 10C under standard discharge conditions and even 20C for short pulses. The cycle life is excellent, with more than 500 cycles retaining over 95% of initial capacity. Such traits make it the best candidate for medium-power traction battery applications.
3. System Architecture of the Traction Battery Management System
The proposed traction battery management system (BMS) is divided into two functional blocks: the power path and the control/communication unit. The power path includes an AC-DC converter with PFC and a DC-DC converter, which supplies the correct charging voltage and current. The control unit contains a microcontroller (C8051F020) that monitors the traction battery state and executes protection algorithms. The overall structure can be described as follows:
\[
\text{AC mains} \rightarrow \text{EMI filter} \rightarrow \text{Rectifier} \rightarrow \text{Boost PFC} \rightarrow \text{DC bus (380 V)} \rightarrow \text{DC/DC forward converter} \rightarrow \text{Traction battery}
\]
The BMS control electronics measure cell voltages, pack current, temperature, and internal resistance. It also computes SOC, handles communication with peripheral devices via SMBus, and drives protection MOSFETs to isolate the traction battery in fault conditions.
4. Design of the Charging Circuit
4.1 Selection of the Switching Power Supply Topology
The required maximum output power is \(P_{out}=55V \times 10A = 550W\). For such a power level, a single-switch flyback topology is not suitable. Therefore I decided to use a dual-switch forward converter, also called a parallel single-ended forward converter. This topology provides good efficiency, low component stress, and simple gate drive compared to full-bridge circuits. Since the input stage is connected to the 220 V AC mains, the rectified DC voltage varies with line condition. To shape the input current and meet the IEC harmonics limits, an active PFC boost converter is placed between the rectifier and the DC/DC stage.
For the DC/DC stage, I selected the interleaved double-ended forward converter because it offers lower output ripple and better transformer utilisation. The switching frequency for the DC/DC converter is set to 200 kHz. The maximum duty ratio is selected as
\[
D_{max}=0.44
\]
which ensures sufficient time for core reset.
4.2 PFC Circuit Design
I adopted the average current mode control for the PFC stage because it gives low total harmonic distortion, insensitivity to noise, and fixed frequency operation. The PFC stage is based on a boost converter operating in continuous conduction mode (CCM). The main parameters of the PFC converter are computed as follows:
Input voltage maximum value:
\[
V_{DC,MAX}=\sqrt{2}V_{AC,MAX}\approx 375\,V
\]
The maximum input current is calculated assuming the DC/DC efficiency \(\eta=0.85\):
\[
I_{DC,MAX}=\frac{P_{OUT,MAX}}{\eta V_{AC,MIN}}=\frac{550}{0.85\times 220\sqrt{2}}\approx 7.04\,A
\]
Boost inductance calculation:
\[
L = \frac{V_{AC,MIN} \cdot D_{MAX}}{\eta \cdot K \cdot P_{OUT,MAX} \cdot f_{PFC}}
\]
where \(K=0.2\) is the ripple ratio, \(D_{MAX}=0.52\), and \(f_{PFC}=100\,kHz\). After substitution:
\[
L \approx 2.44\,mH
\]
The PFC output voltage is regulated at 380 V. The output capacitor is chosen to meet the hold-up time requirement. With a hold-up time of \(t_{HU}=60\,ms\):
\[
C_{out} = \frac{2 P_{out} t_{HU}}{(V_C^2 – V_{min}^2)}
\]
where \(V_C=380\,V\) and \(V_{min}\) is the minimal dc voltage during hold-up, giving a capacitance around 580 μF. I selected a standard 600 μF / 400 V electrolytic capacitor, in parallel with a 0.22 μF film capacitor for high-frequency decoupling.
I chose the power MOSFET 2SK1249 for the PFC switch. This device has a drain-source voltage rating of 500 V and a continuous drain current of 15 A. The boost diode must have fast reverse recovery because the converter operates in CCM. The selected diode is MUR860, which offers 600 V reverse voltage and 8 A forward current.
4.3 High-Frequency Transformer Design
The two forward transformers distribute the output power equally. Therefore each transformer processes 275 W. With a switching frequency of 200 kHz, a core type EI40 with effective area \(S=148\,mm^2\) is selected. The magnetic core material is H7C4. The maximum flux density is set to \(B_m=0.2\,T\) to keep the core losses moderate.
The transformer design is summarised below:
Primary voltage reflected to secondary:
\[
U_{s,min} = \frac{(U_{o,max}+U_L+U_F)T}{t_{on,max}}
\]
where \(U_{o,max}=55\,V\), \(U_L=0.2\,V\), \(U_F=0.5\,V\), \(T=5\,\mu s\), and \(t_{on,max}=2.2\,\mu s\). Thus:
\[
U_{s,min}=126.6\,V
\]
The turns ratio between secondary and primary is:
\[
n=N_s/N_p = \frac{U_{s,min}}{V_{dc,min}} = \frac{126.6}{200}=0.633
\]
Secondary turns:
\[
N_s = \frac{U_{s,min}\cdot t_{on,max}}{B_m\cdot S}\times 10^{4}
\]
with \(S\) expressed in cm². This yields \(N_s=9.4\), so I chose \(N_s=10\). Primary turns become:
\[
N_p= \frac{N_s}{n} = 15.8 \approx 16
\]
Both windings are wound with multiple strands of AWG #22 (primary) and #24 (secondary). The wire selection accounts for the skin effect at 200 kHz. The output filter inductor is calculated for a current ripple of 1 A:
\[
L_o = \frac{(U_{s,min}-U_o-U_F)}{\Delta I_L} \cdot t_{on,max}
\]
which yields 71 μH. The inductor is wound on a core with an air gap of 0.8 mm.
4.4 Control of the DC/DC Stage
The DC/DC converter uses current-mode control with an inner current loop and an outer voltage loop. The UC28517 integrated circuit provides both the PFC and PWM signals. A key feature of UC28517 is its ability to generate an edge-triggered PFC signal and a fall-edge-triggered PWM signal. This reduces the ripple current in the intermediate bus capacitor. The feedback network of the PFC and DC/DC loops was designed according to the standard frequency compensation procedure. The voltage error amplifier for PFC has a crossover frequency below the second harmonic of the line frequency. I designed a Type-2 compensator for the PFC voltage loop, while the current loop bandwidth was set around 10 kHz to ensure fast tracking.
For the DC/DC stage, the battery charge algorithm uses constant current (CC) and constant voltage (CV) modes. The switching between CC and CV is implemented by two transconductance amplifiers with a diode-OR output, as shown conceptually below:
\[
I_{ref} \, (from \, MCU) \xrightarrow{\text{CC amplifier}} \text{Low output} \xrightarrow{\text{diode}} \text{PWM comp}
\]
\[
V_{ref} \, (from \, MCU) \xrightarrow{\text{CV amplifier}} \text{Low output} \xrightarrow{\text{diode}} \text{PWM comp}
\]
The lower of the two amplifier outputs is selected to control the PWM duty cycle. When the traction battery is deeply discharged, the constant-current loop keeps the charging current at a predetermined level (e.g., 0.5C = 10 A). When the traction battery voltage reaches the CV set point (52.5 V), the voltage loop takes over, gradually reducing the current. A complete charge is detected when the current drops below 200 mA.
4.5 EMC Design and Simulation
EMC design is essential for a switching power supply that operates at high frequency. I used several techniques to suppress electromagnetic interference. A power line filter was placed at the AC input to attenuate both common-mode and differential mode noise. The boost inductor and transformers were carefully shielded and grounded. Snubber networks (RC) were connected across the main MOSFETs to limit the voltage spikes caused by transformer leakage inductance. The PCB layout was designed with minimal loop areas, separated power ground and signal ground, and proper decoupling capacitors.
Simulations were performed using PSpice. The PFC stage showed a sinusoidal input current and stable 380 V output voltage after a transient of about 50 ms. The DC/DC converter output produced the required 54 V at 10 A with a ripple voltage below 50 mV. These results confirmed the correct functionality of the charging circuit for the traction battery.
5. Protection and Control Circuit Design
5.1 Control Chip Selection
The protection and control unit is based on the C8051F020 microcontroller, which is a fully integrated mixed-signal SoC. It includes a 12-bit ADC with multiple inputs, two 12-bit DACs, dual comparators, a SMBus/I²C controller, UART, SPI, 64 digital I/O pins, and in-system debug functions. Its instruction set is compatible with MCS-51, but the execution speed is up to 25 MIPS at 25 MHz. The on-chip resources reduce the external component count, improving reliability and resulting in a compact design for the traction battery management system.
5.2 Voltage Detection and Protection
I designed a voltage divider network that scales the traction battery terminal voltage down to the ADC input range. The detection circuit includes a filter capacitor to suppress high-frequency noise. The voltage thresholds for the traction battery management are listed in the following table:
| Protection type | Threshold value | Delay time |
|---|---|---|
| Overcharge protection | 54.5 V ± 0.1 V | 2 s |
| Overcharge release | 53.5 V ± 0.1 V | – |
| Overdischarge protection | 31.5 V ± 0.3 V | 500 ms |
| Overdischarge release | 37.5 V | – |
| Short circuit protection | 5 V (terminal voltage drop) | 10 μs |
| CC/CV mode switching | 52.5 V | 1 s |
Each threshold is enforced by the microcontroller controlling the charge/discharge MOSFETs. Protection delays are implemented to avoid false triggering due to noise or transient spikes. For example, a sustained voltage above 54.5 V for more than 2 seconds will open the charging MOSFET and shut off the charger.
5.3 Current Detection and Overcurrent Protection
Current detection is achieved using a magnetic-balanced Hall effect current sensor. This type of sensor provides excellent electrical isolation, high accuracy, and fast response. Its working principle is based on the Hall effect: the primary current creates a magnetic field which is balanced by a secondary compensation current. The secondary current is a precise replica of the primary current, and the output voltage across an accurate resistor is proportional to the measured current. The signs of the voltage determine the charging or discharging direction.
For overcurrent protection:
- Charge overcurrent threshold: 20 A (with a 50 ms delay)
- Discharge overcurrent threshold: 20 A (with a 50 ms delay)
- Full-charge detection current: < 200 mA (sustained for 3 s)
A fuse is placed in the battery circuit as a final back-up in case the electronic protection fails.
5.4 Internal Resistance and Temperature Detection
Internal resistance measurement is important for traction battery diagnostics. I compared DC and AC methods. The AC method uses a 1 kHz, 50 mA excitation signal, measures the voltage response, and calculates the impedance. This is fast and does not damage the electrode structure. However, its accuracy is affected by ripple current. For the present design, I calculated the internal resistance from the measured voltage difference under dynamic current pulses, using the relation:
\[
R_{internal} = \frac{\Delta V}{\Delta I}
\]
where \(\Delta V\) is the instantaneous voltage change and \(\Delta I\) is the instantaneous current change.
Temperature detection is done with a low-cost silicon temperature sensor AD590, which outputs a current proportional to absolute temperature. The temperature signal is converted to a voltage and sampled by the ADC. If the traction battery temperature exceeds safe limits, the microcontroller disconnects the charging or discharging path.
5.5 Individual Cell Voltage Measurement
For a 15-cell series traction battery pack, cell voltage monitoring is critical for balancing and protection. I implemented a voltage-controlled current source circuit that converts the cell voltage into a proportional current, thereby enabling accurate measurement without common-mode voltage issues. The circuit uses a carefully matched resistor bridge and an operational amplifier. The principle is that if \(R_3=R_4\), then the current \(I\) is approximately \(V_{cell}/R_3\). The output voltage is \(V_{out}=I\cdot R_L\). This configuration ensures high precision and noise immunity over a long transmission line.
6. Software Design
6.1 State of Charge Estimation
Estimating the SOC of a traction battery is one of the most difficult tasks due to the nonlinear electrochemical processes inside the battery. I evaluated several estimation methods, including the open-circuit voltage method, the internal resistance method, artificial neural networks, and ampere-hour counting. The open-circuit method is not suitable for online estimation. Internal resistance gives a non-monotonic curve with SOC, which leads to ambiguity. Neural networks require huge training data and computational resources, making them inappropriate for a low-cost microcontroller. Therefore I selected the ampere-hour (coulomb counting) method with compensation factors.
The basic ampere-hour formula is:
\[
Q_{use} = \int_{0}^{t} i(\tau) d\tau
\]
or, in discrete form:
\[
Q_{use} = \sum_{k=1}^{n} i_k \Delta t
\]
Then:
\[
SOC = \frac{Q_{res}}{Q_E} = \frac{Q_E – Q_{use}}{Q_E}
\]
where \(Q_E\) is the rated capacity at standard conditions, and \(Q_{res}\) is the remaining capacity.
To improve accuracy, I added several compensation terms. First, a compensation current \(g_i\) accounts for battery self-discharge and internal energy loss:
\[
g_i = \eta + \mu (T – T_0)
\]
where \(U\) is the terminal voltage, \(T\) is the temperature, and \(T_0=20\,^\circ C\). The effective current during charge is \(i_f = i – g_i\) and during discharge \(i_f = i + g_i\).
Temperature compensation formula:
\[
SOC_T = SOC \cdot [1 – \nu (T – T_0)]
\]
where \(\nu\) is a temperature coefficient obtained experimentally.
Aging compensation uses a factor \(A_F\):
\[
A_F = \frac{Ah_{ref} – Ah_{pre}}{Ah_{ref}}
\]
where \(Ah_{ref}\) is the maximum capacity over the lifespan and \(Ah_{pre}\) is the current cycle capacity.
Discharge rate compensation is based on Peukert’s law:
\[
I^n t = K
\]
where \(n\) and \(K\) are constants determined from two discharge experiments. After evaluating \(n\) and \(K\), the effective capacity at any given discharge rate is:
\[
Q_E(I) = K I^{1-n}
\]
Integrating all the compensations, my final SOC estimation formula becomes:
\[
SOC = \left(1 – \frac{\sum_{j} \frac{I_j \Delta t_j}{K I_j^{1-n}}}{Q_E}\right) \times [1 – \nu(T-T_0)] \times (1 – A_F)
\]
Here, the discharge current profile is divided into small intervals \(j\) where the current is assumed to be constant. This calculation runs in real time on the C8051F020 and updates SOC every second. To avoid accumulated errors, I implemented a correction algorithm: when the traction battery is left open-circuit for at least 30 minutes, the internal chemical state approaches equilibrium. I then use the open-circuit voltage method to estimate the SOC and compare it to the ampere-hour result. If the difference exceeds 5%, the SOC display is corrected to the open-circuit value and the coulomb counter is reset accordingly.
6.2 SMBus Communication
The protection unit communicates with external host devices, such as a PC or intelligent charger, via the SMBus protocol. SMBus uses two lines: SCL (clock) and SDA (data), both with open-drain or open-collector drivers and pull-up resistors. The bus operates at 100 kbit/s. The data transmission starts with a START condition (SDA falls while SCL is high), followed by a 7-bit slave address, a R/W bit, and the acknowledgment signal. After each data byte, the receiver acknowledges the data. The clock is stretched if a device needs more time; a timeout of 25 ms resets all stuck devices. SMBus allows only one master at a time, but multiple devices can reside on the bus. In my system, the C8051F020 acts as the master and may communicate with a graphic display, an external charging station, or a diagnostic computer. Since SMBus is electrically compatible with I²C, I can easily convert the bus to USB/RS-232 for communication with a PC.
7. Overall System Integration and Testing
The complete hardware was laid out on a printed circuit board with careful attention to power loops and signal integrity. The charging circuit includes a startup soft-start mechanism, inrush current limiting, and thermal protection. The protection circuit uses redundant thresholds: the microcontroller triggers the analog switches independent of software. Moreover, a hardware analog latch circuit provides fast short-circuit protection without waiting for the microcontroller. Long-term charging tests on the 48V/20Ah traction battery pack demonstrated that the CC/CV method charges the battery to full in about 2–3 hours, and the charging process ends automatically when the current falls below the full-charge threshold. The measured current waveform at the AC input is nearly sinusoidal, confirming that the PFC stage achieves a power factor of over 0.98.
8. Conclusion and Future Work
In this paper I have presented the complete design of charge and protection circuits for a lithium iron phosphate traction battery. The charger integrates active PFC with a dual-switch forward converter, and the system controller provides comprehensive protection, precise SOC estimation, and SMBus communication. The system design successfully meets the technical requirements for safe and reliable operation of a 48 V traction battery module.
Future improvements include the optimisation of compensation coefficients through more extensive experimental data, thermal management of the charger enclosure, the adoption of soft-switching to reduce switching losses in DC/DC converters, and the implementation of intelligent passive/active cell balancing for the traction battery pack. Moreover, I plan to extend the communication interface to a CAN bus for automotive-grade traction battery applications. With these improvements, the traction battery system will become more efficient, more durable, and safer for widespread use in electric traction vehicles.