
In pursuit of advancing electric vehicle technology, this thesis investigates the remaining capacity prediction of a traction battery pack, specifically focusing on lithium iron phosphate (LiFePO₄) batteries. The research begins with an analysis of the operational characteristics and challenges associated with traction battery packs. Through extensive discharge experiments, I collected voltage and current data under various temperatures and discharge rates. Based on these data, I developed predictive models using Backpropagation (BP) neural networks. To address the limitations of the standard BP algorithm, including its tendency to converge to local minima and slow training speed, I introduced a hybrid approach combining Genetic Algorithms (GA) with BP networks, known as the GA-BP algorithm. This method optimizes both the network structure parameters, such as initial weights and thresholds, and the training parameters, including learning rate, training epochs, and performance goals. The experimental results demonstrate that the optimized GA-BP model not only enhances prediction accuracy but also significantly improves training efficiency. Ultimately, I established a complete testing system to validate the model, confirming that the prediction errors fall within the acceptable range for engineering applications.
1 Introduction
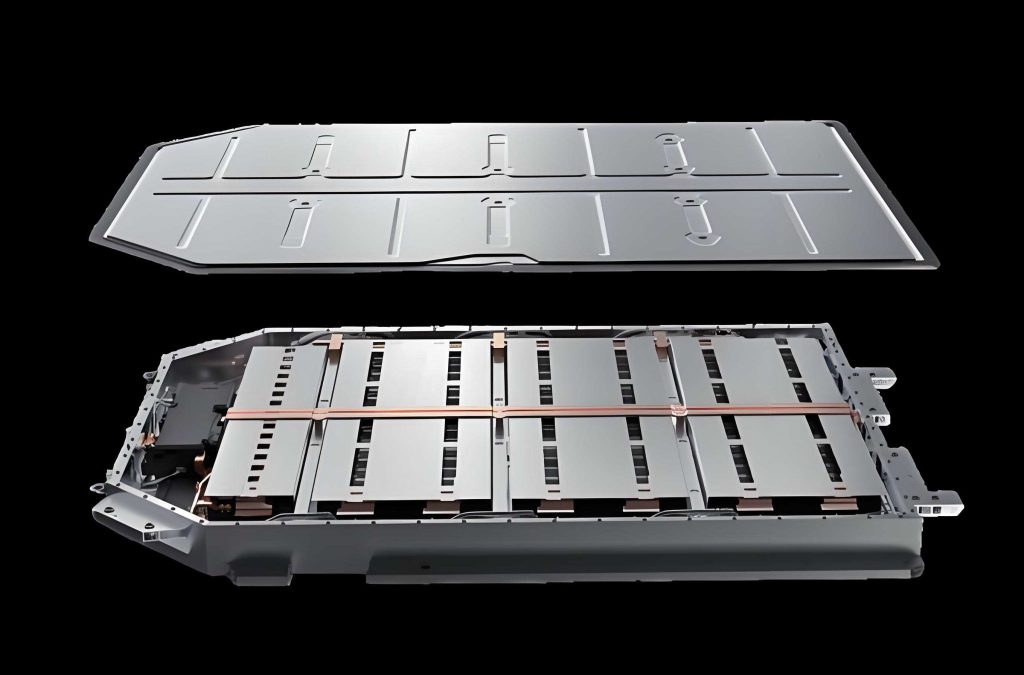
The global shift towards sustainable transportation has accelerated the development of electric vehicles (EVs). As an environmentally friendly alternative to conventional internal combustion engine vehicles, EVs rely fundamentally on their energy storage systems, predominantly traction battery packs. The performance of these traction battery packs directly dictates the vehicle’s driving range, acceleration capability, and overall efficiency. However, the complex electrochemical nature of batteries makes accurate state estimation, particularly the remaining capacity or State of Charge (SOC), a challenging task. This study focuses on the prediction of remaining capacity in traction battery packs, a critical parameter for effective battery management and vehicle control.
2 Analysis of Traction Battery Pack Characteristics
2.1 Working Principle of LiFePO₄ Batteries
The LiFePO₄ battery, a type of lithium-ion battery, utilizes lithium iron phosphate as the cathode material. Its electrochemical reaction is represented as follows:
Negative electrode reaction:
$$ \text{LiFePO}_4 \xrightarrow{\text{charge}} \text{Li}_{1-x}\text{FePO}_4 + x\text{Li}^+ + x\text{e}^- $$
Positive electrode reaction:
$$ x\text{Li}^+ + x\text{e}^- + 6\text{C} \xrightarrow{\text{charge}} \text{Li}_x\text{C}_6 $$
LiFePO₄ batteries offer several advantages for traction battery packs, including high thermal stability, long cycle life, environmental friendliness, and a flat discharge plateau, making them an ideal choice for EVs.
2.2 Performance Indicators of Traction Battery Packs
Several key metrics define the performance of a traction battery pack. Key indicators include the pack’s nominal voltage, its capacity measured in Ampere-hours (Ah), energy density, power density, and cycle life. The relationship between these parameters is essential for understanding the dynamic behavior under load.
| Battery Type | Specific Energy (Wh/kg) | Energy Density (Wh/L) | Specific Power (W/kg) | Cycle Life (Cycles) |
|---|---|---|---|---|
| VRLA | 35~40 | 60~90 | 200~300 | 400~600 |
| Ni-Cd | 40~60 | 80~110 | 150~350 | 600~1200 |
| Ni-MH | 60~70 | 130~170 | 150~300 | 300~1200 |
| Li-Ion | 90~130 | 140~200 | 250~450 | 800~1200 |
| LiFePO₄ | 90~120 | 200~250 | 200~400 | >2000 |
2.3 Discharge Experiment of Traction Battery Pack Cells
I designed a series of discharge experiments to characterize the behavior of a 3.2V, 3Ah 26650P LiFePO₄ cell under different loads and temperatures. A ZEEMOO850 battery testing system measured voltage and current, while a ZEEMOO3000E internal resistance tester monitored cell impedance.
Experimental Procedure: Initially, the cell was charged to 3.65V and left to rest for five hours. Discharge tests occurred at room temperature with constant currents of 0.5A, 1A, 2A, 3A, 4A, 5A, 6A, 7A, 8A, 9A, 15A, 20A, 30A, 50A, and 60A. The voltage, current, and time data were logged to create discharge characteristic curves. I also investigated the impact of varying ambient temperatures on the discharge capacity.
| Discharge Current (A) | Discharge Voltage (V) | Extracted Capacity (Ah) |
|---|---|---|
| 3 | 3.2267 | 0.04991 |
| 3 | 3.2132 | 0.34967 |
| 3 | 3.2015 | 0.69943 |
| 4 | 3.0780 | 1.1352 |
| 5 | 3.0802 | 1.9018 |
| 6 | 3.1050 | 2.4191 |
| 9 | 2.9857 | 2.4231 |
The experiments revealed that the discharge voltage profile significantly depends on the discharge current. Higher discharge rates result in a more rapid voltage drop and a shortened discharge plateau, as illustrated in the data. The extracted capacity before reaching the cut-off voltage also decreases with higher discharge currents, an effect primarily due to increased internal losses and reduced efficiency at high rates.
2.4 Theoretical Derivation for Prediction
The internal state of a traction battery pack is a complex, non-linear system that is difficult to model analytically. The instantaneous remaining capacity \( C(t) \) is influenced by the present terminal voltage \( U(t) \), the current \( I(t) \), and time \( t \). Given that the nominal capacity \( C_0 \) and the average internal resistance \( R_0 \) are constant for a specific battery, and the change in internal resistance is minimal, I simplified the functional relationship. The dependency of terminal voltage on the extracted capacity is not direct; rather, it depends on the current and the time of discharge. Therefore, the final functional expression for the prediction model is:
$$ C(k) = f(U(k), I(k), T) $$
where \( T \) is the sampling period, and \( k \) is the discrete time step. This equation forms the basis for the neural network model, with discharge voltage, discharge current, and time (or derived capacity) as inputs to predict the remaining capacity.
3 Neural Network-Based Prediction Model for Traction Battery Pack
3.1 Modeling Mechanism of Neural Networks
Traditional system modeling relies on physical laws or analytical mathematical expressions. However, for complex systems like traction battery packs, where the internal dynamics are governed by non-linear electrochemical processes and are subject to uncertainties, these methods are insufficient. An alternative is system identification, where a model is constructed based on observed input-output data. The process involves selecting an appropriate model structure, choosing suitable input signals, and defining an error criterion to minimize the difference between the model output and the actual system output.
A common model for non-linear systems is the Non-linear Auto-Regressive Moving Average model with eXogenous inputs (NARMAX). The model can be represented as:
$$ y(k) = f(y(k-1), \ldots, y(k-n_y), u(k-1), \ldots, u(k-n_u)) $$
Neural networks, particularly multi-layer perceptrons trained with the Backpropagation algorithm (BP), are powerful tools for such identification tasks due to their ability to approximate any continuous non-linear function to an arbitrary degree of accuracy (Kolmogorov’s theorem). The BP algorithm, based on the gradient descent method, minimizes the mean square error (MSE) between the predicted and actual outputs.
| Aspect | Traditional Computing | Neural Network Computing |
|---|---|---|
| Problem Solving | Algorithm | Network structure and examples |
| Knowledge Acquisition | Programming | Training with examples |
| Data Processing | Sequential | Parallel |
| Precision | High | Low, non-linear mapping |
| Data Storage | ROM/RAM | Weights of connections |
3.2 Prediction System Modeling and Prediction
Based on the theoretical derivation, I selected the discharge current and voltage as the input parameters and the remaining capacity as the output for the neural network. I designed a three-layer BP network structure: an input layer with two neurons, a hidden layer with eleven neurons, and an output layer with a single neuron, as shown in the following model.
The network training process involves forward propagation of inputs and backward propagation of errors. The output of a neuron in a hidden layer is given by a non-linear activation function \( \varphi \), often the sigmoid function. The weights are updated iteratively until the MSE converges to a desired goal.
To validate the accuracy of the prediction model, I used the trained network to predict the capacity for a 6A discharge cycle, which was not part of the training data set. The results of this initial validation run demonstrated the feasibility of the model. As illustrated by the error between the predicted and actual capacity, the initial model’s predictions were reasonably accurate, particularly during the initial stages of discharge. However, as the cell approached the end of discharge, the model exhibited some deviations. The trained network’s performance on a set of sampled test points is presented in Table 3-2.
| Voltage (V) | Current (A) | Measured SOC (Ah) | Predicted SOC (Ah) | Relative Error (%) |
|---|---|---|---|---|
| 3.434 | 8.9973 | 2.985 | 2.8380 | 4.91 |
| 3.284 | 8.9966 | 2.084 | 1.9550 | 4.32 |
| 3.255 | 8.9966 | 1.938 | 1.8300 | 3.61 |
| 3.202 | 8.9966 | 0.563 | 0.6530 | 3.09 |
The model’s training time using a standard BP algorithm was relatively long. While the results were adequate for applications with low precision demands, improvements in both accuracy and speed were necessary for a more robust and practical traction battery pack management system. This led me to investigate the use of an optimization algorithm.
4 Improved Traction Battery Pack Prediction Model using GA-BP
The pure BP algorithm is known for its slow convergence and tendency to become trapped in local minima, rather than finding the global optimum. To overcome these issues, I combined the BP algorithm with a Genetic Algorithm (GA). GA is a search heuristic inspired by natural selection and genetics, known for its strong global search capabilities. The core idea is to utilize the GA to find optimal initial weights and thresholds for the BP network, thus setting the stage for a more efficient and accurate local search by the BP algorithm. This hybrid approach is referred to as the GA-BP algorithm.
4.1 Optimization of Network Structure Parameters
In this method, the GA process begins by initializing a population of potential solutions, which represent the connection weights and biases of the network. Each individual in the population is evaluated using a fitness function based on the sum of squared errors (MSE). The following equations define the evolutionary process:
Fitness evaluation:
$$ f(i) = \frac{1}{E(i)} $$
where the error is:
$$ E(i) = \sum_{p} \sum_{k} (T_k – V_k)^2 $$
Selection probability:
$$ P_s = f_i / \sum_{i=1}^{M} f_i $$
with a crossover probability \( P_c = 0.6 \) and mutation probability \( P_m = 0.2 \).
Algorithm Steps for GA-BP:
- Randomly initialize a population of network weights and thresholds.
- Evaluate the fitness for each individual based on the BP error function.
- Apply genetic operators: selection, crossover to generate a new population.
- Apply mutation to a small fraction of the population to maintain diversity.
- Re-evaluate new individuals and insert them into the population.
- If the error has reduced to the target \( \varepsilon_{GA} \) or the generation limit is reached, proceed to the next step; otherwise, return to step 3.
- Use the best-evolved individual as the initial weights and thresholds for the BP network and continue training until the final goal \( \varepsilon_{GA-BP} \) is met.
After applying this algorithm, the initial weights (\(W_1, W_2\)) and biases (\(B_1, B_2\)) obtained via GA optimization were as follows:
Input-to-hidden weights \(W_1\):
$$ W_1 = \begin{bmatrix} -0.0090 & 0.5820 \\ 0.3877 & -0.1891 \\ -0.2328 & 0.1273 \\ -0.2127 & -0.1972 \\ -0.3801 & -0.6126 \\ -0.2952 & -0.8903 \\ 0.3591 & -0.0859 \\ -0.2105 & -0.3088 \\ 0.6778 & -0.3019 \\ 0.5918 & -0.3165 \\ 0.2864 & -0.3599 \end{bmatrix} $$
Hidden-to-output weights \(W_2\):
$$ W_2 = \begin{bmatrix} -0.2084 \\ -0.2235 \\ 0.1563 \\ 0.6178 \\ 0.0618 \\ -0.6310 \\ -0.2696 \\ -0.2862 \\ -0.3209 \\ 0.7957 \\ -0.4142 \end{bmatrix} $$
Hidden layer biases \(B_1\):
$$ B_1 = \begin{bmatrix} 0.1061 \\ 0.4113 \\ 0.2258 \\ 0.4827 \\ 0.3245 \\ -0.5378 \\ -0.6311 \\ 0.2888 \\ -0.5434 \\ -0.2097 \\ 0.4065 \end{bmatrix} $$
Output layer bias \(B_2 = [-0.4126]\).
The forecasting results with the optimized initial weights showed a distinct improvement. The predicted capacity closely matched the actual values across the entire discharge range, with a significantly reduced error compared to the standard BP model for the same test cycle. Additionally, the network training time dramatically improved from tens of seconds to just a couple of seconds.
4.2 Optimization of Network Training Parameters
Apart from the structural parameters, the training parameters profoundly impact the model’s convergence speed. Key parameters include the maximum number of training epochs, the learning rate, and the performance goal. I systematically used the GA to optimize these parameters. The objective was to minimize the training time while maintaining a satisfactory level of accuracy. In this GA-based optimization, I defined the fitness function as the inverse of the training time. The parameters under optimization included:
- Training goal (goal): The target MSE for the training set.
- Learning rate (lr): The step size used for weight updates.
- Maximum Epochs (epoch): The maximum number of training iterations.
I evaluated these parameters using a three-layer nested approach, starting from the most influential parameter (goal) and moving outward. The optimal parameters obtained from this process are listed in Table 4-1.
| Optimization Layer | Parameter | Population Size | Search Range | Crossover Probability | Mutation Probability | Best Value |
|---|---|---|---|---|---|---|
| Inner | goal | 4 | 0.01 ~ 0.08 | 0.6 | 0.01 | 0.08 |
| Middle | lr | 8 | 0.001 ~ 0.016 | 0.6 | 0.01 | 0.012 |
| Outer | epoch | 32 | 500 ~ 2050 | 0.6 | 0.01 | 1550 |
The application of the GA-optimized training parameters resulted in a substantial reduction in training time. When all three parameters were used, the BP network achieved its target accuracy in only 2.75 seconds versus the 22.95 seconds required with the original parameter set, marking an approximately 8-fold increase in training efficiency.
4.3 Results of the Integrated Optimization
Finally, I implemented a comprehensive optimization strategy, which integrated the optimal network structure and training parameters. This approach ensures that the network is initialized optimally and is trained using the most effective parameter set. The forecasting results are shown in the following figure, and the corresponding errors are presented below. The integrated GA-BP model was stable and achieved high-fidelity predictions throughout the entire discharge cycle.
| Current (A) | Voltage (V) | Measured Capacity (Ah) | BP Predicted (Ah) | GA-BP Predicted (Ah) | BP Relative Error (%) | GA-BP Relative Error (%) |
|---|---|---|---|---|---|---|
| 3 | 3.2267 | 2.955 | 2.8110 | 2.8800 | 4.81 | 2.53 |
| 3 | 3.2132 | 2.6552 | 2.5202 | 2.7242 | 4.52 | 2.34 |
| 3 | 3.2015 | 2.3055 | 2.3355 | 2.2175 | 1.32 | 2.93 |
| 3 | 3.1917 | 2.0556 | 2.1636 | 1.9906 | 3.61 | 2.16 |
| 3 | 3.1876 | 1.9556 | 1.8146 | 2.0006 | 4.69 | 1.51 |
| 3 | 3.1757 | 1.6558 | 1.5958 | 1.5958 | 2.01 | 2.03 |
| 3 | 3.1696 | 1.5059 | 1.6259 | 1.5899 | 4.05 | 2.83 |
The table demonstrates that the GA-BP algorithm consistently yields more accurate predictions than the standard BP algorithm across various data points, with relative errors often lower by several percentage points.
5 Establishment and Validation of the Prediction System
5.1 Application to Non-measured Data Points
I established a testing system to predict the states that were not captured during the physical experiments due to sampling time limitations or current settings. The system configuration used the 15 discharge datasets gathered from prior experiments to build a comprehensive training dataset for the prediction model. I then applied the prediction model to forecast the remaining capacity for a discharge condition not initially measured: a constant current of 2.5A. I generated input data for the network by selecting specific voltage values in a range likely to occur during the battery’s discharge.
For this test, the prediction model output the remaining capacity values for a series of voltage points at 2.5A and 3.0A. Table 5-1 shows the predicted values.
| Discharge Current (A) | Discharge Voltage (V) | Predicted Remaining Capacity (Ah) |
|---|---|---|
| 3.0 | 3.30 | 2.9735 |
| 3.0 | 3.28 | 2.9682 |
| 3.0 | 3.20 | 2.3436 |
| 3.0 | 3.10 | 1.2442 |
To validate the accuracy of this prediction, I performed the actual discharge test under the same conditions, setting the data acquisition system to record at a higher frequency to capture more data points for comparison. The subsequent experimental data provided the “actual” values to compare against the predictions.
5.2 Validation of the Prediction Model Accuracy
The core of this system is its ability to provide reliable capacity estimations. I evaluated the performance of the prediction system by comparing the predicted remaining capacities with the measured capacities from a high-resolution discharge test for both the 3A and the 2.5A discharge currents. A detailed comparison is presented in the following tables.
| I (A) | U (V) | Predicted (Ah) | Measured (Ah) | Relative Error (%) |
|---|---|---|---|---|
| 3 | 3.40 | 2.9735 | 2.9315 | 1.39 |
| 3 | 3.38 | 2.9682 | 2.9552 | 0.43 |
| 3 | 3.36 | 2.8653 | 2.8893 | 0.80 |
| 3 | 3.34 | 2.7192 | 2.6862 | 1.09 |
| 3 | 3.32 | 2.5634 | 2.5114 | 1.73 |
| 3 | 3.30 | 2.3436 | 2.3836 | 1.33 |
| 3 | 3.28 | 1.9438 | 1.9098 | 1.13 |
| 3 | 3.26 | 1.7466 | 1.7676 | 0.69 |
| 3 | 3.24 | 1.5968 | 1.5648 | 1.07 |
| 3 | 3.22 | 1.3569 | 1.3309 | 0.87 |
| 3 | 3.20 | 1.2442 | 1.2142 | 1.00 |
| I (A) | U (V) | Predicted (Ah) | Measured (Ah) | Relative Error (%) |
|---|---|---|---|---|
| 2.5 | 3.40 | 2.9846 | 2.8966 | 2.93 |
| 2.5 | 3.38 | 2.9666 | 2.8906 | 2.53 |
| 2.5 | 3.36 | 2.8935 | 2.9545 | 2.03 |
| 2.5 | 3.34 | 2.7752 | 2.7062 | 2.29 |
| 2.5 | 3.32 | 2.6024 | 2.6544 | 1.73 |
| 2.5 | 3.30 | 2.4368 | 2.3708 | 2.21 |
| 2.5 | 3.28 | 2.0456 | 1.9686 | 2.56 |
| 2.5 | 3.26 | 1.8985 | 1.9765 | 2.62 |
| 2.5 | 3.24 | 1.7123 | 1.6453 | 2.23 |
| 2.5 | 3.22 | 1.4650 | 1.4130 | 1.73 |
| 2.5 | 3.20 | 1.3368 | 1.2888 | 1.60 |
The validation results confirm that the established testing system can accurately predict the remaining capacity of the traction battery pack cell for conditions not explicitly included in the training dataset. The maximum prediction error observed was below 3%, which is well within the tolerance for most engineering applications. This proves the model’s robust generalization capability and its reliability for State of Charge estimation in battery management systems.
Conclusion
In this thesis, I successfully developed a methodology for predicting the remaining capacity of a traction battery pack, focusing on LiFePO₄ cells. The research utilized an experimental approach to gather real-world data and applied advanced computational intelligence techniques to create accurate and efficient prediction models.
The key findings and contributions of this work are summarized as follows:
- Data-driven Modeling Approach: I demonstrated that the complexities of a traction battery pack’s internal state, which defy traditional physics-based modeling, can be accurately captured by a data-driven neural network approach.
- Optimized Network Architecture: The integration of a Genetic Algorithm with a Backpropagation network (GA-BP) proved to be highly effective. The GA effectively searched for optimal initial weights and thresholds with a global perspective. This pre-optimization step prevented the BP algorithm from falling into local minima and enhanced the precision of the final predictions.
- Improved Training Efficiency: By using GA to optimize the neural network’s training parameters, the model achieved a substantial increase in training speed. The optimized network reduced its training time by over 80% while maintaining or even improving the prediction accuracy, thereby fulfilling real-time performance requirements for battery management systems.
- Comprehensive Optimization: The best performance was obtained by combining structural and training parameter optimization. The integrated GA-BP model predicted the SOC with a significantly higher accuracy and a faster convergence rate compared to the baseline BP model.
- Practical Validation: I validated the entire process by building an experimental testing system that predicted discharge states not part of the training set. The strong agreement with actual experimental measurements, achieving errors below 3%, verified the generalization ability and engineering practicality of the model.
While this system is specialized for a specific LiFePO₄ cell, the methodology is general and can be extended to other battery chemistries and larger traction battery packs. Future work may involve incorporating other influential factors, such as temperature and aging effects, to create an even more comprehensive battery management system.