
As a researcher working on thermal management for electrified transportation, I view the electric vehicle battery pack as one of the most temperature-sensitive assemblies in a modern vehicle. The rapid growth in the number of automobiles has placed enormous pressure on both energy resources and environmental quality. Emissions from conventional vehicles have drawn attention from governments, environmental organizations, and manufacturers, while electric mobility has become a key pathway for addressing energy and environmental challenges because of its high efficiency, low local emissions, and strong energy utilization. Within this transition, the electric vehicle battery pack determines driving range, safety level, and power delivery capability. Temperature is among the most critical factors influencing lithium-ion battery performance and safety. In my analysis, the preferred operating window for lithium-ion cells is approximately 20 °C to 40 °C, and the maximum temperature difference within an electric vehicle battery pack should remain below 5 °C. Excessive temperature reduces capacity and cycle life, and once a critical threshold is reached, thermal runaway may be triggered. As cell capacity, energy density, and power density increase, heat generation at high discharge rates rises sharply, which continuously strengthens the need for advanced thermal management. Therefore, battery thermal management has become a central research topic for the electric vehicle battery pack.
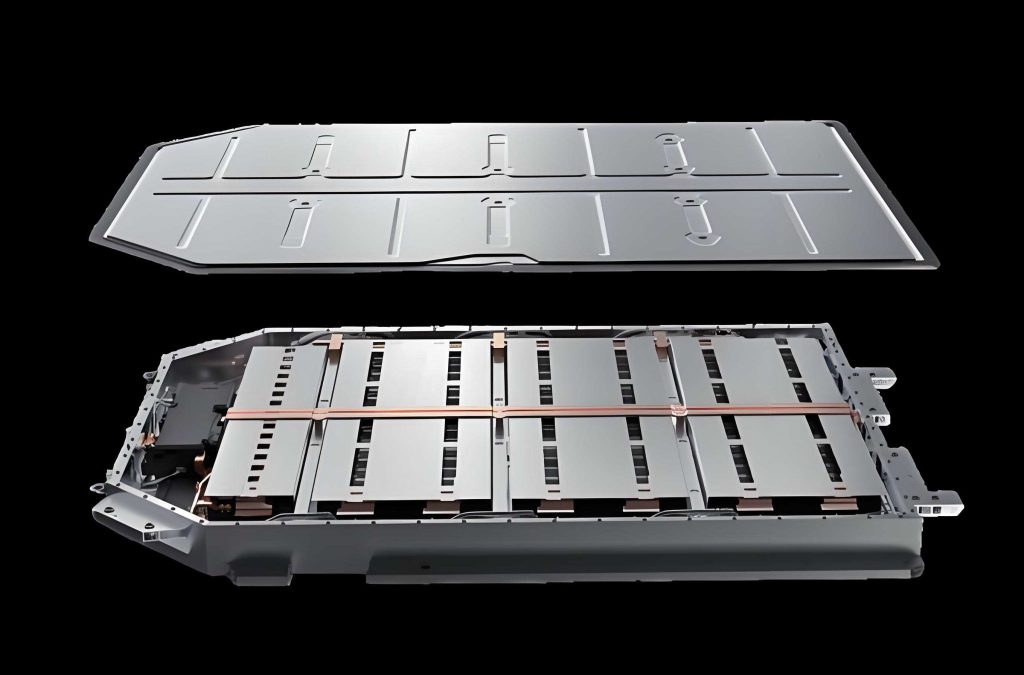
1. Thermal Management Requirements and Fundamental Equations
I begin with the fundamental requirement that an electric vehicle battery pack must be kept within a safe temperature band under actual service conditions. The heat generation inside a cell can be expressed by a combined irreversible and reversible term:
$$ \dot{Q}_{gen} = I^2 R_{int} + I T \frac{\partial U}{\partial T} $$
Here, \(I\) is the current, \(R_{int}\) is the internal resistance, \(T\) is the cell temperature, and \(\partial U / \partial T\) is the entropic coefficient. The first term represents irreversible Joule heating, while the second term represents reversible entropic heating or cooling. For an electric vehicle battery pack, the total heat generation is the sum over all cells:
$$ \dot{Q}_{pack} = \sum_{i=1}^{N} \dot{Q}_{gen,i} $$
The transient thermal field in a battery module or pack can be described by the energy conservation equation:
$$ \rho C_p \frac{\partial T}{\partial t} =
abla \cdot (k
abla T) + \dot{Q}_{gen} $$
where \(\rho\) is density, \(C_p\) is specific heat capacity, \(k\) is thermal conductivity, and \(t\) is time. The cooling requirement can be defined by a simple ratio:
$$ \eta_{cool} = \frac{Q_{removed}}{Q_{generated}} \times 100\% $$
A well-designed thermal management system for an electric vehicle battery pack should achieve high \(\eta_{cool}\), low maximum temperature \(T_{max}\), small temperature difference \(\Delta T\), low parasitic power, low mass, and high reliability. I summarize these targets in Table 1.
| Metric | Symbol | Target or desired trend | Reason |
|---|---|---|---|
| Maximum temperature | \(T_{max}\) | Below 40 °C in normal operation | Slows aging and reduces thermal runaway risk |
| Temperature difference | \(\Delta T\) | Below 5 °C | Improves cell consistency and pack lifetime |
| Cooling efficiency | \(\eta_{cool}\) | As high as possible | Ensures heat removal matches heat generation |
| Parasitic power | \(P_{par}\) | Low | Preserves driving range |
| Mass | \(M_{sys}\) | Low | Supports vehicle lightweighting |
| Cost | \(C_{sys}\) | Low | Enables mass adoption |
| Reliability | \(R_{sys}\) | High | Maintains safety over service life |
In my view, these metrics cannot be optimized independently. A cooling method that lowers \(T_{max}\) but adds excessive pump power, mass, or maintenance burden may not be suitable for a production electric vehicle battery pack. This is why I compare air cooling, liquid cooling, phase change material cooling, heat pipe cooling, and immersion cooling in the following sections.
2. Air Cooling for the Electric Vehicle Battery Pack
Air cooling is the most traditional approach. It can be divided into natural air cooling and forced air cooling. Natural air cooling uses air convection generated by vehicle motion and does not consume additional energy. Forced air cooling uses fans to actively draw air and accelerate flow across cell surfaces, so it consumes electrical energy but provides stronger heat removal. The basic convective heat transfer relation is:
$$ Q = h A (T_b – T_a) $$
where \(h\) is the convective heat transfer coefficient, \(A\) is the effective heat transfer area, \(T_b\) is battery surface temperature, and \(T_a\) is air temperature. For internal flow, the Nusselt number can be estimated by:
$$ Nu = \frac{h L}{k} $$
For turbulent pipe or channel flow, the Dittus-Boelter correlation is often used:
$$ Nu = 0.023 Re^{0.8} Pr^{0.4} $$
where \(Re\) is the Reynolds number and \(Pr\) is the Prandtl number. The Reynolds number is:
$$ Re = \frac{\rho v D_h}{\mu} $$
and the hydraulic diameter is:
$$ D_h = \frac{4 A_c}{P_w} $$
For an electric vehicle battery pack, air cooling design usually focuses on air channel shape, inlet and outlet positions, cell arrangement, and cell spacing. Studies have shown that non-uniform cell spacing can improve temperature uniformity. Symmetric air-cooled systems often outperform asymmetric ones when the inlet and outlet locations are carefully arranged. Internal fin structures can also increase heat transfer area and improve temperature uniformity. For example, a forced-air system with internal fins has been reported to keep maximum temperature and maximum temperature difference below about 48.5 °C and 4.8 °C even at a 4C discharge rate. Table 2 summarizes key air cooling parameters.
| Parameter | Symbol | Typical influence | Design consideration |
|---|---|---|---|
| Air velocity | \(v\) | Higher \(v\) increases \(h\) | Fan power rises with pressure drop |
| Channel gap | \(b\) | Smaller gap increases velocity but raises pressure drop | Balance cooling and parasitic power |
| Cell spacing | \(s\) | Non-uniform spacing can improve uniformity | Avoid local hot spots |
| Inlet position | \(x_{in}\) | Affects flow distribution | Symmetric layouts are often better |
| Outlet position | \(x_{out}\) | Affects recirculation and dead zones | Reduce stagnant regions |
| Fin structure | \(A_{fin}\) | Increases heat transfer area | May increase mass and pressure loss |
The advantages of air cooling are clear: simple structure, relatively low cost, and easy maintenance. It is common in small electric vehicles and low-power electric vehicle battery pack designs. However, air cooling is strongly affected by ambient temperature, vehicle speed, cell arrangement, and effective thermal conductivity. Its cooling rate is relatively slow, and its performance is often insufficient for high-energy-density batteries. In my assessment, air cooling remains useful as a baseline or auxiliary method, but it cannot alone guarantee ideal thermal control for a high-performance electric vehicle battery pack.
3. Liquid Cooling for the Electric Vehicle Battery Pack
Liquid cooling uses a pump to circulate coolant through channels or cold plates around cells. Heat is transferred from cell surfaces to the coolant and then rejected through a heat exchanger. A schematic concept includes a cold plate with serpentine channels, inlet and outlet ports, thermal pads, and module sections. The heat removed by liquid coolant can be written as:
$$ Q = \dot{m} C_p (T_{out} – T_{in}) $$
where \(\dot{m}\) is mass flow rate, \(C_p\) is coolant specific heat, and \(T_{out}\) and \(T_{in}\) are outlet and inlet temperatures. The convective resistance is:
$$ R_{conv} = \frac{1}{h A} $$
The Nusselt number for internal flow can be expressed as:
$$ Nu = \frac{h D_h}{k} $$
and the pressure drop in a channel is often estimated by:
$$ \Delta P = f \frac{L}{D_h} \frac{\rho v^2}{2} $$
where \(f\) is the friction factor, \(L\) is channel length, \(\rho\) is coolant density, and \(v\) is mean velocity. Pump power is approximately:
$$ P_{pump} = \frac{\dot{m} \Delta P}{\rho \eta_{pump}} $$
For an electric vehicle battery pack, the internal channel design of the cold plate is critical. Channel geometry determines heat transfer area, flow distribution, pressure drop, and temperature uniformity. Serpentine, U-shaped, linear, spiral, and hexagonal channels have been studied. Numerical results suggest that serpentine and hexagonal channels can significantly improve temperature uniformity, while some spiral designs maintain lower pressure drop and pumping power. Bio-inspired leaf-vein channels have been reported to reduce maximum temperature and improve heat transfer efficiency compared with rectangular channels. Diamond lattice structures embedded in liquid cooling channels can greatly increase heat transfer coefficient and reduce average thermal resistance. Grooved cold plates and pin-fin channels can also lower maximum temperature and improve temperature uniformity. Table 3 summarizes common liquid cooling channel designs.
| Channel design | Main feature | Advantage | Challenge |
|---|---|---|---|
| Serpentine | Long winding path | Good temperature uniformity | Higher pressure drop |
| U-shaped | Smooth return flow | Simple layout | Possible maldistribution |
| Linear | Straight parallel channels | Low pressure drop | Lower uniformity |
| Hexagonal | Hexagonal flow passages | Improved uniformity | Complex manufacturing |
| Leaf-vein bionic | Mimics natural vein network | Higher heat transfer efficiency | Fabrication complexity |
| Diamond lattice | Embedded cellular structure | High heat transfer coefficient | Increased pressure loss |
| Grooved plate | Surface grooves | Lower maximum temperature | Sealing requirements |
| Pin-fin channel | Pin fins inside channel | Enhanced heat transfer | Higher pumping power |
Liquid cooling is currently the most widely used technology in electric vehicle battery pack thermal management. Its advantages include strong heat dissipation, fast response, flexible layout, mature manufacturing, and compatibility with vehicle air-conditioning systems. It supports fast charging and extreme operating conditions. However, liquid cooling systems are structurally complex, relatively heavy, and costly. They also demand strict sealing to prevent leakage. When microchannels or multi-channel cold plates are used, high-efficiency pumps may be required, which increases parasitic power. In my judgment, liquid cooling will remain a dominant solution for the electric vehicle battery pack, but its future depends on lightweight materials, low-pressure-drop channel design, and intelligent flow control.
4. Phase Change Material Cooling for the Electric Vehicle Battery Pack
Phase change material cooling uses the latent heat absorbed or released during a solid-liquid phase transition. When the temperature rises, the phase change material melts and absorbs a large amount of heat while its own temperature remains nearly constant. When the temperature falls, it solidifies and releases heat. This behavior can suppress temperature differences among cells and improve temperature consistency. For an electric vehicle battery pack, phase change material cooling is often classified as nested or jacket type. Nested configurations are common for cylindrical cells, where cells are embedded in the phase change material. Jacket configurations are common for prismatic cells, where the material fills gaps between cell units to form a sandwich-like structure.
The heat absorbed by a phase change material can be estimated by:
$$ Q_{PCM} = m [C_{p,s}(T_m – T_i) + L + C_{p,l}(T_f – T_m)] $$
where \(m\) is mass, \(C_{p,s}\) and \(C_{p,l}\) are solid and liquid specific heat capacities, \(T_m\) is melting temperature, \(T_i\) is initial temperature, \(T_f\) is final temperature, and \(L\) is latent heat. The Stefan number is useful for comparing sensible and latent heat effects:
$$ Ste = \frac{C_p (T_w – T_m)}{L} $$
where \(T_w\) is wall temperature. A low Stefan number indicates that latent heat dominates. The effective thermal conductivity of a composite phase change material with additives can be approximated by:
$$ k_{eff} = \phi k_{add} + (1 – \phi) k_{PCM} $$
where \(\phi\) is the volume fraction of the additive. For an electric vehicle battery pack, pure phase change materials often suffer from low thermal conductivity. Therefore, metal fins, metal foams, expanded graphite, and heat pipes are often added. Studies have shown that longitudinal metal fins increase contact area between the phase change material and the heat source. More fins generally lead to better heat dissipation. Combining phase change materials with liquid cooling can reduce maximum temperature and maximum temperature difference significantly. In one reported hybrid system, maximum temperature and maximum temperature difference were reduced by 13.2 °C and 10.8 °C compared with conventional liquid cooling, and the liquid cooling operating time was shortened because the phase change material absorbed heat during cycling. Table 4 compares common phase change material properties.
| Material type | Melting point range | Latent heat | Thermal conductivity | Main challenge |
|---|---|---|---|---|
| Paraffin | 20–60 °C | Moderate to high | Low | Low conductivity, leakage |
| Fatty acids | 30–70 °C | Moderate | Low | Corrosion, stability |
| Salt hydrates | 25–80 °C | High | Moderate | Supercooling, phase separation |
| Expanded graphite composite | Adjustable | Moderate | High | Fabrication cost |
| Metal foam composite | Adjustable | Moderate | Very high | Weight, corrosion |
Phase change material cooling is passive, so it requires no additional energy during operation and avoids pumps, pipes, and some maintenance costs. It can effectively suppress cell-to-cell temperature differences. However, when battery heat generation is small and the phase change material does not reach its melting point, latent heat cannot be used, and cooling fails. Therefore, phase change material cooling is more suitable for battery packs with high heat generation. Once the material is fully melted, it cannot continue to provide cooling unless it is re-solidified. For this reason, I consider phase change material cooling to be most effective when coupled with air cooling, liquid cooling, or heat pipes in an electric vehicle battery pack.
5. Heat Pipe Cooling for the Electric Vehicle Battery Pack
Heat pipe cooling transfers heat rapidly through phase-change heat transfer of an internal working fluid. When the evaporator section is heated, the working liquid vaporizes. The saturated vapor flows to the condenser section under temperature and pressure differences. At the condenser, the vapor releases heat and condenses. The condensed liquid returns to the evaporator through capillary action in the wick. This cycle continues until the evaporator and condenser temperatures equalize. The heat transfer rate can be described by:
$$ Q = \frac{\Delta T}{R_{total}} $$
where \(\Delta T\) is the temperature difference between the heat source and heat sink, and \(R_{total}\) is the total thermal resistance. The total resistance can be decomposed as:
$$ R_{total} = R_{evap} + R_{adiabatic} + R_{cond} + R_{wick} + R_{interface} $$
The capillary limit is one of the main performance limits:
$$ Q_{max} = \frac{2 \pi L_{eff} k_{eff} \sigma_l \rho_l}{\mu_l} \left( \frac{1}{r_c} – \frac{1}{r_p} \right) $$
where \(L_{eff}\) is effective length, \(k_{eff}\) is effective thermal conductivity, \(\sigma_l\) is liquid surface tension, \(\rho_l\) is liquid density, \(\mu_l\) is liquid viscosity, \(r_c\) is capillary radius, and \(r_p\) is pore radius. Heat pipe design for an electric vehicle battery pack mainly involves structure, working fluid, and coupling with other cooling methods. A flat aluminum heat pipe charged with acetone at a filling ratio of 50% has been reported to reduce battery temperature substantially compared with air cooling and to simplify the structure compared with liquid cooling. A heat pipe assisted separation-type battery thermal management system with phase change material and porous metal foam has also been shown to provide more suitable temperatures and better reduce internal temperature imbalance. Table 5 summarizes common heat pipe working fluids.
| Working fluid | Useful temperature range | Advantage | Limitation |
|---|---|---|---|
| Water | 30–200 °C | High latent heat | Freezing, compatibility |
| Acetone | -20–120 °C | Good low-temperature performance | Flammability |
| Methanol | -10–130 °C | Moderate latent heat | Toxicity |
| Ammonia | -60–100 °C | High latent heat | Safety, material compatibility |
| Dielectric fluids | Adjustable | Electrical compatibility | Lower heat transfer |
Heat pipes have extremely high effective thermal conductivity and good isothermal performance. They can reduce the need for large heat sinks and save space. They do not rely on fans or mechanical equipment, so they produce little noise and offer high reliability and low maintenance. However, heat pipe manufacturing is relatively complex, requires special materials and equipment, and installation can be difficult. Performance is affected by ambient temperature and humidity. Therefore, heat pipe cooling is often used as an auxiliary or coupling technology in an electric vehicle battery pack rather than as a standalone solution for all conditions.
6. Immersion Cooling for the Electric Vehicle Battery Pack
Immersion cooling, also called direct cooling, fully or partially submerges the electric vehicle battery pack in a cooling medium. Heat is removed by circulation of the dielectric fluid. Support structures may be added between cells to fix them or adjust flow. Immersion cooling can be single-phase or two-phase. In single-phase immersion cooling, the coolant remains liquid and heat is removed by sensible heating. In two-phase immersion cooling, the coolant boils at the cell surface and removes heat through latent heat. The convective heat transfer relation for single-phase immersion is:
$$ q” = h (T_s – T_f) $$
where \(q”\) is heat flux, \(T_s\) is surface temperature, and \(T_f\) is fluid temperature. The Nusselt number can be expressed as:
$$ Nu = C Re^m Pr^{1/3} $$
For two-phase immersion cooling, the heat flux can be written as:
$$ q” = h (T_s – T_{sat}) + \dot{m} h_{fg} $$
where \(T_{sat}\) is saturation temperature and \(h_{fg}\) is latent heat of vaporization. Immersion cooling research for the electric vehicle battery pack focuses on structural layout, internal enhancement structures, coolant selection, and flow rate. A single-phase static immersion thermal management system has been reported to achieve a maximum cooling rate of about 2.7 W at the highest battery temperature, which is about 50% higher than forced air cooling. As the liquid-to-electric ratio increases, cooling efficiency improves, but an excessively high ratio reduces pack integration density. Baffles inserted at different positions can improve thermal performance. A fish-shaped bionic baffle design has been reported to reduce maximum module temperature by 9.2% compared with a conventional baffle under 3C discharge and a mass flow of 2.73 g/s. Table 6 compares common immersion cooling fluids.
| Coolant | Phase | Electrical compatibility | Cooling performance | Concern |
|---|---|---|---|---|
| Deionized water | Single-phase | Requires strict insulation | Very high | Short circuit risk |
| Mineral oil | Single-phase | Good | Moderate | Viscosity, pumping power |
| Engineering fluid | Single-phase | Good | Moderate to high | Cost |
| Fluorocarbon | Two-phase | Excellent | High | Cost, environmental impact |
| Low-boiling dielectric | Two-phase | Excellent | Very high | Sealing, vapor management |
Immersion cooling has a unique advantage: the coolant can contact every part of the electric vehicle battery pack, providing comprehensive and uniform cooling. The medium usually has higher electrical resistance than conventional liquid coolants, and cooling efficiency can be high. It is widely considered one of the most promising cooling methods. However, compatibility, volume efficiency, maintenance, sealing, and cost remain challenges. In my view, immersion cooling will likely first appear in high-performance or fast-charging electric vehicle battery pack platforms, where thermal loads are severe and cost sensitivity is lower.
7. Comparative Analysis of Cooling Methods
To compare these technologies, I use a multi-objective framework. The overall objective can be written as:
$$ F = w_1 T_{max} + w_2 \Delta T + w_3 P_{pump} + w_4 M + w_5 C $$
where \(w_1\) to \(w_5\) are weights for maximum temperature, temperature difference, pump power, mass, and cost. Lower \(F\) is better. The weights depend on vehicle class, duty cycle, climate, and cost targets. Table 7 gives a qualitative comparison of the main cooling methods for an electric vehicle battery pack.
| Cooling method | Cooling capability | Temperature uniformity | Parasitic power | Mass | Cost | Best application |
|---|---|---|---|---|---|---|
| Natural air cooling | Low | Moderate | Very low | Low | Very low | Low-power electric vehicle battery pack |
| Forced air cooling | Moderate | Moderate | Moderate | Low to moderate | Low | Small and medium battery packs |
| Liquid cooling | High | High | Moderate to high | Moderate to high | Moderate to high | Mainstream electric vehicle battery pack |
| Phase change material | Moderate | Very high during phase change | Very low | Moderate | Moderate | Transient high-load buffering |
| Heat pipe | Moderate to high | High | Low | Low to moderate | Moderate | Auxiliary and space-limited packs |
| Immersion cooling | Very high | Very high | Moderate | High | High | Fast charging and extreme conditions |
I also compare the methods by their dominant physical limits. Air cooling is limited by low air heat capacity and low convective coefficient. Liquid cooling is limited by pump power, sealing, and mass. Phase change material cooling is limited by low thermal conductivity and finite latent heat. Heat pipe cooling is limited by capillary and boiling limits. Immersion cooling is limited by fluid cost, compatibility, and system integration. Table 8 summarizes these limits and possible improvements.
| Method | Dominant limit | Possible improvement |
|---|---|---|
| Air cooling | Low \(h\), low \(\rho C_p\) | Fins, optimized spacing, forced convection |
| Liquid cooling | Pressure drop, mass, sealing | Bionic channels, low-viscosity coolant, lightweight plates |
| Phase change material | Low \(k\), limited latent heat | Graphite, metal foam, fins, hybrid cooling |
| Heat pipe | Capillary limit, dry-out | Wick optimization, hybrid heat pipes |
| Immersion cooling | Cost, compatibility, volume | Dielectric fluids, optimized baffles, modular design |
8. Design Equations for Hybrid Thermal Management
Because no single method is perfect, I often evaluate hybrid systems for the electric vehicle battery pack. A hybrid system may combine phase change material with liquid cooling, heat pipes with air cooling, or immersion cooling with cold plates. The overall energy balance for a hybrid electric vehicle battery pack can be written as:
$$ \rho C_p \frac{\partial T}{\partial t} =
abla \cdot (k
abla T) + \dot{Q}_{gen} – \dot{Q}_{air} – \dot{Q}_{liq} – \dot{Q}_{PCM} – \dot{Q}_{hp} – \dot{Q}_{imm} $$
Each heat removal term can be expressed in its own form. For air cooling:
$$ \dot{Q}_{air} = h_{air} A_{air} (T_b – T_{air}) $$
For liquid cooling:
$$ \dot{Q}_{liq} = \dot{m}_{liq} C_{p,liq} (T_{out} – T_{in}) $$
For phase change material cooling:
$$ \dot{Q}_{PCM} = m_{PCM} L \frac{dx}{dt} + m_{PCM} C_{p,PCM} \frac{dT}{dt} $$
For heat pipe cooling:
$$ \dot{Q}_{hp} = \frac{T_{evap} – T_{cond}}{R_{hp}} $$
For immersion cooling:
$$ \dot{Q}_{imm} = h_{imm} A_{imm} (T_s – T_f) + \dot{m}_{vap} h_{fg} $$
The control objective for a hybrid electric vehicle battery pack can be written as a constrained optimization problem:
$$ \min_{u} J = \int_0^{t_f} \left( T_{max}(t) + \alpha \Delta T(t) + \beta P_{par}(t) \right) dt $$
subject to:
$$ T_{max}(t) \leq T_{limit} $$
$$ \Delta T(t) \leq \Delta T_{limit} $$
$$ P_{par}(t) \leq P_{limit} $$
where \(u\) represents control variables such as fan speed, pump speed, valve opening, and coolant flow rate. In my opinion, future electric vehicle battery pack thermal management will increasingly rely on such model-based control rather than fixed operating maps.
9. Material, Structure, Control, and Evaluation Perspectives
From a materials perspective, I see four major directions for the electric vehicle battery pack. First, coolants with higher thermal conductivity, lower viscosity, and better dielectric properties are needed. Second, phase change materials with higher latent heat, higher thermal conductivity, and better cycling stability are needed. Third, lightweight cold plate materials and high-efficiency heat pipe wicks can reduce mass. Fourth, interfaces with low thermal resistance and long-term stability can improve heat transfer from cells to cooling structures. Table 9 summarizes material targets.
| Component | Desired property | Current limitation | Future direction |
|---|---|---|---|
| Coolant | High \(k\), low \(\mu\), high electrical resistivity | Trade-off between cooling and insulation | Advanced dielectric fluids |
| Phase change material | High \(L\), high \(k\), stable cycling | Low \(k\), leakage, degradation | Composite PCM with fillers |
| Cold plate | Low mass, high \(k\), low pressure drop | Aluminum mass and sealing | Composite and microchannel design |
| Heat pipe wick | High capillary pressure, high permeability | Capillary limit and dry-out | Nanostructured wicks |
| Thermal interface | Low resistance, high conformability | Pump-out and aging | Advanced gap fillers |
From a structural perspective, I believe the electric vehicle battery pack should be designed as an integrated thermal-mechanical-electrical system. Cell spacing, busbar layout, cooling channel geometry, and pack enclosure should be co-optimized. For example, a liquid cooling channel that improves heat transfer but increases pressure drop may require a larger pump and reduce net energy efficiency. A phase change material that adds mass may reduce driving range. An immersion cooling system that provides excellent uniformity may require a larger volume and stronger sealing. Therefore, structural design must consider the entire electric vehicle battery pack, not only the cooling plate.
From a control perspective, I expect wider use of sensors and digital models. Temperature sensors, flow meters, pressure sensors, and voltage measurements can be fused to estimate the thermal state of the electric vehicle battery pack. A reduced-order thermal model can be written as:
$$ \dot{x} = A x + B u + E d $$
$$ y = C x + D u $$
where \(x\) is the thermal state vector, \(u\) is the control input, \(d\) is the disturbance, and \(y\) is the measured output. Model predictive control can then optimize cooling power while respecting temperature limits. This is especially important for fast charging, where heat generation changes rapidly and the electric vehicle battery pack may approach thermal limits.
From an evaluation perspective, I argue that temperature reduction alone is not enough. The evaluation of an electric vehicle battery pack cooling system should include maximum temperature, temperature difference, cooling efficiency, parasitic power, mass, volume, cost, reliability, maintenance, and environmental impact. A multi-criteria evaluation matrix can be defined as:
$$ S = \sum_{i=1}^{n} w_i s_i $$
where \(S\) is the total score, \(w_i\) is the weight of criterion \(i\), and \(s_i\) is the normalized score. This approach allows different cooling methods to be compared fairly under different vehicle requirements.
10. Summary of Research Gaps
Current cooling technologies for the electric vehicle battery pack each have bottlenecks. Air cooling has a low performance ceiling. Liquid cooling has high pump power and poor lightweighting potential. Phase change materials lack long-term durability. Heat pipes have complex manufacturing and may fail at high temperature. Immersion cooling faces compatibility, volume efficiency, and maintenance issues. Existing studies often focus on temperature reduction indicators while neglecting energy consumption, cost, and engineering reliability. Many results are also disconnected from real-world service conditions. In my view, future work should move toward multi-objective coordination and break through from four aspects: materials, structures, control, and evaluation.
I also believe that the electric vehicle battery pack should be tested under realistic duty cycles, including high-temperature environments, low-temperature environments, fast charging, aggressive driving, and long-duration operation. A cooling method that works well in a laboratory may fail in a vehicle because of vibration, dust, humidity, altitude, and aging. Therefore, accelerated life testing and field data are essential.
11. Comparative Tables for Practical Selection
For practical selection, I propose the following decision logic. If the electric vehicle battery pack has low power density and low cost requirements, natural or forced air cooling may be sufficient. If the pack must support fast charging and high continuous power, liquid cooling is usually the first choice. If the main challenge is transient peak heating, phase change material cooling can be added as a buffer. If space is limited and heat must be transported over a distance, heat pipes can be integrated. If the highest possible temperature uniformity is required and cost is not the primary constraint, immersion cooling should be considered. Table 10 provides a practical selection guide.
| Application scenario | Recommended primary method | Recommended auxiliary method | Key reason |
|---|---|---|---|
| Low-speed small vehicle | Natural air cooling | None | Low cost and low heat generation |
| Urban commuter vehicle | Forced air cooling | Phase change material | Moderate cost and transient buffering |
| Mainstream passenger vehicle | Liquid cooling | Heat pipe or PCM | High performance and fast charging capability |
| High-performance vehicle | Liquid cooling or immersion cooling | Heat pipe | Extreme heat flux and uniform cooling |
| Fast-charging fleet | Immersion cooling | Liquid cooling | High heat removal and uniform temperature |
| Cold-climate vehicle | Liquid cooling with heating | PCM | Thermal management includes heating and cooling |
12. Conclusion
In this article, I have reviewed cooling methods for the electric vehicle battery pack from the perspective of actual service conditions. I discussed air cooling, liquid cooling, phase change material cooling, heat pipe cooling, and immersion cooling. I explained their principles, advantages, disadvantages, and design considerations. I also provided equations for heat generation, energy balance, convective heat transfer, pressure drop, phase change, heat pipe limits, immersion heat transfer, and multi-objective optimization. Through multiple comparison tables, I showed that each method has a distinct application space. Air cooling is simple and cheap but limited. Liquid cooling is powerful and mature but complex and heavy. Phase change material cooling is passive and uniform but finite. Heat pipe cooling is highly conductive and reliable but manufacturing-intensive. Immersion cooling is uniform and promising but costly and integration-intensive.
For the electric vehicle battery pack, the best solution is rarely a single technology. A hybrid approach that combines the strengths of multiple methods is often more effective. I believe future progress will come from advanced materials, optimized structures, intelligent control, and comprehensive evaluation. The goal is not only to reduce maximum temperature, but also to achieve low temperature difference, low parasitic power, low mass, low cost, high reliability, and long service life. Only then can thermal management fully support the safe, efficient, and widespread adoption of the electric vehicle battery pack.