
In my work, I focused on the thermal management of an electric vehicle battery pack because the electric vehicle battery pack strongly influences driving range, service life, safety, and fast-charging capability. I treated the electric vehicle battery pack as a coupled thermal-fluid system in which lithium-ion cells generate heat,导热垫 transfer heat to a liquid cooling plate, and coolant removes heat through forced convection. My main objective was to design and optimize a side-mounted liquid cooling plate with staggered rib and groove structures so that the electric vehicle battery pack could remain within a suitable temperature window while avoiding excessive pressure drop and pumping power.
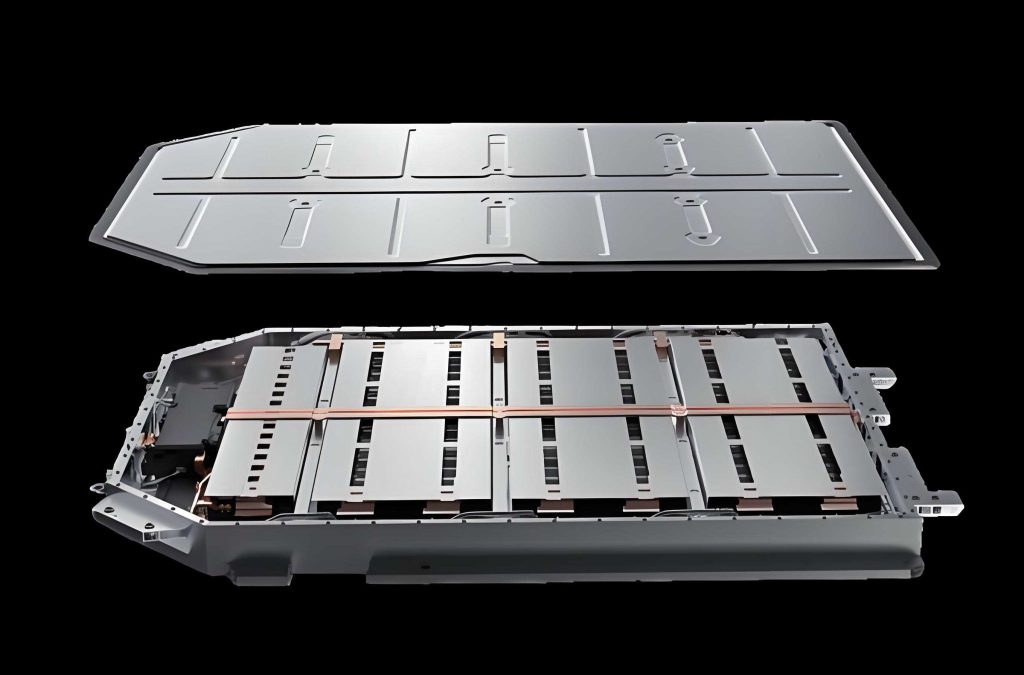
I started from the thermal characteristics of a single lithium-ion cell and then extended the analysis to a full electric vehicle battery pack. The electric vehicle battery pack must normally operate between about 15 °C and 35 °C, and the maximum temperature difference inside the electric vehicle battery pack should remain below 5 °C. When the electric vehicle battery pack operates above this range, capacity fade, impedance growth, and thermal runaway risk increase. When it operates below this range, electrolyte viscosity rises, lithium plating can occur, and charging performance deteriorates. Therefore, I evaluated both maximum temperature and temperature uniformity for every design case.
I used numerical simulation, single-factor analysis, surrogate modeling, and multi-objective optimization. I first obtained the heat generation rate of a 190 Ah prismatic ternary lithium-ion cell through hybrid pulse power characterization tests. I then built a three-dimensional thermal model of the cell and validated it against temperature-rise experiments. After that, I constructed an electric vehicle battery pack model and compared bottom-mounted and side-mounted liquid cooling plates. I found that the side-mounted configuration reduced the longitudinal temperature difference of the electric vehicle battery pack more effectively. I also compared same-side and staggered inlet/outlet arrangements and selected the staggered side-mounted layout as the baseline.
To further improve cooling performance, I introduced convex ribs and concave grooves into the side cooling plate. I studied circular, diamond, forward teardrop, and reverse teardrop shapes under different flow rates, spacings, and diameters. I evaluated maximum temperature, surface temperature standard deviation, pressure drop, Nusselt number ratio, friction factor ratio, and the performance evaluation criterion. I selected circular ribs and circular grooves because they provided the best balance among heat transfer enhancement, temperature uniformity, and hydraulic penalty. I then proposed a staggered rib-groove liquid cooling plate and optimized its geometry using a radial basis function surrogate model and the NSGA-II algorithm. Finally, I assessed the optimized electric vehicle battery pack under fast charging, low-temperature heating, and high-temperature high-speed cruising conditions.
The electric vehicle battery pack studied here had a total capacity of 139.2 kWh and was constructed from cells arranged in a 2P88S configuration. Because full-scale simulation of the entire electric vehicle battery pack would be computationally expensive, I selected one representative layer for detailed analysis. The electric vehicle battery pack was divided into upper and lower layers, and each layer contained eight modules. I used a side-mounted liquid cooling plate between adjacent modules. This arrangement increased the heat transfer area and used the high through-plane thermal conductivity of the prismatic cells.
For the cell thermal model, I assumed the cell was a homogeneous rectangular solid with orthotropic thermal conductivity. The equivalent density, specific heat, and thermal conductivity were calculated from the layered materials inside the cell. The equivalent specific heat was
$$ C_p = \frac{\sum_{i=1}^{n} C_i m_i}{m} $$
and the equivalent density was
$$ \rho = \frac{m}{v} = \frac{\sum_{i=1}^{n} m_i}{\sum_{i=1}^{n} v_i}. $$
The through-plane thermal conductivity was calculated as a series resistance, while the in-plane thermal conductivity was calculated as a parallel resistance:
$$ \lambda_y = \frac{\sum_{i=1}^{n} L_{yi}}{\sum_{i=1}^{n} \frac{L_{yi}}{\lambda_i}}, \qquad \lambda_x = \lambda_z = \frac{\sum_{i=1}^{n} \lambda_i L_{xi}}{\sum_{i=1}^{n} L_{xi}}. $$
I treated the heat generation of the lithium-ion cell as the sum of reaction heat, Joule heat, polarization heat, and side-reaction heat:
$$ Q_t = Q_r + Q_j + Q_p + Q_s. $$
For normal operating conditions, I neglected side reactions. The Joule heat and polarization heat were combined as
$$ Q_j + Q_p = I^2 (R_e + R_p), $$
and the total heat generation rate per unit volume was expressed using the Bernardi model:
$$ \dot{q} = \frac{I}{V_b}\left(U_{oc} – U – T\frac{\partial U_{oc}}{\partial T}\right). $$
In my simulation, I converted the cell internal resistance and entropy coefficient into a heat generation rate that varied with state of charge. The state of charge during constant-current discharge was updated as
$$ SOC = SOC_0 – \frac{It}{3600 C_R}. $$
I fitted the heat generation rate as a sixth-order polynomial of discharge time:
$$ \dot{q}(t) = A_1 t^6 + A_2 t^5 + A_3 t^4 + A_4 t^3 + A_5 t^2 + A_6 t + A_7. $$
The cell parameters and thermal properties used in my electric vehicle battery pack model are summarized in Table 1 and Table 2.
| Parameter | Value |
|---|---|
| Cell chemistry | Ternary lithium-ion |
| Nominal capacity | 190 Ah |
| Nominal voltage | 3.8 V |
| Cell mass | 1.8 kg |
| Cell dimensions | 146 mm × 80 mm × 103 mm |
| Charging temperature range | −30 °C to 50 °C |
| Discharging temperature range | −20 °C to 50 °C |
| Optimal operating range | 15 °C to 35 °C |
| Maximum continuous discharge | 1C |
| Maximum pulse discharge | 2C |
| Component | Density (kg/m³) | Specific heat (J/kg·K) | Thermal conductivity (W/m·K) | Viscosity (kg/m·s) |
|---|---|---|---|---|
| Cell equivalent | 2478.5 | 1100 | 18.2 / 2 / 18.2 | — |
| Aluminum alloy | 2719 | 871 | 180 | — |
| 50% ethylene glycol aqueous solution | 1071.1 | 3300 | 0.384 | 0.017 at 25 °C |
| Thermal pad | 2150 | 1200 | 2 | — |
I performed hybrid pulse power characterization tests at 25 °C over a state-of-charge range from 90% to 10%. Each pulse cycle included a 30 s discharge pulse, a 25 min rest, a 30 s charge pulse, and another rest. I repeated the procedure at 0.5C, 1C, and 2C. The discharge and charge internal resistances are given in Table 3 and Table 4. I found that the internal resistance decreased as the charge/discharge rate increased, and it rose sharply at low state of charge. This behavior is important because a low-state-of-charge high-power event can cause a rapid temperature rise inside the electric vehicle battery pack.
| SOC | 0.1 | 0.2 | 0.3 | 0.4 | 0.5 | 0.6 | 0.7 | 0.8 | 0.9 |
|---|---|---|---|---|---|---|---|---|---|
| 0.5C discharge resistance (mΩ) | 0.59 | 0.42 | 0.32 | 0.28 | 0.28 | 0.33 | 0.37 | 0.35 | 0.34 |
| 1C discharge resistance (mΩ) | 0.45 | 0.33 | 0.25 | 0.23 | 0.25 | 0.31 | 0.33 | 0.32 | 0.28 |
| 2C discharge resistance (mΩ) | 0.37 | 0.27 | 0.22 | 0.20 | 0.23 | 0.28 | 0.29 | 0.25 | 0.24 |
| SOC | 0.1 | 0.2 | 0.3 | 0.4 | 0.5 | 0.6 | 0.7 | 0.8 | 0.9 |
|---|---|---|---|---|---|---|---|---|---|
| 0.5C charge resistance (mΩ) | 0.39 | 0.29 | 0.24 | 0.24 | 0.26 | 0.30 | 0.32 | 0.31 | 0.32 |
| 1C charge resistance (mΩ) | 0.30 | 0.23 | 0.20 | 0.21 | 0.24 | 0.27 | 0.28 | 0.28 | 0.29 |
| 2C charge resistance (mΩ) | 0.23 | 0.18 | 0.17 | 0.18 | 0.20 | 0.24 | 0.25 | 0.26 | 0.26 |
I validated the cell thermal model by comparing simulated average surface temperature with measured temperature-rise data at 0.5C, 1C, and 2C. The simulated results agreed with the experiments within 8%. At 2C discharge, the cell surface temperature reached about 54 °C, which exceeded the recommended upper limit for the electric vehicle battery pack. This confirmed that passive cooling was insufficient and that a liquid cooling system was required.
For the computational fluid dynamics model, I solved the continuity, momentum, and energy equations. The continuity equation was
$$ \nabla \cdot \vec{U} = 0. $$
The momentum equation for the coolant was
$$ \rho_f (\vec{U}\cdot\nabla)\vec{U} = -\nabla P + \mu_f \nabla^2 \vec{U}. $$
The energy equation for the fluid was
$$ \rho_f c_{p,f} \vec{U}\cdot\nabla T_f = \nabla \cdot (\lambda_f \nabla T_f), $$
and the energy equation for the solid regions was
$$ \nabla^2 T_s = 0. $$
I used the realizable k-epsilon model for turbulence, the SIMPLEC algorithm for pressure-velocity coupling, and poly-hexcore meshes for the solid and fluid domains. I checked grid independence using coarse, medium, and fine meshes. The medium mesh differed from the fine mesh by less than 0.1% in maximum temperature and about 0.21% in pressure drop. Therefore, I selected the medium mesh for all subsequent simulations to balance accuracy and computational cost.
I then compared a bottom-mounted liquid cooling plate and a side-mounted liquid cooling plate for the electric vehicle battery pack. The bottom-mounted design is common in many electric vehicle battery pack architectures because it supports the modules and is easy to package. The side-mounted design increases the contact area and places the cooling plate between modules, which improves temperature uniformity. The results are shown in Table 5. The side-mounted design reduced the maximum temperature from 39.67 °C to 35.60 °C, reduced the cell maximum temperature difference from 12.15 °C to 6.90 °C, and reduced the electric vehicle battery pack maximum temperature difference from 13.27 °C to 10.46 °C.
| Cooling layout | Electric vehicle battery pack maximum temperature (°C) | Cell maximum temperature difference (°C) | Electric vehicle battery pack maximum temperature difference (°C) |
|---|---|---|---|
| Bottom-mounted harmonica cold plate | 39.67 | 12.15 | 13.27 |
| Side-mounted harmonica cold plate | 35.60 | 6.90 | 10.46 |
Although the side-mounted design was better, the maximum temperature was still close to 35 °C and the maximum temperature difference was still above 5 °C. I therefore studied the inlet and outlet arrangement. I compared same-side inlet/outlet and staggered inlet/outlet layouts. In the same-side layout, all coolant entered on one side and exited on the same side. In the staggered layout, the inlet and outlet were distributed on opposite sides of the electric vehicle battery pack. The staggered layout reduced the maximum temperature from 35.60 °C to 34.50 °C and reduced the electric vehicle battery pack maximum temperature difference from 10.46 °C to 8.50 °C, with only a negligible change in cell maximum temperature difference. I selected the staggered side-mounted liquid cooling plate as my baseline for further optimization.
| Inlet/outlet layout | Electric vehicle battery pack maximum temperature (°C) | Cell maximum temperature difference (°C) | Electric vehicle battery pack maximum temperature difference (°C) |
|---|---|---|---|
| Same-side inlet/outlet | 35.60 | 6.90 | 10.46 |
| Staggered inlet/outlet | 34.50 | 6.93 | 8.50 |
To enhance heat transfer without excessive pumping power, I introduced convex ribs and concave grooves. I studied four shapes: circular, diamond, forward teardrop, and reverse teardrop. I evaluated the maximum surface temperature, surface temperature standard deviation, pressure drop, Nusselt number ratio, friction factor ratio, and performance evaluation criterion. The Reynolds number was defined as
$$ Re = \frac{\rho_f u_{in} D_h}{\mu_f}, $$
where the hydraulic diameter was
$$ D_h = \frac{2 H_{ch} W_{ch}}{H_{ch} + W_{ch}}. $$
The friction factor was
$$ f = \frac{2 \Delta p D_h}{\rho_f L u_{aver}^2}. $$
The convective heat transfer coefficient was
$$ h = \frac{q_{eff} A_c}{A_{con}(T_{w,aver} – T_{f,aver})}, $$
and the average Nusselt number was
$$ Nu_{aver} = \frac{h_{aver} D_h}{\lambda_f}. $$
I used the performance evaluation criterion to compare enhanced designs with the original harmonica cold plate:
$$ PEC = \frac{Nu/Nu_0}{(f/f_0)^{1/3}}. $$
When PEC is greater than 1, the enhanced design provides a better overall thermal-hydraulic performance than the baseline for the same friction loss. The volume flow rate was
$$ Q_v = A_{in} u_{in}. $$
The shape comparison is summarized in Table 6. Circular ribs and circular grooves gave the best combination of heat transfer and pressure drop. Circular ribs produced the lowest maximum temperature, while circular grooves produced the highest PEC among the groove shapes. Diamond shapes had the weakest heat transfer enhancement. I therefore selected circular ribs and circular grooves for the staggered rib-groove design.
| Shape | Structure | Maximum temperature trend | Temperature standard deviation trend | Pressure drop trend | PEC trend |
|---|---|---|---|---|---|
| Circular | Rib / groove | Lowest / second lowest | Higher / lower | Highest rib, moderate groove | Best overall |
| Diamond | Rib / groove | Highest / highest | Lower / lowest | Lowest | Weakest |
| Forward teardrop | Rib / groove | Second lowest / third | Moderate | Moderate | Good |
| Reverse teardrop | Rib / groove | Third / second | Moderate | Moderate | Good |
I then analyzed the effect of coolant volume flow rate. I tested 1.21 L/min, 1.81 L/min, 2.42 L/min, 3.02 L/min, and 3.62 L/min. As flow rate increased, the maximum temperature decreased and temperature uniformity improved. However, pressure drop increased rapidly. For the circular rib design, the maximum temperature decreased from 35.15 °C at 1.21 L/min to 30.20 °C at 3.62 L/min. For the circular groove design, it decreased from 35.32 °C to 30.35 °C. The pressure drop of the rib design was consistently higher than that of the groove design. At the highest flow rate, the rib pressure drop was about 28.5% higher than the groove pressure drop. Since the electric vehicle battery pack benefits from lower pumping power, I selected 2.42 L/min as a balanced flow rate.
| Volume flow rate (L/min) | Rib maximum temperature (°C) | Groove maximum temperature (°C) | Rib pressure drop trend | Groove pressure drop trend | PEC trend |
|---|---|---|---|---|---|
| 1.21 | 35.15 | 35.32 | Lowest | Lowest | Highest |
| 1.81 | 33.10 | 33.25 | Moderate | Moderate | High |
| 2.42 | 31.65 | 31.90 | Balanced | Balanced | Balanced |
| 3.02 | 30.70 | 30.95 | High | High | Lower |
| 3.62 | 30.20 | 30.35 | Very high | High | Lowest |
Next, I studied the spacing between rib and groove structures. I tested 35 mm, 30 mm, and 25 mm. Reducing the spacing increased the number of enhanced structures and improved heat transfer. The maximum temperature of the rib design decreased from 31.76 °C to 31.64 °C, while the groove design showed a similar but weaker trend. The surface temperature standard deviation increased slightly as spacing decreased, meaning that temperature uniformity became slightly worse. The pressure drop of the rib design increased rapidly as spacing decreased, whereas the groove pressure drop decreased slightly because the grooves provided additional flow area. The PEC of both designs increased as spacing decreased. I selected 25 mm because it provided the best overall thermal-hydraulic performance.
| Spacing (mm) | Rib maximum temperature (°C) | Groove maximum temperature (°C) | Rib pressure drop trend | Groove pressure drop trend | PEC trend |
|---|---|---|---|---|---|
| 35 | 31.76 | 31.95 | Lowest | Moderate | Lowest |
| 30 | 31.70 | 31.90 | Moderate | Moderate | Moderate |
| 25 | 31.64 | 31.85 | Highest | Slightly lower | Highest |
I also investigated the diameter of the circular ribs and grooves. I tested 6 mm, 7 mm, 8 mm, 9 mm, and 10 mm. Increasing the diameter improved heat transfer for both ribs and grooves. The rib design showed a clear decrease in maximum temperature from 31.81 °C at 6 mm to 31.65 °C at 10 mm. The groove design showed a smaller decrease. The surface temperature standard deviation increased with diameter, indicating a slight loss of temperature uniformity. The pressure drop of the rib design increased rapidly with diameter, reaching 394.69 Pa at 10 mm, while the groove design decreased to 258.75 Pa. The Nusselt number ratio increased for both designs, and the rib design reached about 1.60 times the baseline at 10 mm. The friction factor ratio of the rib design increased from 1.04 to 1.23, while the groove design decreased from 0.86 to 0.78. Because the PEC continued to increase with diameter, I selected 10 mm as the diameter for both circular ribs and circular grooves.
| Diameter (mm) | Rib maximum temperature (°C) | Groove maximum temperature (°C) | Rib pressure drop (Pa) | Groove pressure drop (Pa) | PEC trend |
|---|---|---|---|---|---|
| 6 | 31.81 | 31.98 | Lower | Higher | Lowest |
| 7 | 31.77 | 31.95 | Moderate | Moderate | Low |
| 8 | 31.73 | 31.92 | Moderate | Moderate | Moderate |
| 9 | 31.69 | 31.88 | High | Lower | High |
| 10 | 31.65 | 31.85 | 394.69 | 258.75 | Highest |
Based on these single-factor studies, I proposed a staggered rib-groove liquid cooling plate in which circular ribs and circular grooves alternate along the flow direction. The rib height and groove depth were allowed to vary from inlet to outlet. I defined the first and last rib heights as \(h_1\) and \(h_{19}\), and the first and last groove depths as \(d_1\) and \(d_{18}\). The intermediate values were obtained by linear interpolation:
$$ \delta_h = \frac{h_{19} – h_1}{18}, \qquad h_i = h_1 + (i-1)\delta_h, \quad i=1,2,\ldots,19, $$
$$ \delta_d = \frac{d_{18} – d_1}{17}, \qquad d_j = d_1 + (j-1)\delta_d, \quad j=1,2,\ldots,18. $$
I set the rib height range to 0 mm ≤ \(h\) ≤ 2 mm and the groove depth range to −2 mm ≤ \(d\) ≤ 0 mm. I used an optimal Latin hypercube design to sample 84 cases. For each case, I created the geometry, generated the mesh, and solved the CFD model. I then built a radial basis function surrogate model to map the design variables to the responses. The responses were the cold plate surface maximum temperature \(T_{max}\), the surface temperature standard deviation \(T_{sd}\), and the pressure drop \(\Delta P\). I validated the surrogate model using the coefficient of determination \(R^2\). The values were 0.90091 for \(T_{max}\), 0.92914 for \(T_{sd}\), and 0.96244 for \(\Delta P\), all above 0.9.
| Variable | Geometric parameter | Lower bound | Upper bound |
|---|---|---|---|
| \(X_1\) | \(h_1\) (mm) | 0 | 2 |
| \(X_2\) | \(h_{19}\) (mm) | 0 | 2 |
| \(X_3\) | \(d_1\) (mm) | −2 | 0 |
| \(X_4\) | \(d_{18}\) (mm) | −2 | 0 |
| Response | \(R^2\) |
|---|---|
| Maximum temperature \(T_{max}\) | 0.90091 |
| Surface temperature standard deviation \(T_{sd}\) | 0.92914 |
| Pressure drop \(\Delta P\) | 0.96244 |
I formulated the optimization problem as
$$ \begin{aligned} \text{find} \quad & x = [h_1, h_{19}, d_1, d_{18}] \\ \text{minimize} \quad & T_{max} = f_1(x), \\ & T_{sd} = f_2(x), \\ & \Delta P = f_3(x) \\ \text{subject to} \quad & \Delta P < 300.4 \ \text{Pa}. \end{aligned} $$
I used the NSGA-II algorithm with a population of 20, 100 generations, a mutation probability of 0.1, and a crossover probability of 0.8. The Pareto front showed that lower maximum temperature and lower temperature standard deviation generally required higher pressure drop. I selected the compromise solution with \(T_{max} = 31.726 °C\), \(T_{sd} = 1.25802 °C\), and \(\Delta P = 276.7094 Pa\). After rounding the design variables, I obtained \(h_1 = 0 mm\), \(h_{19} = 2 mm\), \(d_1 = -0.8 mm\), and \(d_{18} = -2 mm\). This means that the rib height increased from zero at the inlet to 2 mm at the outlet, while the groove depth increased from 0.8 mm to 2 mm along the flow direction. The rounded design produced \(T_{max} = 31.712 °C\), \(T_{sd} = 1.2612 °C\), and \(\Delta P = 273.4 Pa\).
| Design | \(X_1\) (mm) | \(X_2\) (mm) | \(X_3\) (mm) | \(X_4\) (mm) | \(T_{max}\) (°C) | \(T_{sd}\) (°C) | \(\Delta P\) (Pa) |
|---|---|---|---|---|---|---|---|
| Optimal design | 1.226e−4 | 1.9987 | −0.82138 | −1.9967 | 31.726 | 1.25802 | 276.7094 |
| Rounded design | 0 | 2 | −0.8 | −2 | 31.712 | 1.2612 | 273.4 |
I then placed the optimized staggered rib-groove liquid cooling plate into the electric vehicle battery pack and compared it with the original side-mounted harmonica cold plate. The electric vehicle battery pack maximum temperature decreased from 34.50 °C to 33.46 °C, a reduction of 3%. The cell maximum temperature difference decreased from 6.93 °C to 6.23 °C, a reduction of 10.1%. The electric vehicle battery pack maximum temperature difference decreased from 8.50 °C to 7.74 °C, a reduction of 8.94%. The pressure drop decreased from 2703.6 Pa to 2460.6 Pa, a reduction of 8.99%. These results showed that the staggered rib-groove design improved both cooling performance and temperature uniformity while reducing hydraulic penalty.
| Design | Electric vehicle battery pack maximum temperature (°C) | Cell maximum temperature difference (°C) | Electric vehicle battery pack maximum temperature difference (°C) | Pressure drop (Pa) |
|---|---|---|---|---|
| Optimized staggered rib-groove | 33.46 | 6.23 | 7.74 | 2460.6 |
| Original side harmonica plate | 34.50 | 6.93 | 8.50 | 2703.6 |
| Improvement | −3% | −10.1% | −8.94% | −8.99% |
Finally, I evaluated the optimized electric vehicle battery pack under three representative operating conditions: fast charging, low-temperature heating, and high-temperature high-speed cruising. For fast charging, I used a stepped charging strategy. From 0 to 0.6 state of charge, the electric vehicle battery pack was charged at 2C. From 0.6 to 0.9 state of charge, it was charged at 1C. From 0.9 to 1.0 state of charge, it was charged at 0.5C. The total charging time was 2880 s, and the electric vehicle battery pack reached 80% state of charge in about 30 min. The peak maximum temperature occurred at the end of the 2C stage, reaching 30.13 °C, with a maximum temperature difference of 4.53 °C. At the end of charging, the maximum temperature was 26.45 °C and the maximum temperature difference was 1.30 °C. Both values remained within the desired range.
| Fast charging stage | State of charge range | Charge rate | Peak maximum temperature (°C) | Peak maximum temperature difference (°C) |
|---|---|---|---|---|
| Stage 1 | 0–0.6 | 2C | 30.13 | 4.53 |
| Stage 2 | 0.6–0.9 | 1C | Lower | Lower |
| Stage 3 | 0.9–1.0 | 0.5C | 26.45 at end | 1.30 at end |
For low-temperature heating, I initialized the electric vehicle battery pack, thermal pads, and cold plates at −20 °C. The coolant inlet temperature was 15 °C, and the inlet flow velocity was 2 m/s. The electric vehicle battery pack minimum temperature rose above 0 °C at 620 s, and it reached 10 °C at 1210 s. The heating rate remained around 1.5 °C/min, which met the engineering requirement of at least 0.3 °C/min. At the end of heating, the maximum temperature was 15.03 °C and the minimum temperature was 10.23 °C. The electric vehicle battery pack was therefore ready for low-rate charging and normal operation.
| Low-temperature heating metric | Value |
|---|---|
| Initial temperature | −20 °C |
| Coolant inlet temperature | 15 °C |
| Inlet velocity | 2 m/s |
| Time to minimum temperature above 0 °C | 620 s |
| Time to minimum temperature above 10 °C | 1210 s |
| Heating rate | ≈1.5 °C/min |
| Final maximum temperature | 15.03 °C |
| Final minimum temperature | 10.23 °C |
For high-temperature high-speed cruising, I assumed the electric vehicle battery pack started at 40 °C after being parked in a hot environment. The vehicle then cruised at 120 km/h. I estimated the road load power from rolling resistance and aerodynamic drag:
$$ P = \frac{1}{3600 \eta} \left( G f u_a + \frac{C_D A u_a^3}{76140} \right). $$
The required power was about 65 kW, which corresponded to approximately 0.5C discharge for the electric vehicle battery pack. The coolant inlet temperature was 25 °C, and the inlet velocity was 2 m/s. The electric vehicle battery pack temperature dropped from 40 °C to below 35 °C after 390 s, and the maximum temperature difference fell below 5 °C after 770 s. At steady state, the maximum temperature was 25.77 °C and the maximum temperature difference was 0.66 °C. The optimized liquid cooling system therefore satisfied the thermal requirements under high-temperature high-speed cruising.
| High-temperature high-speed cruising metric | Value |
|---|---|
| Initial temperature | 40 °C |
| Cruising speed | 120 km/h |
| Coolant inlet temperature | 25 °C |
| Inlet velocity | 2 m/s |
| Time to maximum temperature below 35 °C | 390 s |
| Time to maximum temperature difference below 5 °C | 770 s |
| Steady maximum temperature | 25.77 °C |
| Steady maximum temperature difference | 0.66 °C |
Overall, my study showed that the placement of the liquid cooling plate inside the electric vehicle battery pack is as important as the internal channel design. A side-mounted layout with staggered inlet and outlet positions improved the temperature distribution of the electric vehicle battery pack. Adding circular ribs and grooves further enhanced heat transfer. The rib structures increased local flow velocity and disturbed the thermal boundary layer, while the groove structures reduced pressure drop and provided additional flow area. By combining both structures in a staggered arrangement and optimizing their heights and depths, I obtained a liquid cooling plate that reduced the maximum temperature, cell temperature difference, electric vehicle battery pack temperature difference, and pressure drop simultaneously.
I also confirmed that the optimized electric vehicle battery pack cooling system performed well under fast charging, low-temperature heating, and high-temperature high-speed cruising. In fast charging, the electric vehicle battery pack remained below 35 °C and the temperature difference remained below 5 °C. In low-temperature heating, the electric vehicle battery pack reached a safe operating temperature within a reasonable time. In high-temperature high-speed cruising, the electric vehicle battery pack cooled rapidly from 40 °C and maintained excellent temperature uniformity. These results support the use of staggered rib-groove side-mounted liquid cooling plates in advanced electric vehicle battery pack thermal management systems.
For future work, I would include more detailed components such as coolant manifolds, module separators, and full cooling loops in the electric vehicle battery pack model. I would also build an experimental electric vehicle battery pack test bench to validate the cooling performance under real operating conditions. In addition, I would explore adaptive flow control and integrated heating-cooling modes to improve the annual efficiency of the electric vehicle battery pack thermal management system. Such extensions would help move the design from numerical optimization toward production-ready electric vehicle battery pack cooling solutions.